SINUMERIK 840D sl. Service - Functions. Manual (2018-2020) - page 72

TE3: Speed/torque coupling, master-slave
19.9 Examples
Preconditions
● One configured master axis
MD37250 $MA_MS_ASSIGN_MASTER_SPEED_CMD ≠ 0
● Activation of a master-slave coupling via
MD37262 $MA_MS_COUPLING_ALWAYS_ACTIVE=0
● The coupling is open.
Typical sequence of operations
Action
Effect/comment
● Approach coupling position
Each axis moves to the coupling position.
● Close coupling mechanically
Both axes are mechanically coupled to one anoth-
er.
● Request to close the coupling
PLC interface signal "Master/slave on" DB32, ...
DBX24.7 is set.
● Read back coupling state
When the axis is at a standstill, the coupled slave
axis sets PLC interface signal "Master/slave ac-
tive" DB32, ... DBX96.7 and clears "Position con-
troller active" DB32, ... DBX61.5.
Wait for checkback signal.
● Moving the master-slave group
The master axis is moved.
19.9.3
Closing/separating the coupling via the part program for the SINUMERIK 840D
sl
This application allows you to close or separate a master-slave coupling between the machine
axes AX1=Master axis and AX2=Slave via the part program.
Preconditions
● A configured master axis MD37250 0 0.
● Not a static master-slave coupling:
MD37262 $MA_MS_COUPLING_ALWAYS_ACTIVE= 0
● The coupling is open.
Parts program
Program code
Comment
N10 G0 AX1=0 AX2=0
; Approach the coupling position on an axis-for-axis basis
N20 MASLON (AX2)
; (mechanically connect the axes)
; Close the coupling.
N30 AX1=100
; Move the master-slave group using the master axis.
Special functions
Function Manual, 12/2018, A5E40874099B AB
755

TE3: Speed/torque coupling, master-slave
19.9 Examples
Program code
Comment
N40 MASLOF (AX2)
; Open the coupling.
; (Mechanically separate the axes)
N50 AX1=200 AX2=200
; Move the axes separately.
N60 M30
19.9.4
Release the mechanical brake
This application allows implementation of a brake control for machine axes AX1=Master axis
and AX2=Slave axis in a master-slave coupling.
Preconditions
● Master-slave coupling is configured.
● Axes are stationary.
● No servo enable signals.
Typical sequence of operations
Action
Effect/comment
● Request to close the coupling
The following PLC interface signal is set:
DB31, ... DBX24.7 (Master/Slave ON)
● Set controller enable
PLC interface signal "Servo enable" DB31, ...
DBX2.1 is set for both axes.
● Interpreting the feedback
Link PLC interface signals of the master axis using
AND:
DB31, ... DBX61.7 (current controller active)
DB31, ... DBX61.6 (speed controller active)
DB31, ... DBX61.5 (position controller active)
Link PLC interface signals of the saster axis using
AND:
DB31, ... DBX61.7 (current controller active)
DB31, ... DBX61.6 (speed controller active)
DB31, ... DBX96.7 (master/slave active)
● Release brakes
If the result of the AND operations on the master
and slave axes is ≠ 0, the brake may be released.
Special functions
756
Function Manual, 12/2018, A5E40874099B AB

TE3: Speed/torque coupling, master-slave
19.10 Data lists
19.10
Data lists
19.10.1
Machine data
19.10.1.1
Axis/spindlespecific machine data
Number
Identifier: $MA_
Description
37250
MS_ASSIGN_MASTER_SPEED_CMD
Leading axis for speed setpoint coupling
37252
MS_ASSIGN_MASTER_TORQUE_CTR
Leading axis for torque distribution
37254
MS_TORQUE_CTRL_MODE
Connection of torque control output
37255
MS_TORQUE_CTRL_ACTIVATION
Activate torque compensatory control
37256
MS_TORQUE_CTRL_P_GAIN
Gain factor of torque compensatory controller
37258
MS_TORQUE_CTRL_I_TIME
Reset time for torque compensatory controller
37260
MS_MAX_CTRL_VELO
Limitation of torque compensatory control
37262
MS_COUPLING_ALWAYS_ACTIVE
Permanent master-slave coupling
37263
MS_SPIND_COUPLING_MODE
Coupling characteristics of a spindle
37264
MS_TENSION_TORQUE
Master-slave tension torque
37268
MS_TORQUE_WEIGHT_SLAVE
Torque weighting of the slave axis
37270
MS_VELO_TOL_COARSE
Master-slave velocity tolerance "coarse"
37272
MS_VELO_TOL_FINE
Master-slave velocity tolerance "fine"
37274
MS_MOTION_DIR_REVERSE
Invert master-slave direction of travel
19.10.2
System variables
After a block search, the coupling status and associated axis positions can be adjusted
subsequently by means of a system ASUB (asynchronous subroutine) "PROGEVENT.SPF".
System variables $P_SEARCH_MASL_C, $P_SEARCH_MASL_D and $AA_MASL_STAT are
available for this purpose; they can be used to alter the positional offset between the coupled
axes and the coupling status:
Identifier
Meaning
$P_SEARCH_MASLC[following axis name]
This variable registers a change in the coupling state during the
SERUPRO block search.
$P_SEARCH_MASLD[following axis name]
This variable indicates the positional offset between the slave and
master axes at the instant the coupling was closed.
$AA_MASL_STAT[following axis name]
This variable indicates the current coupling state.
Value ≠ 0: "Master-slave coupling active"
In this case, it contains the current machine number of the master
axis and, if the NCU link is active (several operating panel fronts
and NCUs), also the NCU No. at the hundreds position.
Example: 201 for Axis 1 on NCU2.
Special functions
Function Manual, 12/2018, A5E40874099B AB
757

TE3: Speed/torque coupling, master-slave
19.10 Data lists
19.10.3
Signals
19.10.3.1
Signals to axis/spindle
Signal name
SINUMERIK 840D sl
SINUMERIK 828D
Request master-slave torque compensatory controller
DB31,
DBX24.4
DB380x.DBX5000.4
On==1 / Off==0
Request master-slave coupling On==1 / Off==0
DB31,
DBX24.7
DB380x.DBX5000.7
19.10.3.2
Signals from axis/spindle
Signal name
SINUMERIK 840D sl
SINUMERIK 828D
State master-slave speed difference "fine"
DB31, ... DBX96.2
DB390x.DBX5000.2
State master-slave speed difference "coarse"
DB31, ... DBX96.3
DB390x.DBX5000.3
State master-slave torque compensatory controller On==1 / DB31, ... DBX96.4
DB390x.DBX5000.4
Off==0
State master-slave coupling On==1 / Off==0
DB31, ... DBX96.7
DB390x.DBX5000.7
Special functions
758
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20
20.1
Brief description
The handling transformation package has been designed for use on manipulators and robots.
The package is a type of modular system, which enables the customer to configure the
transformation for his machine by setting machine data (provided that the relevant kinematics
are included in the handling transformation package).
Section structure
The "Handling transformation package" section deals with the following topics:
● The "Kinematic transformation (Page 760)" section describes the kinematic transformation
environment.
● The "Definition of terms (Page 760)" section explains some basic terms.
● The "Configuration of the kinematic transformation (Page 763)" section explains the
machine data required for the configuration.
● The "Kinematic descriptions (Page 777)" section uses configuring examples to illustrate
the most commonly used 2-axis to 5-axis kinematics that can be configured with the
"Handling transformation package".
● The "Tool orientation (Page 798)" to "Tool programming (Page 805)" sections handle the
programming. describing orientation programming, the entry of tool parameters and
transformation calls.
Abbreviations
FL
Flange coordinate system
HP
Wrist point coordinate system
IRO
Internal robot coordinate system
p3, q3, r3
Coordinates of the last basic axis
RO
Robot or base center point coordinate system (= basic coordinate system)
WS
Workpiece coordinate system
T
Tool coordinate system
x3, y3, z3
Coordinates of the first wrist axis
Special functions
Function Manual, 12/2018, A5E40874099B AB
759
TE4: Handling transformation package - 840D sl only
20.3 Definition of terms
20.2
Kinematic transformation
Task of a transformation
The purpose of a transformation is to transform movements in the tool tip, which are
programmed in a Cartesian coordinate system, into machine axis positions.
Fields of application
The handling transformation package described here has been designed to cover the largest
possible number of kinematic transformations implemented solely via parameter settings in
machine data. Currently, kinematics with two to maximum six axes to be included in the
transformation can be configured with this package, corresponding to up to five spatial degrees
of freedom. In this case, a maximum of 3 degrees are available for translation and 3 degrees
for orientation, This package thus allows a tool (milling cutter, laser beam) to be oriented by a
5-axis machine in any desired relation to the workpiece in every point of the machining space.
The workpiece is always programmed in the rectangular workpiece coordinate system; any
programmed or set frames rotate and shift this system in relation to the basic system. The
kinematic transformation then converts this information into motion instructions for the real
machine axes. The kinematic transformation requires information about the design
(kinematics) of the machine, which are stored in machine data.
Kinematic categories
The handling transformation package is divided into two categories of kinematics, which can
be selected via machine data:
MD62600 $MC_TRAFO6_KINCLASS (kinematic category)
● STANDARD: This category includes the most commonly used kinematics.
● SPECIAL: Special kinematics
20.3
Definition of terms
20.3.1
Units and directions
Lengths and angles
In the transformation machine data, all lengths are specified in millimeters or inches and, unless
otherwise stated, all angles in degrees at intervals of [ -180°, 180° ].
Direction of rotation
In the case of angles, arrows in the drawings always indicate the mathematically positive
direction of rotation.
Special functions
760
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.3 Definition of terms
20.3.2
Definition of positions and orientations using frames
In order to make a clear distinction from the term "frame" as it is used in the NC language, the
following description explains the meaning of the term "frame" in relation to the handling
transformation package.
Frame
A frame can be used to translate one coordinate system into another. In this respect, a
distinction must be made between translation and rotation. Translation results in an offset; a
rotation, a rotation of the coordinate system with respect to the initial system. Coordinates X,
Y and Z are used as designator for a translation. They are defined so as to result in a legal
coordinate system.
Translation
A translation is always specified in relation to the coordinate directions of the initial system.
These directions are assigned to machine data as follows:
● X direction: ..._POS[ 0 ]
● Y direction: ..._POS[ 1 ]
● Z direction: ..._POS[ 2 ]
Rotation
A rotation is specified in RPY angles A, B and C (R=roll, P=pitch, Y=yaw). The positive direction
of rotation is defined by the right hand rule, i.e. if the thumb on the right hand is pointing in the
direction of the axis of rotation, then the fingers are pointing in the positive angular direction.
Angles A and C are defined in the interval [ -180; +180 ], and B in the interval [ -90; +90 ].
The definitions of the RPY angles are as follows:
● Angle A: 1. rotation about the Z axis of the initial system
● B angle: 2. Rotation through the rotated Y axis
● C angle: 3. rotation about the twice rotated X axis
The RPY angles are assigned to machine data as follows:
● Angle A: ..._RPY[ 0 ]
● B angle: ..._RPY[ 1 ]
● C angle: ..._RPY[ 2 ]
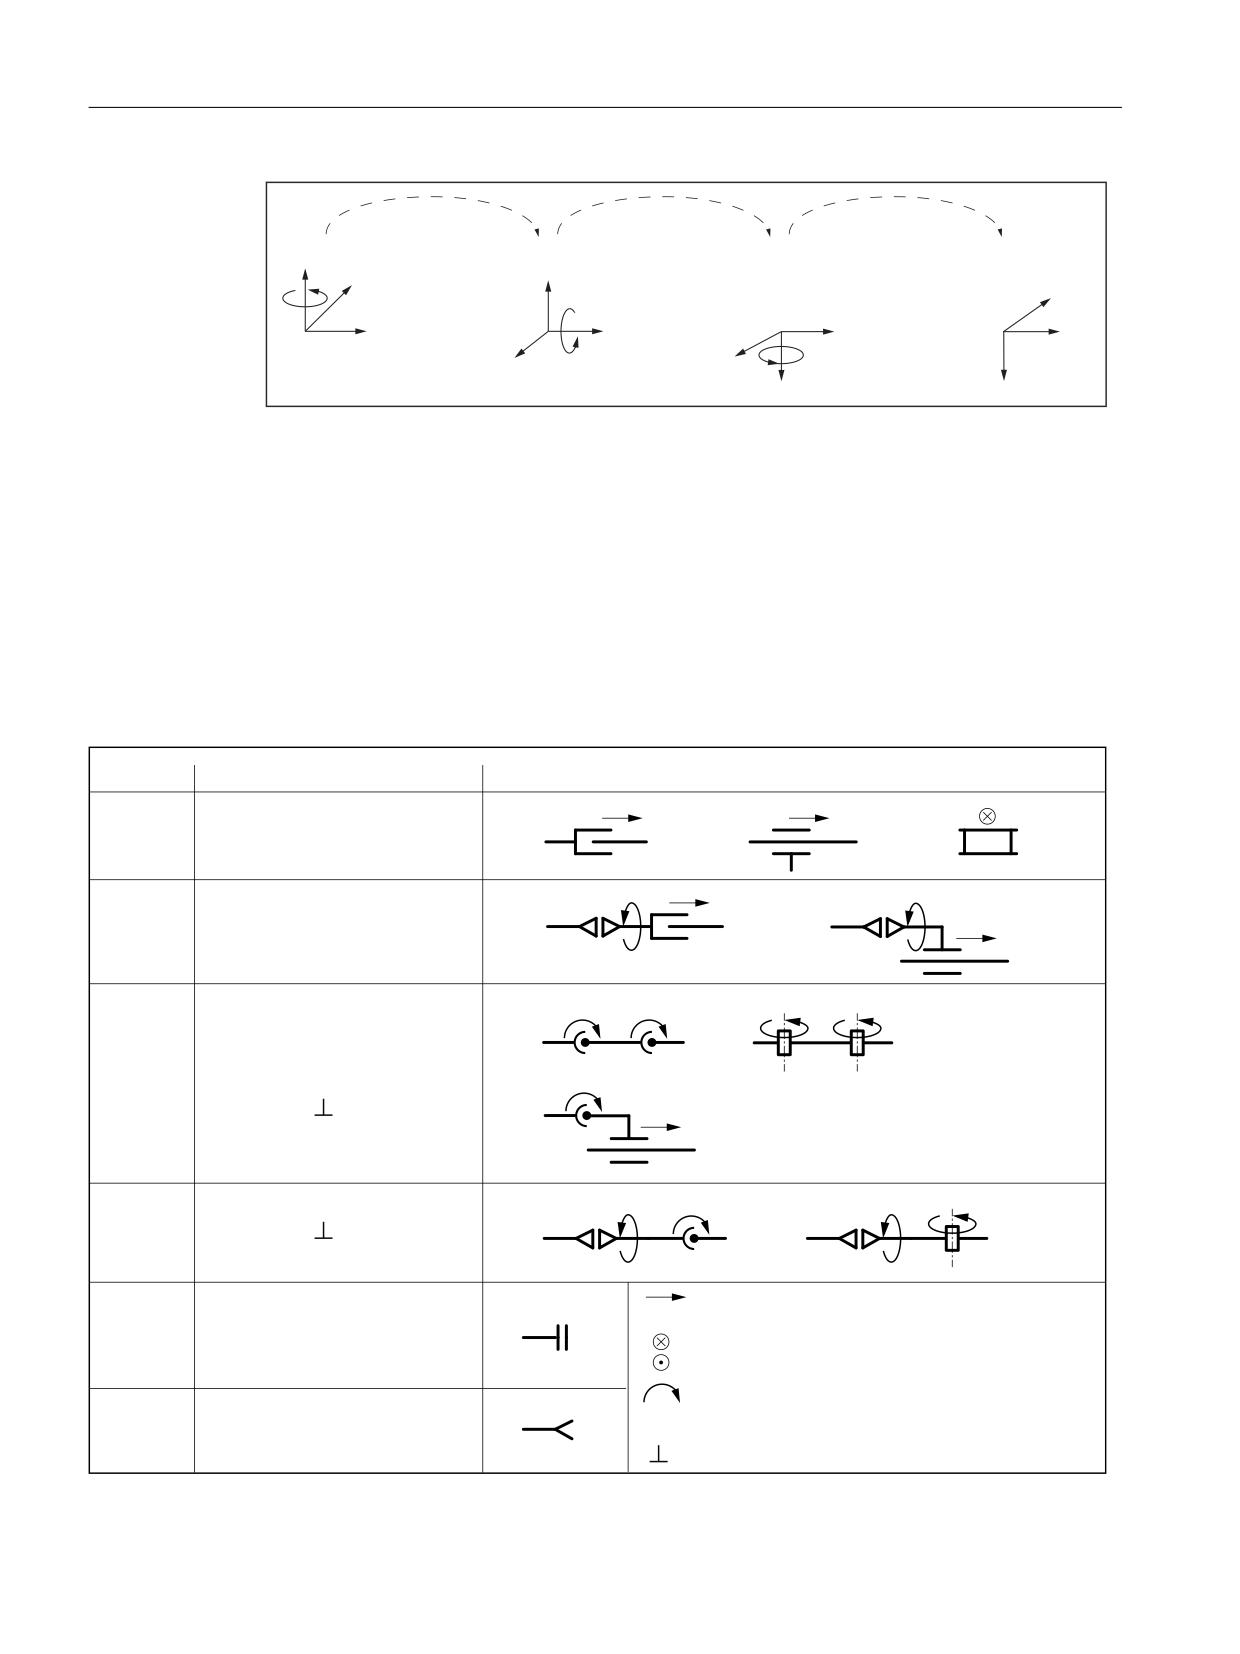
The following diagram shows an example for a rotation through the RPY angle. The initial
coordinate system X1, Y1, Z1 is transitioned into the coordinate system X4, Y4, Z4
1. Rotation through angle A around the Z1 axis
2. Rotation through angle B around the Y2 axis
3. Rotation through angle C around the X3 axis.
Special functions
Function Manual, 12/2018, A5E40874099B AB
761
TE4: Handling transformation package - 840D sl only
20.3 Definition of terms
$
r
% r
&
r
=
=
<
<
;
<
<
=
;
=
;
;
Figure 20-1
Example of rotation through RPY angles
20.3.3
Definition of a joint
Meaning
A sliding joint is implemented using a translatory axis, and a swivel joint, using a rotary axis.
The basic axis identifiers result from the arrangement and sequence of the individual joints.
These are specified using letter codes (S, C, R, N).
,GHQWLILHU
'HVLJQDWLRQ
,FRQV
6
6OLGLQJ MRLQW
&
6OLGLQJ MRLQW __ VZLYHO MRLQW
6ZLYHO MRLQW __ VZLYHO MRLQW
5
6ZLYHO MRLQW
6OLGLQJ MRLQW
1
6ZLYHO MRLQW
VZLYHO MRLQW
3RVLWLYH D[LV GLUHFWLRQ
)ODQJH IRU DWWDFKLQJ
3RVLWLYH D[LV GLUHFWLRQ
)/
WKH WRRO
IORZLQJ WRZDUG WKH GUDZLQJ SODQH
IORZLQJ DZD\ IURP WKH GUDZLQJ SODQH
3RVLWLYH GLUHFWLRQ RI URWDWLRQ
__
$[LV GLUHFWLRQV SDUDOOHO WR RQH DQRWKHU
7
7RRO
$[LV GLUHFWLRQV SHUSHQGLFXODU WR RQH DQRWKHU
Special functions
762
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
Figure 20-2
Joint identifying letters
20.4
Configuration of a kinematic transformation
Meaning
In order to ensure that the kinematic transformation can convert the programmed values into
axis motions, it must have access to some information about the mechanical construction of
the machine. This information is stored in machine data:
● Axis assignments
● Geometry information
20.4.1
General machine data
MD24100 $MC_TRAFO_TYPE_1 (definition of transformation 1 in the channel)
The value 4100 must be entered in this data for the handling transformation package.
MD24110 $MC_TRAFO_AXES_IN_1 (axis assignment for transformation)
The axis assignment at the transformation input defines which transformation axis is mapped
internally onto a channel axis. It is specified in machine data:
MD24110 $MC_TRAFO_AXES_IN_1
There is a predetermined axis sequence for the handling transformation package, The basic
axes are entered in the first three components (index 0…2). The upper three components
(index 3…5) are assigned to the manual axes.
● MD24110 $MC_TRAFO_AXES_IN_1[0] = 1 ; 1. Basic axis
● MD24110 $MC_TRAFO_AXES_IN_1[1] = 2 ; 2. Basic axis
● MD24110 $MC_TRAFO_AXES_IN_1[2] = 3 ; 3. Basic axis
● MD24110 $MC_TRAFO_AXES_IN_1[3] = 4 ; 1. Manual axis
● MD24110 $MC_TRAFO_AXES_IN_1[4] = 5 ; 2. Manual axis
● MD24110 $MC_TRAFO_AXES_IN_1[5] = 6 ; 3. Manual axis
MD24120 $MC_TRAFO_GEOAX_ASSIGN_TAB_1 (assignment between geometry axis and channel
axis for transformation 1)
The translational degrees of freedom that are available for the transformation are entered via
machine data:
MD24120 $MC_TRAFO_GEOAX_ASSIGN_TAB_1
Special functions
Function Manual, 12/2018, A5E40874099B AB
763
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
The 3 geometry axes normally correspond to Cartesian axis directions X, Y and Z.
In this case, the first three channel axis numbers must be transferred from MD24110
$MC_TRAFO_AXES_IN_1 to MD24120 $MC_TRAFO_GEO_AX_ASSIGN_TAB_1.
● MD24120 $MC_TRAFO_GEO_AX_ASSIGN_TAB_1[0] = 1
● MD24120 $MC_TRAFO_GEO_AX_ASSIGN_TAB_1[1] = 2
● MD24120 $MC_TRAFO_GEO_AX_ASSIGN_TAB_1[2] = 3
20.4.2
Parameterization using geometry data
Modular principle
The machine geometry is parameterized according to a type of modular principle. With this
method, the machine is successively configured in geometry parameters from its base center
point to the tool tip, thereby producing a closed kinematic loop. In this case, frames are used
to describe the geometry. While the control is powering up, the configuration machine data is
checked and alarms displayed when relevant. All axes of the mode group are tracked as alarm
response. The alarms can be deleted using POWER ON.
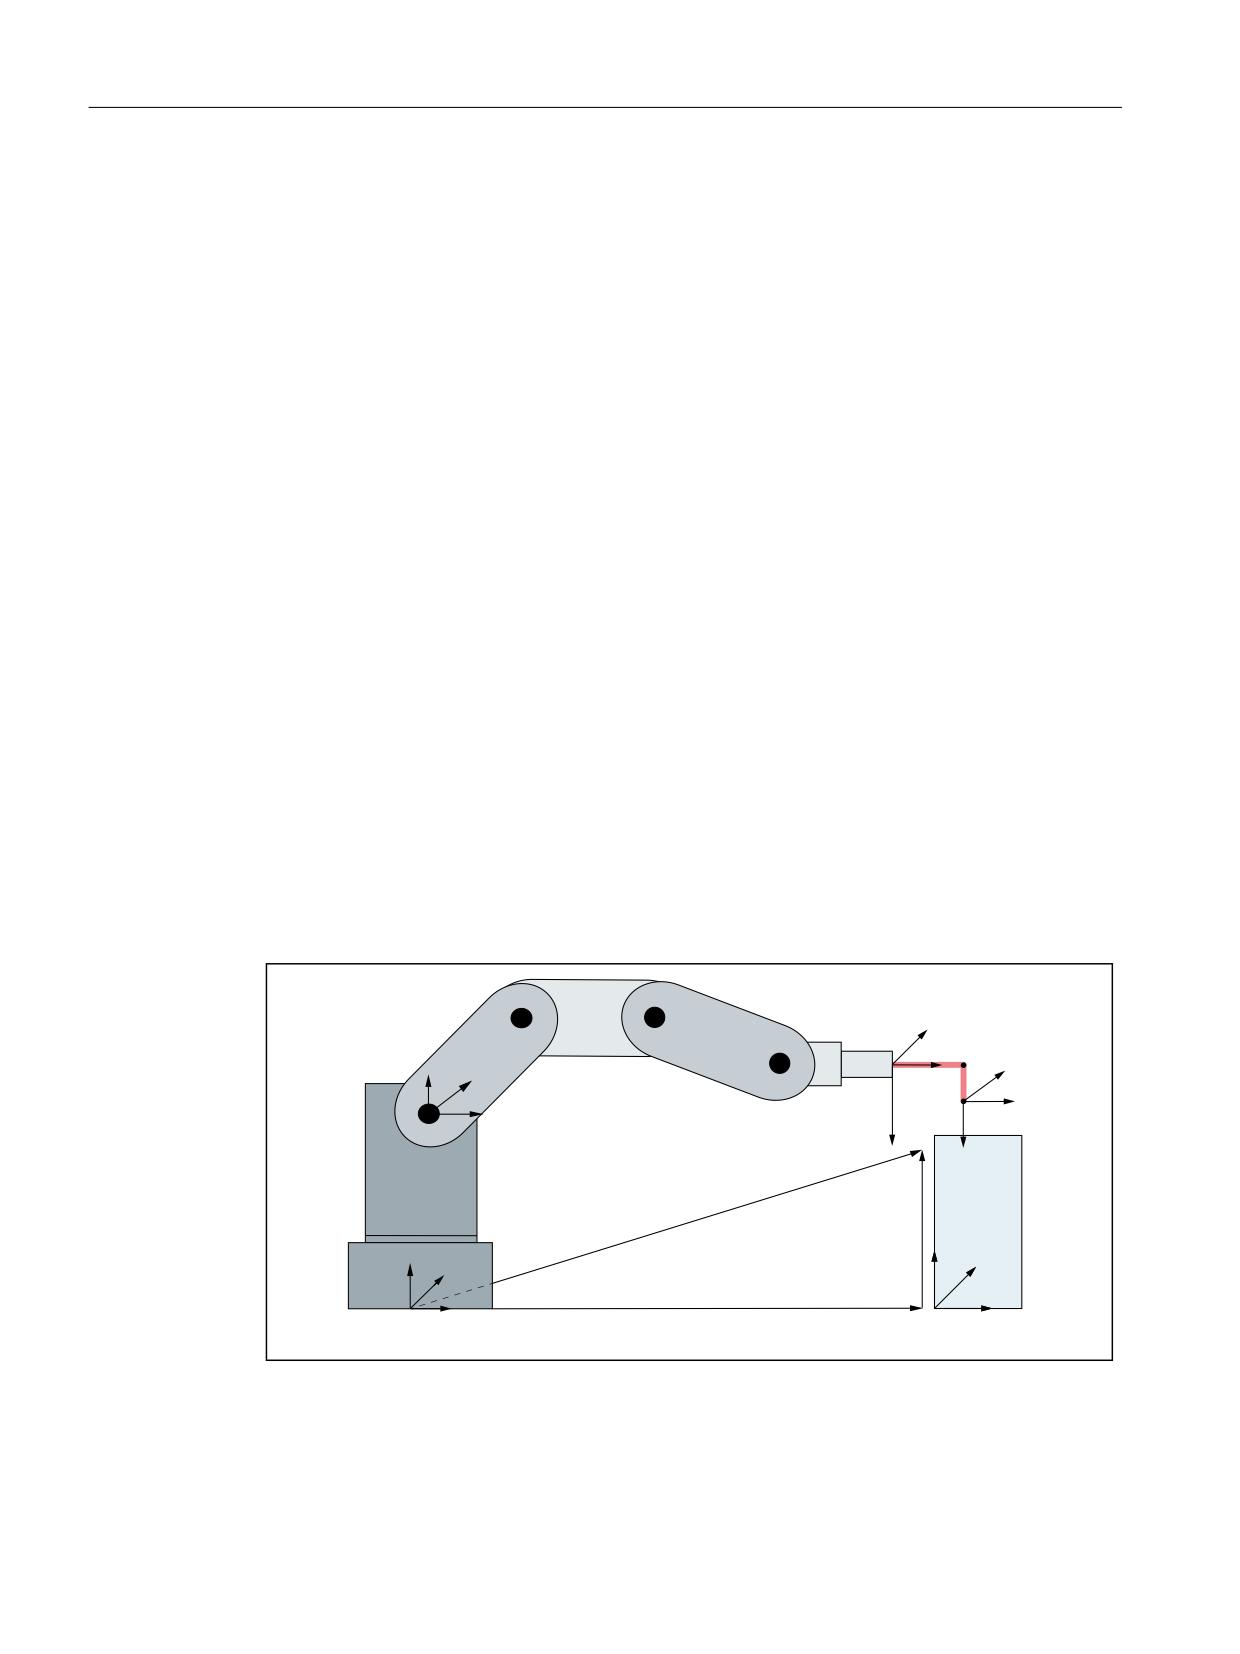
As shown in the following diagram "Closed kinematic loop illustrated by the example of a robot",
the kinematic transformation converts the tool operating point (tool coordinate system: XTO,
YTO, ZTO), specified relative to the base coordinate system (BCS = robot coordinate system:
XRO, YRO, ZRO), in machine axis values (MCS positions: A1, A2, A3, ...). The operating point
(XWZ, YWZ, ZWZ) is specified in the part program in relation to the workpiece to be machined
(workpiece coordinate system WCS: XWS, YWS, ZWS). The programmable frames make it
possible to create an offset between the workpiece coordinate system (WCS) and the base
coordinate system (BCS).
$
;
)/
=,52
;:=
<,52
<)/
$
$
<:=
$
;,52
$
=)/
=:=
.LQHPDWLF
WUDQVIRUPDWLRQ
3URJUDPPHG
SRVLWLRQ
$
=:6
=52
<:6
<52
;52
3URJUDPPDEOH )5$0(6
:.6
;:6
%.6
Figure 20-3
Closed kinematic loop illustrated by the example of a robot
Special functions
764
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
Note
For more detailed information about coordinate systems, please see:
Reference:
Function Manual Basic Functions;
Chapter "K2, axes, coordinate systems, frames" > "Coordinate systems"
The following machine data is available for configuring kinematic transformations:
Frame between base center point and internal coordinate system
The frame T_IRO_RO links the base center point of the machine (BCS = RO) with the first
internal coordinate system (IRO) determined by the transformation.
● MD62613 $MC_TRAFO6_TIRORO_RPY (frame between base center point and internal
coordinate system (rotation component), n = 0...2)
● MD62612 $MC_TRAFO6_TIRORO_POS (frame between base center point and internal
coordinate system (position component), n = 0...2)
Basic axis arrangement
The type of basic axis arrangement is specified in machine data:
● MD62603 $MC_TRAFO6_MAIN_AXES (basic axis identifier)
The first three axes included in the transformation are generally referred to as the "basic axes".
They must always be mutually parallel or perpendicular.
The handling transformation package contains the basic axis kinematics shown in the following
diagram. Every basic axis arrangement has its own special identifier (see Chapter "Definition
of a joint (Page 762)").
Special functions
Function Manual, 12/2018, A5E40874099B AB
765
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
5
5
=,52
5
4
4
4
<,52
=,52
3
3
3
;,52
;,52
<,52
=,52
<,52
;,52
$
%
$
=,52
=,52
5
=,52
5
5
<,52
4
4
<,52
4
<,52
3
3
3
;,52
;,52
;,52
$
%
$
$
$
4
3
5
%
<,52
;,52
=,52
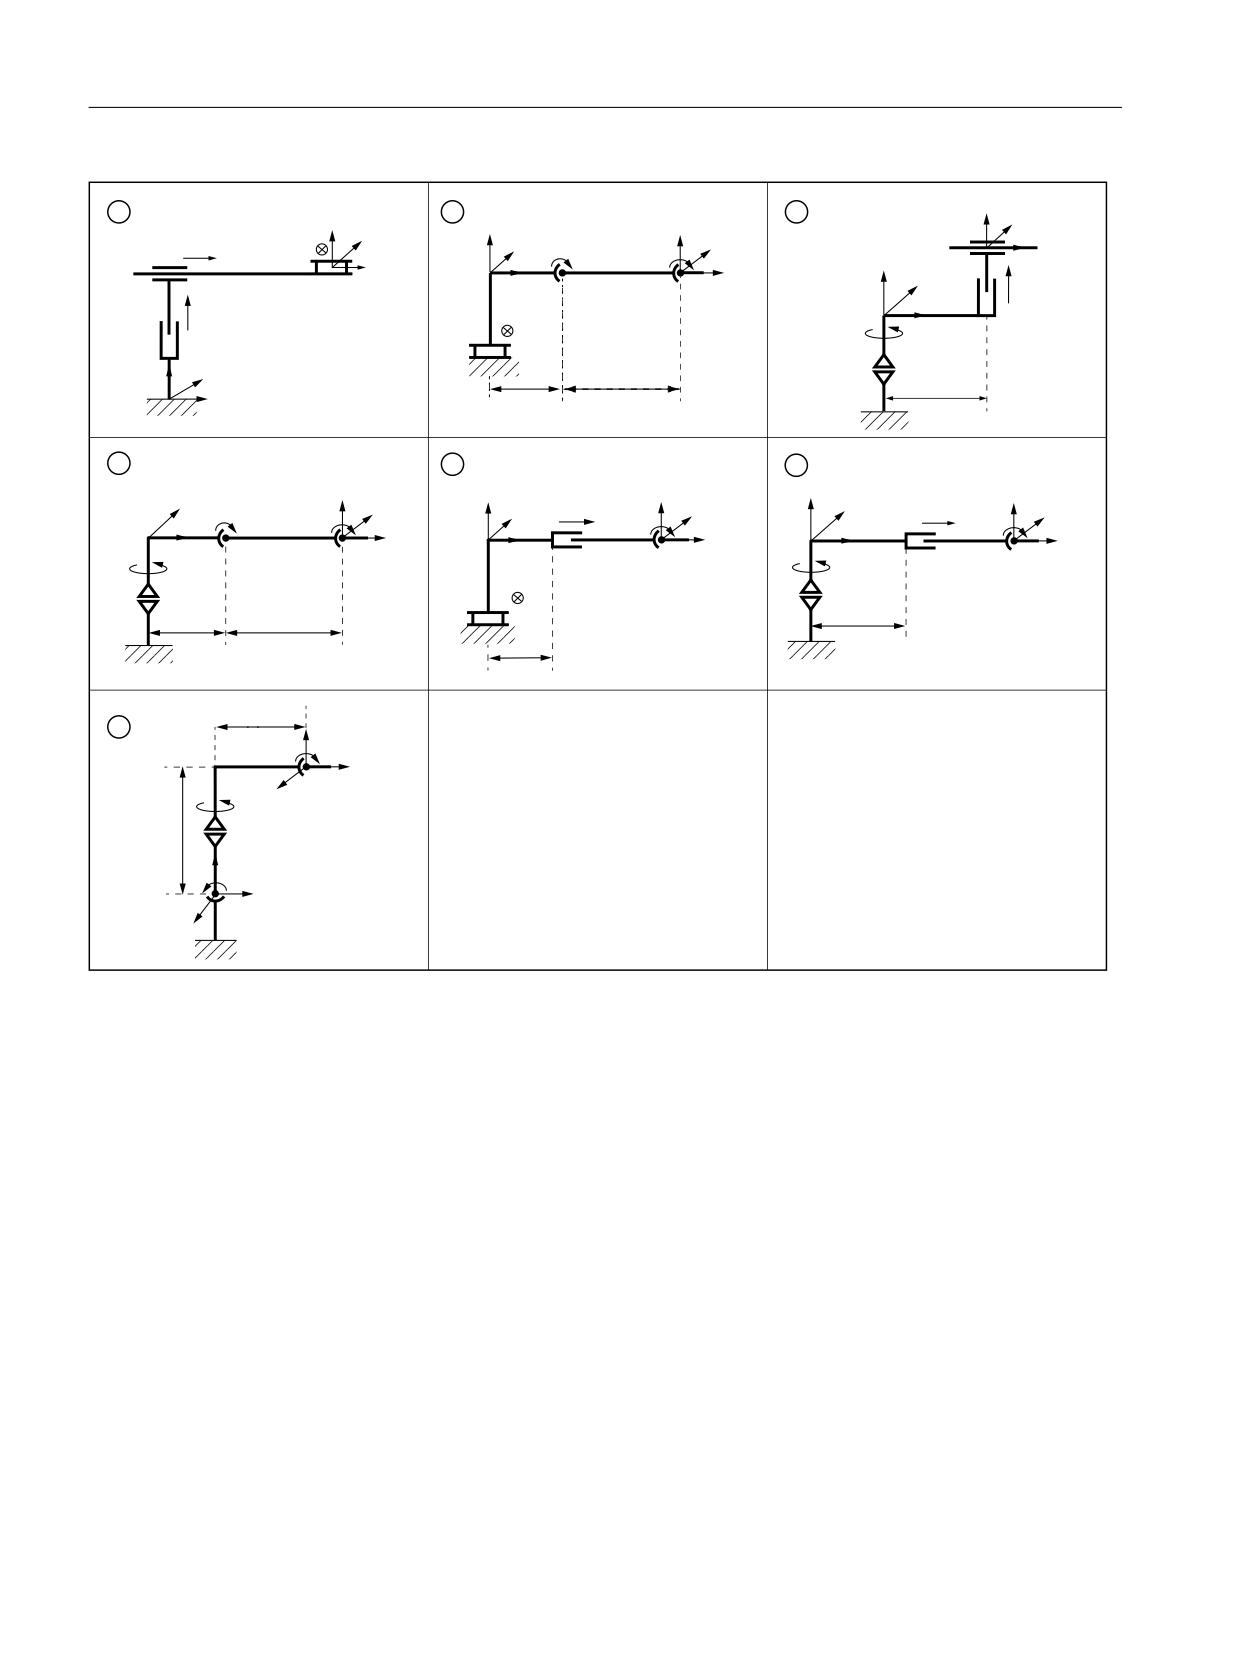
① SS: MD62603 = 1, gantry (3 linear axes, rectangular)
② CC: MD62603 = 2, SCARA (1 linear axis, 2 rotary axes (in parallel))
③ CS: MD62603 = 6, SCARA (2 linear axes, 1 rotary axis (spin axis))
④ NR: MD62603 = 3, articulated arm (3 rotary axes (2 axes in parallel))
⑤ SC: MD62603 = 4, SCARA (2 linear axes, 1 rotary axis (swivel axis))
⑥ RR: MD62603 = 5, articulated arm (1 linear axis, 2 rotary axes (vertical))
⑦ NN: MD62603 = 7, articulated arm (3 rotary axes)
Figure 20-4
Overview of basic axis configuration
Basic axis lengths A and B
The basic axis lengths A and B are specified with machine data:
● MD62607 $MC_TRAFO6_MAIN_LENGTH_AB (basic axis lengths A and B, n = 0...1)
As Fig. "Overview of basic axis configurations" illustrates, these are specially defined for each
type of basic axis.
Special functions
766
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
Position of the 4th axis
Whether the 4th axis is mounted parallel, anti-parallel or perpendicular to the last rotary basic
axis is specified in machine data:
● MD62606 $MC_TRAFO6_A4PAR (axis 4 is parallel/anti-parallel to last basic axis)
Description of the wrist axis
Frame to attach the wrist axis
Frame T_X3_P3 links the last coordinate system of the basic axes with the first wrist axis
coordinate system.
● MD62608 $MC_TRAFO6_TX3P3_POS (attachment of wrist axis (position component], n
= 0...2)
● MD62609 $MC_TRAFO6_TX3P3_RPY (attachment of wrist axis (rotation component), n =
0...2)
Frame between wrist point and flange coordinate system
Frame T_FL_WP links the last hand wrist axis coordinate system with the flange coordinate
system.
● MD62610 $MC_TRAFO6_TFLWP_POS (frame between wrist point and flange coordinate
system (position component), n = 0...2)
● MD62611 $MC_TRAFO6_TFLWP_RPY (frame between wrist point and flange coordinate
system (rotation component), n = 0...2)
This data is explained in more detail in the following sections.
Description of the wrist axis type
These parameters describe the wrist axis type.
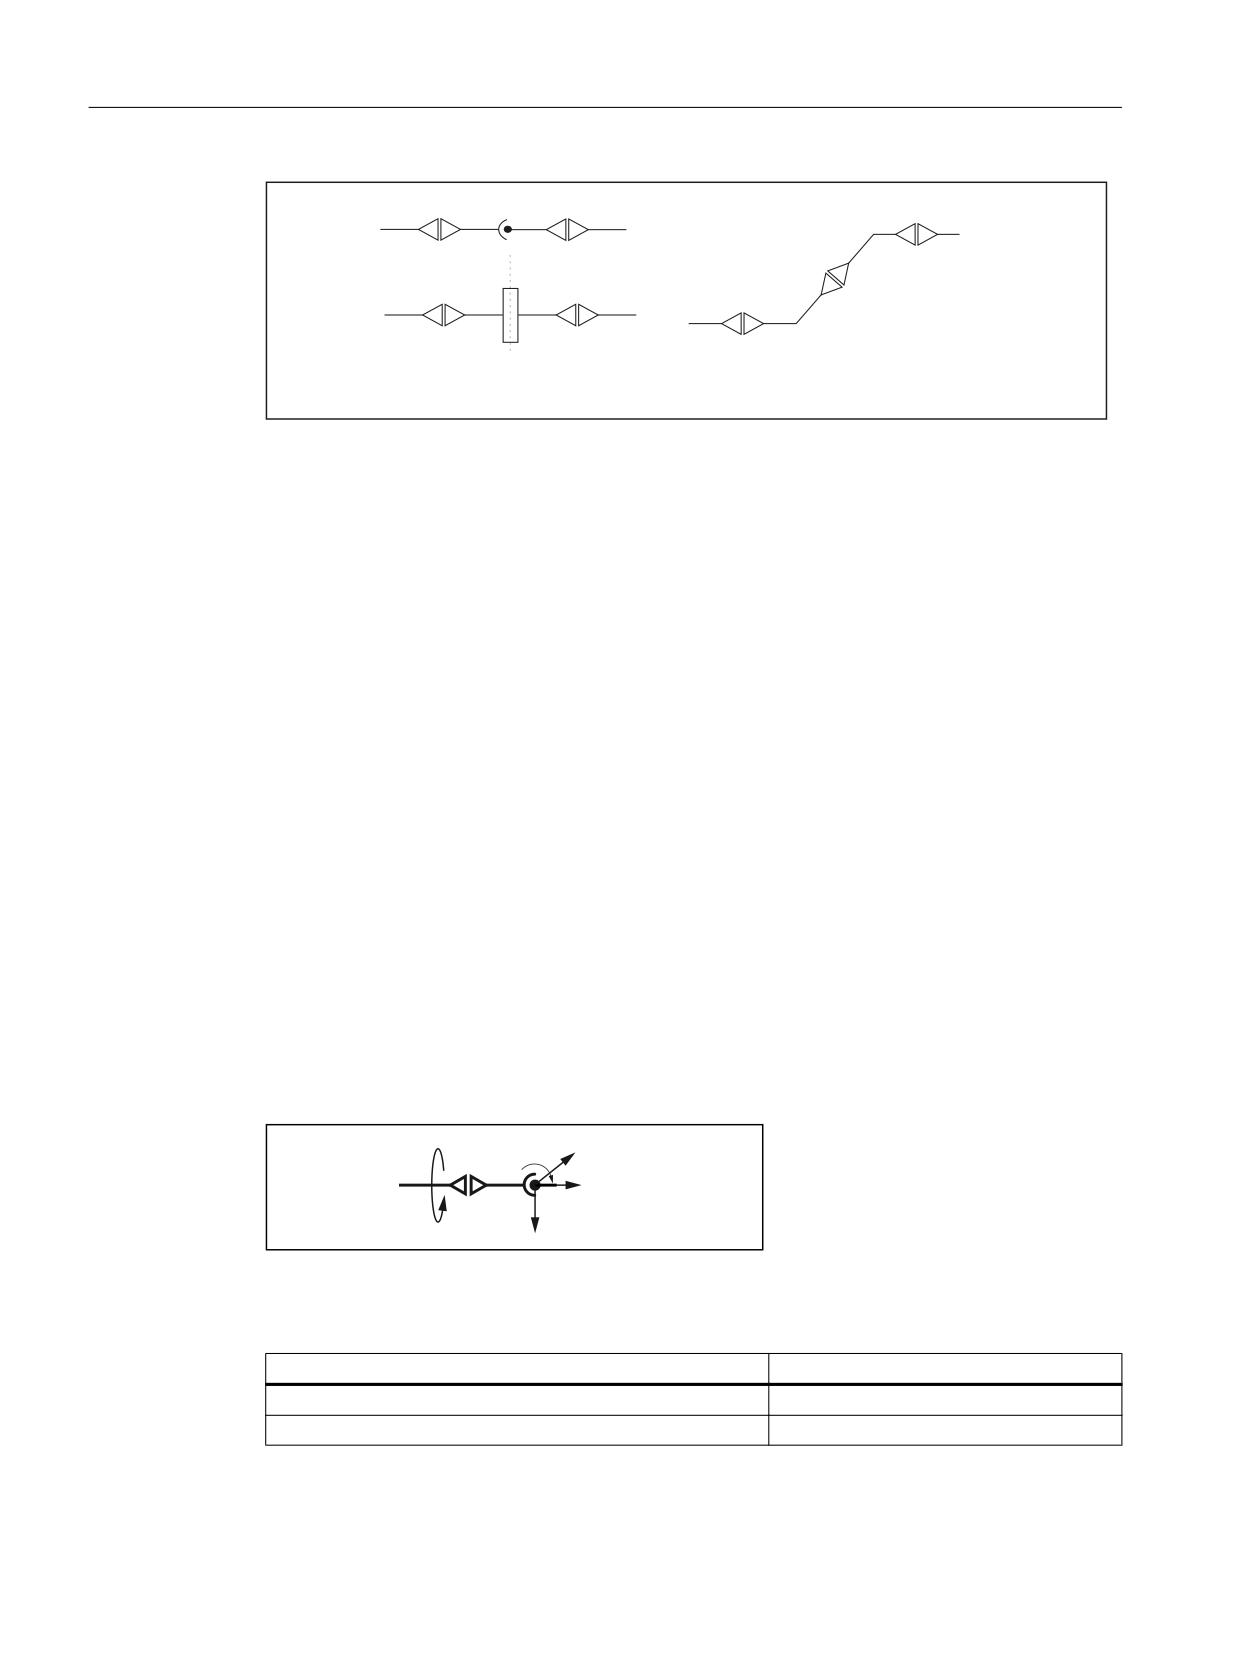
● MD62604 $MC_TRAFO6_WRIST_AXES (wrist axis identifier)
The term wrist axes generally refers to axes four to six.
Wrist axes included in every transformation
The fourth axis and all further axes are generally referred to as "wrist axes". The handling
transformation package can only identify wrist axes with rotary axes. The wrist axis identifier
for three-axis wrists is entered in machine data:
● MD62604 $MC_TRAFO6_WRIST_AXES (wrist axis identifier)
When there are fewer than three wrist axes, the identifier for the inclined wrist axis or a central
wrist axis is entered in the machine data:
● MD62604 $MC_TRAFO6_WRIST_AXES (wrist axis identifier)
The current software only supports the central and inclined wrist axis types.
Special functions
Function Manual, 12/2018, A5E40874099B AB
767
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
&HQWUDO KDQG
%HYHOHG KDQG ZLWK HOERZ
Figure 20-5
Overview of wrist axis configuration
Parameterization of wrist axes
With the following machine data, using a special frame type, the geometry of the wrist axis
and/or the position of the coordinate system in the wrist axis with respect to one another is
defined.
● MD62614 $MC_TRAFO6_DHPAR4_5A (parameter A for configuring the wrist axis, n = 0...1)
● MD62615 $MC_TRAFO6_DHPAR4_5D (parameter D for configuring the wrist axis, n =
0...1)
● MD62616 $MC_TRAFO6_DHPAR4_5ALPHA. (Parameter ALPHA for configuring the wrist
axis, n = 0...1)
For this purpose, the machine data corresponds to certain frame components (see Section
"Definition of positions and orientations using frames (Page 761)"):
● X component: MD62614 $MC_TRAFO6_DHPAR4_5A ≙ _POS[ 0 ] (x component)
● Z component: MD62615 $MC_TRAFO6_DHPAR4_5D ≙ _POS[ 2 ] (z component)
● C angle: MD62616 $MC_TRAFO6_DHPAR4_5ALPHA ≙ _RPY[ 2 ] (C angle)
The other components of the frame are zero.
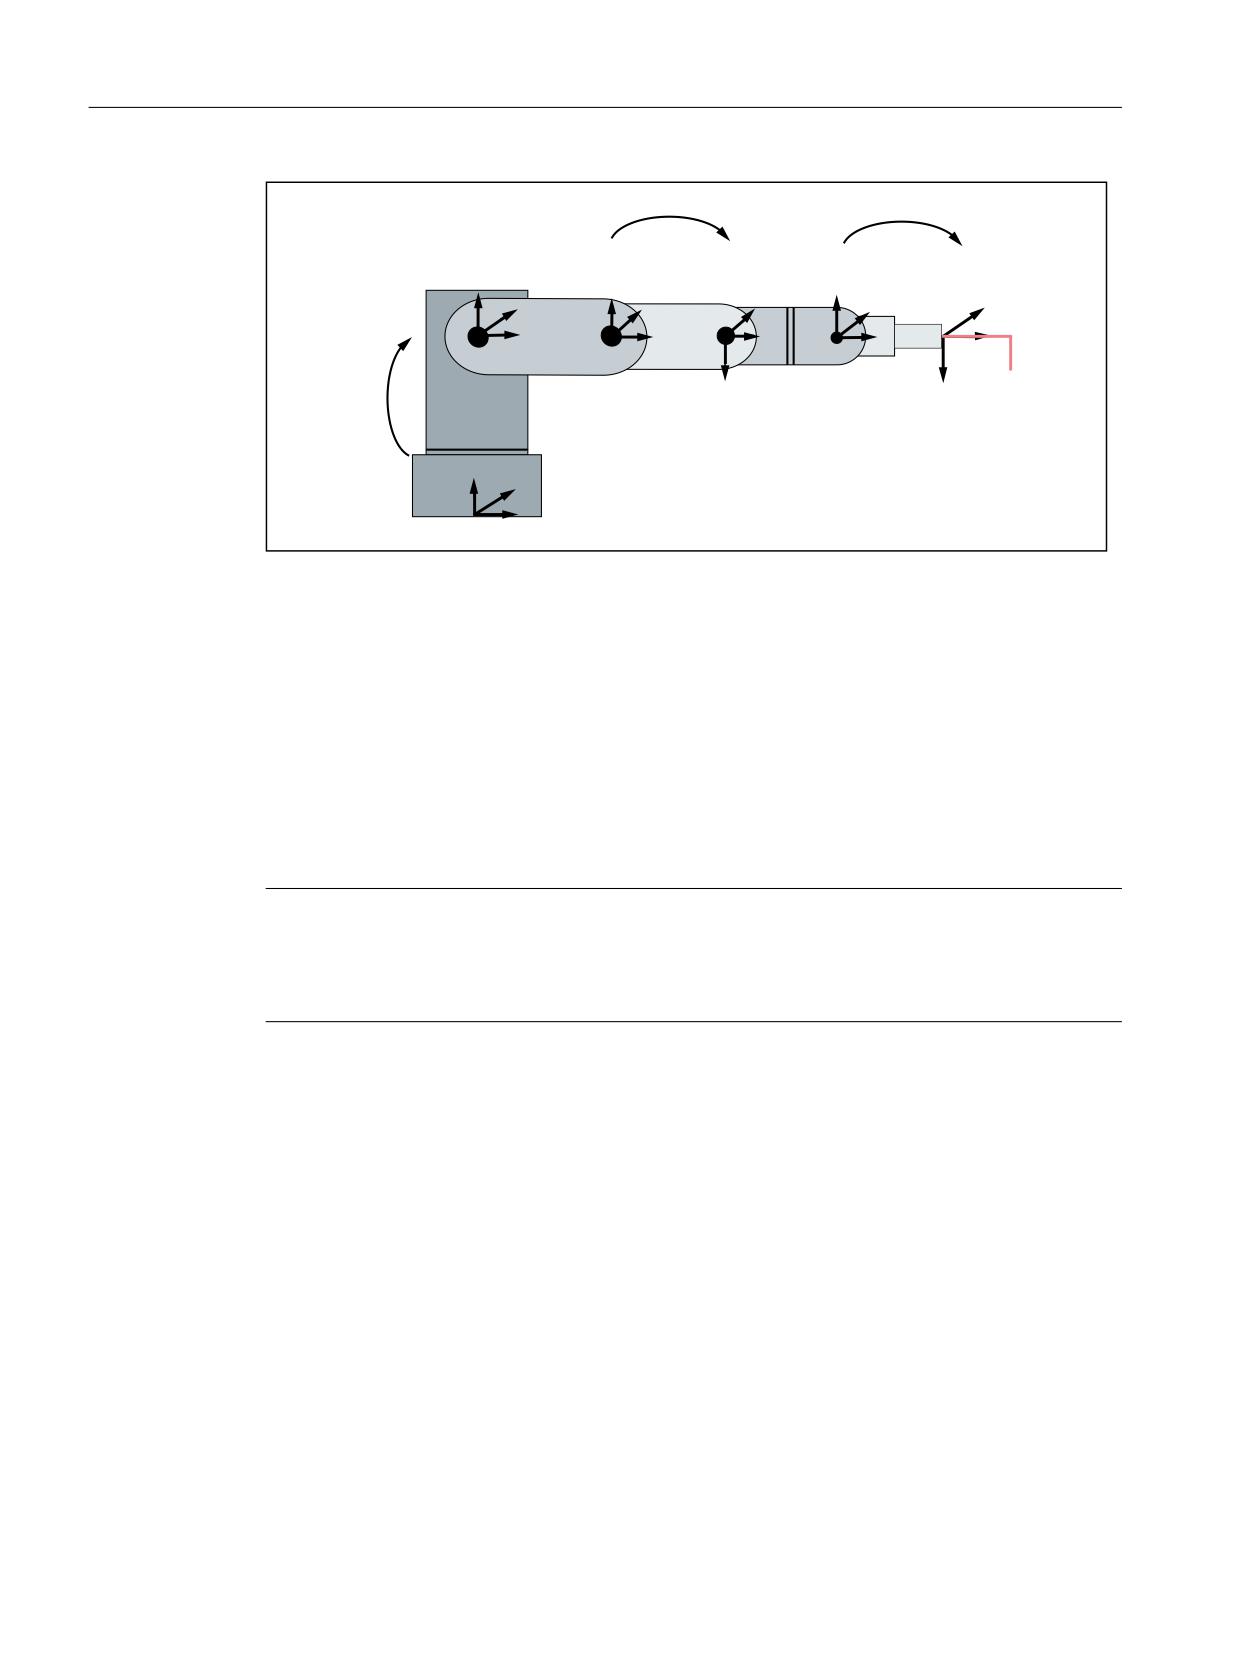
Central wrist axis
On a central wrist axis, all wrist axes intersect at one point. All parameters must be set as
shown in Table "Configuring data for a central wrist axis".
]
+3
]
[
[
[+3
Figure 20-6
Central wrist axis, 5-axis machine
Table 20-1
Configuring data for a central wrist axis
Machine data
Value
MD62604 $MC_TRAFO6_WRIST_AXES
2
MD62614 $MC_TRAFO6_DHPAR4_5A
[0.0, 0.0]
Special functions
768
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
Machine data
Value
MD62615 $MC_TRAFO6_DHPAR4_5D
[0.0, 0.0]
MD62616 $MC_TRAFO6_DHPAR4_5ALPHA
[-90.0, 90.0]
Inclined wrist axis
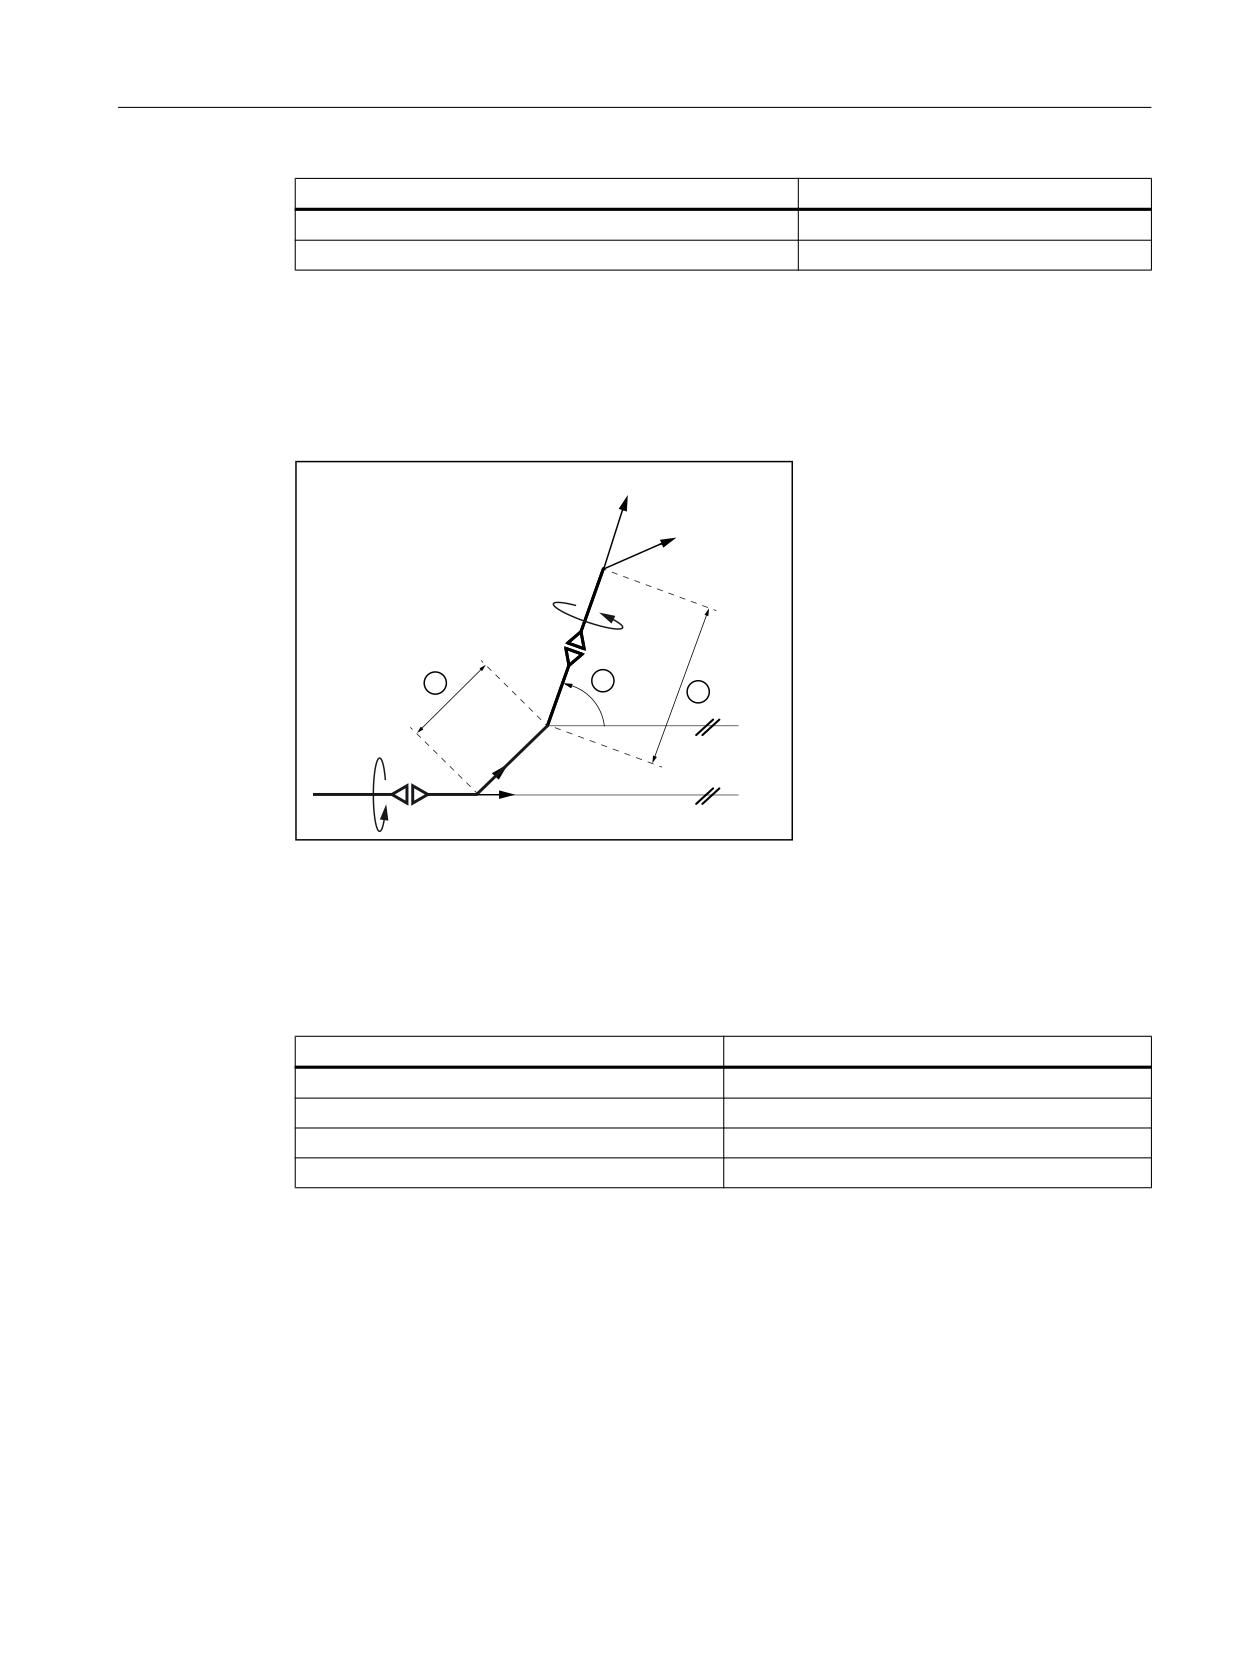
The inclined wrist axis differs from the central wrist axis in two respects, i.e. the axes do not
intersect nor are they mutually perpendicular. Parameters a4, d5, and a4 are available for this
type of hand, as shown in Table "Configuring data for a central wrist axis".
]
]
+3
[
[
+3
[
]
① MD62614 $MC_TRAFO6_DHPAR4_5A[ 0 ]
② MD62616 $MC_TRAFO6_DHPAR4_5ALPHA[ 0 ]
③ MD62615 $MC_TRAFO6_DHPAR4_5D[ 1 ]
Figure 20-7
Inclined wrist axis, 5-axis machine
Table 20-2
Configuring data for an inclined wrist axis (5-axis
Machine data
Value
MD62604 $MC_TRAFO6_WRIST_AXES
6
MD62614 $MC_TRAFO6_DHPAR4_5A
[a4, 0.0]
MD62615 $MC_TRAFO6_DHPAR4_5D
[0.0, d5]
MD62616 $MC_TRAFO6_DHPAR4_5ALPHA
[α4, 0.0]
Special functions
Function Manual, 12/2018, A5E40874099B AB
769
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
7B; B3
7B)/B:3
$
$
$
$
$
]
,5
2
U
[
\
T
+3
[
,5
2
\
]
)/
+
3
[
S
[
\
,5
2
+3
\
)/
]
]
)
/
7B,5
2B52
$
]
5
2
\
2
5
[
5
2
Figure 20-8
Link frames
Frame: T_IRO_RO
Frame T_IRO_RO provides the link between the base center point coordinate system (RO)
defined by the user and the internal robot coordinate system (IRO). The internal robot
coordinate system is predefined in the handling transformation package for each basic axis
type and included in the kinematic diagrams for the basic axis arrangements. The base center
point system is in the Cartesian zero point of the machine, corresponding to the basic
coordinate system. If no FRAMES are programmed, the basic coordinate system equals the
workpiece coordinate system.
Note
For more detailed information about FRAMES, please see:
References:
Programming Manual Fundamentals
Frame T_IRO_RO is not subject to any restrictions for 5-axis kinematics.
The following restrictions apply in relation to 4-axis kinematics:
● The first rotary axis must always be parallel/anti-parallel to one of the coordinate axes of
the base center point coordinate system (RO).
● No further restrictions apply to type SS basic axes.
● In the case of type CC, CS or SC basic axes, no further restrictions apply provided that the
4th axis is parallel to the last rotary basic axis.
● With respect to all other basic axes, and basic axes of type CC, CS or SC if the 4th axis is
perpendicular to the last rotary basic axis, the Z axis of RO must be parallel to the Z axis
of IRO.
Special functions
770
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
Frame: T_X3_P3
Frame T_X3_P3 describes the method used to attach the wrist axis to the basic axes. Frame
T_X3_P3 is used to link the coordinate system of the last basic axis (p3_q3_r3 coordinate
system) with the coordinate system of the first wrist axis (x3_y3_z3 coordinate system). The
p3_q3_r3 coordinate system is included in the kinematic diagrams for the basic axis
arrangements.
The z3 axis is always on the 4th axis.
Depending on the number of axes to be included in the transformation, frame T_X3_P3 is
subject to certain restrictions relating to the wrist and basic axes:
● For 5-axis kinematics, frame T_X3_P3 can be freely selected in the following cases:
- If the basic axes are of the SS type.
- If the basic axes are type CC, CS, or SC, the transformation must either include a central
wrist axis or the 4th axis must be positioned parallel to the last rotary basic axis.
- If the basic axes are type NR or RR, the transformation must either include a central
wrist axis or the 4th axis must be positioned in parallel to the last basic rotary axis and
an X flange must intersect the 5th axis.
- If the basic axes are of the NN type, the transformation must include a central wrist axis.
● For 4-axes, ensure that the Z3 axis is always parallel/anti-parallel or perpendicular to the
last basic axis.
Frame: T_FL_WP
Frame T_FL_WP links the flange with the last internal coordinate system (wrist point coordinate
system) preset by the handling transformation package.
For kinematics with less than 6 axes, this frame is subject to certain restrictions. These
restrictions are explained by the relevant kinematics.
Other configuring data
Number of transformed axes
The number of axes included in the transformation is defined in machine data:
● MD62605 $MC_TRAFO6_NUM_AXES (number of transformed axes)
The number of transformed axes can currently lie between two and six axes.
Special functions
Function Manual, 12/2018, A5E40874099B AB
771

TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
Changing the axis sequence
Rearrangement of axes: MD62620
Note
With certain types of kinematics, it is possible to transpose axes without changing the behavior
of the kinematic transformation. Machine data:
MD62620 $MC_TRAFO6_AXIS_SEQ (rearrangement of axes)
The axes on the machine are numbered consecutively from 1 to 6 and must be entered in the
internal sequence in machine data:
MD62620 $MC_TRAFO6_AXIS_SEQ[0] ...[4]
All other axis-specific machine data refer to the sequence of axes on the machine.
Table 20-3
Changing the axis sequence
Basic axis kinematics
Options for changing axis sequence
SS, CC
Any
SC
1 and 2
CS
2 and 3
Example 1
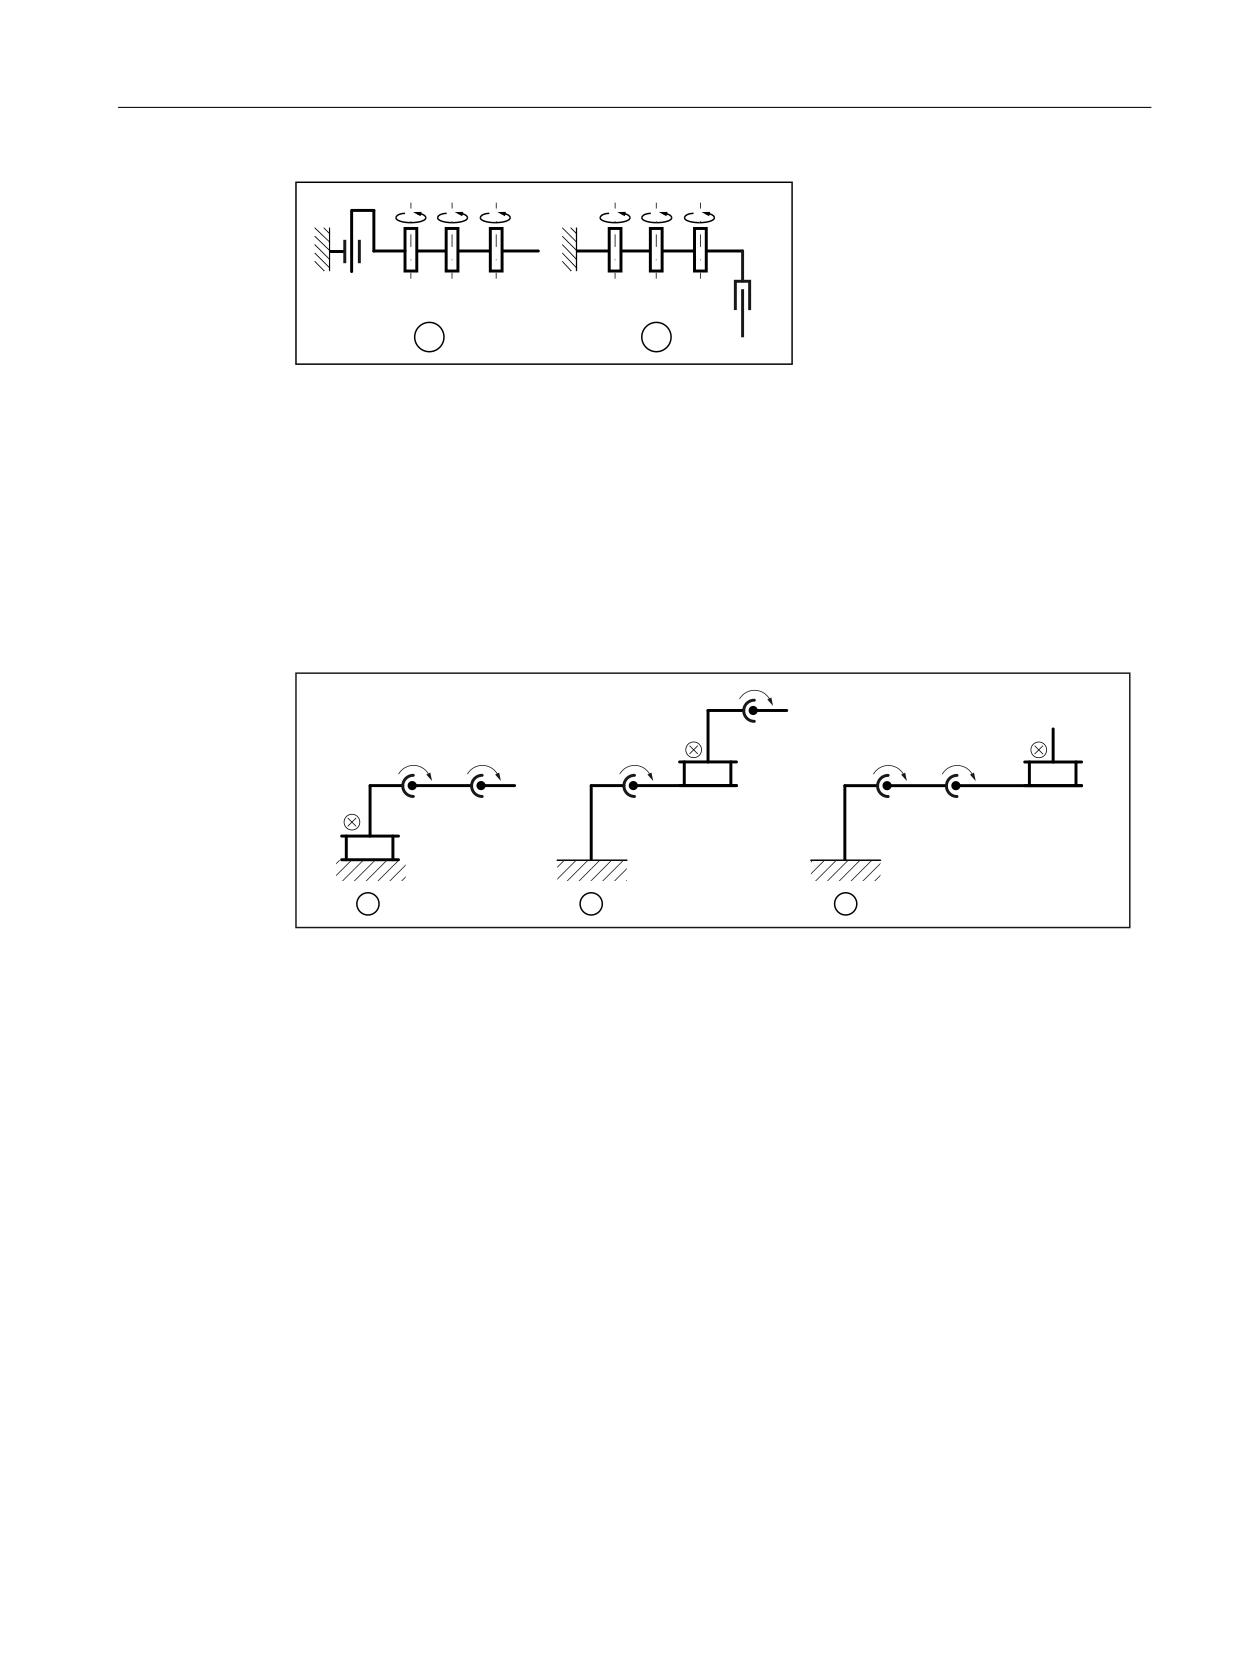
There are two kinematics, such as those shown in Fig. "Rearrangement of axes 1". Kinematic
1 is directly included in the handling transformation package. It corresponds to a CC kinematic
with a wrist axis parallel to the last basic rotary axis.
Kinematic 2 is the same as kinematic 1 inasmuch as it is irrelevant for the resulting robot
movement whether the translational axis is axis 1 or axis 4. In this instance, the data for
kinematic 2 must be entered as follows in machine data:
● MD62620 $MC_TRAFO6_AXIS_SEQ (rearrangement of axes)
The input is as follows:
● MD62620 $MC_TRAFO6_AXIS_SEQ[ 0 ] = 4
● MD62620 $MC_TRAFO6_AXIS_SEQ[ 1 ] = 1
● MD62620 $MC_TRAFO6_AXIS_SEQ[ 2 ] = 2
● MD62620 $MC_TRAFO6_AXIS_SEQ[ 3 ] = 3
Special functions
772
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
① Kinematics 1
② Kinematics 2
Figure 20-9
Rearrangement of axes 1
Example 2
This example involves a SCARA kinematic transformation as illustrated in Fig.
"Rearrangement of axes 2", in which the axes can be freely transposed. Kinematic 1 is directly
included in the handling transformation package. It corresponds to a CC kinematic. As regards
the transposition of axes, it is irrelevant how many wrist axes are involved in the transformation.
① Kinematics 1: Axis sequence 1 2 3
② Kinematics 2: Axis sequence 2 1 3
③ Kinematics 3: Axis sequence 2 3 1
Figure 20-10
Rearrangement of axes 2
Changing the directions of axes
A rotational or offset direction is preset for each axis in the handling transformation package.
This direction is not necessarily the same as the corresponding direction on the machine. The
following machine data must be set to -1 for the relevant axis if the direction is to be inverted,
or otherwise to +1:
● MD62618 $MC_TRAFO6_AXES_DIR[ ] (matching of physical and mathematical directions
of rotation [axis no.]: 0...5)
Adapting the zero points of the axes
Offset between mathematical and mechanical zero points
The mathematical zero points of axes are preset in the handling transformation package.
However, the mathematical zero point does not always correspond to the mechanical zero
Special functions
Function Manual, 12/2018, A5E40874099B AB
773
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
point (calibration point) of axes. In order for the zero point of each axis to fit one another, the
difference between the mathematical zero point and the alignment point for each axis must be
entered in the following machine data:
● MD62617 $MC_TRAFO6_MAMES[ ] (offset between mathematical and mechanical zero
points [axis no.]: 0...5)
The deviation to be entered corresponds to the difference between the mechanical zero point
and the mathematically positive direction of rotation of the axis.
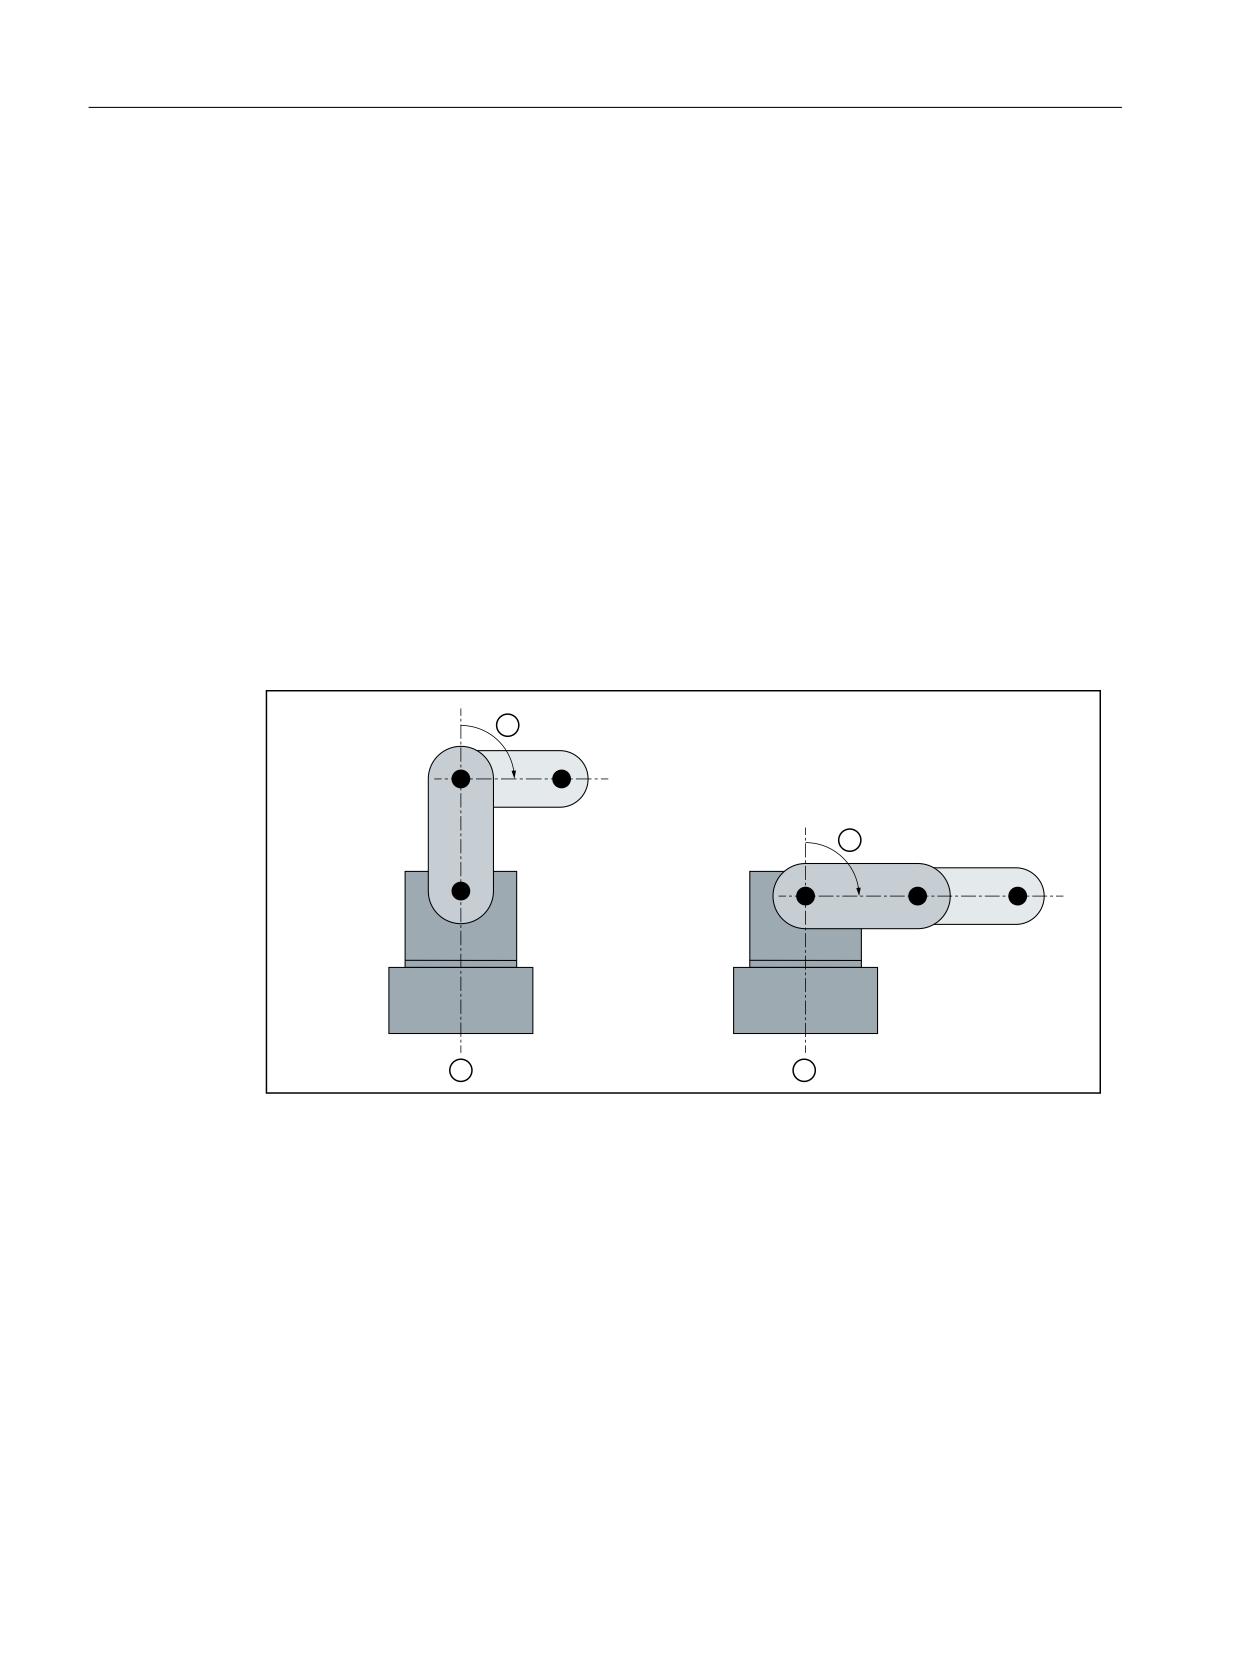
Example
Jointed arm kinematics are shown in the following diagram.
In the mathematical zero position ②, axis 2 (A2) has a value of 90º. This value should be
entered into the machine data for axis 2 (index 1):
● MD62617 $MC_TRAFO6_MAMES[ 1 ] = 90
Axis 3 (A3) is counted relative to the previous axis 2 (A2) in the kinematic chain, and in the
mechanical zero position ① has the value: -90º:
● MD62617 $MC_TRAFO6_MAMES[ 2 ] = -90
$
$
$
$
$
$
① mechanical zero position (adjusted position):
② MD62617 $MC_TRAFO6_MAMES[ 2 ] = -90
③ mathematical zero position
④ MD62617 $MC_ TRAFO6_MAMES[ 1 ] = 90
Figure 20-11
Matching mathematical and mechanical zero points
Axis type for transformation
Which axis type is handled is specified in machine data:
● MD62601 $MC_TRAFO6_AXES_TYPE (axis type for transformation [axis no.]: 0...5)
Special functions
774
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
The transformation package distinguishes between the following axis types:
● Linear axis: MD62601 = 1
● Rotary axis: MD62601 = 3
Velocity and acceleration values for override control that limits the dynamic response
CAUTION
Unnecessarily high limiting default values
Since software release RCTRA 07.05.00, RCTRA transformation for limiting the Cartesian
velocities and acceleration levels, takes into account machine data MD62629 to MD62632.
In order to avoid unnecessarily limiting the velocities and acceleration levels, this machine
data must be adapted to the machine capabilities. Frequently, unnecessarily high limiting
default values are set here, as - up until now - this data has not been used.
For traversing axes with active RCTRA transformation and override controls that limit the
dynamic performance, dedicated substitute limit values have been introduced for velocities
and acceleration levels for Cartesian motion components.
The override controller within the transformation is only active if motion is interpolated, whose
dynamic limits are not secured - or not completely secured - through motion planning in the
Look Ahead function of the control.
The velocity controller is active in the following cases:
● When traversing in the JOG mode with transformation
● For overlaid motion in realtime, e.g. via system variable $AA_OFF[ X ]
● For velocity limits as a result of Safety Integrated (SG level active)
Cartesian velocity
The velocities for individual translatory motion directions when traversing with override
controller are specified using machine data:
● MD62629 $MC_TRAFO6_VELCP[ i ] (Cartesian velocity [No.]: 0...2)
- Index i = 0 : X component of basic system
- Index i = 1 : Y component of basic system
- Index i = 2 : Z component of basic system
Special functions
Function Manual, 12/2018, A5E40874099B AB
775
TE4: Handling transformation package - 840D sl only
20.4 Configuration of a kinematic transformation
Cartesian acceleration rates
The acceleration levels for individual translatory motion directions when traversing with
override controller are specified using machine data:
● MD62630 $MC_TRAFO6_ACCCP[i] (Cartesian acceleration levels [no.]: 0...2)
- Index i = 0 : X component of basic system
- Index i = 1 : Y component of basic system
- Index i = 2 : Z component of basic system
Orientation angle velocities
The velocities for individual orientation directions when traversing with override controller are
specified using machine data:
● MD62631 $MC_TRAFO6_VELORI[ i ] (orientation angle velocities [no.]: 0...2)
- Index i = 0 : A angle
- Index i = 1 : B angle
- Index i = 2 : C angle
Orientation angle acceleration rates
The acceleration levels for individual orientation directions when traversing with override
controller are specified using machine data:
● MD62632 $MC_TRAFO6_ACCORI[ i ] (orientation angle acceleration levels [no.]: 0...2)
- Index i = 0 : A angle
- Index i = 1 : B angle
- Index i = 2 : C angle
Reduction factor for the velocity controller
A reduction factor for the velocity controller in the JOG mode can be specified with the machine
data:
● MD62633 $MC_ROBX_DYN_LIM_REDUCE (reduction factor for the velocity controller)
Time constant for the velocity controller
A time constant for the PT1 filter of the velocity controller can be specified with the machine
data:
● MD62634 $MC_ROBX_VEL_FILTER_TIME (time constant for the velocity controller)
Special functions
776
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
20.5
Descriptions of kinematics
The following descriptions of kinematics for transformations involving 2 to 5 axes explain the
general configuring procedure first before describing how the machine data need to be
configured, using a configuring example for each kinematic type. These examples do not
include all possible lengths and offsets. The direction data refer to the positive directions of
traversal and rotation for the transformation. The axis positions correspond to their zero
position for the relevant transformation.
20.5.1
3-axis kinematics
3-axis kinematics normally possess three translational degrees of freedom, but do not have a
rotational degree of freedom for orientation. As a consequence, 3-axis kinematics only have
basic axes.
Configuration
The procedure for configuring a 3-axis kinematic is as follows:
1. Enter "Standard" kinematic category in machine data:
MD62600 $MC_TRAFO6_KINCLASS (kinematic category)
2. Set the number of axes for transformation in machine data:
MD62605 $MC_TRAFO6_NUM_AXES = 3 (number of transformed axes)
3. Compare the basic axes with the basic axes contained in the handling transformation
package. → Enter the basic axis identifier in machine data:
MD62603 $MC_TRAFO6_MAIN_AXES (basic axis identifier)
4. If the axis sequence is not the same as the normal axis sequence, it must be corrected in
machine data:
MD62620 $MC_TRAFO6_AXIS_SEQ (rearrangement of axes)
5. As identifier for the wrist axes, the following machine data must be set to 1 (no wrist axis):
MD62604 $MC_TRAFO6_WRIST_AXES = 1 (wrist axis identifier)
6. Enter the axis types for the transformation in machine data:
MD62601 $MC_TRAFO6_AXES_TYPE (axis type for transformation)
7. Compare the directions of rotation of axes with the directions defined in the handling
transformation package and correct in machine data:
MD62618 $MC_TRAFO6_AXES_DIR (matching of physical and mathematical directions
of rotation)
8. Enter the mechanical zero offset in machine data:
MD62617 $MC_TRAFO6_MAMES (offset between mathematical and mechanical zero
points)
9. Enter the basic axis lengths in machine data:
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB (basic axis lengths A and B)
Special functions
Function Manual, 12/2018, A5E40874099B AB
777
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
10.Define frame T_IRO_RO and enter the offset in machine data:
MD62612 $MC_TRAFO6_TIRORO_POS (frame between base center point and internal
system (position component))
Enter the rotation in machine data:
MD62613 $MC_TRAFO6_TIRORO_RPY (frame between base center point and internal
system (rotation component))
11.Determine the flange coordinate system. For this purpose, the p3_q3_r3 coordinate system
must be regarded as the initial system. The offset is entered in machine data:
MD62610 $MC_TRAFO6_TFLWP_POS (frame between wrist point and flange (position
component))
The rotation is entered in machine data:
MD62611 $MC_TRAFO6_TFLWP_RPY (frame between wrist point and flange (rotation
component))
SCARA kinematics
SCARA kinematics are characterized by the fact that they possess both translational and rotary
axes. The kinematics have different names depending on how the basic axes are arranged
with respect to one another, e.g.: CC, SC, CS kinematics (see Chapter "Definition of a joint
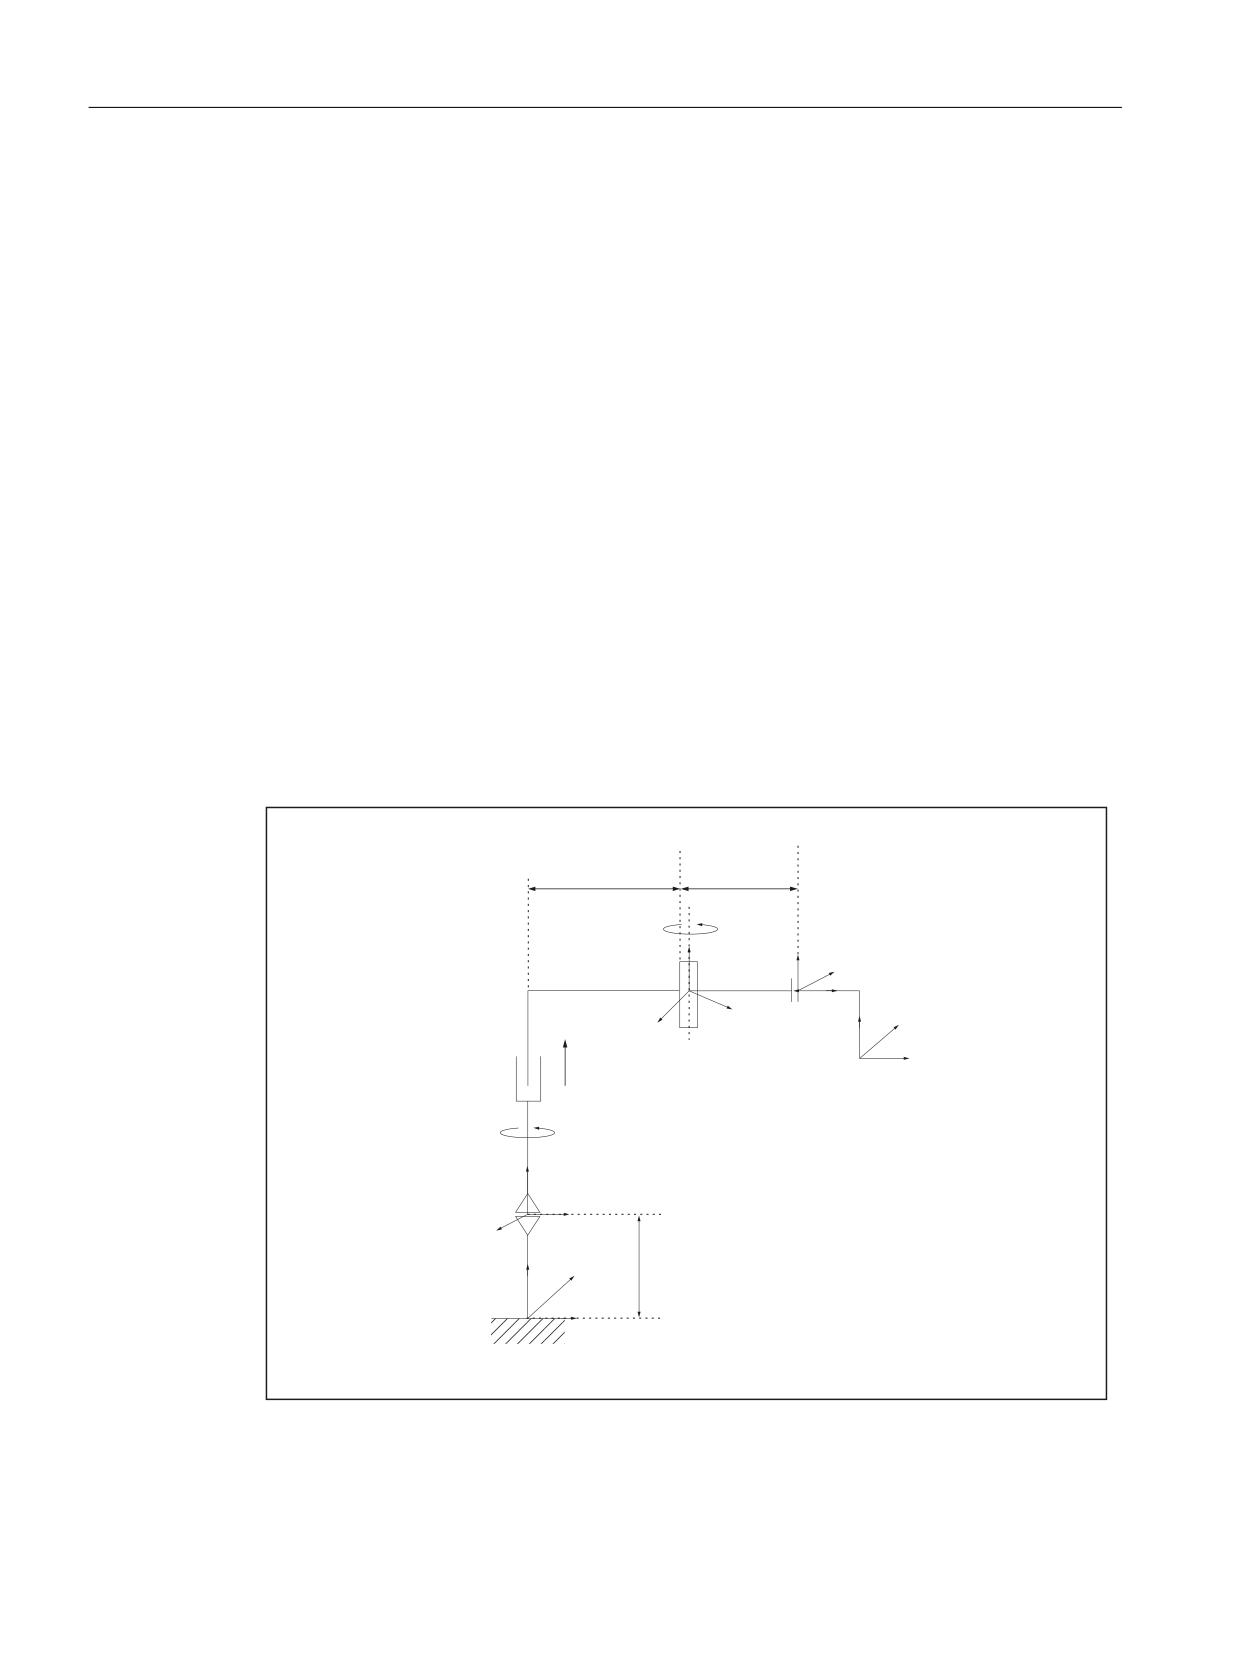
(Page 762)").
3-axis CC kinematics
&&
0'
0'
75$)2 B0$,1B/(1*7+B$%>
@
75$)2 B7)
/:3B326> @
T
]
)/
\)/
S
[)/
]:=
\:=
U
[:=
\,52
[,522
],52
]
0'
52
\52
75$)2 B7,5252B326> @
[52
Figure 20-12
3-axis CC kinematics
Special functions
778
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Table 20-4
Configuration data for 3-axis CC kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
3
MD62603 $MC_TRAFO6_MAIN_AXES
2
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 1, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[2, 1, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[0.0, 300.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 90.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[0.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[200.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, -90.0]
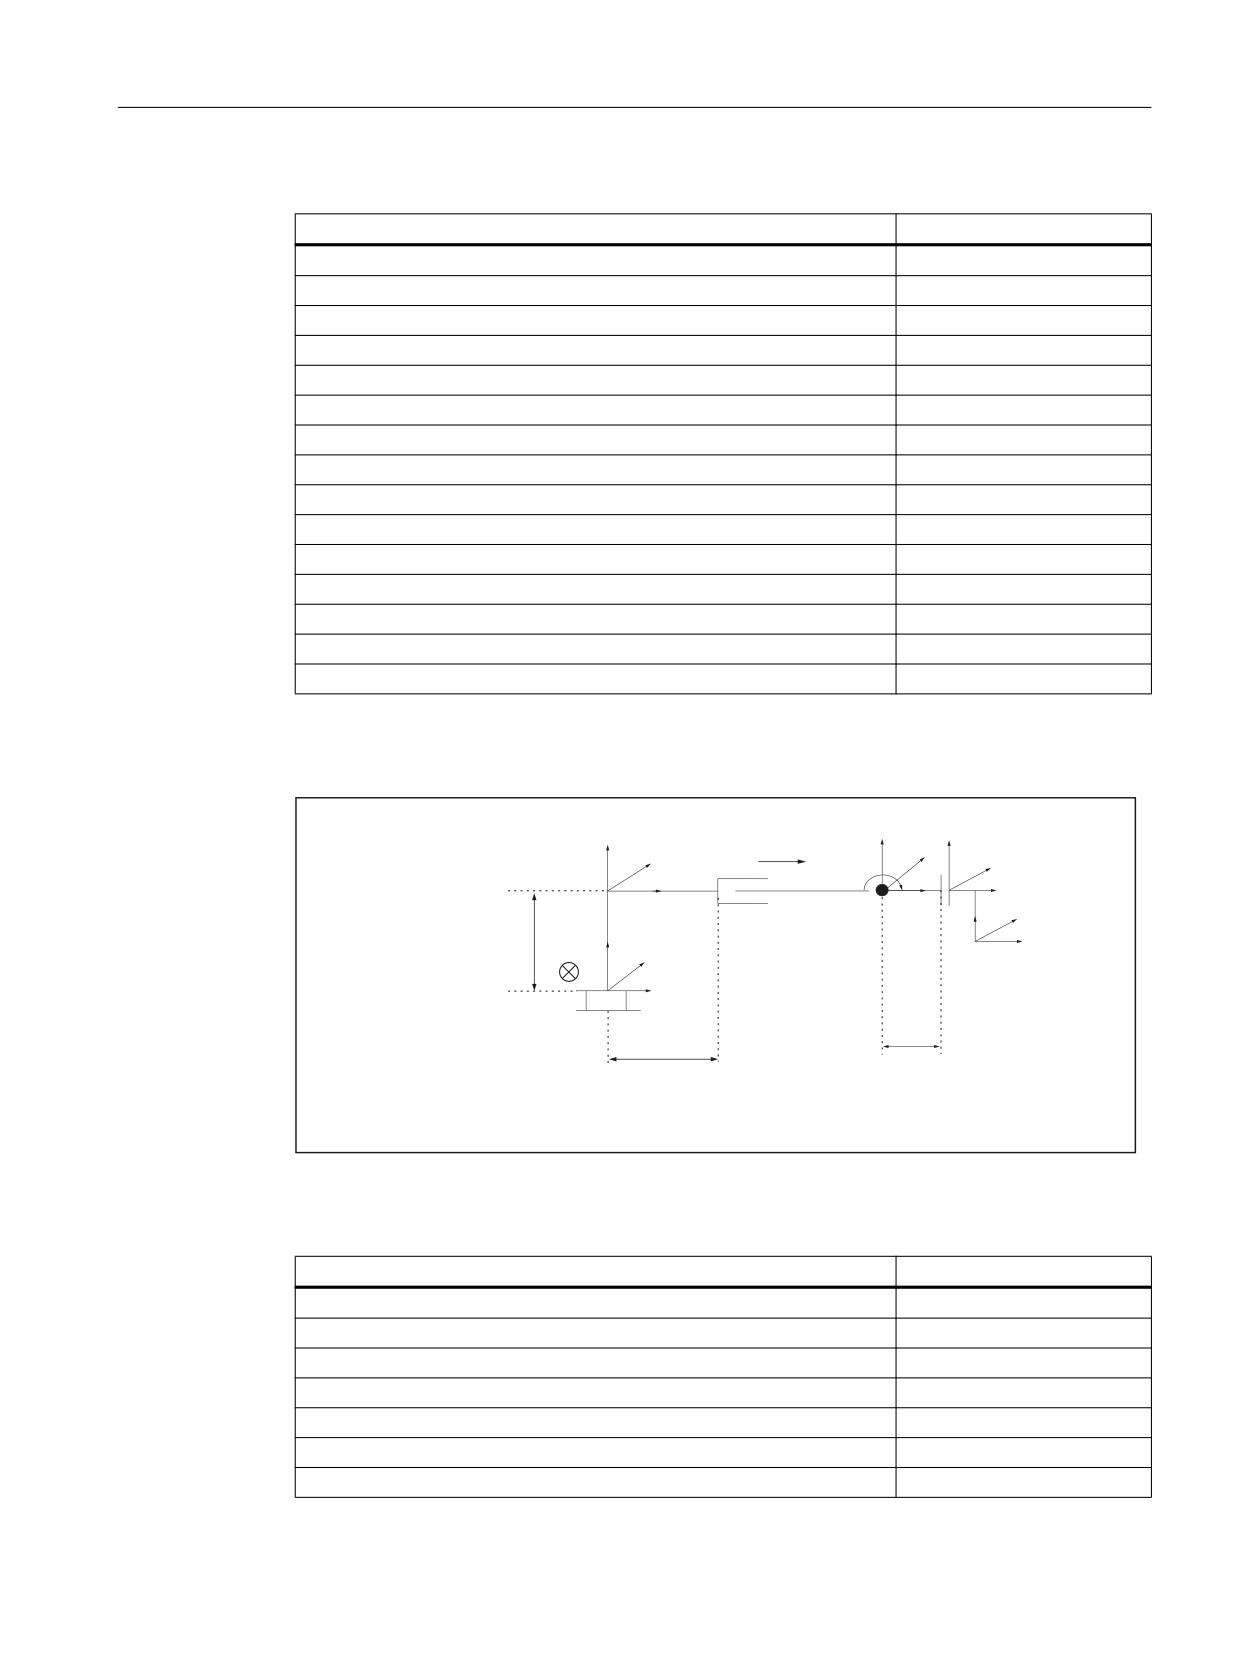
3-axis SC kinematics
])/
6&
U
,52
]
T
\,52
\)/
[)/
[,52
S
]:=
\:=
0'
],52
[:=
75$)2 B7,5252B326> @
\,52
[,52
0'
0'
75$)2 B0$,1B/(1*7+B$%> @
75$)2 B7)/:3B326> @
Figure 20-13
3-axis SC kinematics
Table 20-5
Configuration data for 3-axis SC kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
3
MD62603 $MC_TRAFO6_MAIN_AXES
4
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[1, 1, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
Special functions
Function Manual, 12/2018, A5E40874099B AB
779
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Machine data
Value
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[500.0, 0.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[0.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[300.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, 0.0]
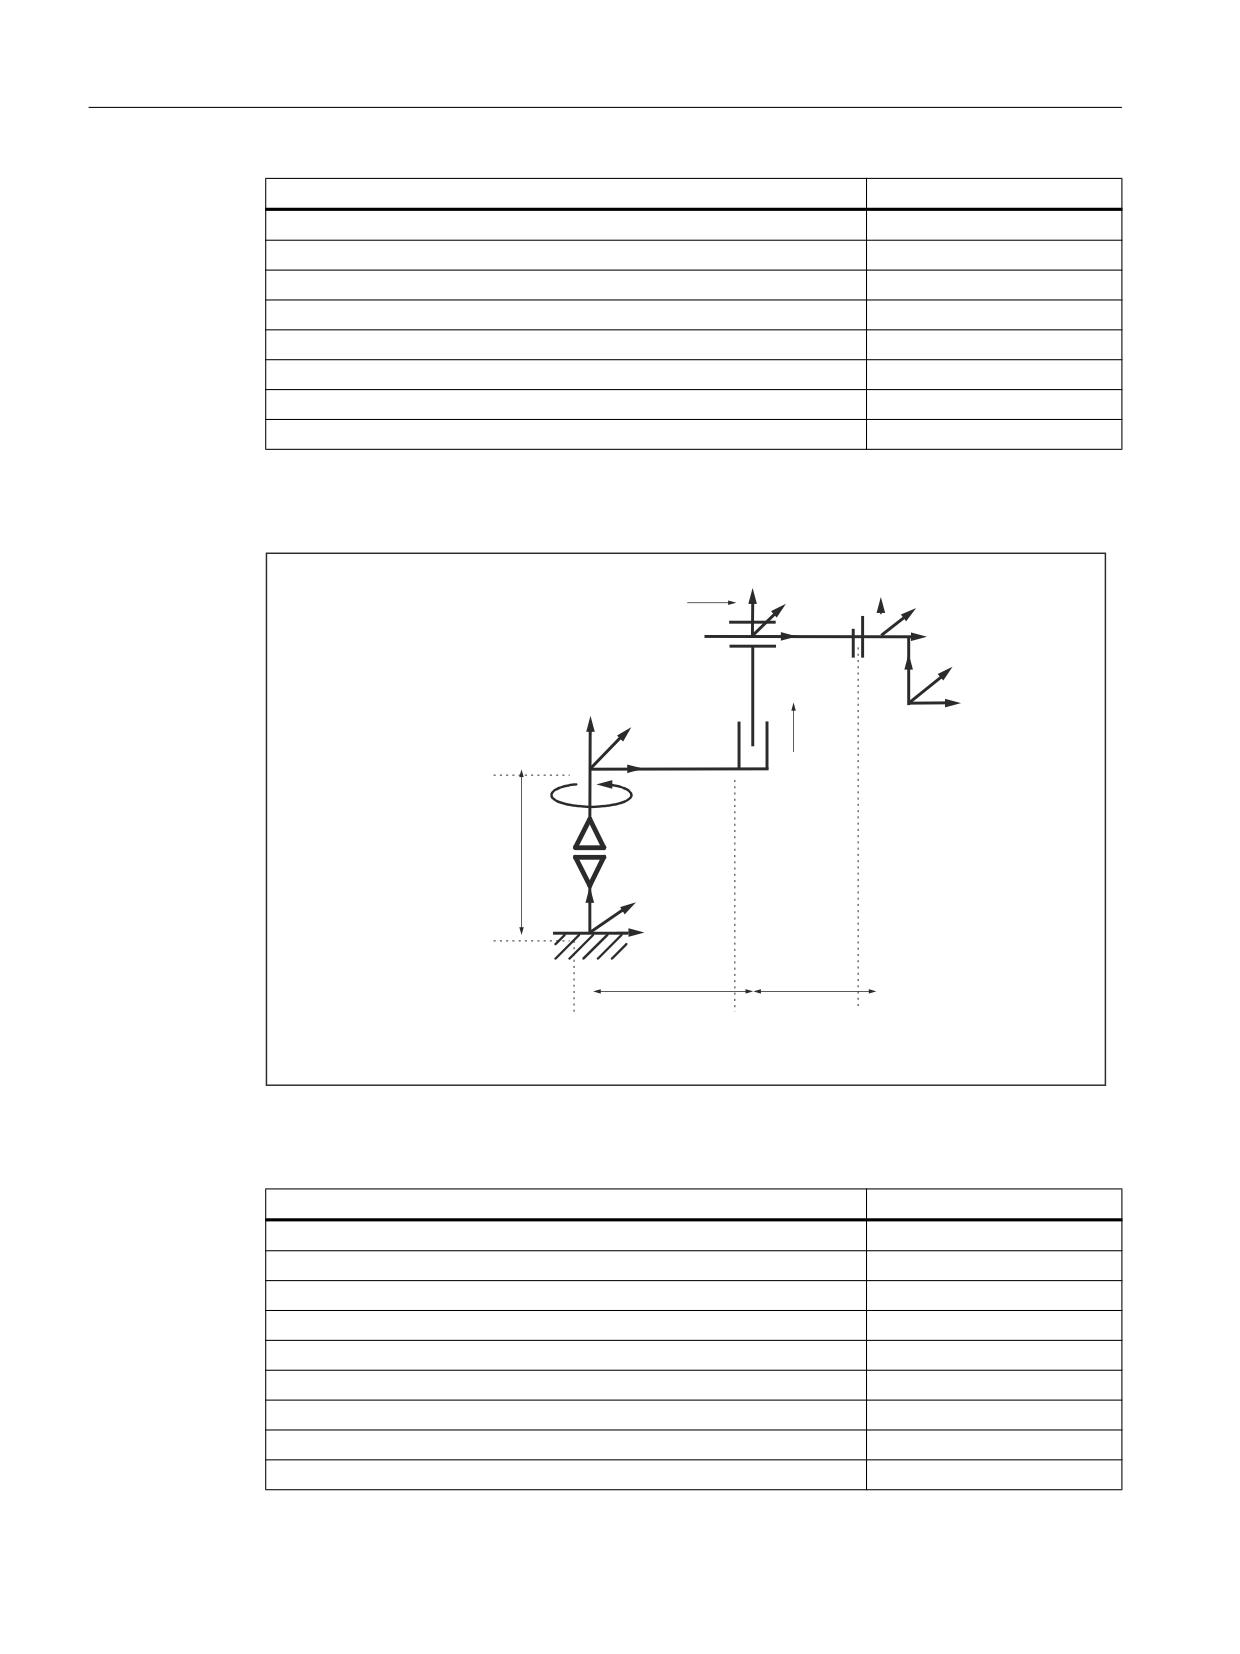
3-axis CS kinematic
U
&6
]
T
)/
\
)/
[
S
)/
\
]
:=
:=
]
[
,52
:=
\
,52
[
,52
0'
75$)2 B7,5252B326> @
]
52
\
52
[
52
0'
75$)2 B7)/:3B326> @
0'
75$)2 B0$,1B/(1*7+B$%> @
Figure 20-14
3-axis CS kinematic
Table 20-6
Configuration data for 3-axis CS kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
3
MD62603 $MC_TRAFO6_MAIN_AXES
6
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 1, 1, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[500.0, 0.0]
Special functions
780
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Machine data
Value
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[0.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[300.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, 0.0]
Articulated-arm kinematics
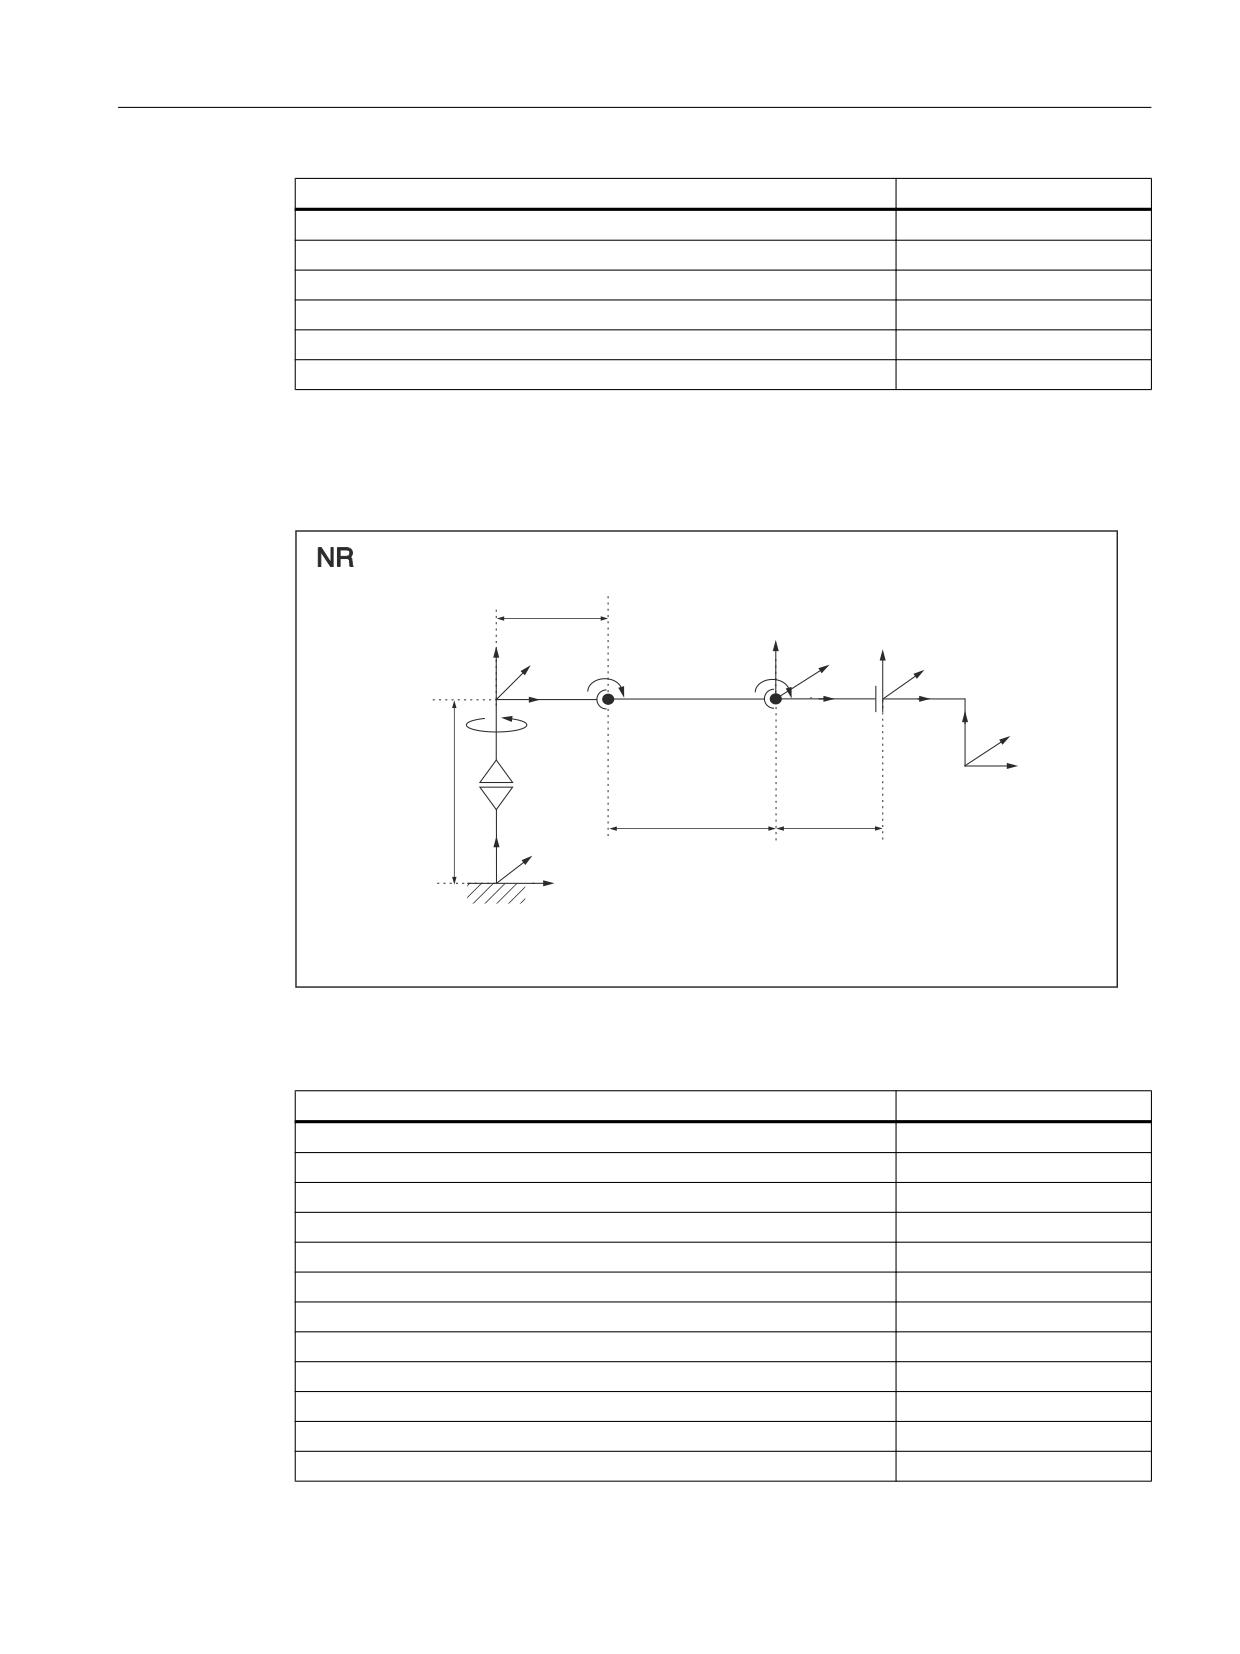
3-axis NR kinematics
0'
75$)2 B0$,1B/(1*7+B$%> @
5
=,52
=
)/
<
4
,52
<)/
;,52
3
;)/
=:=
<:=
;:=
0'
75$) B
7,5252B326> @
=52
<52
0'
75$)2 B
7)/:3B326> @
;52
0'
75$)2 B
0$,1B/(1*7+B$%> @
Figure 20-15
3-axis NR kinematics
Table 20-7
Configuration data 3-axis NR kinematic
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
3
MD62603 $MC_TRAFO6_MAIN_AXES
3
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[300.0, 500.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[0.0, 0.0, 0.0]
Special functions
Function Manual, 12/2018, A5E40874099B AB
781
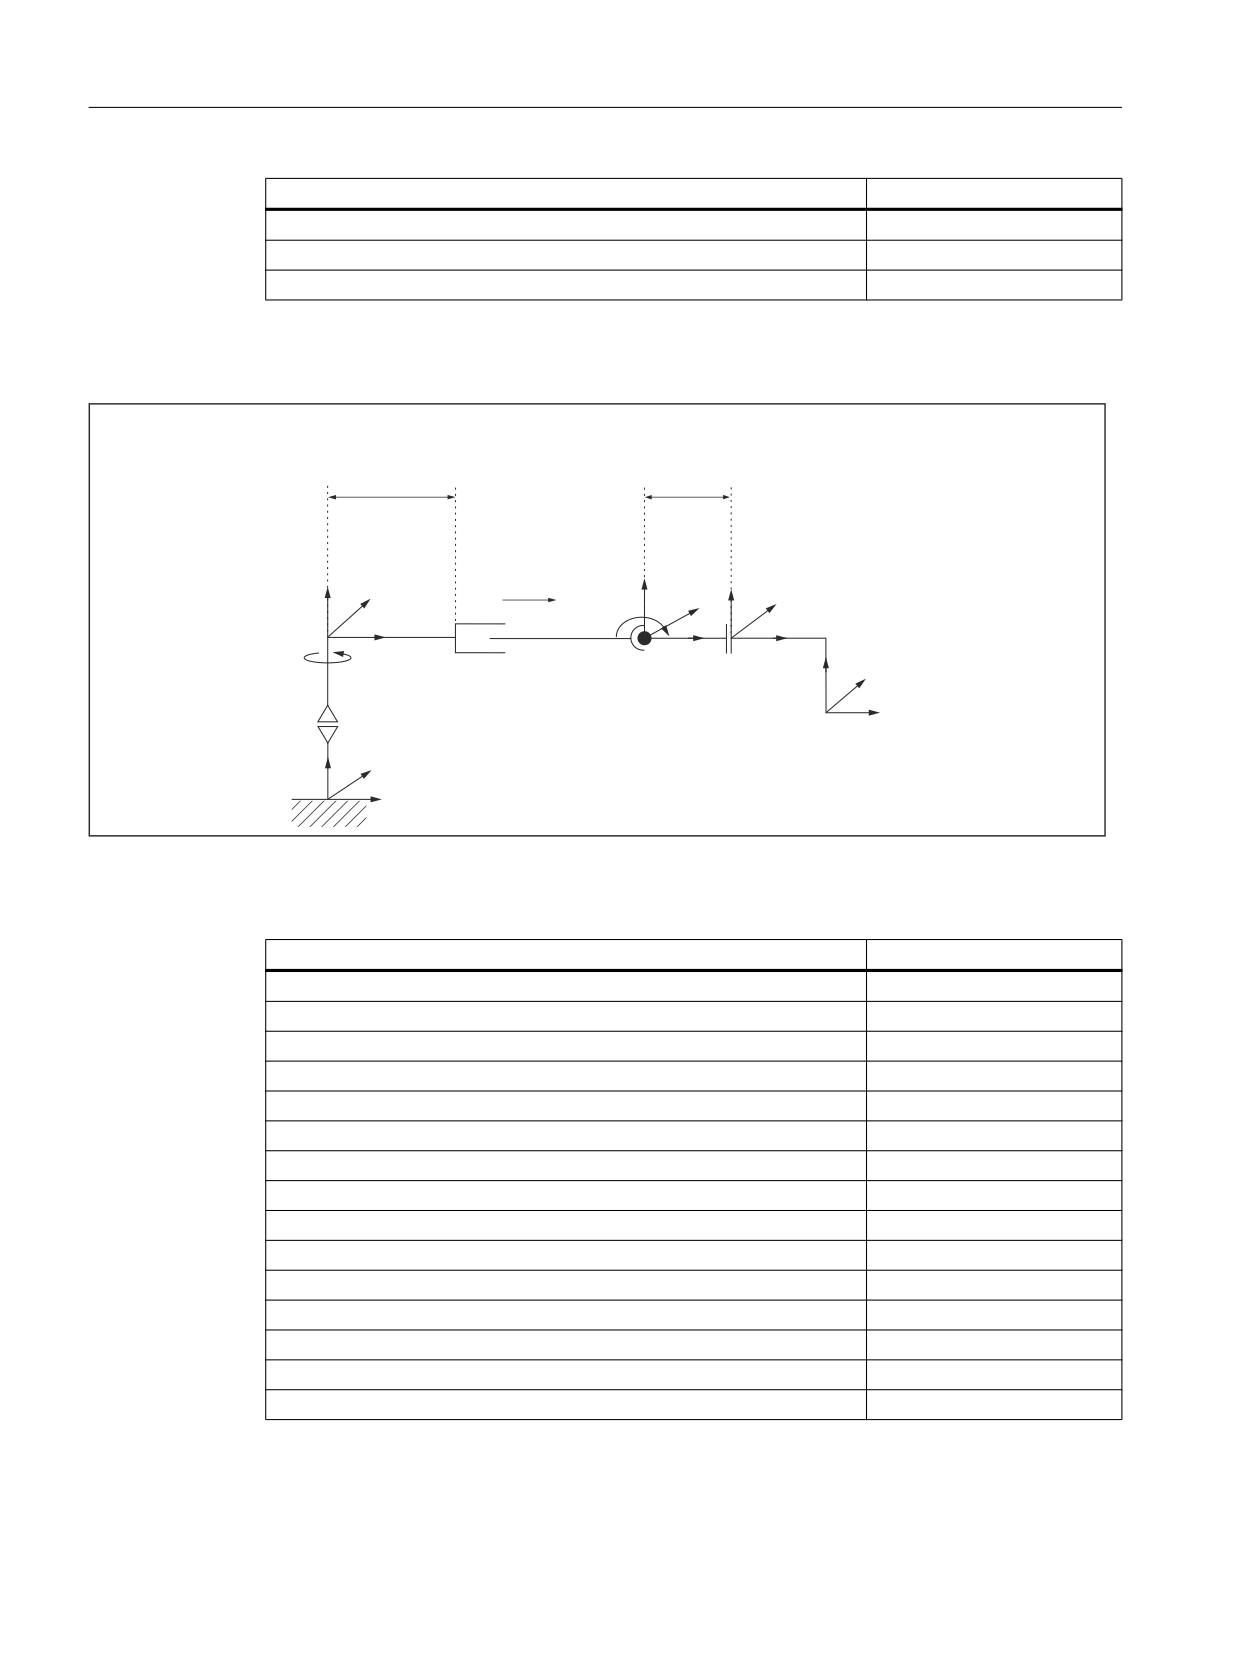
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Machine data
Value
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[300.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, 0.0]
3-axis RR kinematics
55
0'
0'
75$)2 B0$,1B/(1*7+B$%> @
75$)2 B7)/:3B326> @
5
=,52
=)/
<,52
4
<)/
;,52
3
;)/
=:=
<:=
;:=
=52
<52
;52
Figure 20-16
3-axis RR kinematics
Table 20-8
Configuration data for 3-axis RR kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
3
MD62603 $MC_TRAFO6_MAIN_AXES
5
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 1, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[300.0, 0.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 300.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[0.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[200.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, 0.0]
Special functions
782
Function Manual, 12/2018, A5E40874099B AB
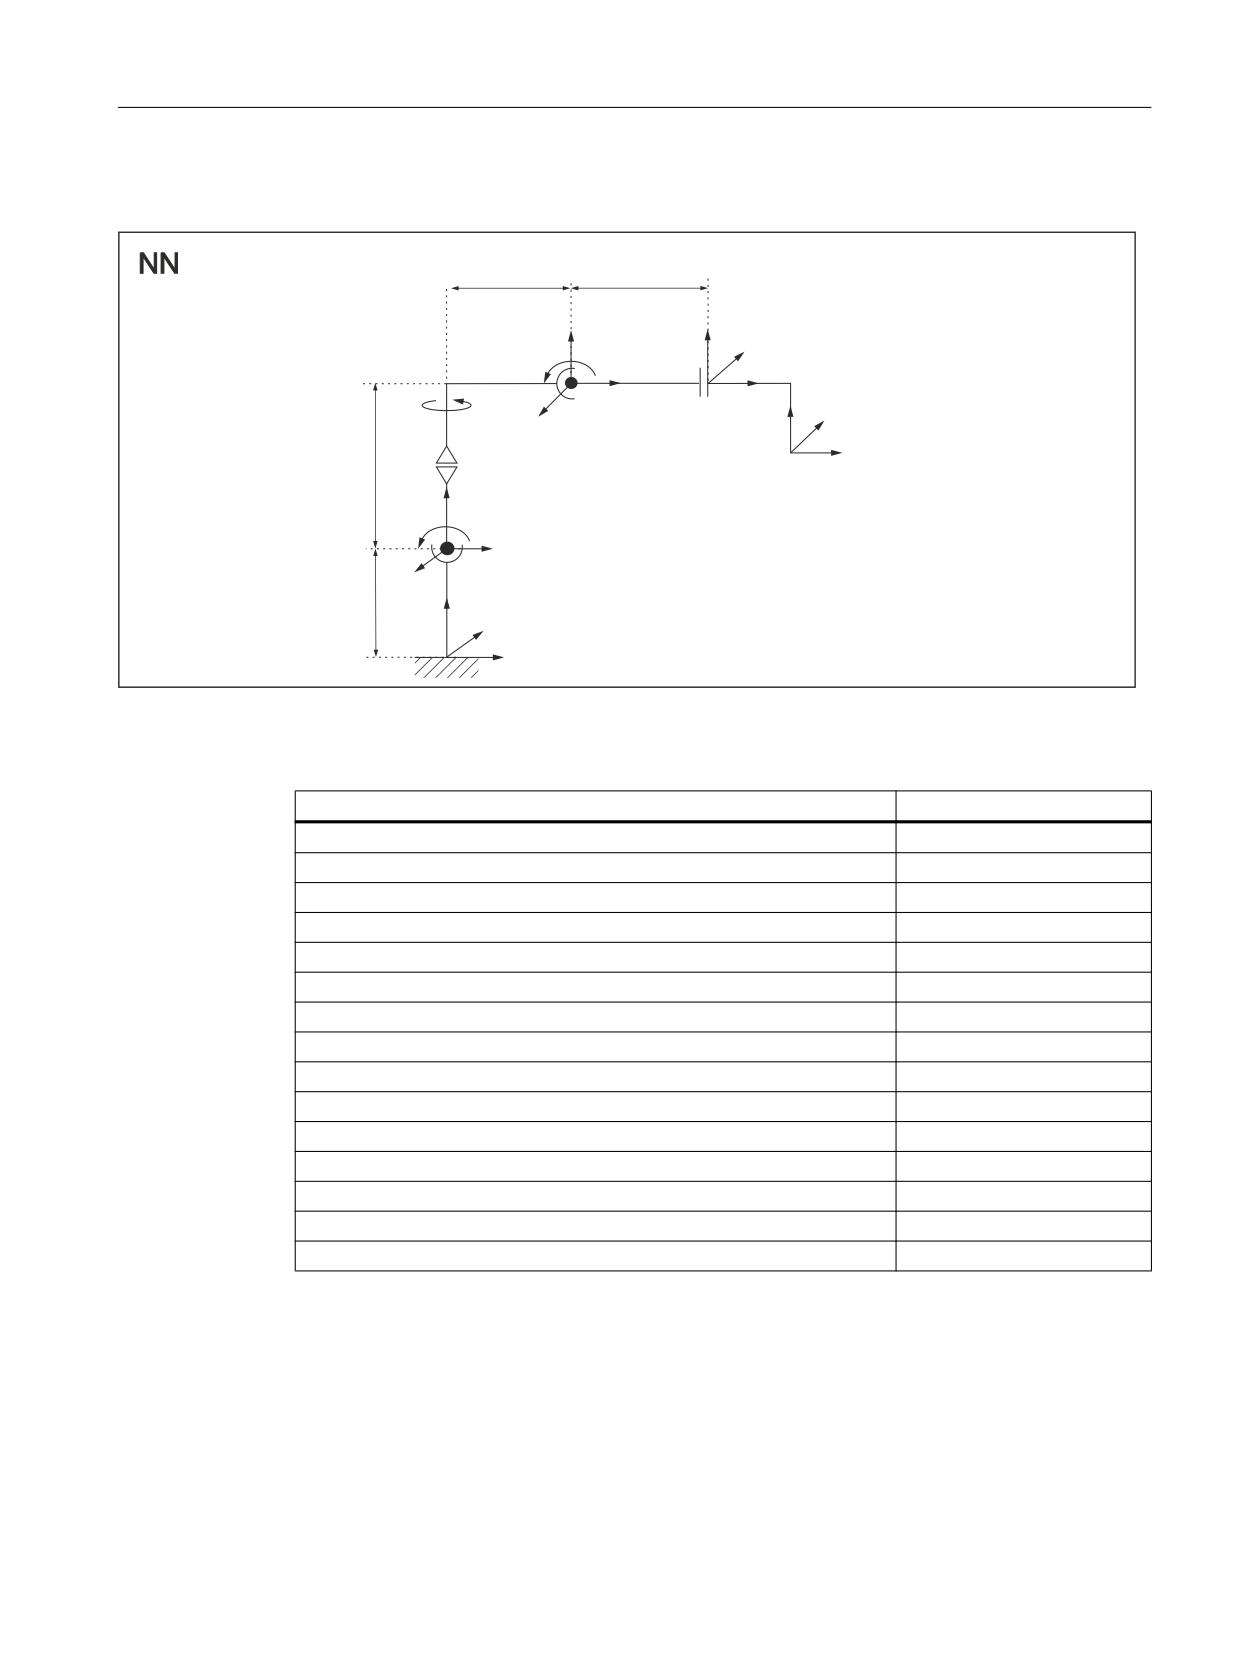
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
3-axis NN kinematics
0'
0'
75$)2 B0$,1B/(1*7+B$%> @
75$)2 B7)/:3B326> @
4
=)/
<)/
;)/
3
=:=
5
<:=
0'
;:=
75$)2 B0$,1
B
/(1*7+B$%> @
<,52
;,52
=,52
0'
75$)2 B7,5252B
326> @
=52
<52
;52
Figure 20-17
3-axis NN kinematics
Table 20-9
Configuration data for 3-axis NN kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
3
MD62603 $MC_TRAFO6_MAIN_AXES
7
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[300.0, 500.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 300.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 90.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[0.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPYFehler! Bookmark not defined.
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[400.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, -90.0]
20.5.2
4-axis kinematics
4-axis kinematics normally have 3 translational degrees of freedom and one rotational degree
of freedom for orientation.
Special functions
Function Manual, 12/2018, A5E40874099B AB
783
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Restrictions
The following restrictions apply to 4-axis kinematics:
The frame T_FL_WP is subject to the following condition:
● MD62611 $MC_TRAFO6_TFLWP_RPY = [ 0.0, 90.0, 0.0 ] (frame between wrist point and
flange (rotation component))
● X flange and X tool must be parallel to the 4th axis.
● Two successive basic axes must be parallel or orthogonal.
● The 4th axis must only be mounted in a parallel or orthogonal way to the last basic axis.
Configuration
The procedure for configuring a 4-axis kinematic is as follows:
1. Enter "Standard" kinematic category in the machine data:
MD62600 $MC_TRAFO6_KINCLASS (kinematic category)
2. Set the number of axes for transformation in the machine data:
MD62605 $MC_TRAFO6_NUM_AXES=4 (number of transformed axes)
3. Compare the basic axes with the basic axes contained in the handling transformation
package.
- Enter the basic axis identifier in machine data:
MD62603 $MC_TRAFO6_MAIN_AXES (basic axis identifier)
4. If the axis sequence is not the same as the normal axis sequence, it must be corrected in
machine data:
MD62620 $MC_TRAFO6_AXIS_SEQ (rearrangement of axes)
5. As identifier for the wrist axes, the following machine data must be set (no wrist axis):
MD62604 $MC_TRAFO6_WRIST_AXES = 1 (wrist axis identifier)
6. Whether axis 4 runs parallel/anti-parallel to the last rotary basic axis is entered into the
machine data:
MD62606 $MC_TRAFO6_A4PAR (axis 4 is parallel/anti-parallel to last basic axis)
7. Enter the axis types for the transformation in machine data:
MD62601 $MC_TRAFO6_AXES_TYPE (axis type for transformation)
8. Compare the directions of rotation of axes with the directions defined in the handling
transformation package and correct in the machine data:
MD62618 $MC_TRAFO6_AXES_DIR (matching of physical and mathematical directions
of rotation)
9. Enter the mechanical zero offset in the machine data:
MD62617 $MC_TRAFO6_MAMES (offset between mathematical and mechanical zero
points)
10.Enter the basic axis lengths in the machine data:
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB (basic axis lengths A and B)
Special functions
784
Function Manual, 12/2018, A5E40874099B AB
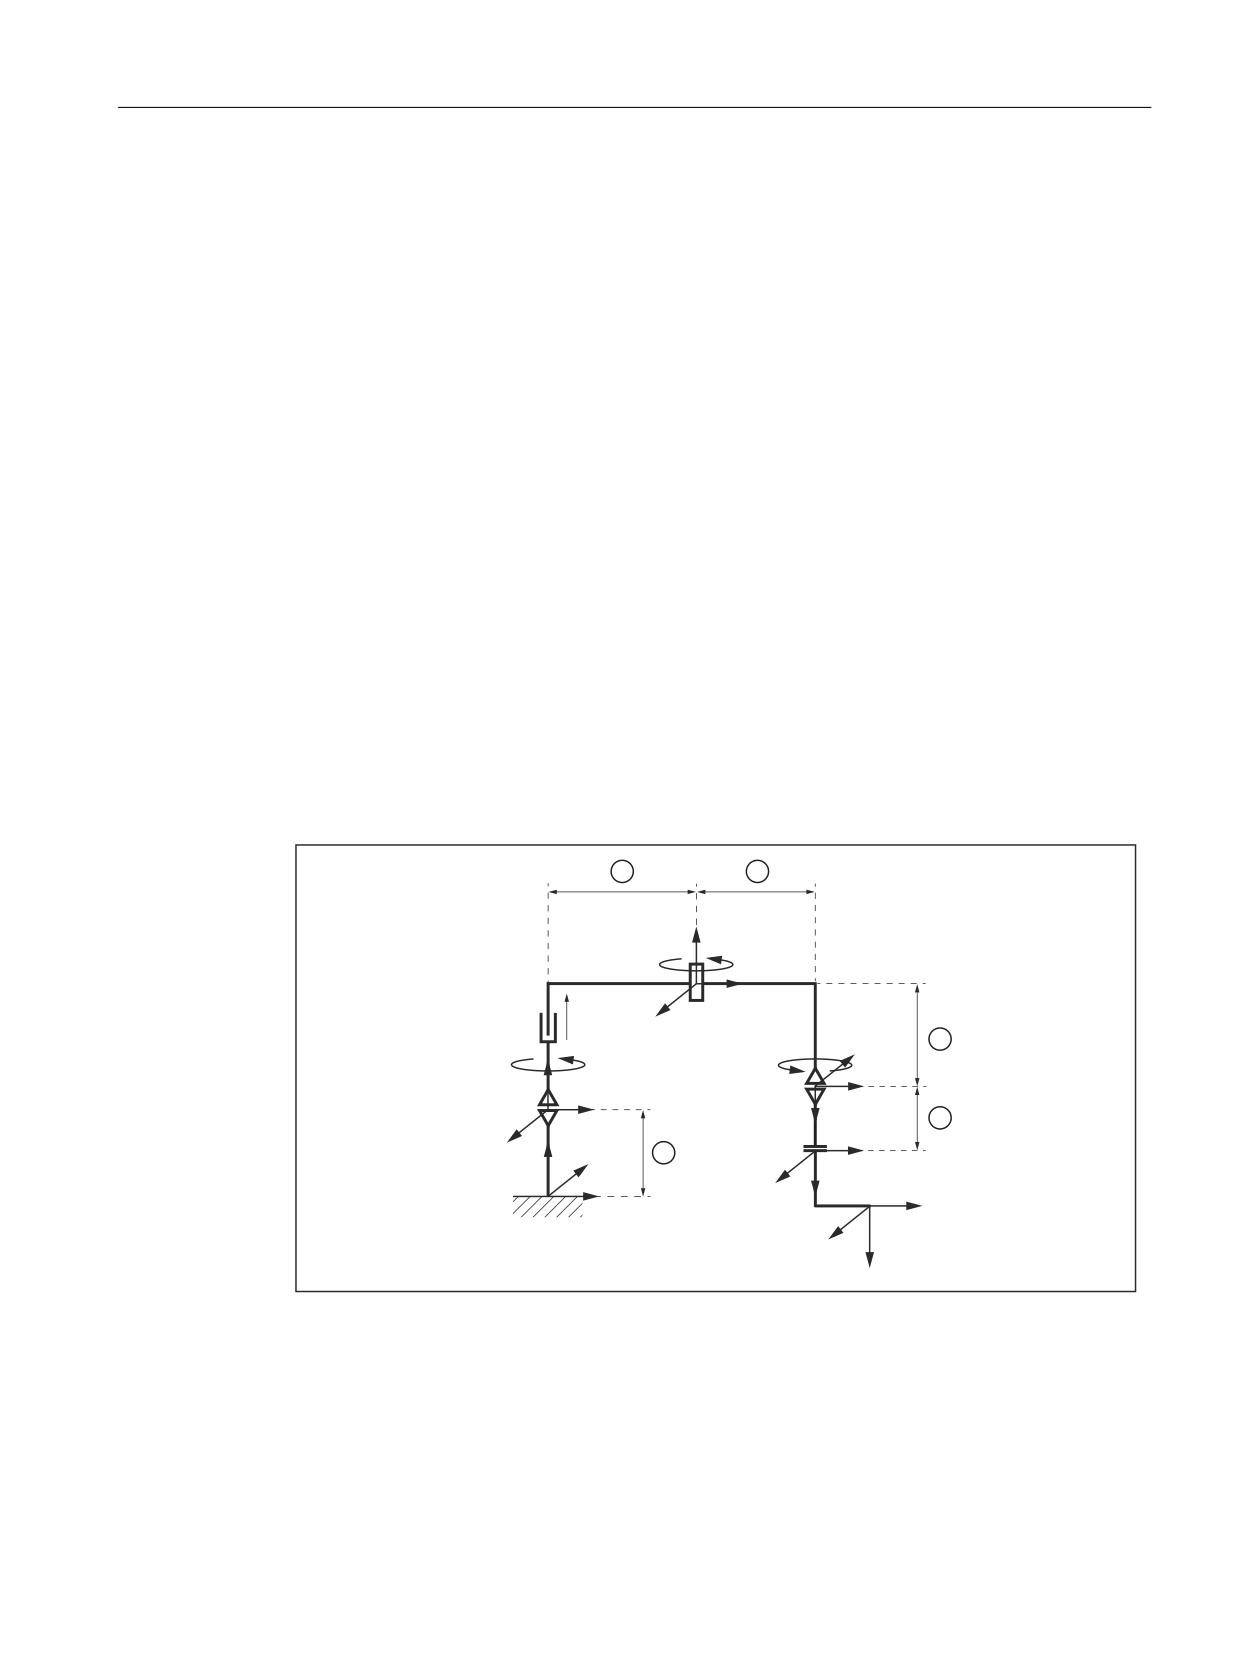
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
11.Define frame T_IRO_RO and enter the offset in the machine data:
MD62612 $MC_TRAFO6_TIRORO_POS (frame between base center point and internal
system (position component))
Enter the rotation in the machine data:
MD62613 $MC_TRAFO6_TIRORO_RPY (frame between base center point and internal
system (rotation component))
12.Specification of frame T_X3_P3 to attach wrist axis. For this purpose, the p3_q3_r3
coordinate system must be regarded as the initial system. The offset is entered in the
machine data:
MD62608 $MC_TRAFO6_TX3P3_POS (attachment of wrist axis (position component))
The rotation is entered in the machine data:
MD62609 $MC_TRAFO6_TX3P3_RPY (attachment of wrist axis (rotation component))
is entered.
13.Determine the flange coordinate system. For this purpose, the wrist point coordinate system
must be regarded as the initial system. The offset is entered in the machine data:
MD62610 $MC_TRAFO6_TFLWP_POS (frame between wrist point and flange (position
component))
The rotation is entered in the machine data:
MD62611 $MC_TRAFO6_TFLWP_RPY (frame between wrist point and flange (rotation
component))
SCARA kinematics
4-axis CC kinematics
T
S
U
[+3
\,52
\+3
]+3
[,52
],52
\
)/
[)/
])/
\:=
]:=
[:=
① MD62612 $MC_TRAFO6_TIRORO_POS[2]
② MD62607 $MC_TRAFO6_MAIN_LENGTH_AB[1]
③ MD62608 $MC_TRAFO6_TX3P3_POS[0]
④ MD62608 $MC_TRAFO6_TX3P3_POS[1]
⑤ MD62610 $MC_TRAFO6_TFLWP_POS[0]
Figure 20-18
4-axis CC kinematics
Special functions
Function Manual, 12/2018, A5E40874099B AB
785
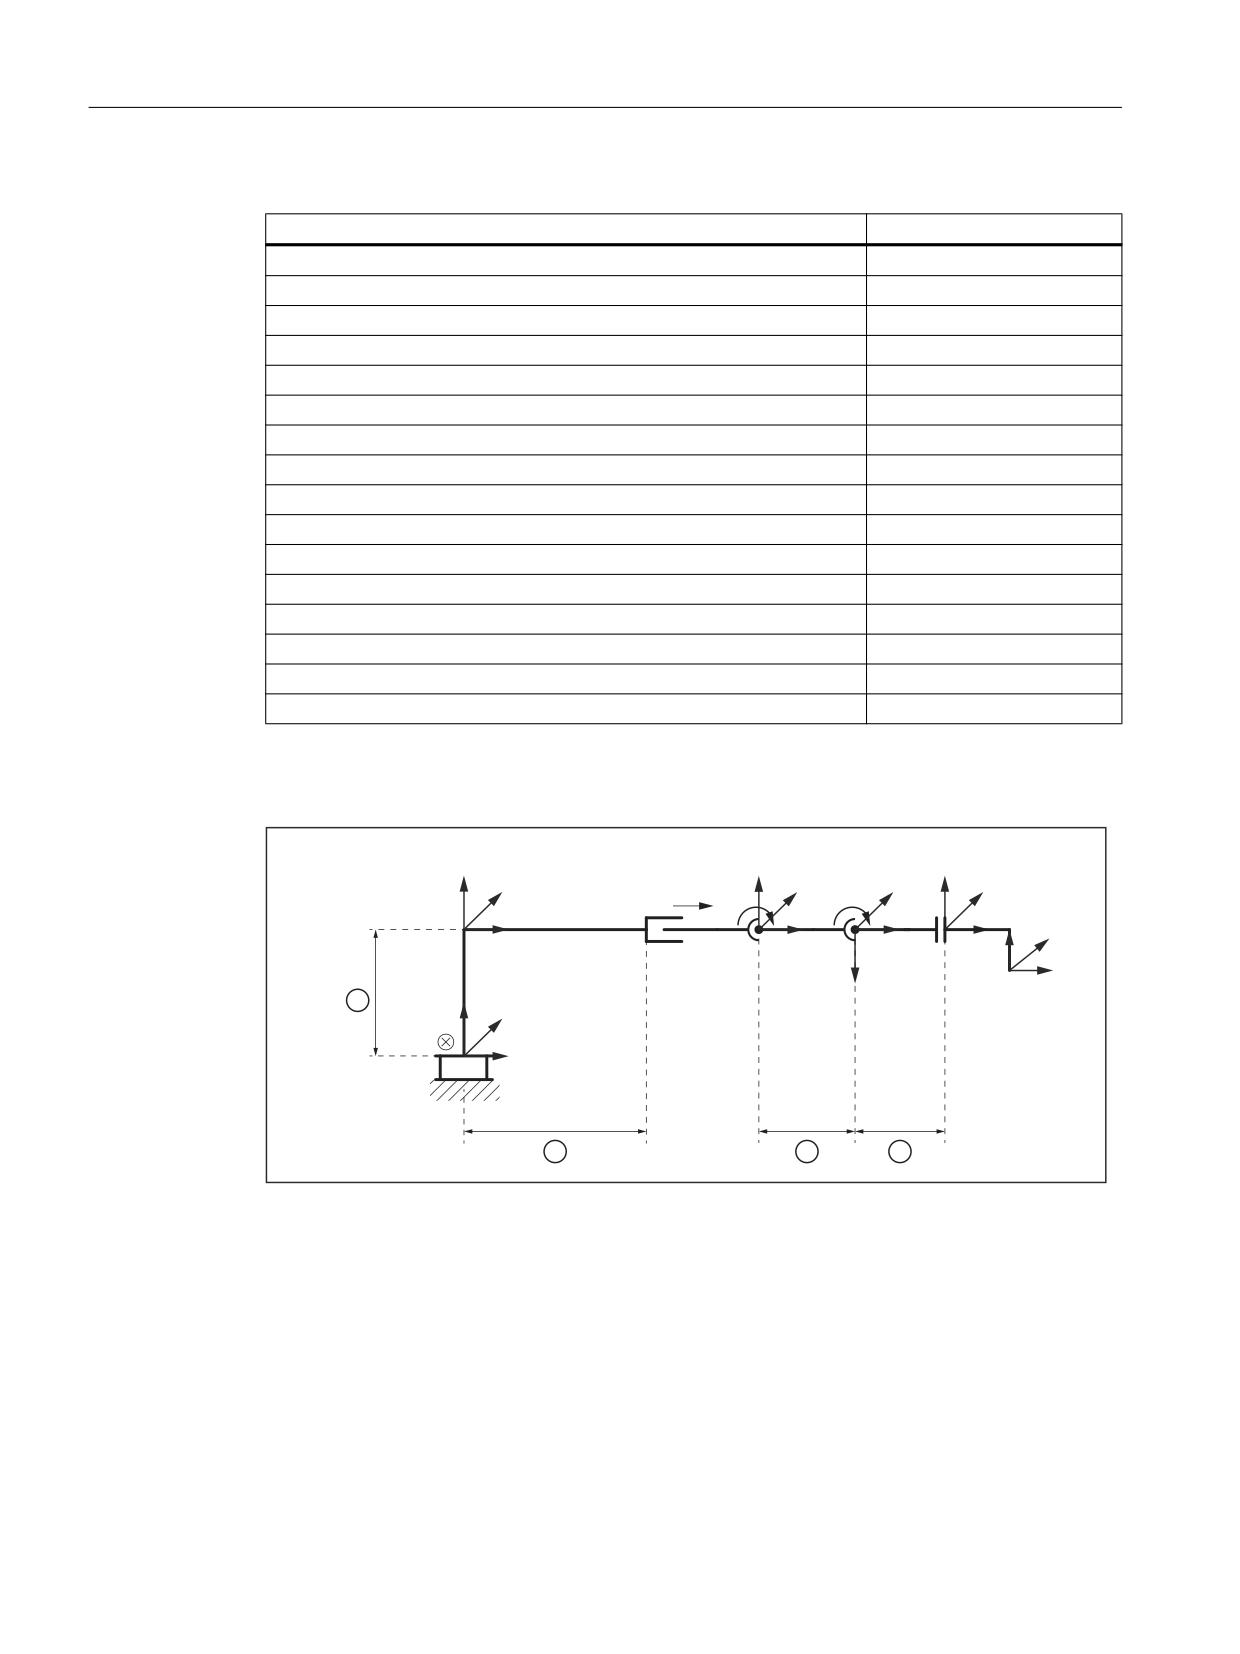
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Table 20-10 Configuration data for 4-axis CC kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
4
MD62603 $MC_TRAFO6_MAIN_AXES
2
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62606 $MC_TRAFO6_A4PAR
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 1, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[2, 1, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR)
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[0.0, 300.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 90.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[300.0, 0.0, -200.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[-90.0, 90.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[0.0, 0.0, 200.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, -90.0, 0.0]
4-axis SC kinematics
],52
U
\)/
\,52
T
]
[)/
\:=
[,52
S
[
])/
[:=
\
]:=
]52
\52
[52
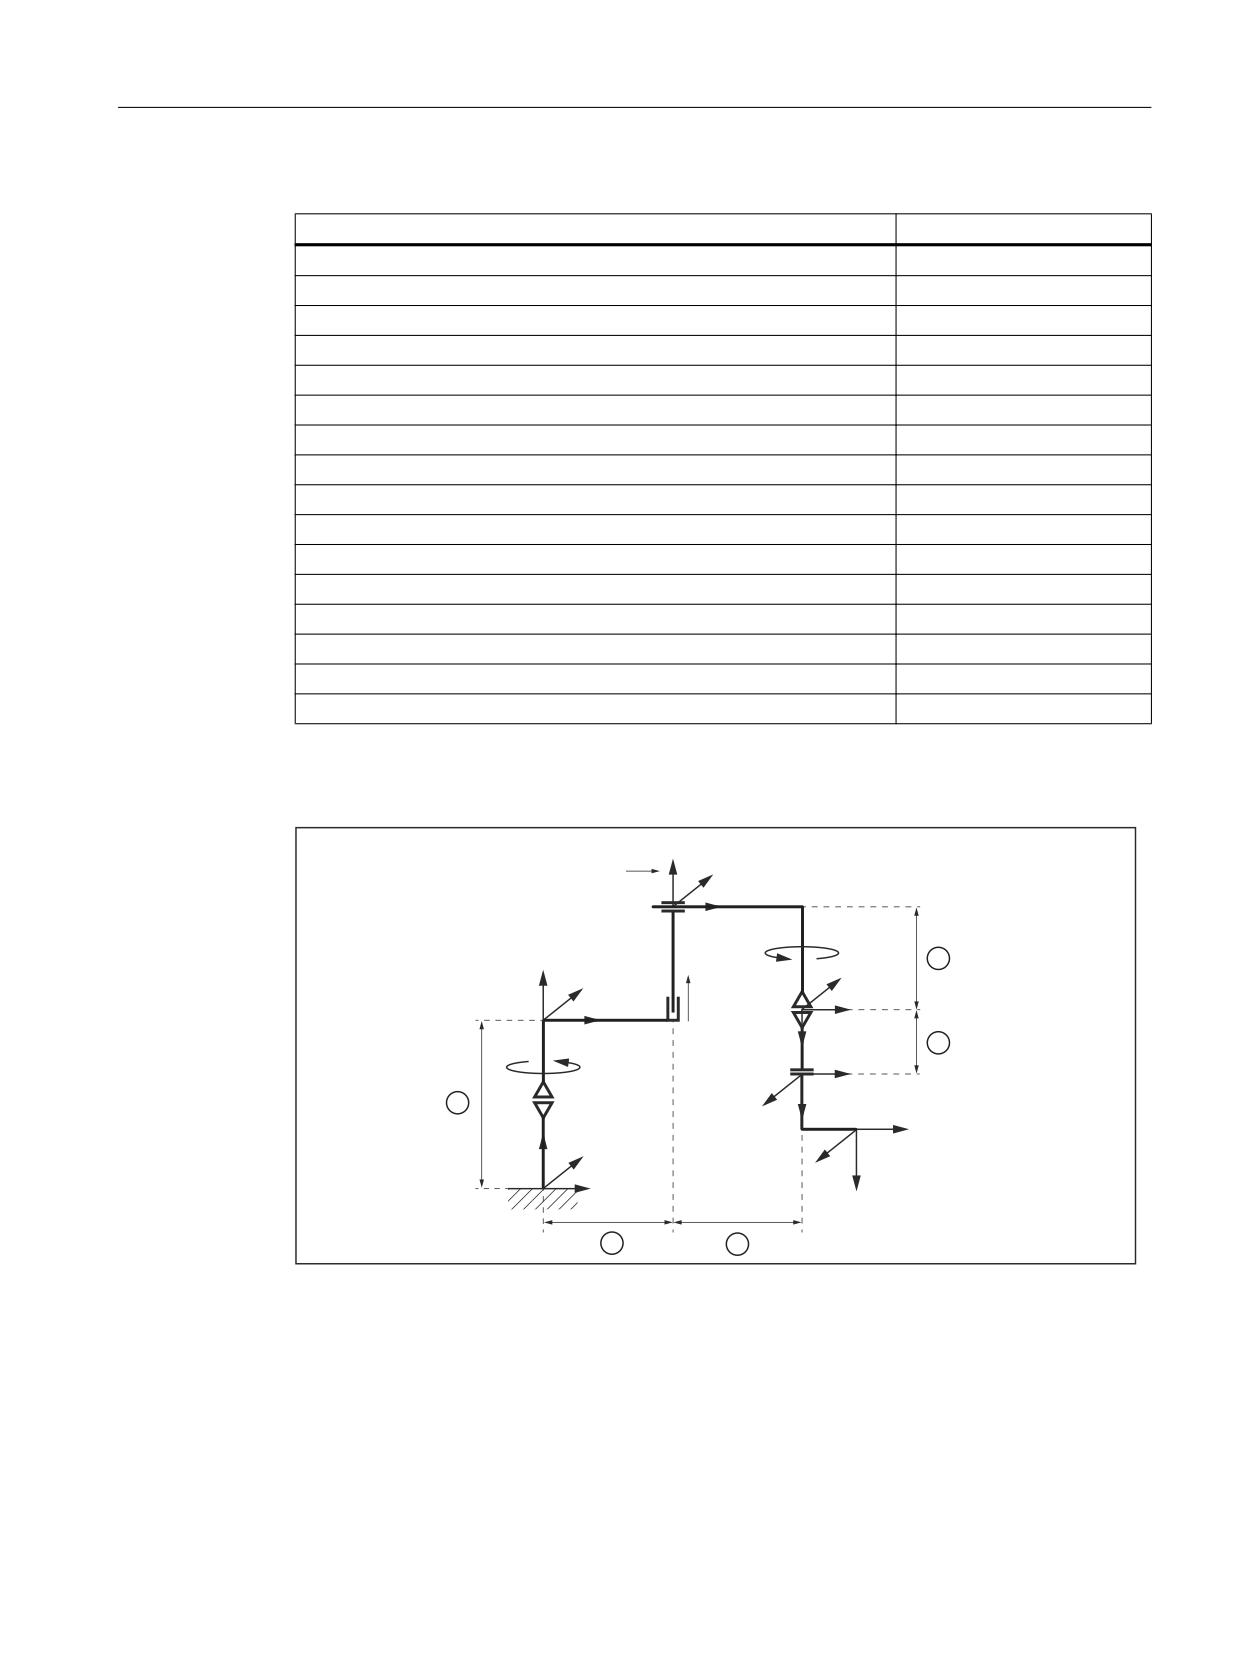
① MD62612 $MC_TRAFO6_TIRORO_POS[2]
② MD62607 $MC_TRAFO6_MAIN_LENGTH_AB[0]
③ MD62608 $MC_TRAFO6_TX3P3_POS[0]
④ MD62610 $MC_TRAFO6_TFLWP_POS[0]
Figure 20-19
4-axis SC kinematics
Special functions
786
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Table 20-11 Configuration data for 4-axis SC kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
4
MD62603 $MC_TRAFO6_MAIN_AXES
4
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62606 $MC_TRAFO6_A4PAR
1
MD62601 $MC_TRAFO6_AXES_TYPE
[1, 1, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[300.0, 0.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 300.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[200.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, -90.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[200.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, -90.0, 180.0]
4-axis CS kinematic
U
T
S
],52
[+3
\,52
\+3
[,52
]+3
\)/
])/
[)/
]52
\:=
\52
]:=
[:=
[52
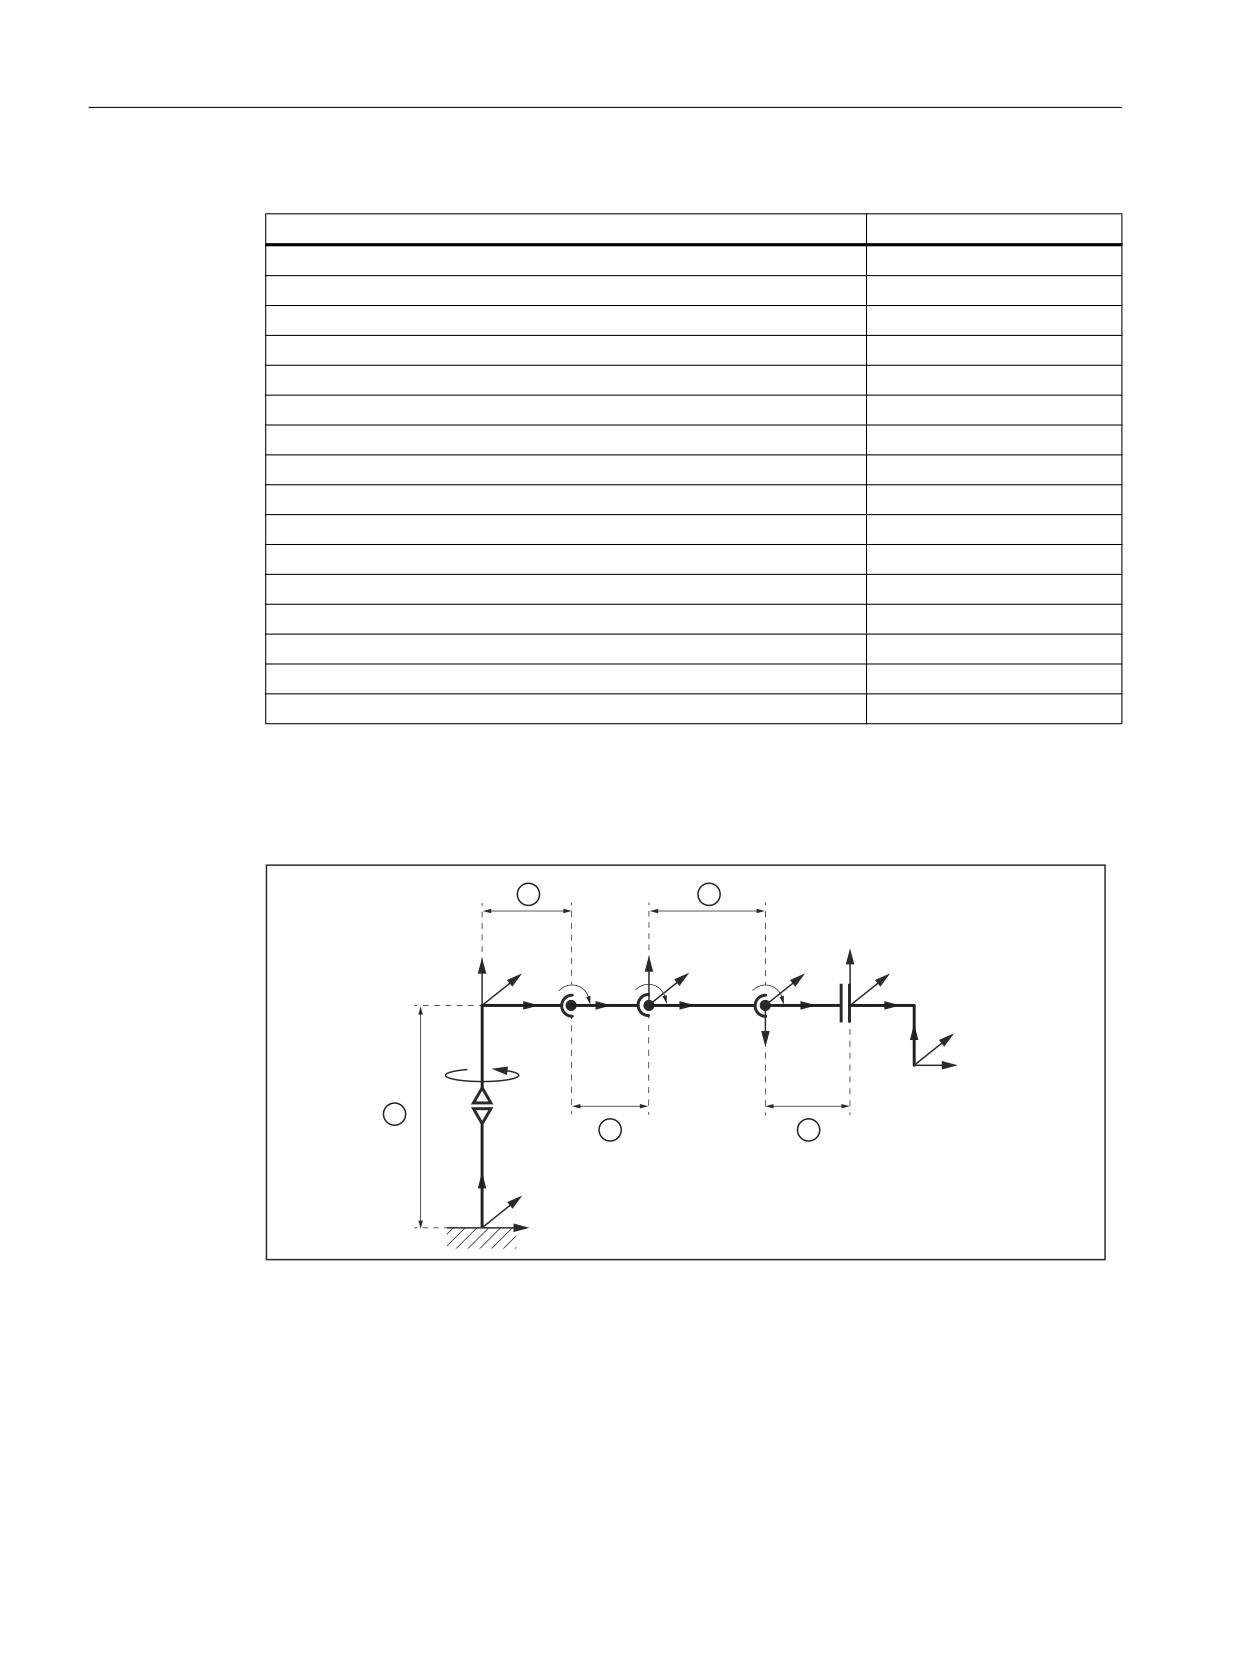
① MD62612 $MC_TRAFO6_TIRORO_POS[2]
② MD62607 $MC_TRAFO6_MAIN_LENGTH_AB[0]
③ MD62608 $MC_TRAFO6_TX3P3_POS[0]
④ MD62608 $MC_TRAFO6_TX3P3_POS[2]
⑤ MD62610 $MC_TRAFO6_TFLWP_POS[2]
Figure 20-20
4-axis CS kinematic
Special functions
Function Manual, 12/2018, A5E40874099B AB
787
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Table 20-12 Configuration data for 4-axis CS kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
4
MD62603 $MC_TRAFO6_MAIN_AXES
6
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62606 $MC_TRAFO6_A4PAR
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 1, 1, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[400.0, 0.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 400.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[500.0, 0.0, -200.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[90.0, 0.0, 180.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[0.0, 0.0, 200.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, -90.0, 0.0]
Articulated-arm kinematics
4-axis NR kinematics
U
],52
T
\)/
]+3
\,52
[)/
])/
[,52
\+3
S
[:=
[+3
\:=
]:=
]52
\52
[52
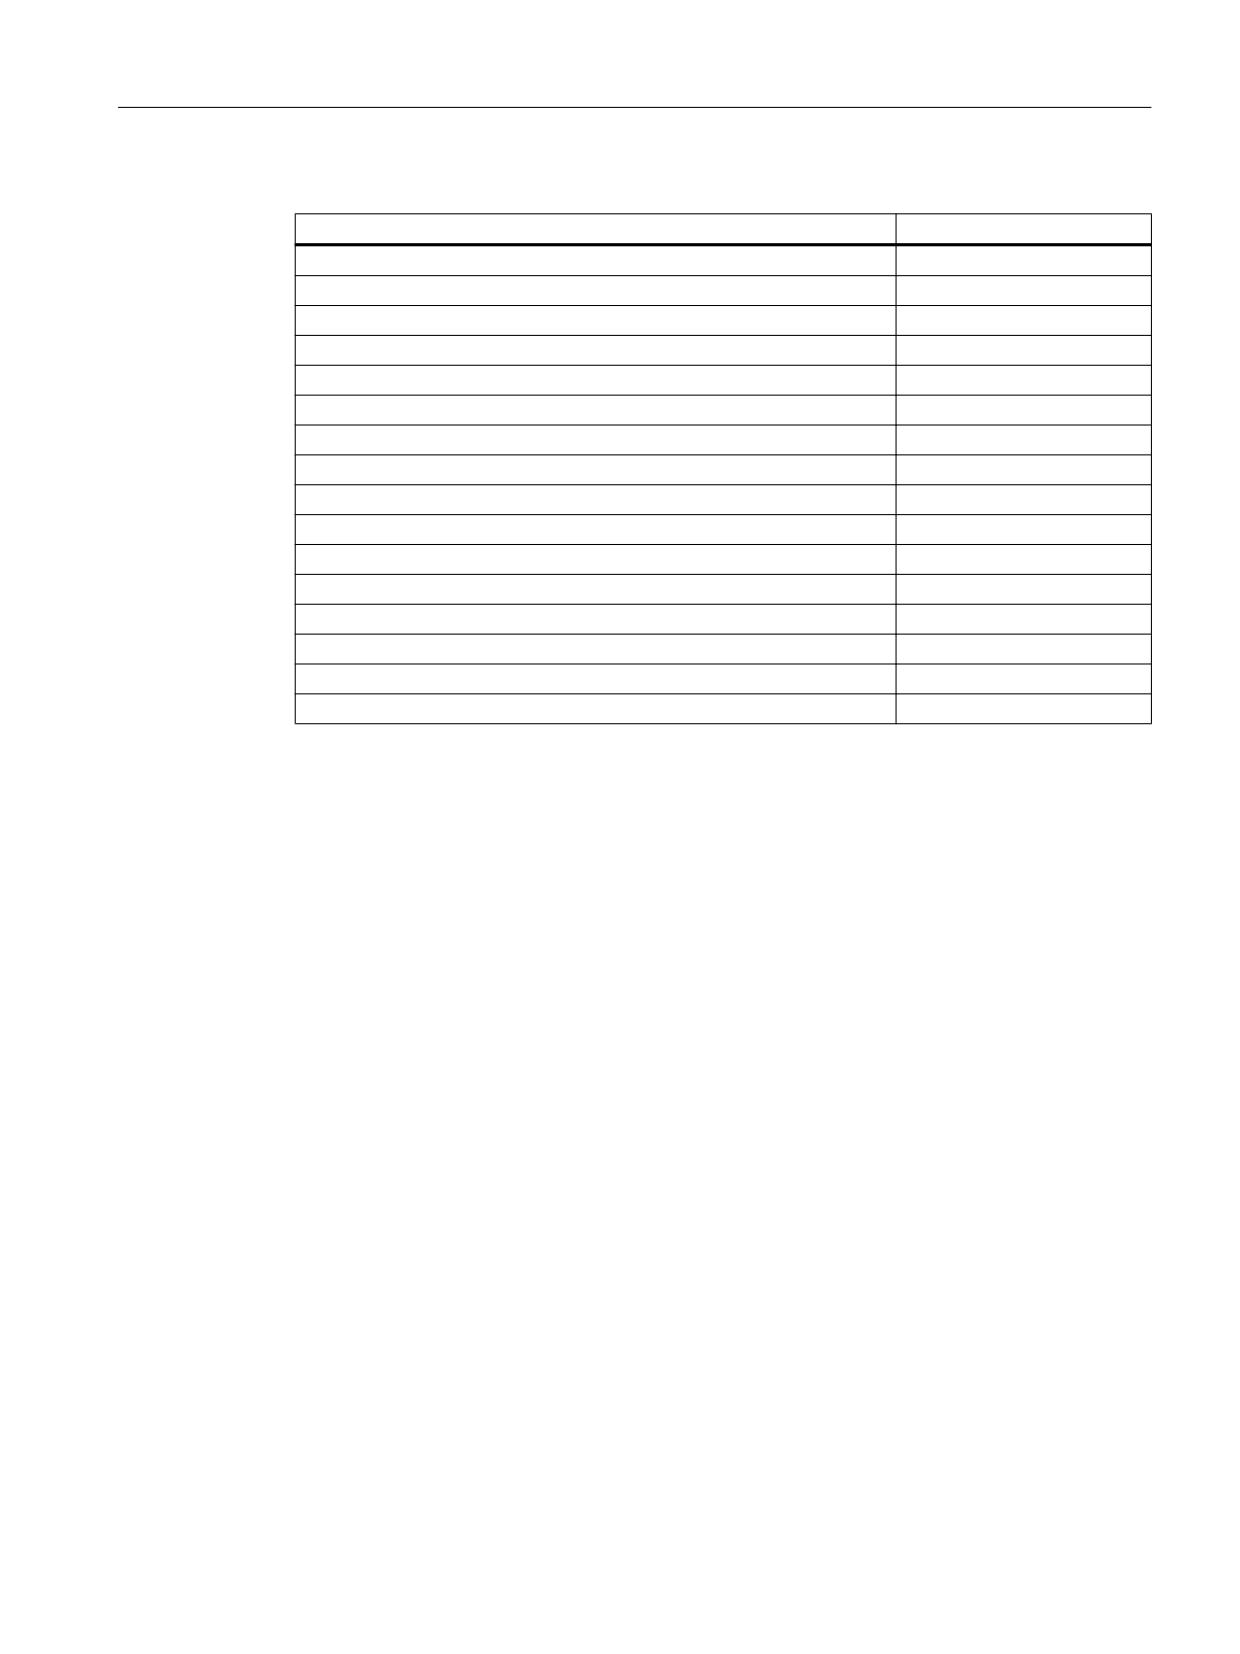
① MD62612 $MC_TRAFO6_TIRORO_POS[2]
② MD62607 $MC_TRAFO6_MAIN_LENGTH_AB[0]
③ MD62607 $MC_TRAFO6_MAIN_LENGTH_AB[1]
④ MD62608 $MC_TRAFO6_TX3P3_POS[0]
⑤ MD62610 $MC_TRAFO6_TFLWP_POS[0]
Figure 20-21
4-axis NR kinematics
Special functions
788
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Table 20-13 Configuration data 4-axis NR kinematic
Machine data
Value
MD62600 $MC_TRAFO6_ KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
4
MD62603 $MC_TRAFO6_MAIN_AXES
3
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62606 $MC_TRAFO6_A4PAR
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 3, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[300.0, 300.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[300.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, -90.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[200.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, -90.0, 180.0]
See also
Definition of a joint (Page 762)
20.5.3
5-axis kinematics
5-axis kinematics usually imply 3 degrees of freedom for translation and 2 for orientation.
Restrictions
The following restrictions apply to 5-axis kinematics:
1. There are restrictions for the flange coordinate system because the X flange axis must
intersect the 5th axis, nevertheless, it must not be parallel to it.
2. The frame T_FL_WP is subject to the following condition as far as 5-axis articulated-arm
kinematics are concerned:
- MD62610 $MC_TRAFO6_TFLWP_POS = [0.0, 0.0, Z] (frame between wrist point and
flange (position component))
- MD62611 $MC_TRAFO6_TFLWP_RPY = [A, 0.0, 0.0] (frame between wrist point and
flange (rotation component))
3. There are restrictions for the tool as far as 5-axis articulated-arm kinematics are concerned:
-
4. Axis parallel to the 3rd axis: 2-dimensional tool is possible [X, 0.0, Z]
-
4. Axis perpendicular to the 3rd axis: Only 1-dimensional tool is possible [X, 0.0, 0.0]
Special functions
Function Manual, 12/2018, A5E40874099B AB
789
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
4. There are restrictions for the tool as far as 5-axis Scara kinematics are concerned:
-
4. Axis perpendicular to the 3rd axis: 1-dimensional tool is possible [X, 0.0, 0.0]
5. Two successive basic axes must be parallel or orthogonal.
6. The 4th axis must only be mounted in a parallel or orthogonal way to the last basic axis.
Configuration
The procedure for configuring a 5-axis kinematic is as follows:
1. Enter "Standard" kinematic category in machine data:
MD62600 $MC_TRAFO6_KINCLASS (kinematic category)
2. Set the number of axes for transformation in the machine data:
MD62605 $MC_TRAFO6_NUM_AXES = 5 (number of transformed axes)
3. Compare the basic axes with the basic axes contained in the handling transformation
package.
- Enter the basic axis identifier in machine data:
MD62603 $MC_TRAFO6_MAIN_AXES (basic axis identifier)
4. If the axis sequence is not the same as the normal axis sequence, it must be corrected in
machine data:
MD62620 $MC_TRAFO6_AXIS_SEQ (rearrangement of axes)
5. ID specification for the wrist axes. If axis 4 and 5 intersect, a central hand (ZEH) is present.
In all other cases, the ID for beveled hand with elbow (BHE) must be entered in the machine
data:
MD62604 $MC_TRAFO6_WRIST_AXES (wrist axis identifier)
6. Whether axis 4 runs parallel/anti-parallel to the last rotary basic axis must be entered into
the machine data:
MD62606 $MC_TRAFO6_A4PAR (axis 4 is parallel/anti-parallel to last basic axis)
7. Enter the axis types for the transformation in machine data:
MD62601 $MC_TRAFO6_AXES_TYPE (axis type for transformation)
8. Compare the directions of rotation of axes with the directions defined in the handling
transformation package and correct in machine data:
MD62618 $MC_TRAFO6_AXES_DIR (matching of physical and mathematical directions
of rotation)
9. Enter the mechanical zero offset in the machine data:
MD62617 $MC_TRAFO6_MAMES (offset between mathematical and mechanical zero
points)
10.Enter the basic axis lengths in machine data:
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB (basic axis lengths A and B)
11.Define frame T_IRO_RO and enter the offset in machine data:
MD62612 $MC_TRAFO6_TIRORO_POS (frame between base center point and internal
system (position component))
Define frame T_IRO_RO and enter the rotation in machine data:
MD62613 $MC_TRAFO6_TIRORO_RPY (frame between base center point and internal
system (rotation component))
Special functions
790
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
12.Specification of frame T_X3_P3 to attach hand. The offset is entered in machine data:
MD62608 $MC_TRAFO6_TX3P3_POS (attachment of hand (position component))
The rotation is entered in the machine data:
MD62609 $MC_TRAFO6_TX3P3_RPY (attachment of hand (rotation component))
13.Specification of wrist axes parameters. For this purpose, only the parameters for axis 4
must be entered in the machine data:
MD62614 $MC_TRAFO6_DHPAR4_5A[0] (parameter A for configuring the hand)
MD62616 $MC_TRAFO6_DHPAR4_5ALPHA[0] (parameter A for configuring the hand)
All other parameters must be set to 0.0.
14.Determine the flange coordinate system. For this purpose, the hand-point coordinate
system must be regard as the initial system. The offset is entered in the machine data:
MD62610 $MC_TRAFO6_TFLWP_POS (frame between wrist point and flange (position
component))
The rotation is entered in the machine data:
MD62611 $MC_TRAFO6_TFLWP_RPY (frame between wrist point and flange (rotation
component))
SCARA kinematics
5-axis CC kinematics
0'
&&
0'
0&B75$)2 B'+3$5 B $> @
0&B75$)2 B0$,
1B
0'
/(1*7+B$%> @
0'
0&B75$)2
B7)/:3B326> @
0&B75$)2 B7; 3 B
326> @
T
]
\
]
]
+3
)/
[
[+3
[)/
]:=
S
U
[:=
\+3
\)/
\,52
\:=
[,52
],52
0'
]52
0&B75$)2 B7,5252B326> @
\52
[52
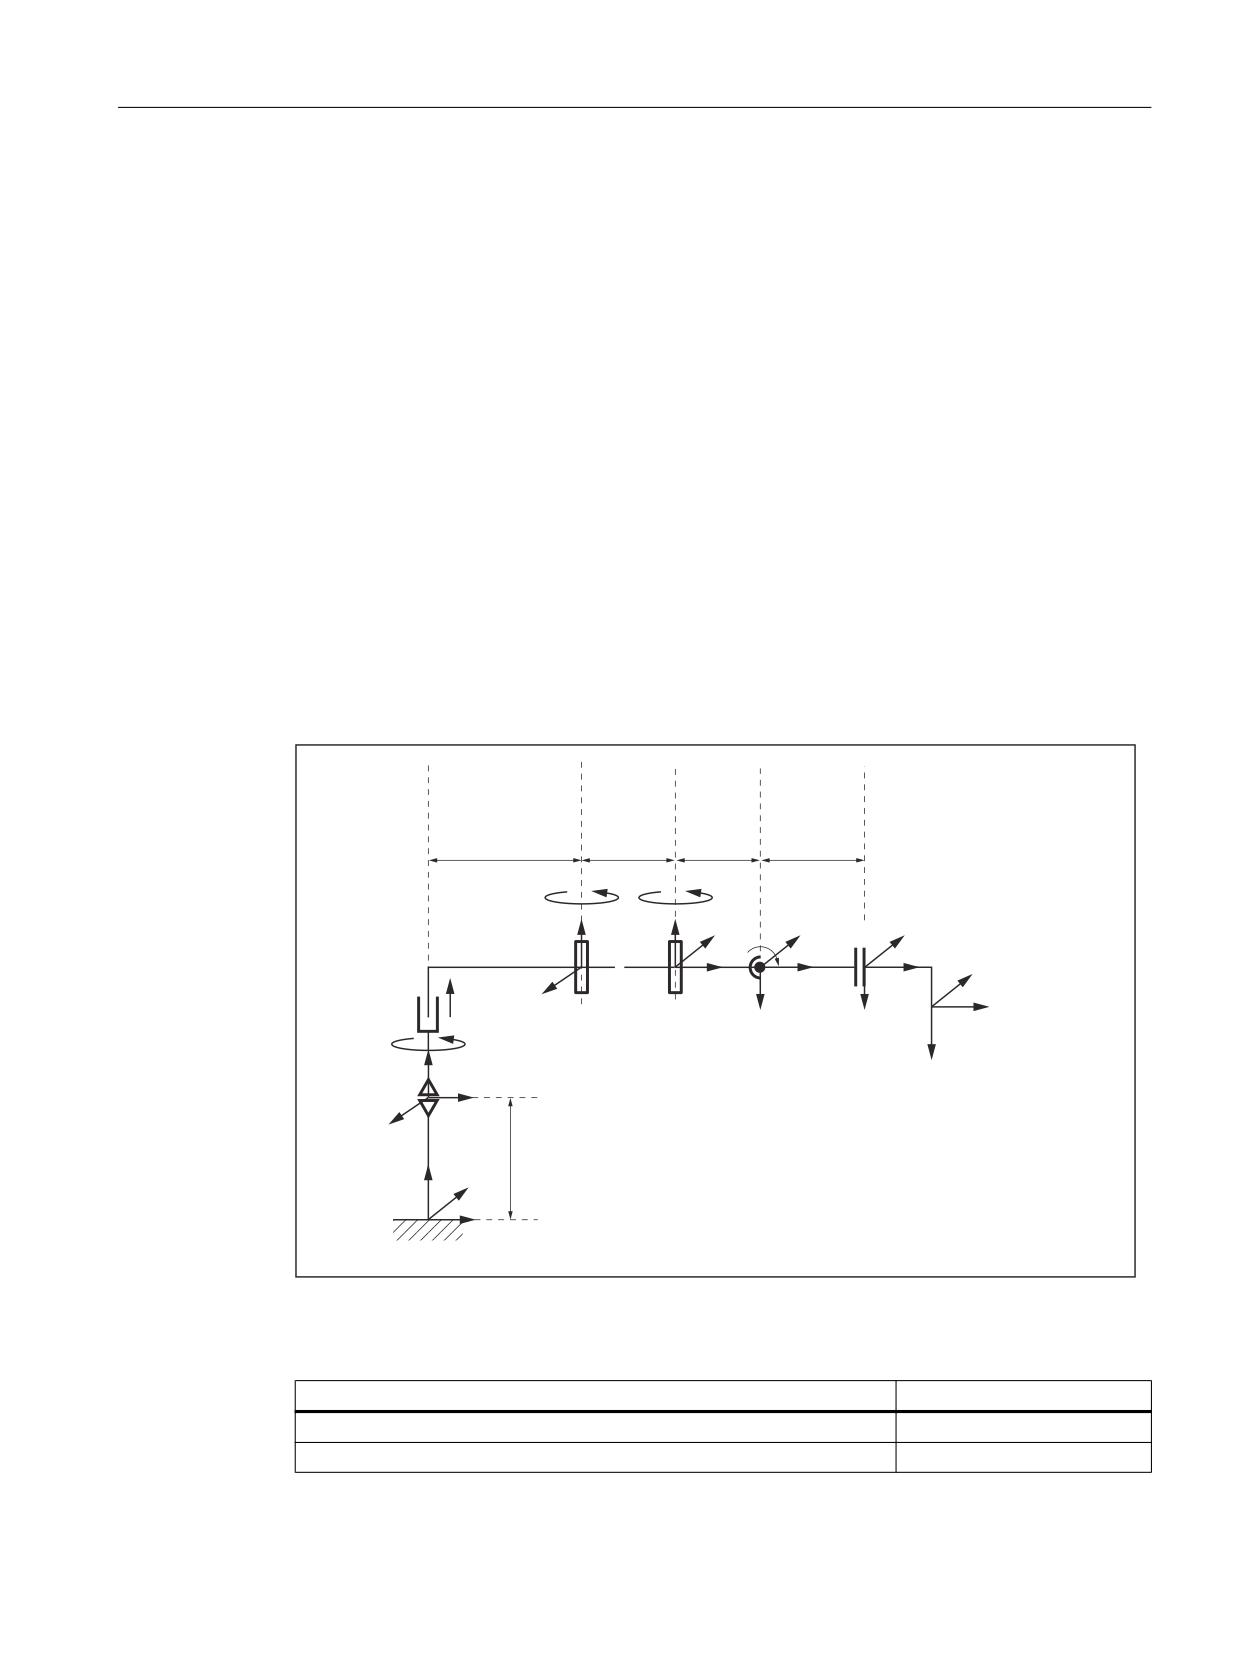
Figure 20-22
5-axis CC kinematics
Table 20-14 Configuration data for 5-axis CC kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
5
Special functions
Function Manual, 12/2018, A5E40874099B AB
791
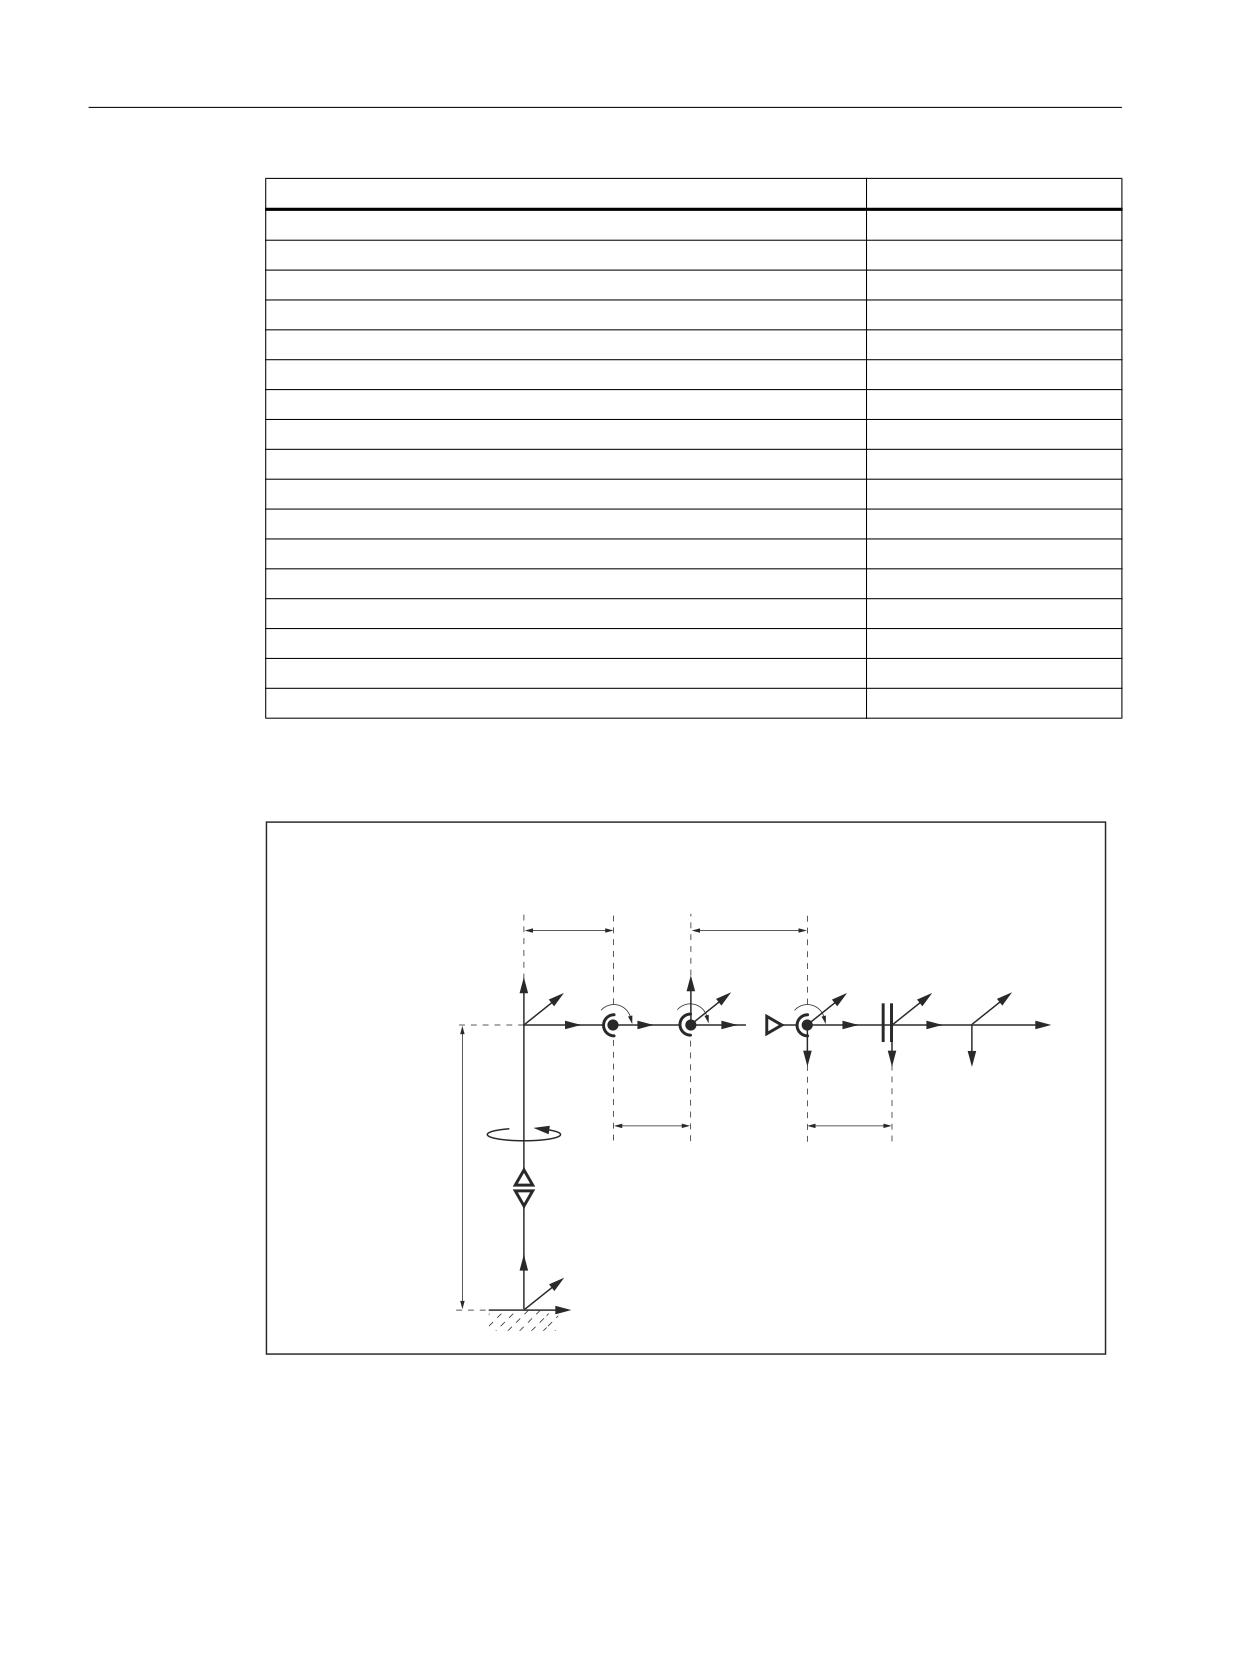
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Machine data
Value
MD62603 $MC_TRAFO6_MAIN_AXES
2
MD62604 $MC_TRAFO6_WRIST_AXES
5
MD62606 $MC_TRAFO6_A4PAR
1
MD62601 $MC_TRAFO6 _AXES_TYPE
[3, 1, 3, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[2, 1, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[0.0, 500.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 90.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[300.0, 0.0, -200.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, -90.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[200.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, 0.0]
MD62614 $MC_TRAFO6_DHPAR4_5A
[200.0, 0.0]
MD62615 $MC_TRAFO6_DHPAR4_5D
[0.0, 0.0]
MD62616 $MC_TRAFO6_DHPAR4_5ALPHA
[-90.0, 0.0]
5-axis NR kinematics
15
0'
0'
0&B75$)2 B0$,1B/(1*7+B$%> @
0&B75$)2 B7; 3 B326> @
]
U
,52
T
]+3
])/
]:=
\
,52
[:=
[,52
\+3
[)/
S
[+3
\)/
\
:=
0'
0'
0'
0&B75$)2 B0$,1B
0&B75$)2 B7)/:3B326> @
0&B75$)2 B
/(1*7+B$%> @
7,5252B326> @
]52
\52
[52
Figure 20-23
5-axis NR kinematics
Special functions
792
Function Manual, 12/2018, A5E40874099B AB
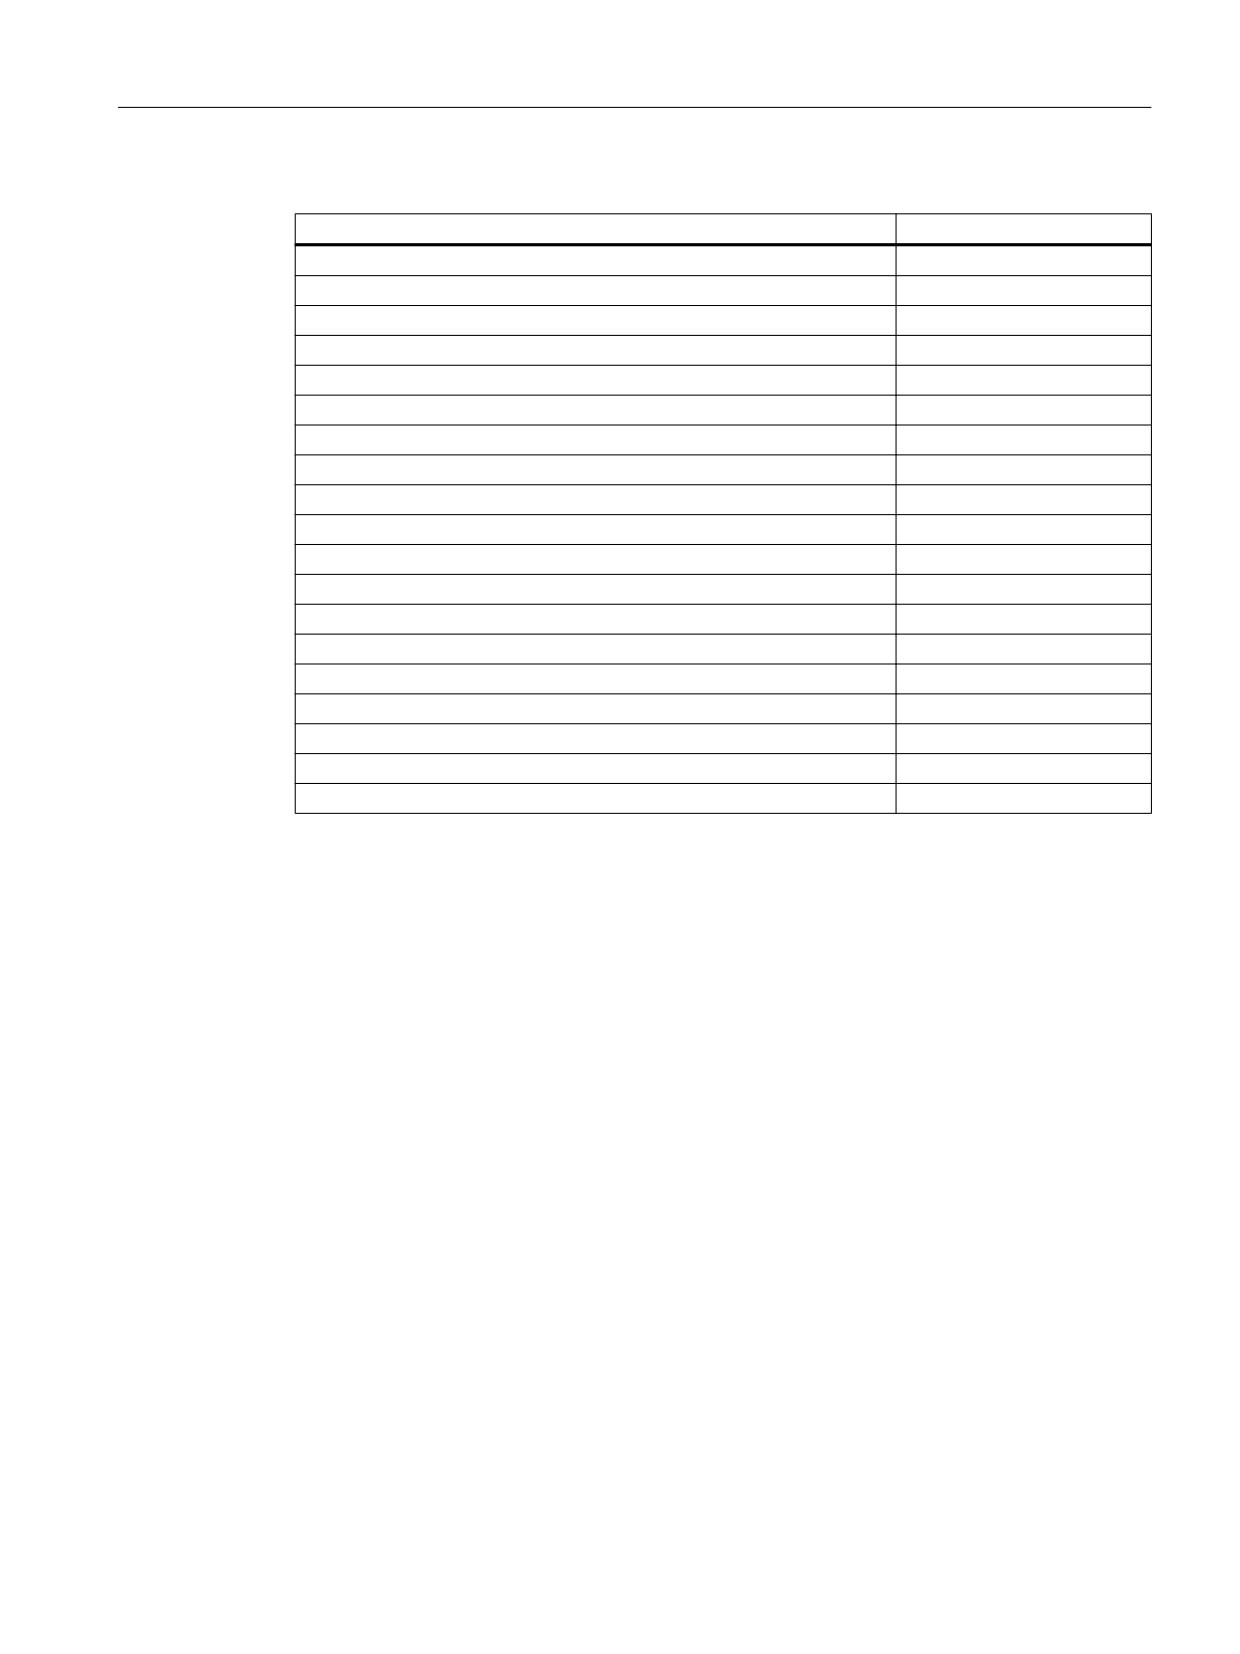
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Table 20-15 Configuration data 5-axis NR kinematic
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
1
MD62605 $MC_TRAFO6_NUM_AXES
5
MD62603 $MC_TRAFO6_MAIN_AXES
3
MD62604 $MC_TRAFO6_WRIST_AXES
2
MD62606 $MC_TRAFO6_A4PAR
0
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 3, 3, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[30.0, 300.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 500.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[500.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 90.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[0.0, -300.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[-90.0, 0.0, 0.0]
MD62614 $MC_TRAFO6_DHPAR4_5A
[0.0, 0.0]
MD62615 $MC_TRAFO6_DHPAR4_5D
[0.0, 0.0]
MD62616 $MC_TRAFO6_DHPAR4_5ALPHA
[-90.0, 0.0]
See also
Definition of a joint (Page 762)
20.5.4
6-axis kinematics
6-axis kinematics usually imply 3 degrees of freedom for translation and 3 more for orientation.
This allows for the tool direction to be manipulated freely in space. Also, the tool can be rotated
along its own axis to the machining surface or inclined with a tilting angle.
This kinematic type is supported by the software, but only for very specific solutions as the
auxiliary method for this handling transformation package. A general, comprehensive and
universally applicable software version is still not available for 6-axis kinematics.
Special functions
Function Manual, 12/2018, A5E40874099B AB
793
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
20.5.5
Special kinematics
MD62602 $MC_TRAFO6_SPECIAL_KIN (special kinematic type)
Special kinematics are kinematics that are not directly included in the building block system
of the Handling transformation package. They are frequently missing a degree of freedom or
are characterized by mechanical links between the axes or with the tool. Set the following
machine data for these kinematics:
MD62600 $MC_TRAFO6_KINCLASS = 2 (kinematic category)
Which special kinematic is handled is specified in machine data:
MD62602 $MC_TRAFO6_SPECIAL_KIN (special kinematic type)
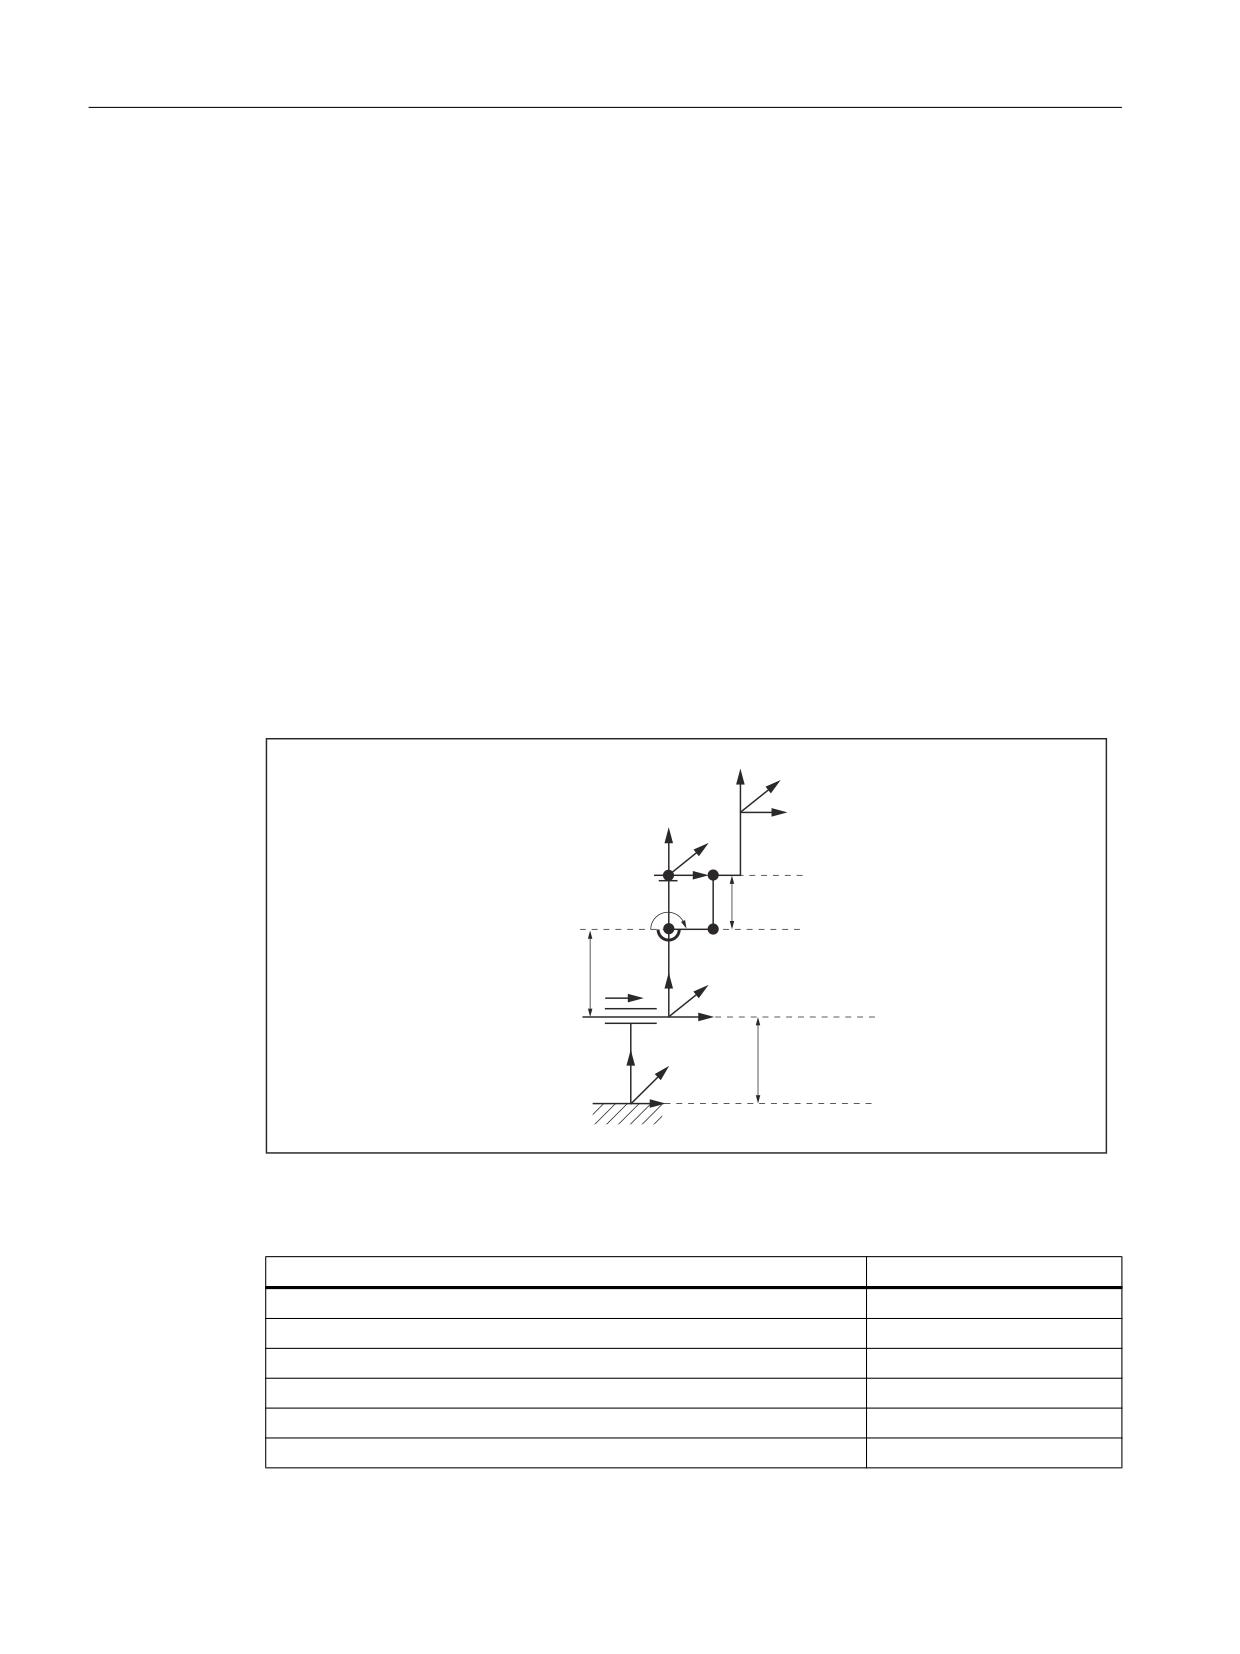
Special 2-axis SC kinematic
This special kinematic is characterized by the fact that the tool is always maintained in the
same orientation via a mechanical linkage. It implies two Cartesian degrees of protection. The
identifier for this kinematic is machine data:
MD62602 $MC_TARFO6_SPECIAL_KIN = 3 (special kinematic type)
[:=
]:=
\:=
[)/
])/
\)/
0'
0&B75$)2 B0$,1B/(1*7+B$%> @
0'
$
[
0&B75$)2 B0$,1B/(1*7+B$%> @
,52
]
,52
,52
\
$
[
52
0'
0&B75$)2 B7,5252B326> @
]52
\52
Figure 20-24
Special 2-axis SC kinematic
Table 20-16 Configuring data for a special 2-axis SC kinematic
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
2
MD62602 $MC_TRAFO6_SPECIAL_KIN
3
MD62605 $MC_TRAFO6_NUM_AXES
2
MD62603 $MC_TRAFO6_MAIN_AXES
2
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[1, 3, 3, ...]
Special functions
794
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Machine data
Value
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[400.0, 500.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 300.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[0.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[0.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, 0.0]
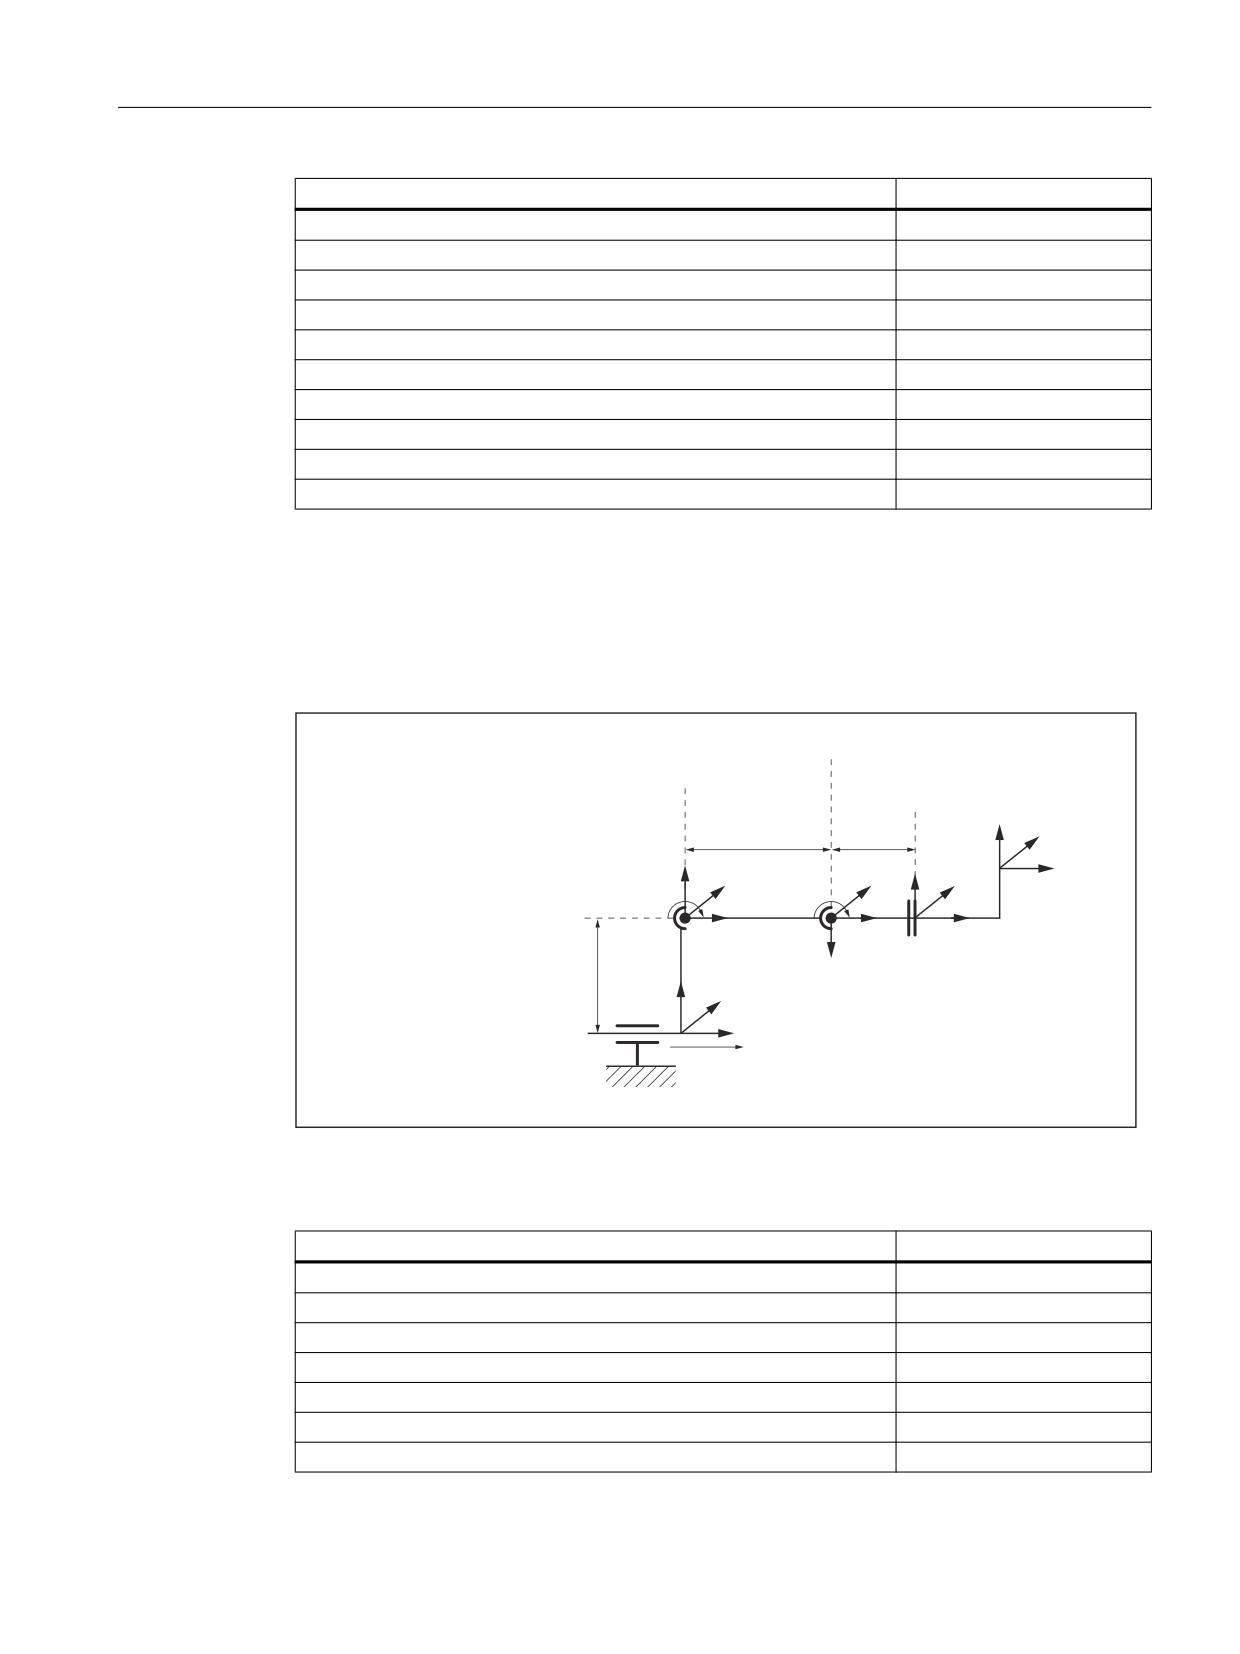
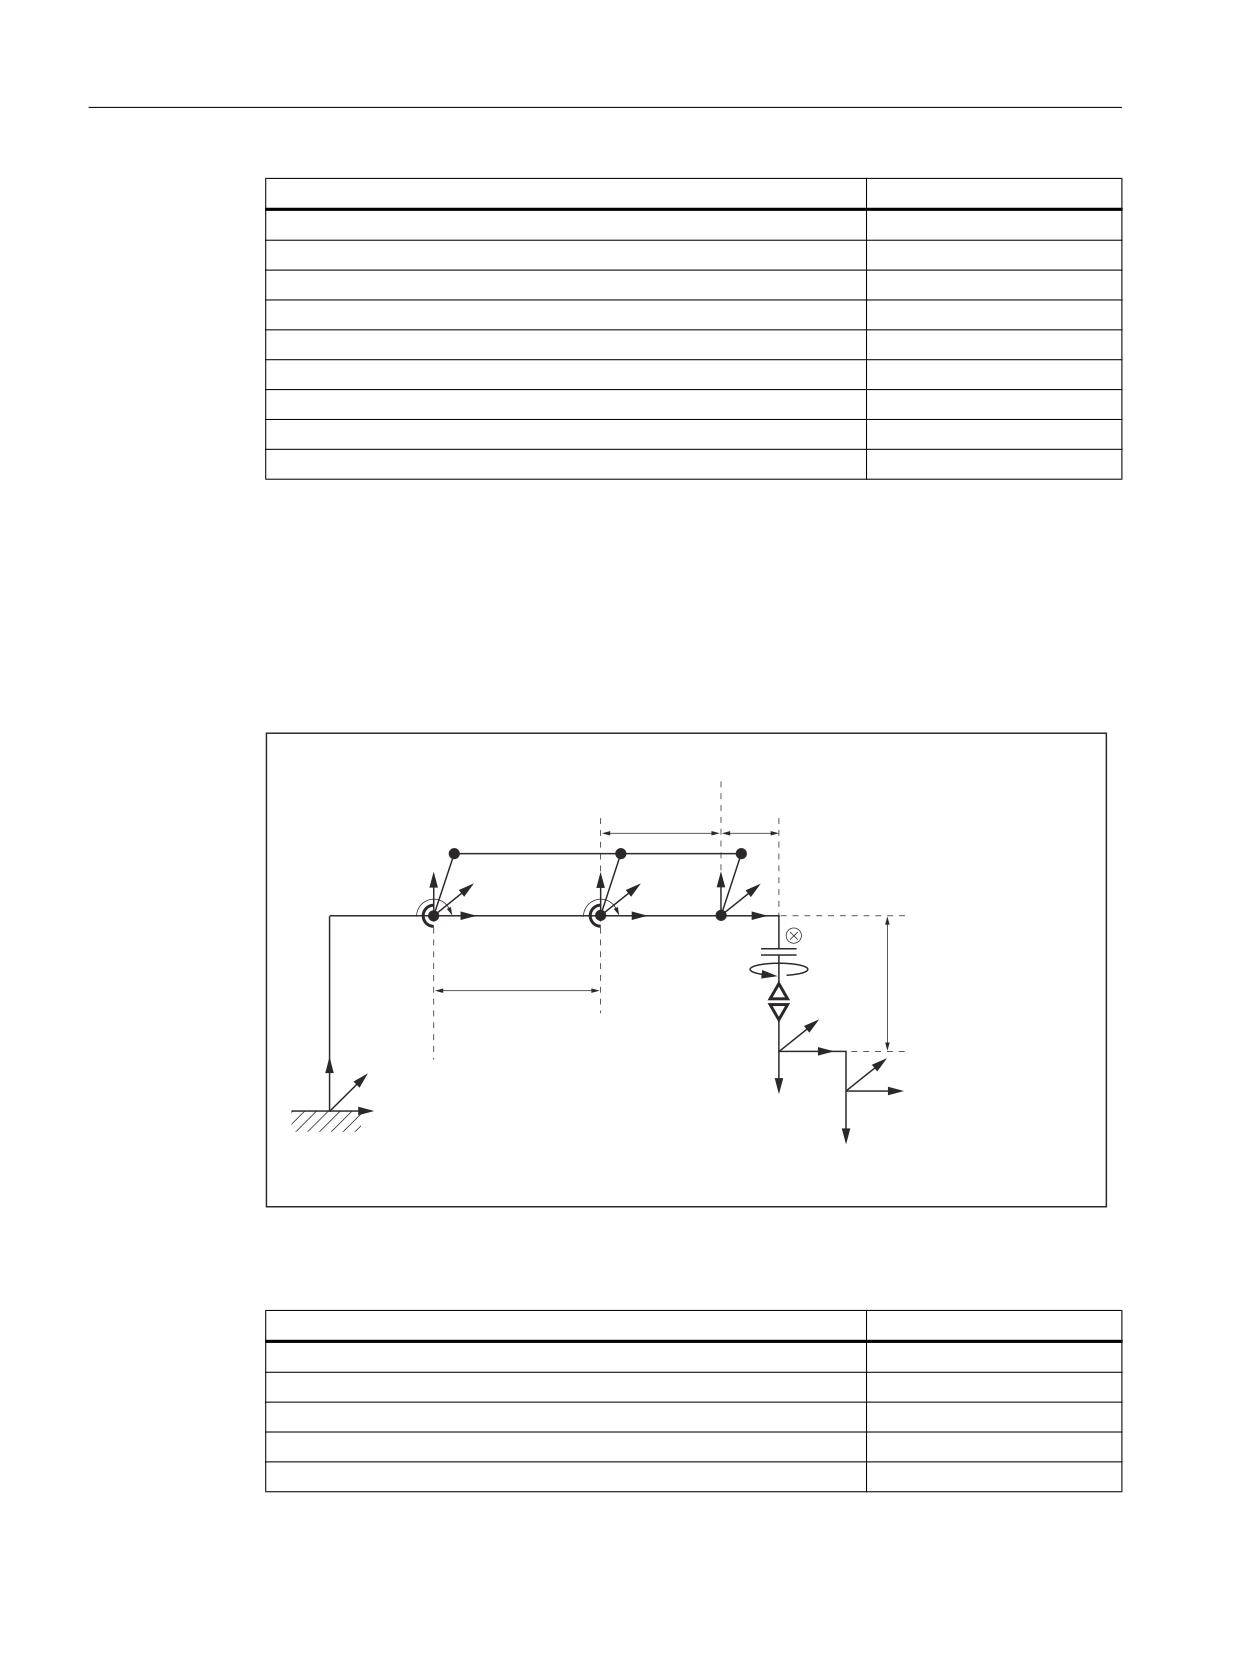
Special 3-axis SC kinematic
The special kinematic has 2 Cartesian degrees of freedom and one degree of freedom for
orientation. The identifier for this kinematic is:
MD62602 $MC_TRAFO6_SPECIAL_KIN = 4 (special kinematic type)
0'
0'
0&B75$)2 B7; 3 B326> @
0&B75$)2 B7)/:3B326> @
\:=
[:=
],52
\)/
\,52
]
[
]:=
)/
$
[
$
[
]
,52
)/
0'
0&B75$)2 B7,5252B326> @
\
]52
\52
[52
$
Figure 20-25
Special 3-axis SC kinematic
Table 20-17 Configuring data for a special 3-axis SC kinematic
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
2
MD62602 $MC_TRAFO6_SPECIAL_KIN
4
MD62605 $MC_TRAFO6_NUM_AXES
3
MD62603 $MC_TRAFO6_MAIN_AXES
2
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[1, 3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
Special functions
Function Manual, 12/2018, A5E40874099B AB
795
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Machine data
Value
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[0.0, 0.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[0.0, 0.0, 400.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[400.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, -90.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[200.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, -90.0, 180.0]
Special 4-axis SC kinematic
This special kinematic is characterized by the fact that axis 1 and axis 2 are mechanically
coupled. This coupling ensures that axis 2 is maintained at a constant angle when axis 1 is
swiveled. This kinematic also guarantees that axes 3 and 4 always remain perpendicular,
irrespective of the positions of axes 1 and 2. The identifier for this kinematic is:
MD62602 $MC_TRAFO6_SPECIAL_KIN = 7 (special kinematic type)
0'
0'
0&B75$)2 B7; 3 B326> @
0&B75$)2 B0$,1B/(1*7+B$%> @
],52
]
U
\
\
T
,52
[
S
[
,52
0'
0&B75$)2 B7)/:3B
0'
326> @
\)/
0&B75$)2 B0$,1B/(1*7+B$%> @
]52
\:=
\52
])/
]:=
[52
[)/
[:=
Figure 20-26
Special 4-axis SC kinematic
Table 20-18 Configuring data for a special 4-axis SC kinematic
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
2
MD62602 $MC_TRAFO6_SPECIAL_KIN
7
MD62605 $MC_TRAFO6_NUM_AXES
4
MD62603 $MC_TRAFO6_MAIN_AXES
2
MD62604 $MC_TRAFO6_WRIST_AXES
1
Special functions
796
Function Manual, 12/2018, A5E40874099B AB
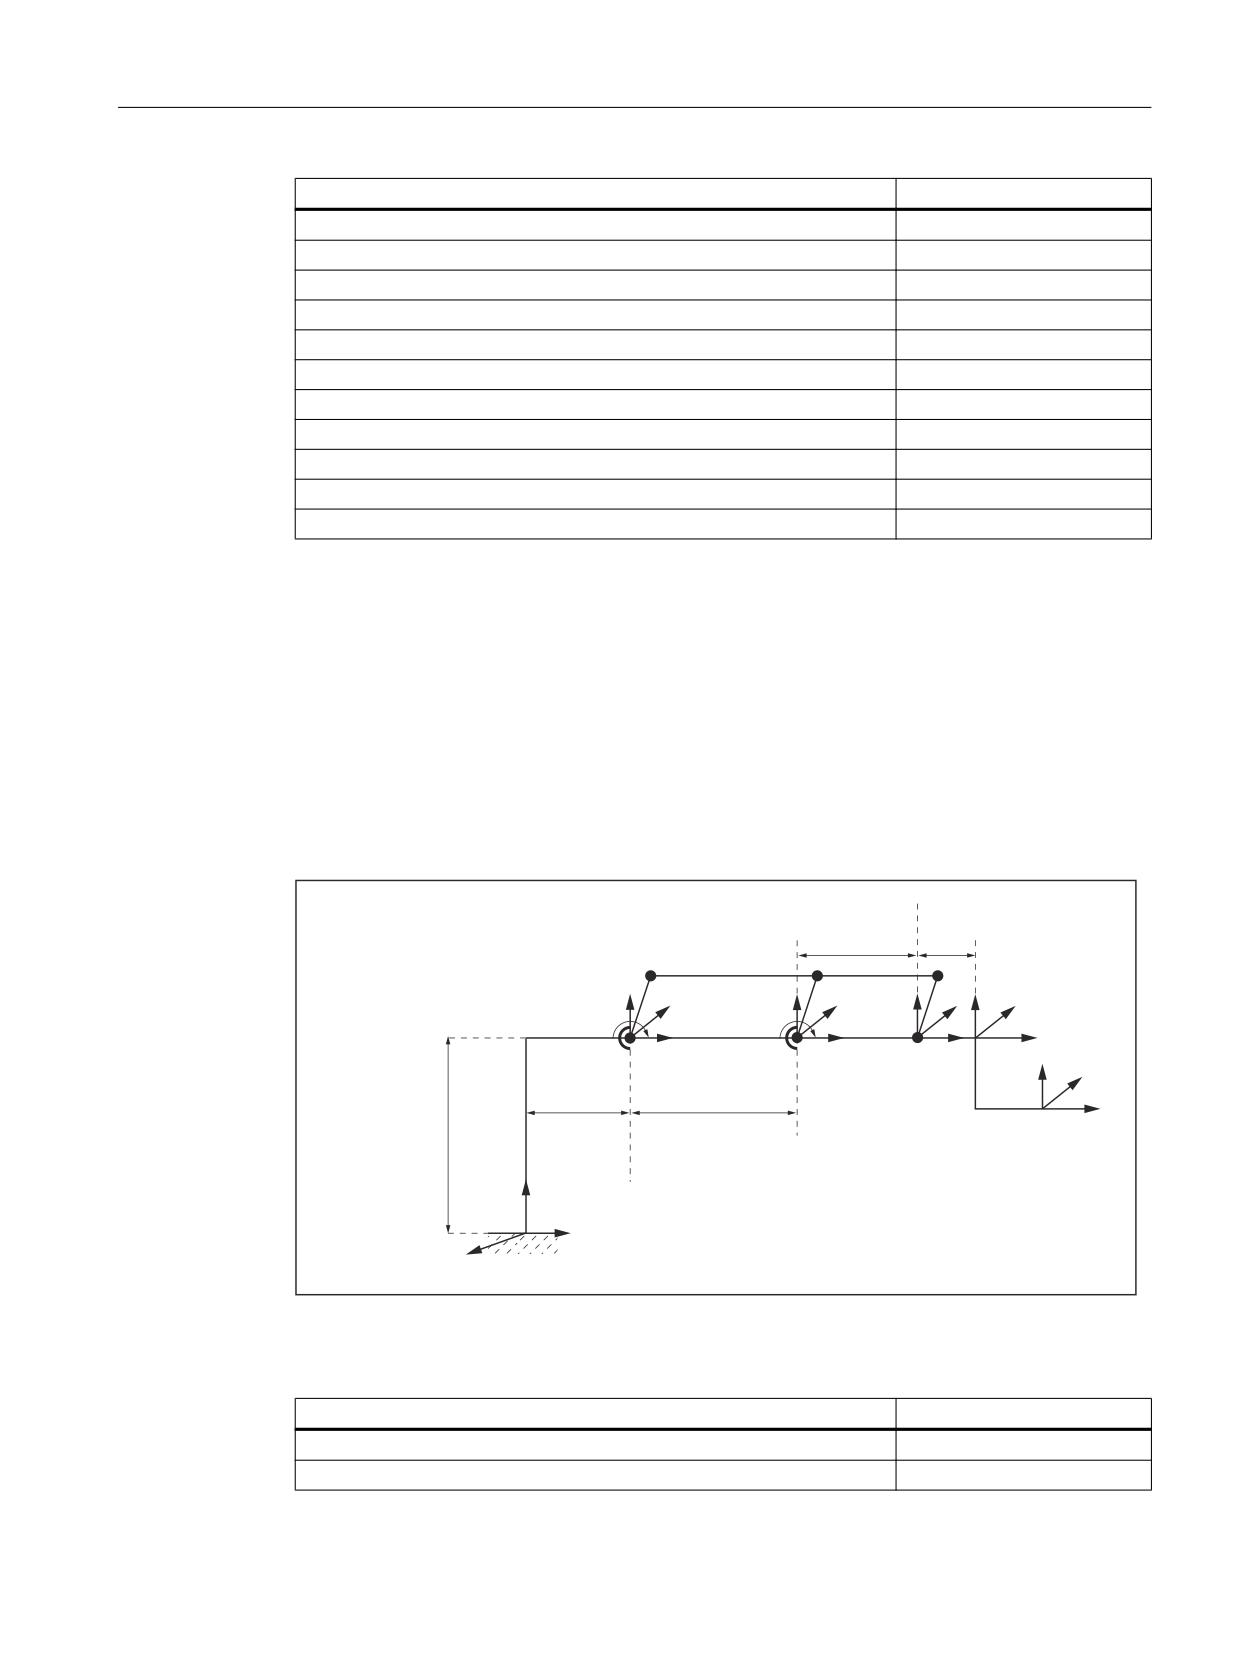
TE4: Handling transformation package - 840D sl only
20.5 Descriptions of kinematics
Machine data
Value
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 3, 1, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[100.0, 400.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[100.0, 0.0, 1000.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, 0.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[300.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[0.0, 0.0, -600.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 90.0, 0.0]
Special 2-axis NR kinematics
This special kinematic is characterized by the fact that axis 1 and axis 2 are mechanically
coupled. Another special feature is the tool. With this kinematic, it maintains its orientation in
space irrespective of the positions of the other axes.
The identifier for this kinematic is:
MD62602 $MC_TRAFO6_SPECIAL_KIN = 5 (special kinematic type)
Without a mechanical coupling between axis 1 and 2, it has the following identifier:
MD62602 $MC_TRAFO6_SPECIAL_KIN = 8 (special kinematic type)
0'
0'
0&B75$)2 B
0&B75$)2 B7; 3 B326> @
0$,1B/(1*7+B$%> @
],52
])/
U
\
]
\
\,52
T
)/
[)/
S
[
[
,52
]:=
\
:=
[:=
0'
0'
0&B75$)2 B
0&B75$)2 B0$,1B/(1*7+B$%> @
7,5252B326> @
0'
\52
0&B75$)2 B7,5252B326> @
[52
]52
Figure 20-27
Special 2-axis NR kinematics
Table 20-19 Configuration data for special 2-axis NR kinematics
Machine data
Value
MD62600 $MC_TRAFO6_KINCLASS
2
MD62602 $MC_TRAFO6_SPECIAL_KIN
5 (8)
Special functions
Function Manual, 12/2018, A5E40874099B AB
797
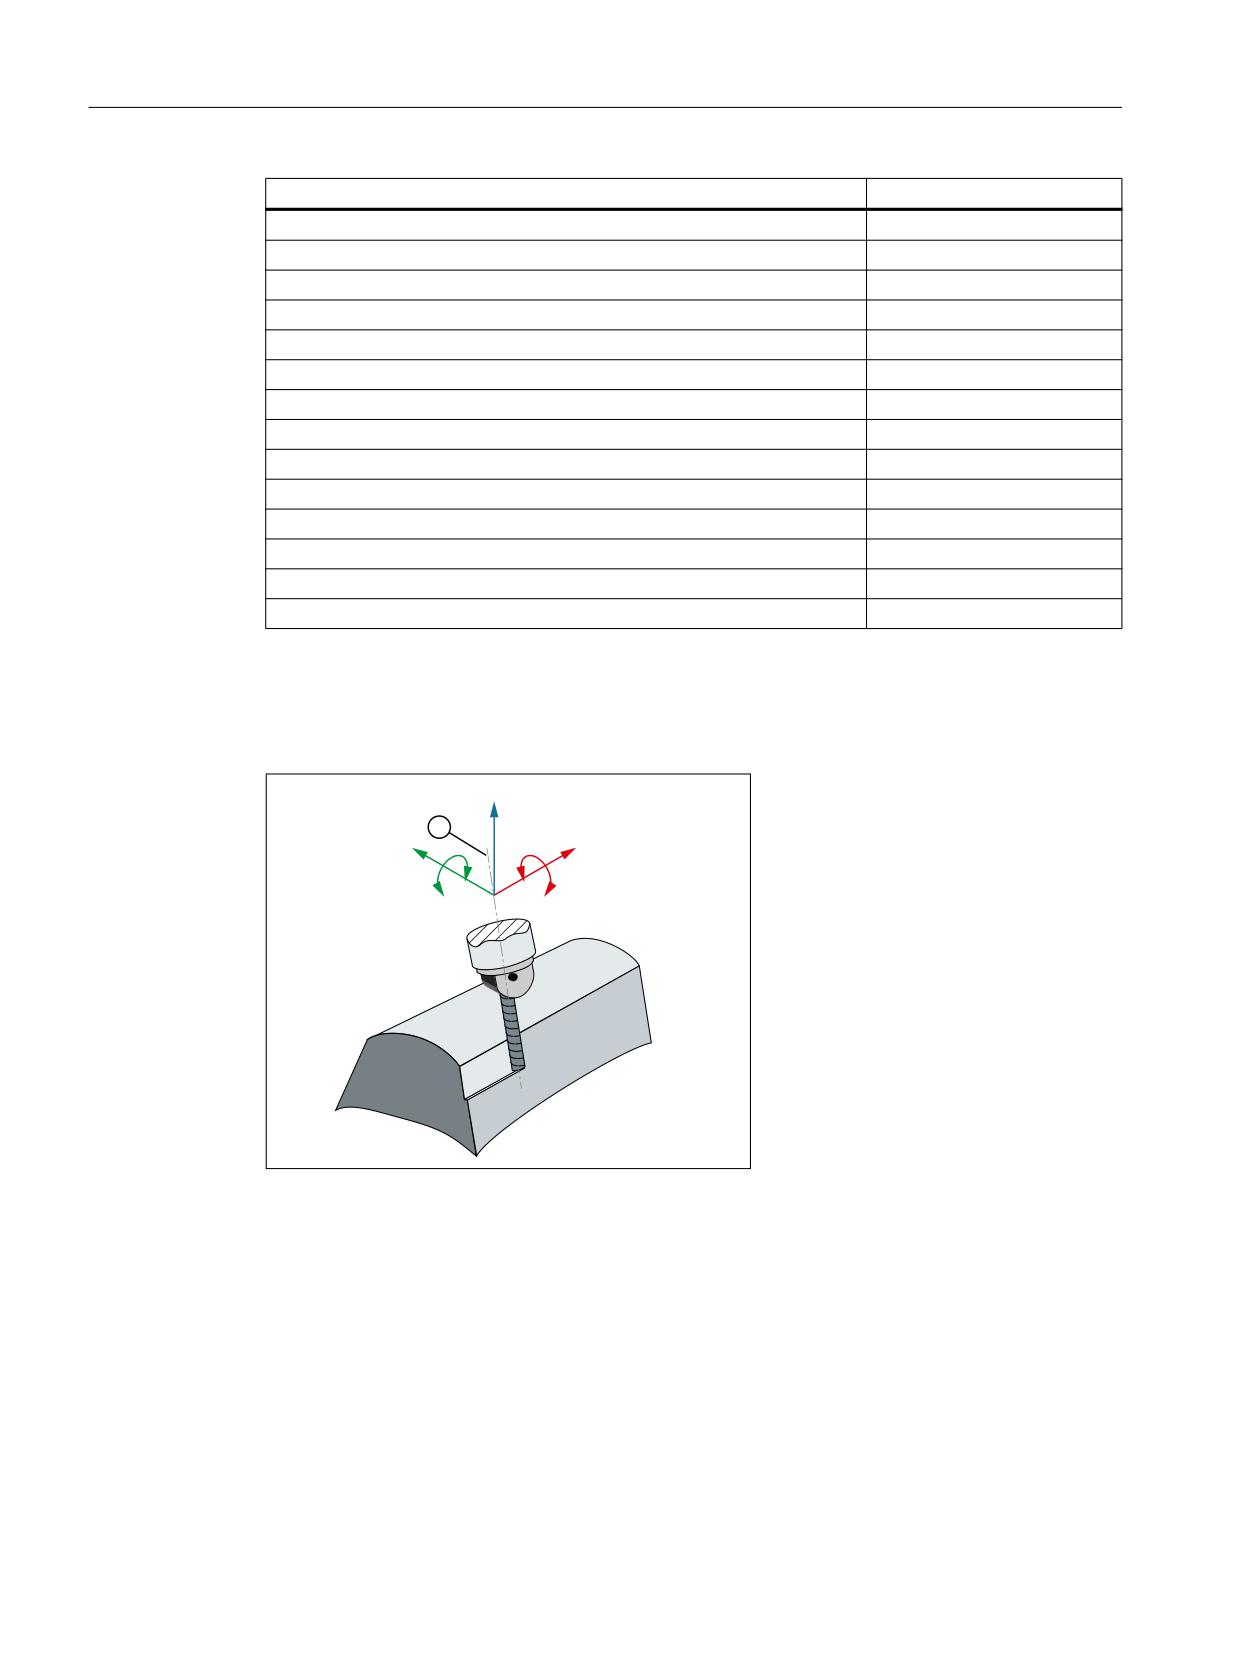
TE4: Handling transformation package - 840D sl only
20.6 Tool orientation
Machine data
Value
MD62605 $MC_TRAFO6_NUM_AXES
2
MD62603 $MC_TRAFO6_MAIN_AXES
3
MD62604 $MC_TRAFO6_WRIST_AXES
1
MD62601 $MC_TRAFO6_AXES_TYPE
[3, 3, ...]
MD62620 $MC_TRAFO6_AXIS_SEQ
[1, 2, 3, 4, 5, 6]
MD62618 $MC_TRAFO6_AXES_DIR
[1, 1, 1, 1, 1, 1]
MD62617 $MC_TRAFO6_MAMES
[0.0, 0.0, 0.0, 0.0, 0.0, 0.0]
MD62607 $MC_TRAFO6_MAIN_LENGTH_AB
[100.0, 400.0]
MD62612 $MC_TRAFO6_TIRORO_POS
[100.0, 500.0, 0.0]
MD62613 $MC_TRAFO6_TIRORO_RPY
[0.0, 0.0, -90.0]
MD62608 $MC_TRAFO6_TX3P3_POS
[400.0, 0.0, 0.0]
MD62609 $MC_TRAFO6_TX3P3_RPY
[0.0, 0.0, 0.0]
MD62610 $MC_TRAFO6_TFLWP_POS
[0.0, 0.0, 0.0]
MD62611 $MC_TRAFO6_TFLWP_RPY
[0.0, 0.0, 0.0]
20.6
Tool orientation
=
<
;
%
$
① Tool axis
Figure 20-28
Peripheral milling with 5-axis transformation
Machine data
Identifiers of the Euler angles
The identifiers with which the Euler angles are programmed in the NC program can be set
using:
MD10620 $MN_EULER_ANGLE_NAME_TAB (name of Euler angles)
Standard identifier: "A2", "B2", "C2"
Special functions
798
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.6 Tool orientation
Identifier of the direction vector components
The identifier with which the components of the direction vector are programmed in the NC
program can be set using:
MD10640 $MN_DIR_VECTOR_NAME_TAB (name of normal vectors)
The tool orientation can be located in any block. Above all, it can be programmed alone in a
block, resulting in a change of orientation in relation to the tool tip which is fixed in its
relationship to the workpiece.
Channel-specific input: Euler or RPY angle
Whether the tool orientation programming is realized in the channel with Euler angle or RPY
angle can be set using:
MD21100 $MC_ORIENTATION_IS_EULER (angle definition for orientation programming)
G command for orientation interpolation
The type of interpolation for the orientation is specified using machine data:
MD21104 $MC_ORI_IPO_WITH_G_CODE = <value>
<value>
Meaning
FALSE
G commands for orientation interpolation: ORIWKS and ORIMKS
TRUE
G commands of the 51st G group for orientation interpolation: ORIAXES, ORIVECT,
ORIPLANE, ...
Channel-specific initial setting for the tool orientation
G commands of the 25th G group: "Tool orientation reference" which takes effect after a
channel or end of program reset, can be set via:
MD20150 $MC_GCODE_RESET_VALUES[ 24 ] (25. G group: tool orientation reference)
Programming
Function
The tool orientation can be programmed via:
● Directly programming the rotary axes
● Programming the Euler or RPY angle
● Programming the direction vector
The coordinate system in which motion is executed is defined using the ORIWKS and
ORIMKS commands.
Syntax
ORIWKS
ORIMKS
Special functions
Function Manual, 12/2018, A5E40874099B AB
799

TE4: Handling transformation package - 840D sl only
20.6 Tool orientation
Meaning
ORIWKS:
Tool orientation in the workpiece coordinate system (WCS)
In the case of a change in orientation with the tool tip at a fixed point in space, the tool
moves along a large arc on the plane extending from the start vector to the end vector.
Transitioning a tool orientation at the start of a block to an orientation at the end of the
block is only possible in the WCS.
Effective:
Modal
ORIMKS:
Tool orientation in the machine coordinate system (MCS)
In the case of a change in orientation of a tool tip at a fixed point in space, linear
interpolation takes place between the rotary axis positions.
Effective:
Modal
Note
● ORIWKS is the preferred approach for a program independent of a particular machine.
● It is not possible to program the tool orientation using Euler angles, RPY angles or direction
vectors for kinematics involving fewer than 5 axes. For 4-axis kinematics with only one
rotary axis, there is only one degree of freedom for orientation. This orientation angle can
only be programmed with orientation axis angle "A".
● Transferring an orientation using ORIMKS is not allowed in the handling transformation
package. With an active transformation, the machine axis angles are not programmed and
traversed, but rather the "orientation angles" (RPY angles according to robotics definition,
see Section "Definition of positions and orientations using frames (Page 761)").
20.6.1
Orientation programming for 4-axis kinematics
4-axis kinematics possess only one degree of freedom for orientation. When programming
orientation using RPY angle, Euler angle or direction vector, it is not always possible to
approach the specified orientation. If at all, this type of orientation programming is only practical
for certain kinematics, where there is an invariance of the orientation angle with respect to the
basis axes. This is the case for the Scara kinematics, for example.
For this reason, orientation programming is only permitted via "orientation angle" A for 4-axis
kinematics. This angle corresponds to the RPY angle C of the robot definition. This means
one rotation around the ZRO axis, as illustrated in Fig. "Orientation angle for 4-axis kinematics".
Special functions
800
Function Manual, 12/2018, A5E40874099B AB
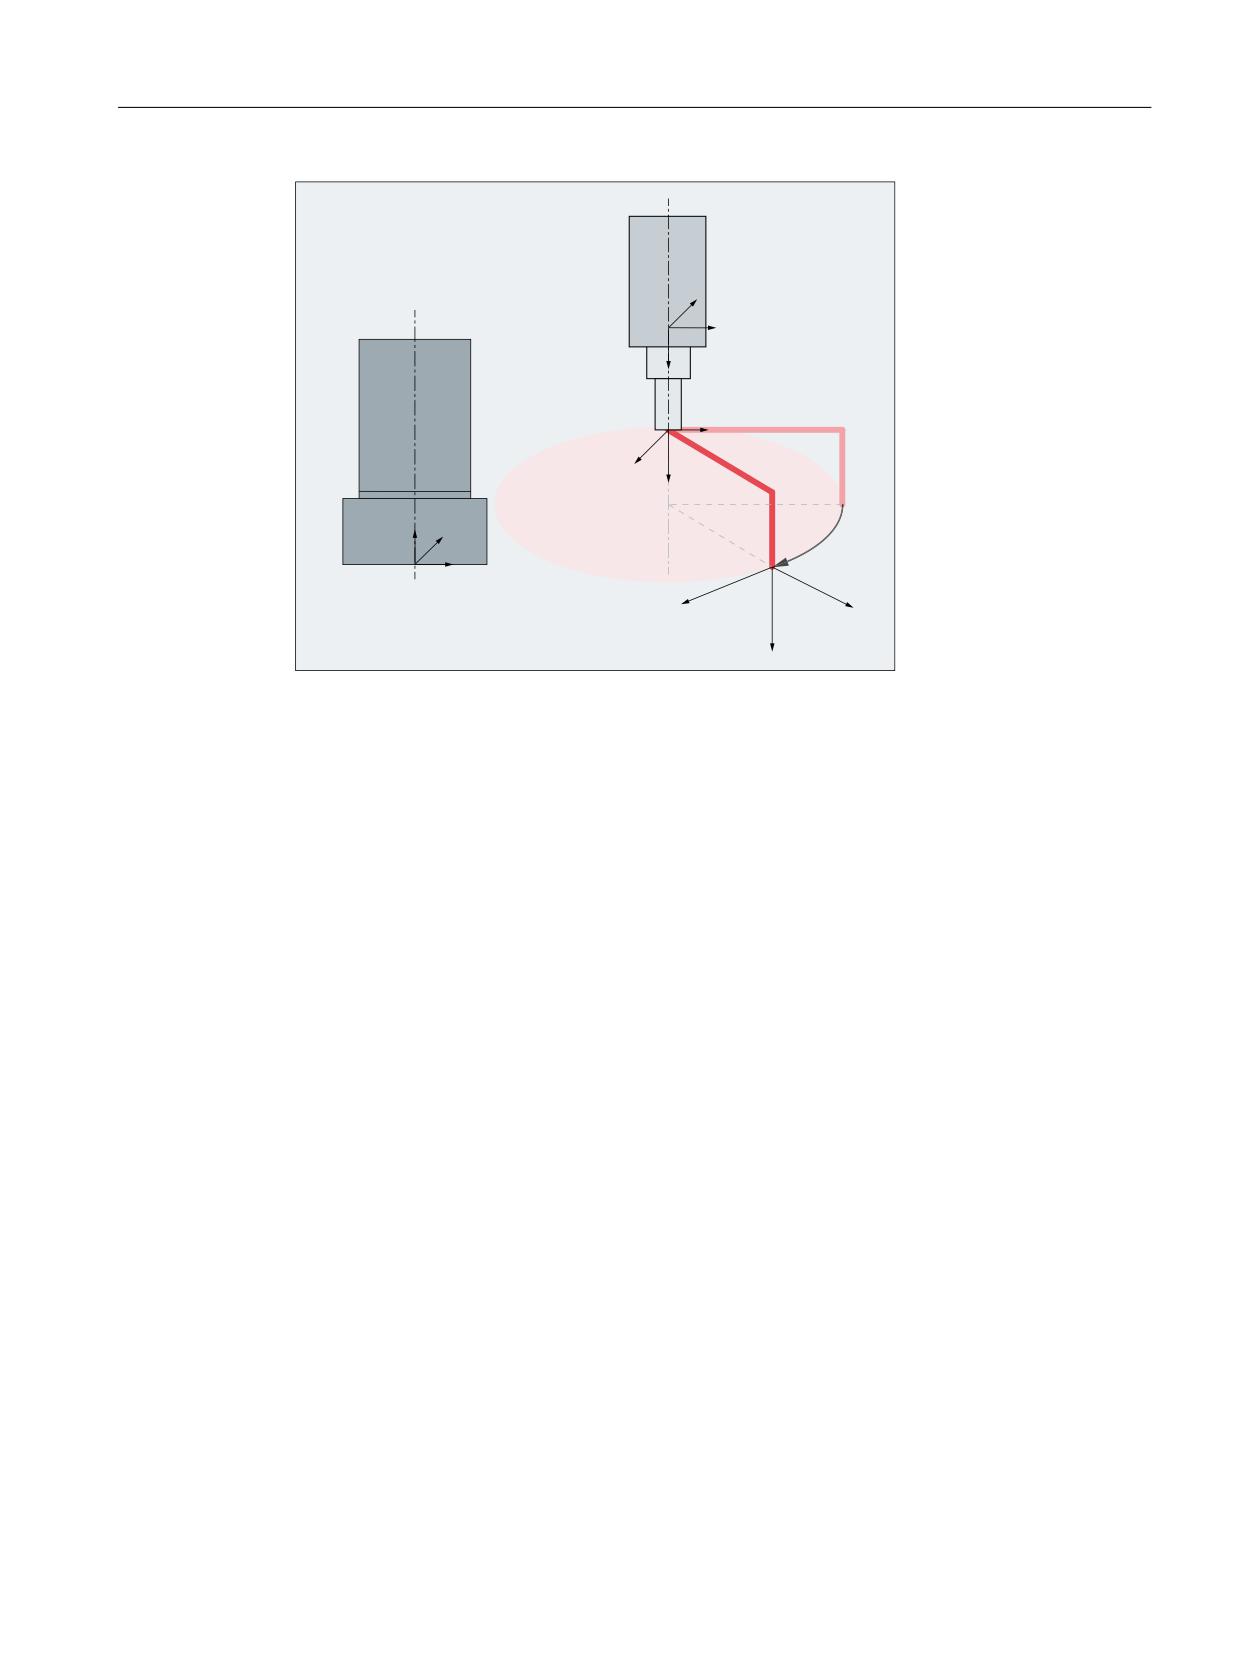
TE4: Handling transformation package - 840D sl only
20.6 Tool orientation
$
;+3
<+3
=+3
<)/
=)/
;)/
$
=52
$
<52
%.6
;
52
=:=
<:=
;:=
A
Virtual orientation angle
Figure 20-29
Orientation angle for 4-axis kinematics
Absolute calculation of the tool orientation for 4-axis kinematics
For 4-axis kinematics, the "virtual orientation angle" A is normally only defined within the range
-180° < A < = + 180°. This means that, in the transition from 180° to 181°, angle A jumps to
-179°. The following machine data must be set to avoid this step, and to ensure that angle A
is continually controlled:
MD62643 $MC_TRAFO6_SPECIAL_FEATURE_MASK, bit 0 = 1
As a consequence, for the following 4-axis kinematics, angle A is controlled in absolute terms:
● CC kinematics
● SC kinematics
● CS kinematics
This is on condition that the 4th axis is installed parallel to the last rotary basic axis (MD62606
$MC_TRAFO6_A4PAR == 1).
Angle A is calculated from the sum of the rotary axes. Machine data MD62617
$MC_TRAFO6_MAMES and MD62618 $MC_TRAFO6_AXES_DIR are taken into account.
If, as a result of the rotations via MD62612 $MC_TRAFO6_TIRORO_RPY and MD62611
$MC_TRAFO6_TFLWP_RPY, additional rotations are obtained, then these must be
compensated using MD62642 $MC_TRAFO6_C_ANGLE_OFFSET. In machine data
MD62642, the angle, which is displayed as "virtual orientation angle" A at the mathematical
zero position of the axes, must be entered with inverted sign.
Special functions
Function Manual, 12/2018, A5E40874099B AB
801
TE4: Handling transformation package - 840D sl only
20.6 Tool orientation
20.6.2
Orientation programming for 5-axis kinematics
For 5-axis kinematics, when programming via orientation vector, it is assumed that the
orientation vector corresponds to the x component of the tool.
When programming via orientation angle (RPY angle according to robotics definition), the x
component of the tool is considered the initial point for rotations.
For this purpose, the vector in the x tool direction, as shown in Fig. "Orientation angle for 5-
axis kinematic", is first rotated around the Z axis by the angle A and then around the rotated
Y axis by the angle B. The rotation by the angle C is not possible for 5-axis kinematics because
of the restricted degrees of freedom for the orientation.
]:=
])/
\)/
\:=
[)/
%
$
$
=52
<52
[:=
;52
%.6
Figure 20-30
Orientation angle for 5-axis kinematic
Adaptation of the flange coordinate system
This machine data is used to set the flange coordinate system on the user side so that Z can
be set as the tool direction for 5-axis kinematics:
MD62636 $MC_TRAFO6_TFL_EXT_RPY
Definition of the tool direction
In this machine data, set whether the tool direction will be calculated according to robotics
conventions or NC conventions:
MD62637 $MC_TRAFO6_TOOL_DIR
Standard definition of the tool direction
The tool calculation normally used with machine tools can be set with machine data:
MD62637 $MC_TRAFO6_TOOL_DIR = 1
This machine data also has an effect on the rotation sequence of the virtual orientation axes.
For this purpose, the vector in the Z tool direction is first turned through angle A at the X axis
Special functions
802
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.8 Call and application of the transformation
and then through angle B at the rotated Y axis. The rotation by the angle C is not possible for
5-axis kinematics because of the restricted degrees of freedom for the orientation.
Note
More information can be found in:
● Function Manual, Special Functions, Section "Orientation axes"
● Programming Manual, Job Planning; Section "Orientation axes".
20.7
Singular positions and how they are handled
The calculation of the machine axes to a preset position, i.e. position with orientation, is not
always clear. Depending on the machine kinematic, there may be positions with an infinite
number of solutions. These positions are called "singular".
Singular positions
● A singular position is, for example, characterized by the fact that the fifth axis is positioned
at 0°. In this case, the singular position does not depend on a specified orientation. The
fourth axis is not specified in this position, i.e., the fourth axis does not have any influence
on the position or the orientation.
● A singular position also applies for articulated arm and SCARA kinematics if the third axis
is at 0° or 180°. These positions are called leveling/diffraction singularity.
● Another singular position exists for articulated arm kinematics if the hand point is above
the rotary axis of axis 1. This position is called overhead singularity.
Extreme velocity increase
If the path runs in close vicinity to a pole (singularity), one or several axes may traverse at a
very high velocity. Alarm 10910 "Irregular velocity run in a path axis" is then triggered.
Behavior at pole
The unwanted behavior of fast compensating movements can be improved by reducing the
velocity in the proximity of a pole. Traveling through the pole with active transformation is
usually not possible.
20.8
Call and application of the transformation
Activating
The transformation is activated by means of the TRAORI(1) command.
Once the TRAORI(1) command has been executed and the transformation thus activated,
the interface signal switches to "1":
Special functions
Function Manual, 12/2018, A5E40874099B AB
803
TE4: Handling transformation package - 840D sl only
20.8 Call and application of the transformation
DB21, … DBX33.6 (transformation active)
If the machine data have not been defined for an activated transformation grouping, the NC
program stops and the control displays the alarm 14100 "Orientation transformation does not
exist".
For more information, go to:
References:
Programming Manual, Production Planning,
Section: "5-axis machining"
Deactivating
The currently active transformation is deactivated by means of TRAFOOF or TRAFOOF().
Note
When the "Handling transformation package" transformation is deactivated, no preprocessing
stop and no synchronization of the preprocessing with the main run is performed.
RESET/end of program
The control behavior in terms of transformation following run-up, end of program or RESET
depends on machine data:
MD20110 $MC_RESET_MODE_MASK (definition of control basic setting na)
Bit 7:
Reset behavior of "active kinematic transformation"
Bit 7 = 0
For this reason, the initial setting is defined for active transformation after the
end of part program or RESET, according to the following machine data:
MD20140 $MC_TRAFO_RESET_VALUE (transformation data block run-up (re-
set/part program end))
Meaning:
0:
After RESET no transformation is active.
1 to 8:
The set transformation is active according to machine data:
MD24100 $MC_TRAFO_TYPE_1 (definition of transformation 1 in
the channel)
To machine data:
MD24460 $MC_TRAFO_TYPE_8 (channel transformation 8)
Bit 7 = 1
The current setting for the active transformation remains unchanged after a
RESET or end of part program.
Special functions
804
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.10 Tool programming
20.9
Actual value display
MCS machine coordinate system
The machine axes are displayed in mm/inch and/or degrees in MCS display mode.
WCS workpiece coordinate system
If the transformation is active, the tool tip (TCP) is specified in mm/inch and the orientation by
the RPY angles A, B and C in WCS display mode. The tool orientation results from turning a
vector in the Z direction firstly with A around the Z axis, then with B around the new Y axis and
lastly with C around the new X axis.
If the transformation is deactivated, the axes will be displayed with the channel axis names.
Otherwise the geometry axis names will be displayed.
20.10
Tool programming
Meaning
The tool lengths are specified in relation to the flange coordinate system. Only 3-dimensional
tool compensation is possible. Depending on which kinematic is involved, additional
restrictions for the tool exist for 5- and 4-axis kinematics. For a kinematic as illustrated in Fig.
"5-axis NR kinematic", only a 1-dimensional tool with length in the x direction is permitted.
The tool direction is dependent on the machine's initial setting, as specified with G commands
G17, G18 and G19. The tool lengths refer to the zero position specified by G17. These should
not be changed in the program.
Example
An example of a 2-dimensional tool mounted on a 5-axis Scara is described below (see Fig.
"5-axis CC kinematic"). Type 100 (cutting tool) should be specified as identification for the tool.
The tool lengths result from the specifications shown in Fig. "Tool length programming". X-
TOOL must be entered as tool length x and Y-TOOL must be entered as tool length y in the
tool parameters.
$TC_DP1[1,1 ] = 100 ;
Cutting tool type
$TC_DP3[1,1 ] = 0.0 ;
(z) length compensation vector
$TC_DP4[1,1 ] = Y-TOOL ;
(y) length compensation vector
$TC_DP5[1,1 ] = X-TOOL ;
(x) length compensation vector
Special functions
Function Manual, 12/2018, A5E40874099B AB
805
TE4: Handling transformation package - 840D sl only
20.12 Startup
; 722/
]+3
])/
[+3
[)/
]:=
< 722/
\+3
\
)/
$
$
[:=
\:=
Figure 20-31
Tool length programming
20.11
Cartesian PTP travel with handling transformation package
It is possible to use the "Cartesian PTP travel" function with the handling transformation
package (see Section "Cartesian PTP travel (Page 42)"). For this, the following machine data
must be set:
MD24100 $MC_TRAFO_TYPE_1 = 4100 (definition of transformation 1 in the channel)
20.12
Startup
20.12.1
General commissioning
The handling transformation package is a compile cycle.
The general commissioning of a compile cycle is described in Chapter "TE01: Installation and
activation of loadable compile cycles (Page 673)".
20.12.2
Function-specific commissioning
Option
The "Handling transformation package" function is an option for which a license must be
purchased:
● Transformation Handling RCTRA, Order No.: 6FC5800-0AM31-0YB0
Special functions
806
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.12 Startup
A detailed description of licensing, for instance the assignment between a license and
hardware, is provided in:
References
Commissioning Manual, CNC Commissioning: NC, PLC, Drive
Section: "Licensing"
User-specific alarm texts
To create user-specific alarm texts in conjunction with compile cycles, see Chapter "Creating
alarm texts (Page 679)"
Parameterizing transformation
1.
Enter the transformation type into the machine data:
- MD24100 $MC_TRAFO_TYPE_1 = 4100 (definition of transformation 1 in the channel)
2.
Enter the assignment of the channel axes involved in the transformation in the machine
data (axis numbers, starting at 1):
- MD24110 $MC_TRAFO_AXES_IN_1[0 ... 5] (axis assignment for transformation)
3.
Enter the geometry axes corresponding to the Cartesian degrees of freedom of the machine
in the machine data:
- MD24120 $MC_TRAFO_GEOAX_ASSIGN_TAB_1[0 ... 2] (assignment between
geometry axis and channel axis for transformation 1)
4.
Enter the kinematic identifier in the machine data:
- MD62600 $MC_TRAFO6_KINCLASS (kinematic category)
5.
Enter the identifier for special kinematics, if there are any, in machine data:
- MD62602 $MC_TRAFO6_SPECIAL_KIN (special kinematic type)
6.
Enter the number of axes in the machine data:
- MD62605 $MC_TRAFO6_NUM_AXES (number of transformed axes)
7.
If the travel direction of the involved axes is opposed to the transformation definition, then
change the factory setting in the machine data:
- MD62618 $MC_TRAFO6_AXES_DIR[ ] (matching of physical and mathematical
directions of rotation)
8.
Enter the data which define the basic axes:
- MD62603 $MC_TRAFO6_MAIN_AXES (basic axis identifier)
- MD62607 $MC_TRAFO6_MAIN_LENGTH_AB (basic axis lengths A and B)
9.
Enter any changes to the axis sequence in the machine data:
- MD62620 $MC_TRAFO6_AXIS_SEQ (rearrangement of axes)
Special functions
Function Manual, 12/2018, A5E40874099B AB
807
TE4: Handling transformation package - 840D sl only
20.13 Supplementary conditions
10.Enter the data which define the wrist axis:
- MD62604 $MC_TRAFO6_WRIST_AXES (wrist axis identifier)
- MD62614 $MC_TRAFO6_DHPAR4_5A (parameter A for configuring the wrist axis)
- MD62615 $MC_TRAFO6_DHPAR4_5D (parameter D for configuring the wrist axis)
- MD62616 $MC_TRAFO6_DHPAR4_5ALPHA (parameter ALPHA for configuring the
wrist axis)
- MD62606 $MC_TRAFO6_A4PAR (axis 4 is parallel/anti-parallel to last basic axis)
11.Enter the geometry parameters:
- Frame T_IRO_RO
- Frame T_X3_P3
- Frame T_FL_WP
12.Enter the position in relation to the calibration point in the machine data:
- MD62617 $MC_TRAFO6_MAMES (offset between mathematical and mechanical zero
points)
13.Enter the Cartesian velocities and acceleration rates.
20.13
Supplementary conditions
Clearance control
The handling transformation package cannot be used together with the technology function:
"clearance control".
Moving to fixed end stop
The handling transformation package cannotbe used in conjunction with the "Travel to fixed
stop".
Several transformations
The handling transformation package can be activated just once per channel in all channels.
Tool programming
Tools can only be parameterized by specifying tool lengths. It is not possible to program an
orientation for the tool.
Special functions
808
Function Manual, 12/2018, A5E40874099B AB
TE4: Handling transformation package - 840D sl only
20.14 Data lists
Programming of orientation
The programming possibilities of the orientation depend on the number of axes available on
the machine:
● Number < 5:
- Orientation axis angle
● Number = 5:
- Orientation axis angle
- Orientation vector
Singularities
A pole cannot be directly passed through when a transformation is active.
NOTICE
Traversing close to the pole
When traversing close to the pole, the axes involved can be overloaded. This is because the
control does not automatically reduce or limit the feedrate, acceleration or jerk. As a
consequence, the user is responsible in limiting the feedrate of the axes involved and/or the
clearance to the pole.
20.14
Data lists
20.14.1
Machine data
20.14.1.1
General machine data
Number
Identifier: $MN_
Description
10620
EULER_ANGLE_NAME_TAB[n]
Name of Euler angle
19410
TRAFO_TYPE_MASK, bit 4
Option data for OEM transformation
60943
CC_ACTIVE_IN_CHAN_RCTR
Activation of the handling transformation for the corre-
sponding channels
19610
TECHNO_EXTENSION_MASK
Option data for handling transformation
Special functions
Function Manual, 12/2018, A5E40874099B AB
809

TE4: Handling transformation package - 840D sl only
20.14 Data lists
20.14.1.2
Channelspecific machine data
Number
Identifier: $MC_
Description
21100
ORIENTATION_IS_EULER
Angle definition for orientation programming
21110
X_AXIS_IN_OLD_X_Z_PLANE
Coordinate system with automatic FRAME definition
24100
TRAFO_TYPE_1
Definition of transformation
24110
TRAFO_AXES_IN_1
Axis assignment for transformation 1
24120
TRAFO_GEOAX_ASSIGN_TAB_1
Assignment of geometry axes to channel axes
20.14.1.3
Channel-specific machine data for compile cycles
Number
Identifier: $MC_
Description
62600
TRAFO6_KINCLASS
Kinematic category
62601
TRAFO6_AXES_TYPE
Axis type for transformation
62602
TRAFO6_SPECIAL_KIN
Special kinematic type
62603
TRAFO6_MAIN_AXES
Basic axis identifier
62604
TRAFO6_WRIST_AXES
Wrist axis identifier
62605
TRAFO6_NUM_AXES
Number of transformed axes
62606
TRAFO6_A4PAR
Axis 4 is parallel/anti-parallel to last basic axis
62607
TRAFO6_MAIN_LENGTH_AB
Basic axis lengths A and B
62608
TRAFO6_TX3P3_POS
Attachment of hand (position component)
62609
TRAFO6_TX3P3_RPY
Attachment of hand (rotation component)
62610
TRAFO6_TFLWP_POS
Frame between wrist point and flange (position compo-
nent)
62611
TRAFO6_TFLWP_RPY
Frame between wrist point and flange (rotation compo-
nent)
62612
TRAFO6_TIRORO_POS
Frame between base center point and internal system
(position component)
62613
TRAFO6_TIRORO_RPY
Frame between base center point and internal system
(rotation component)
62614
TRAFO6_DHPAR4_5A
Parameter A for configuring the hand
62615
TRAFO6_DHPAR4_5D
Parameter D for configuring the hand
62616
TRAFO6_DHPAR4_5ALPHA
Parameter ALPHA for configuring the hand
62617
TRAFO6_MAMES
Offset between mathematical and mechanical zero
points
62618
TRAFO6_AXES_DIR
Matching of physical and mathematical directions of ro-
tation
62619
TRAFO6_DIS_WRP
Mean distance between wrist point and singularity (not
used)
62620
TRAFO6_AXIS_SEQ
Rearrangement of axes
62621
TRAFO6_SPIN_ON
Configuration includes triangular or trapezoidal spin-
dles
62622
TRAFO6_SPIND_AXIS
Axis that is controlled by triangular spindle
Special functions
810
Function Manual, 12/2018, A5E40874099B AB

TE4: Handling transformation package - 840D sl only
20.14 Data lists
Number
Identifier: $MC_
Description
62623
TRAFO6_SPINDLE_RAD_G
Radius G for triangular spindle
62624
TRAFO6_SPINDLE_RAD_H
Radius H for triangular spindle
62625
TRAFO6_SPINDLE_SIGN
Sign for triangular spindle
62626
TRAFO6_SPINDLE_BETA
Angular offset for triangular spindle
62627
TRAFO6_TRP_SPIND_AXIS
Axes driven via trapezoidal connection
62628
TRAFO6_TRP_SPIND_LEN
Trapezoid lengths
62629
TRAFO6_VELCP
Cartesian velocities (substitute limit values for the ve-
locity controller)
62630
TRAFO6_ACCCP
Cartesian accelerations (substitute limit values for the
velocity controller)
62631
TRAFO6_VELORI
Orientation angle velocities (substitute limit values for
the velocity controller)
62632
TRAFO6_ACCORI
Orientation angle accelerations (substitute limit values
for the velocity controller)
62634
TRAFO6_DYN_LIM_REDUCE
Reduction factor for velocity controller during the JOG
travel
62635
TRAFO6_VEL_FILTER_TIME
Time constant for PT1 filter when the velocity controller
is active
62636
TRAFO6_TFL_EXT_RPY
Adaptation of the flange coordinate system
62637
TRAFO6_TOOL_DIR
Definition of the tool direction
62642
TRAFO6_C_ANGLE_OFFSET
Offset angle for C angle calculation in the BCS
62643
SPECIAL_FEATURE_MASK
Function mask
20.14.2
Signals
20.14.2.1
Signals to channel
Signal name
SINUMERIK 840D sl
SINUMERIK 828D
Activate PTP traversing
DB21, … .DBX29.4
-
20.14.2.2
Signals from channel
Signal name
SINUMERIK 840D sl
SINUMERIK 828D
Transformation active
DB21,
DBX33.6
DB330x.DBX1.6
Number of the active G commands of the G group 25 (OR- DB21,
DBB232
-
IWKS, ORIMKS, ORIPATH)
PTP traversing active
DB21, … .DBX317.6
-
Special functions
Function Manual, 12/2018, A5E40874099B AB
811
TE4: Handling transformation package - 840D sl only
20.14 Data lists
Special functions
812
Function Manual, 12/2018, A5E40874099B AB
TE6: MCS coupling - 840D sl only
21
21.1
Brief description
If there are two or more separately traversable machining heads on a machine tool and a
transformation is required for machining, the orientation axes of the machining heads cannot
be coupled via the standard coupling functions COUPON, TRAILON. The couplings are
established in the workpiece coordinate system (WCS). However, under the conditions
mentioned above the coupling of the orientation axes must be performed in the machine
coordinate system (MCS).
The compile cycle "MCS coupling" can be used to parameterize couplings in the machine
coordinate system (MCS) with coupling factors "1" and "-1" for a master axis, referred to as
CC_Master in the following, and several slave axes, referred to as CC_Slave in the following.
The couplings can be switched on and off via commands in the part program.
0DFKLQLQJ KHDG
0DFKLQLQJ KHDG
<
<
=
=
$
$
:
:
;
&
8
&
Figure 21-1
Application example: Double slide gantry-type milling machine
Master and slave axes
A CC_Master can be master for several CC_Slaves. A CC_Slave cannot be a CC_Master at
the same time.
The following functions are not possible for a CC_Slave:
● To be a PLC axis
● To be a command axis
● To be traversed separately from the CC_Master in JOG mode
Special functions
Function Manual, 12/2018, A5E40874099B AB
813
TE6: MCS coupling - 840D sl only
21.2 Description of MCS coupling functions
Tolerance window
When the coupling is active, the actual values of the CC_Master and CC_Slave are monitored
for compliance with a parameterizable tolerance window.
Programming a CC-Slave
If a CC_Slave is programmed in a channel, either an alarm is displayed or the axis is requested
for the channel via an implicitly triggered axis interchange (GET), depending on the setting in
machine data:
MD30552 $MA_AUTO_GET_TYPE = <GET type> (automatic GET for axis)
Switching the coupling on/off
A coupling is switched on and off via OEM-specific language commands and can be active in
all operating modes.
Collision protection
In order to protect the machining heads against collision in decoupled operation or in mirrored
coupling, a collision protection can be parameterized. The activation is performed via machine
data or the NC/PLC interface. The assignment of the protected pairs is not dependent on the
CC_Master and CC_Slave pairs.
21.2
Description of MCS coupling functions
21.2.1
Defining coupling pairs
A CC_SLAVE axis is matched to its CC_Master axis via the following axial machine data:
MD63540 $MA_CC_MASTER_AXIS (specifies the CC_Master axis assigned to a CC_Slave
axis)
The axes involved in the coupling can only be changed when the coupling is not active (open).
A CC_Slave axis is displayed in axial VDI-Out byte:
DB31, ... DBX97.0 (MCS coupling: slave axis)
Precondition
● The CC_Master and CC_Slave axes must be either both rotary axes or both linear axes.
● Spindles cannot be coupled by this function.
● Neither CC_Master nor CC_Slave axis are permitted to be a interchanged axis
($MA_MASTER_CHAN[AXn]=0)
Special functions
814
Function Manual, 12/2018, A5E40874099B AB
TE6: MCS coupling - 840D sl only
21.2 Description of MCS coupling functions
21.2.2
Switching the coupling ON/OFF
Activating the coupling
● Activating the 1:1 coupling. Monitoring of the tolerance window is active.
CC_COPON([<axis1>][<axis2>][<axis3>][<axis4>][<axis5>])
● Activating the 1:-1 coupling (mirror). Monitoring of the tolerance window is not active.
CC_COPONM([<axis1>][<axis2>][<axis3>][<axis4>][<axis5>])
Axis name
An axis can be specified via:
● Machine axis name
● Channel axis name
● Geometry axis name
Boundary conditions
● A programmed axis must be involved in a coupling.
● CC_Master axes, CC_Slave axes or both can be programmed simultaneously. All defined
couplings are switched on with CC_COPON or CC_COPONM.
● An alarm is output if an axis not involved in a coupling is programmed.
NC/PLC interface signals
All NC/PLC interface signals of a coupling refer to the CC_Slave axes.
● DB31, … DBX97.1 (MCS coupling: coupling active)
● DB31, ... DBX97.2 (MCS coupling: mirroring active)
● DB31, …DBX24.2 (MCS coupling: deactivate or do not permit)
If the coupling is suppressed, an alarm is not output for the CC_Slave axis.
Deactivating the coupling
CC_COPOFF([<axis1>][<axis2>][<axis3>][<axis4>][<axis5>])
As for switching on the coupling with the difference that no alarm is output if an axis is
programmed that is not involved in a coupling.
An existing coupling can also be switched off by the axial NC/PLC interface signal of the
CC_Slave axis.
Boundary condition
A coupling can only be switched on or off when the axes are at standstill.
Special functions
Function Manual, 12/2018, A5E40874099B AB
815
TE6: MCS coupling - 840D sl only
21.3 Description of collision protection
21.2.3
Tolerance window
A monitoring window is specified via axial machine data:
MD63541 $MA_CC_POSITION_TOL (monitoring window)
The absolute difference between the actual values of CC_Slave axis and CC_Master axis must
never be greater than this value. Alarm 70010 is output if values are exceeded.
Monitoring is not active
● if the machine data is set to 0,
● if the coupling is switched off (open),
● if 'axis/spindle inhibit' is set for one of the axes,
● if an axis is in the 'follow-up mode',
● for the 1:-1 coupling.
If the offset stored at the instant of coupling activation changes when 1:1 coupling is active,
the change is indicated at the NC => PLC VDI-SS:
DB31, ... DBX97.3 (MCS coupling: offset change)
Note
The offset can change.
● if the SW limit monitor was active for one axis during the main run,
● if one axis has been switched to follow-up mode,
● if collision protection was active for one axis.
21.2.4
Memory configuration: Block memory
The technological function requires additional data in the NC-internal block memory. The
values must be increased for the following memory configuring channel-specific machine data:
● MD28090 $MC_MM_NUM_CC_BLOCK_ELEMENTS += 1 (number of block elements for
compile cycles)
● MD28100 $MN_MM_NUM_CC_BLOCK_USER_MEM += 1 (size of block memory for
compile cycles (DRAM) in KB)
21.3
Description of collision protection
21.3.1
Defining protection pairs
A ProtecSlave axis (PSlave) is matched to its ProtecMaster (PMaster) axis via the following
axial machine data:
Special functions
816
Function Manual, 12/2018, A5E40874099B AB
TE6: MCS coupling - 840D sl only
21.3 Description of collision protection
MD63542 $MA_CC_PROTECT_MASTER (specifies the PMaster axis assigned to a PSlave
axis)
The protection pairs can thus be defined independently of the coupling pairs. A PSlave axis
may act as the PMaster axis for another axis. The axes must be either both rotary axes or both
linear axes.
21.3.2
Switching collision protection ON / OFF
The minimum clearance between PSlave and PMaster is provided in the axial machine data
of the PSlave axis:
MD63544 $MA_CC_COLLISION_WIN (collision protection window)
No collision protection is implemented if the value entered here is less than 0. The 0 position
offset between PSlave and PMaster is provided in the axial machine data (PSlave axis):
MD63545 $MA_CC_OFFSET_MASTER (zero point offset between PSlave and PMaster)
Before the collision protection is switched on, the monitoring function for each individual axis
must be enabled in the following machine data:
MD63543 $MA_CC_PROTECT_OPTIONS
In the same machine data for the PSlave axis, a setting is entered to specify whether the
collision protection must be active continuously or whether it is activated via VDI interface
signal (PLC => NC):
DB31, … DBX24.3
If collision protection is active, the setpoint positions of the PSlave and PMaster in the next
IPO cycle are extrapolated and monitored in the IPO clock cycle using the current setpoint
position and current velocity.
If the axes violate the minimum clearance, they are braked at the configured maximum
acceleration rate:
MD32300 $MA_MAX_AX_ACCEL (Axis acceleration)
Or at a 20% faster acceleration rate, defined in machine data:
MD63543 $MA_CC_PROTECT_OPTIONS
An alarm is output as soon as the axes reach zero speed.
WARNING
Risk of collision when starting
If the axes are forced to brake, the positions displayed in the workpiece coordinate system
are incorrect!
These are not re-synchronized again until a system RESET.
If the axes are already violating the minimum clearance when collision protection is activated,
they can only be traversed in one direction (retraction direction). The retraction direction is
configured in machine data:
MD63543 $MA_CC_PROTECT_OPTIONS
Special functions
Function Manual, 12/2018, A5E40874099B AB
817
TE6: MCS coupling - 840D sl only
21.3 Description of collision protection
The collision protection status is optionally displayed in axial VDI-Out byte of the PSlave:
DB31, ... DBX66.0 (MCS coupling: collision protection active)
● DB31, … DBX66.0=1 → collision protection active
● DB31, … DBX66.0=0 → collision protection inactive
This output is activated via Bit7 in machine data of the PSlave axis:
MD63543 $MA_CC_PROTECT_OPTIONS
21.3.3
Configuring example
&&B&2//,6,21B:,1>36ODYH@
&&B3527(&7B237,216>30DVWHU@ ELW
30DVWHU
36ODYH
&&B3527(&7B237,216>36ODYH@ ELW
&&B2))6(7B0$67(5>36ODYH@
Figure 21-2
Configuring example
Note
Since the collision protection function extrapolates the target positions from the "current
velocity + maximum acceleration (or +20%)", the monitoring alarm may be activated
unexpectedly at reduced acceleration rates:
Example:
PMaster = X, PSlave = X2, $MA_CC_COLLISION_WIN = 10mm
Starting point in part program: X=0.0 X2=20.0
N50 G0 X100 X2=90
; the monitoring alarm is activated because X and X2 are interpolating together: for this reason,
the acceleration rate of X2 < maximum acceleration.
Remedy:
● N50 G0 POS[X]=100 POS[X2]=90
● or switch the monitoring function off.
Special functions
818
Function Manual, 12/2018, A5E40874099B AB
TE6: MCS coupling - 840D sl only
21.5 Special operating states
21.4
User-specific configurations
Parking the machining head
In this context, "parking" means that the relevant machining head is not involved in workpiece
machining. All of the axes are in closed-loop position control and are at an exact stop.
The coupling should be active, even if only one machining head is being used for production!
This is essential primarily if only the second head (Y2
) is being for machining. "Axis/spindle
inhibit" must then be set axially (PLC -> NC) for the "parked" head.
Note
When an axis/spindle inhibit is active, a part program can be executed if this axis is not
operating under position control.
Spindle functionalities
Since an MCS coupling cannot be activated for spindles, other types of solutions should be
configured for these.
● Positioning the spindle (SPOS= ...)
Instead, a cycle is called from SPOS. SPOS is called for all active spindles in this cycle.
● Speed setpoint
Speed and direction of rotation setpoints can be detected via synchronized actions or PLC
and transferred to all other active spindles.
● Synchronous spindle function
21.5
Special operating states
Reset
The couplings can remain active after a RESET.
Reorg
No non-standard functionalities.
Block search
During a block search, the last block containing an OEM-specific language command is always
stored and then output with the last action block. This feature is illustrated in the following
examples. The output positions of the axes are always 0.
Example 1:
N01 M3 S1000
Special functions
Function Manual, 12/2018, A5E40874099B AB
819
TE6: MCS coupling - 840D sl only
21.6 Boundary conditions
N02 G01 F1000 X10 Y10
N03 CC_COPON( X, Y)
TARGET:
If this program is started normally, axes X and Z traverse to X10 Z10 in the decoupled state.
After block search to TARGET: axes X and Y traverse to this position in the coupled state!
Example 2:
N01 M3 S1000
N02 CC_COPON( X)
N03 G01 F1000 X100 Y50
N04 CC_COPOFF( X)
N05 CC_COPON( Y)
N06 Y100
N10 CC_COPOFF()
TARGET:
After block search to TARGET: the axes traverse to X100 Y100 in the decoupled state.
Example 3:
N01 CC_COPON( X, Y, Z)
N02
N10 CC_COPOFF( Z)
TARGET:
After block search to TARGET: no coupling is active!
Single block
There are no nonstandard functionalities.
21.6
Boundary conditions
Validity
The function is configured only for the first channel.
Braking behavior
Braking behavior at the SW limit with path axes
The programmable acceleration factor ACC for braking at the SW limit corresponds to the path
axes.
Special functions
820
Function Manual, 12/2018, A5E40874099B AB
TE6: MCS coupling - 840D sl only
21.7 Data lists
The axes in an MCS coupling are principal axes that are referred to as geometry axes due to
their geometric arrangement.
Braking geometry axes using synchronized actions
The faster deceleration capacity as required for path axes can be implemented for geometry
axes as follows using a synchronized action:
ACC[x2]=190
Axial acceleration limitation with G0
The following machine data is not considered by the MCS coupling:
MD32434 $MA_G00_ACCEL_FACTOR (scaling of the acceleration limitation with G0)
A value deviating from the standard value affects the braking ramp up to the software limit
switch.
21.7
Data lists
21.7.1
Machine data
21.7.1.1
Channelspecific machine data
Number
Identifier: $MC_
Description
28090
NUM_CC_BLOCK_ELEMENTS
Number of block elements for compile cycles.
28100
NUM_CC_BLOCK_USER_MEM
Total size of usable block memory for compile cycles
21.7.1.2
Axis/spindlespecific machine data
Number
Identifier: $MA_
Description
63540
CC_MASTER_AXIS
Specifies the CC_Master axis assigned to a CC_Slave
axis.
63541
CC_POSITION_TOL
Monitoring window
63542
CC_PROTEC_MASTER
Specifies the PMaster axis assigned to a PSlave axis.
63543
CC_PROTEC_OPTIONS
63544
CC_COLLISION_WIN
Collision protection window
63545
CC_OFFSET_MASTER
Zero point offset between PSlave and PMaster
Special functions
Function Manual, 12/2018, A5E40874099B AB
821

TE6: MCS coupling - 840D sl only
21.7 Data lists
21.7.2
Signals
21.7.2.1
Signals to axis/spindle
Signal name
SINUMERIK 840D sl
SINUMERIK 828D
MCS coupling: deactivate or do not permit
DB31, …DBX24.2
-
MCS coupling: Activate collision protection
DB31, ... DBX24.3
-
21.7.2.2
Signals from axis/spindle
Signal name
SINUMERIK 840D sl
SINUMERIK 828D
MCS coupling: Collision protection active
DB31, ... DBX66.0
-
MCS coupling: Following axis
DB31, …DBX97.0
-
MCS coupling: Coupling active
DB31, …DBX97.1
-
MCS coupling: Mirroring active
DB31, …DBX97.2
-
MCS coupling: Offset change
DB31, …DBX97.3
-
Special functions
822
Function Manual, 12/2018, A5E40874099B AB
TE7: Continue machining at the contour (retrace
support) - 840D sl only
22
22.1
Brief description
Function
The "Continue machining - Retrace support (RESU)" technological function supports the
retracing of uncompleted 2-dimensional machining processes such as laser cutting, water jet
cutting, etc.
In the event of a fault during the machining process, e.g. loss of the laser, RESU can be used
even by machine operators who do not have specific knowledge of the active part program to
interrupt machining and travel back along the contour from the interruption point to a program
continuation point necessary for machining purposes.
After reaching the "continue machining" point, the machine operator triggers the re-machining.
As part of the retrace process, an implicit block search takes place along the contour with
calculation followed by repositioning on the contour and automatic retracing of the part program
machining process.
The possibility of retrace support within a machining program is realized by programming
RESU start and end points using the CC_PREPRE(...) procedure. The program continuation
point can be arbitrarily selected within a contour range defined in this way.
1
1
1
&&B35(35(
1
1
1
1
1
&&B35(35(
1
VW JHRPHWU\ D[LV
① RESU start point or start of the RESU-capable contour range
② RESU end point or end of the RESU-capable contour range
③ Example of a program continuation point
Figure 22-1
Programmed contour with program continuation and interruption points
Special functions
Function Manual, 12/2018, A5E40874099B AB
823
TE7: Continue machining at the contour (retrace support) - 840D sl only
22.2 Function description
Precise retracing of contours is possible along all programmed contours comprising straight
and circular elements. During retracing, other contour elements such as splines or
automatically inserted non-linear contour elements (circle, parable, etc. e.g. through tool radius
compensation) are mapped as straight lines between the start and end points of the
corresponding contour element, thereby preventing precise retracing of contours.
Function code
The code for the "Continue Machining - Retrace support" technological function for function-
specific identifiers of program commands, machine data, etc. is:
RESU (= REtrace SUpport)
Restrictions
The use of the "Continue Machining Retrace support" technological function is subject to the
following restrictions:
● The technological function is available only in the 1st channel of the NC.
● Program continuation or reverse travel is only possible for part program blocks that contain
traversing blocks in the configured RESU working plane (e.g. 1st and 2nd geometry axes
of the channel, see Section "Definition of the RESU working plane (Page 831)").
References
The "Continue Machining - Retrace support" technological function is a compile cycle. For the
handling of compile cycles (see Section "TE01: Installation and activation of loadable compile
cycles (Page 673)").
22.2
Function description
22.2.1
Function
Block search with calculation on contour
To be able to resume interrupted machining at a specific point in a part program, a block search
can be carried out using the "Block search with calculation on contour" standard function.
However, detailed knowledge of the part program is required to be able to enter the block
number of the part program block required for the block search (i.e. the number of the block
the search needs to locate).
Continue machining - retrace support
The "Continue machining - Retrace support" technological function supports the continuation
of the machining operation by means of an implicit block search with calculation on the contour
without the machine operator needing to know the part program block required.
Special functions
824
Function Manual, 12/2018, A5E40874099B AB