SINUMERIK 840D sl. Service - Functions. Manual (2018-2020) - page 70
T3: Tangential control - 840D sl only
13.3 Limit angle
Geometry axis switchover
Before geometry axis switchover can be performed for an existing coupling, the coupling must
first be deleted.
Program code
Comment
N10 GEOAX(2,Y1)
; 2nd geometry axis = machine axis Y1
N20 TANG(A, X, Y)
; Define tangential coupling for following axis A
N30 TANGON(A, 90)
; Activate tangential coupling for following axis A
N40 G2 F8000 X0 Y0 I0 J50
; Motion block
N50 TANGOF(A)
; Deactivate tangential coupling for following axis A
N60 TANGDEL(A)
; Delete tangential coupling for following axis A
N70 GEOAX(2, Y2)
; 2nd geometry axis = machine axis Y2
N80 TANG(A, X, Y)
; Define new tangential coupling for following axis A
N90 TANGON(A, 90)
; Activate new tangential coupling for following axis
A
13.3
Limit angle
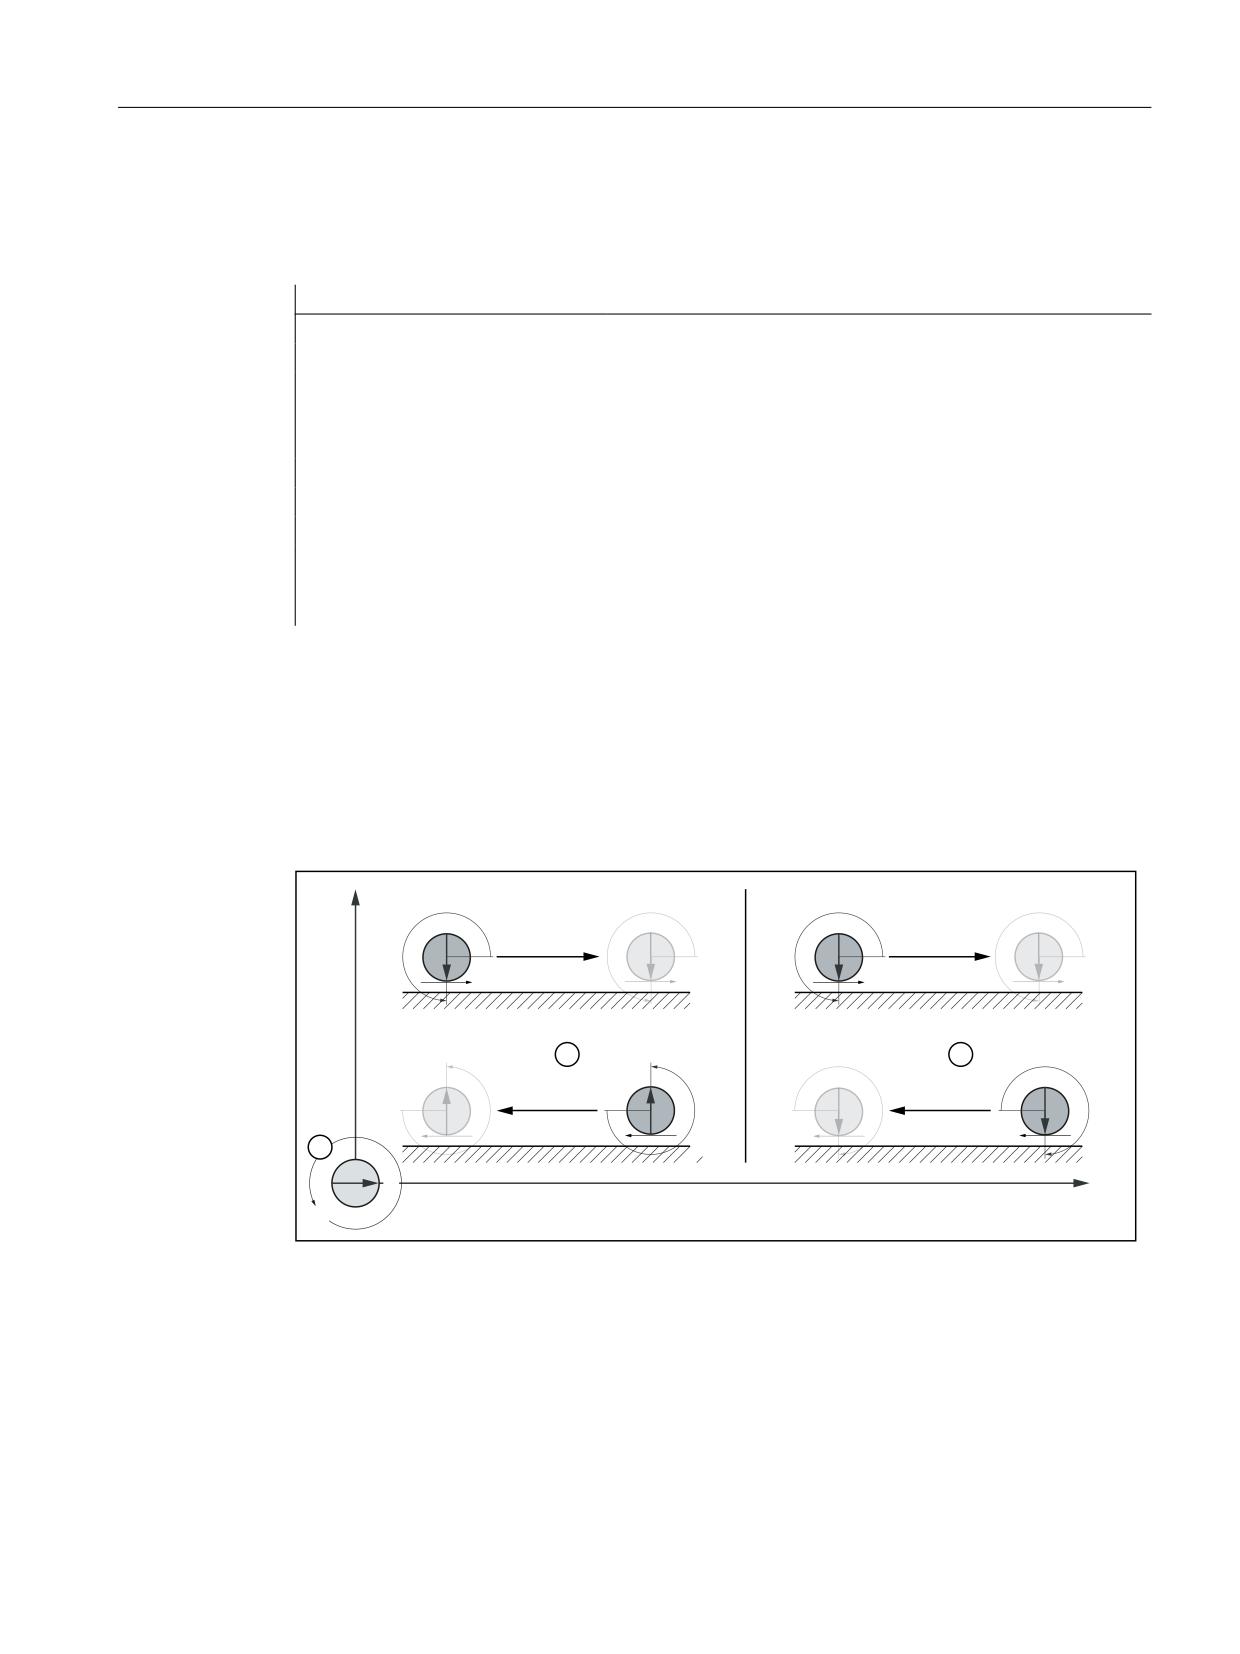
For alternating traversing motion, the direction of the path tangent jumps through 180° at the
reversal point. The alignment of the following axis also jumps through 180 °. This behavior is
generally not practical (see Fig., ②). Instead, for return motion, the following axis should be
traversed with the same alignment as for the forward motion (see Fig., ③).
r
r
<
r
r
&
|
;
① Initial position and positive direction of rotation of the following/rotary axis C
② Forward and reverse motion with the same offset angle 270°
③ Forward and reverse motion with alternating offset angles, 270° and -270°
Special functions
Function Manual, 12/2018, A5E40874099B AB
617
T3: Tangential control - 840D sl only
13.5 Examples
Avoiding reversal jump
Using the working area limitation G25 (lower limit) and G26 (upper limit), for the following axis,
a minimum and a maximum value must be entered for the position values referred to the basic
coordinate system. After this, the working area limitation for the following axis should be
activated/deactivated depending on the machining situation using the WALIMON / WALIMOF
commands. At the path reversal instant , the working area limitation must beactive.
Effect
If the following axis traverses with the actual offset angle with the axis position outside the
active working area limitation, then the control system checks whether the following axis, when
using the negative offset angle, would move in a permissible working area. If this is the case,
then the following axis is traversed with the negative offset angle.
Reference
Programming Guide Fundamentals; Chapter "Supplementary commands" > "Working area
limitation" > "Working area limitation in the BCS (G25/G26, WALIMON, WALIMOF)"
13.4
Supplementary conditions
Block search with active tangential coupling
If tangential control is active, it is recommended that for a block search only optimization type
"P" and block search type 2 ("Block search with calculation at the contour"), programmable
under TANG() (Page 611), or 5 ("Block search with calculation in the program test mode
(SERUPRO)") are used.
Explicit positioning of the following axis
If the following axis explicitly traverses an active tangential coupling, then the traversed
distance is additive to the programmed offset angle.
13.5
Examples
Example 1: Define and activate tangential coupling
Program code
Comment
; Define tangential coupling:
;
- Following axis C, leading axes X and Y
;
- Coupling factor: 1.0
;
- Coordinate system: BCS
;
- Optimization type: "P"
N10 TANG(C,X,Y,1,"B","P")
; Simplified: TANG(C,X,Y,,,"P")
; Activate tangential coupling:
;
- Offset angle: 90°
Special functions
618
Function Manual, 12/2018, A5E40874099B AB

T3: Tangential control - 840D sl only
13.5 Examples
Program code
Comment
N20 TANGON(C,90)
Example 2: Plane change
Program code
Comment
; Define tangential coupling:
;
- Following axis A, leading axes X and Y
;
- Coupling factor: 1.0
;
- Coordinate system: BCS
;
- Optimization type: "S"
N10 TANG(A,X,Y)
; Activate tangential coupling:
;
- Offset angle: 0°
N20 TANGON(A)
N30 X10 Y20
; Traverse leading axes
N80 TANGOF(A)
; Deactivate tangential coupling
N90 TANGDEL(A)
; Delete tangential coupling
; Define NEW tangential coupling:
;
- Following axis A, leading axes X and Z
;
- Coupling factor: 1.0
;
- Coordinate system: BCS
;
- Optimization type: "S"
TANG(A,X,Z)
TANGON(A)
Example 3: Geometry axis switchover
Program code
Comment
N10 GEOAX(2,Y1)
; 2nd geometry axis: Y1
; Define tangential coupling:
;
- Following axis A, leading axes X and Y
;
- Coupling factor: 1.0
;
- Coordinate system: BCS
;
- Optimization type: "S"
N20 TANG(A,X,Y)
; Activate tangential coupling:
;
- Offset angle: 90°
N30 TANGON(A,90)
N40 G2 F8000 X0 Y0 I0 J50
; Traverse circle
Special functions
Function Manual, 12/2018, A5E40874099B AB
619

T3: Tangential control - 840D sl only
13.5 Examples
Program code
Comment
N50 TANGOF(A)
; Deactivate tangential coupling
N60 TANGDEL(A)
; Delete tangential coupling
N70 GEOAX(2,Y2)
; 2nd geometry axis: Y2
; Define NEW tangential coupling:
;
- Following axis A, leading axes X and Y
;
- Coupling factor: 1.0
;
- Coordinate system: BCS
;
- Optimization type: "S"
N80 TANG(A,X,Y)
; Activate tangential coupling:
;
- Offset angle: 90°
N90 TANGON(A,90)
Example 4: Optimization type "P"
Program code
Comment
N100 G0 C0
N110 G1 X1000 Y500 F50000
N120 TRAORI
; Activate transformation
N130 G642
; Activate smoothing
N171 TRANS X50 Y50
; Work offset WCS
; Define tangential coupling:
;
- Following axis C, leading axes X and Y
;
- Coupling factor: 1.0
;
- Coordinate system: BCS
;
- Optimization type: "P"
N180 TANG(C,X,Y,1,,"P")
; Activate tangential coupling:
;
- Offset angle: 0°
;
- Rounding clearance 5.0 mm
;
- Angular tolerance 2.0°
N190 TANGON(C,0,5.0,2.0)
N210 G1 X1310 Y500
N215 G1 X1420 Y500
N220 G3 X1500 Y580 I=AC(1420) J=AC(580)
N230 G1 X1500 Y760
N240 G3 X1360 Y900 I=AC(1360) J=AC(760)
N250 G1 X1000 Y900
N280 TANGOF(C)
; Deactivate tangential coupling
N290 TRAFOOF
; Deactivate transformation
Special functions
620
Function Manual, 12/2018, A5E40874099B AB
T3: Tangential control - 840D sl only
13.6 Data lists
Example 5: Corner in space
Program code
; Comment
; Define tangential coupling:
;
- Following axis A, leading axes X and Y
;
- Coupling factor: 1.0
;
- Coordinate system: BCS
;
- Optimization type: "S" (standard)
TANG(A,X,Y,1.0,"B")
TLIFT(A)
; Activate intermediate block generation
G1 G641 X0 Y0 Z0 A0
; Go to initial position
; Activate tangential coupling:
;
- Offset angle: 0°
TANGON(A,0)
N4 X10
; Traverse leading axis X
N5 Z10
; Traverse geometry axis Z
N6 Y10
; Traverse leading axis Y
M30
By traversing the geometry axes in blocks N4 and N6, a discontinuous characteristic is
obtained, i.e. a corner in the contour of the leading axes of the tangential coupling. By
programming TLIFT(), an intermediate block is inserted in front of N6, in which following axis
A is rotated through 90° in the tangential direction of the Y axis. Only then is the Y axis traversed
in N6.
13.6
Data lists
13.6.1
Machine data
13.6.1.1
NC-specific machine data
Number
Identifier: $MN_
Description
11450
SEARCH_RUN_MODE
Block search parameterization
13.6.1.2
Axis/spindlespecific machine data
Number
Identifier: $MA_
Description
37400
EPS_TLIFT_TANG_STEP
Tangential angle for corner recognition
37402
TANG_OFFSET
Default angle for tangential follow-up control
Special functions
Function Manual, 12/2018, A5E40874099B AB
621

T3: Tangential control - 840D sl only
13.6 Data lists
13.6.2
Setting data
13.6.2.1
Channel-specific setting data
Number
Identifier $SC_
Description
42121
AX_ADJUST_FEED
Path feed in adjustment motion of the tangential axes
13.6.3
System variables
Identifier
Description
$AC_BLOCKTYPE
Current block is an intermediate block generated by TLIFT
Special functions
622
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) -
only 840D sl
14
14.1
Function
Note
The "Automatic post optimization with AST" function is an option for SINUMERIK 840D sl that
requires a license.
With the "Automatic post optimization with AST" function, axes with a changed mechanical
system can be post optimized from the part program.
SIEMENS provides predefined cycles for the functions of the Automatic Servo Tuning (AST)
(post optimization) (see "Programming (Page 626)"). They can be used by machine
manufacturers to create their own tuning cycles. The machine operator must only use the
machine manufacturer's cycle.
Note
Storage location for optimization cycles
In order that the machine operator can call the optimization cycles generated by the machine
manufacturer based on AST cycles, these must be saved in the manufacturer cycle directory
(_N_CMA_DIR) of the NC memory.
Application
General problem description: Dependency on the loading
After changing the load - and therefore the moment of inertia, for all directly-driven axes, the
current setpoint filters must be adapted to ensure that the speed control loop remains stable.
Such axes are:
● Tables with torque motors
● Linear axes with linear motors that support different masses
● Directly driven main spindles with different clamping fixtures (lathe chuck)
Special functions
Function Manual, 12/2018, A5E40874099B AB
623
T4: Automatic post optimization with AST (option) - only 840D sl
14.1 Function
All conventionally driven axes (servomotor with ballscrew spindle and possibly with gearbox)
do not require that the speed controller is post optimized (retuned).
Note
If, after the load has changed, the actual parameter data set no longer fits, in order to traverse
directly-driven axis reliably without any instability, then parameter values must be adapted
before setting the controller enable (DB31, ... DBX2.1 = 1). Automatic post optimization with
AST is only possible after the controller has been enabled.
The following measures are possible:
● The active parameter data set is set so that it is suitable for all load conditions - and can
be used without adaptation ("moderately" adjusted parameter data set).
● A "moderately" adjusted parameter data set is adapted using automatic post optimization
with AST, and is then subsequently activated.
● The required parameter values are assigned by the PLC (FB3, PI services, …) and/or
manufacturer cycle beforesetting the controller enable.
Typical applications
For typical applications, see Chapter "Examples (Page 648)".
Setting up optimization cycles/troubleshooting
We recommend that an optimization cycle that has been newly created or modified is executed
and tested before the machine is shipped.
The reasons for this are as follows:
● For programming errors - or if the appropriate preconditions are not available (e.g. XML file
with optimization strategy is missing), then the program is canceled. Based on the alarm
that is output, the program line with the error can be identified and the error subsequently
resolved. As soon as the optimization cycle can be executed without any errors, program
stops should no longer occur for the end user.
● If the user interface-based automatic servo optimization (AST) had not been previously
used on the machine, and the machine data is not set for the current recommendation for
precontrol (e.g. MD33000 $MA_FIPO_TYPE = 3, MD32620 $MA_FFW_TYPE = 4), then
the first time that the AST cycles are executed results in this machine data being set, and
a power on (NC reset) or a channel reset is necessary.
Reference:
For information on user interface-based automatic servo optimization, see:
● CNC Commissioning Manual: NC, PLC, Drive
Special functions
624
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.2 Commissioning
14.2
Commissioning
System requirements
● SINUMERIK 840D sl with SINUMERIK Operate
● CNC software as of version 4.7 SP1
● "Automatic post optimization with AST" option is set.
Machines with several HMI components
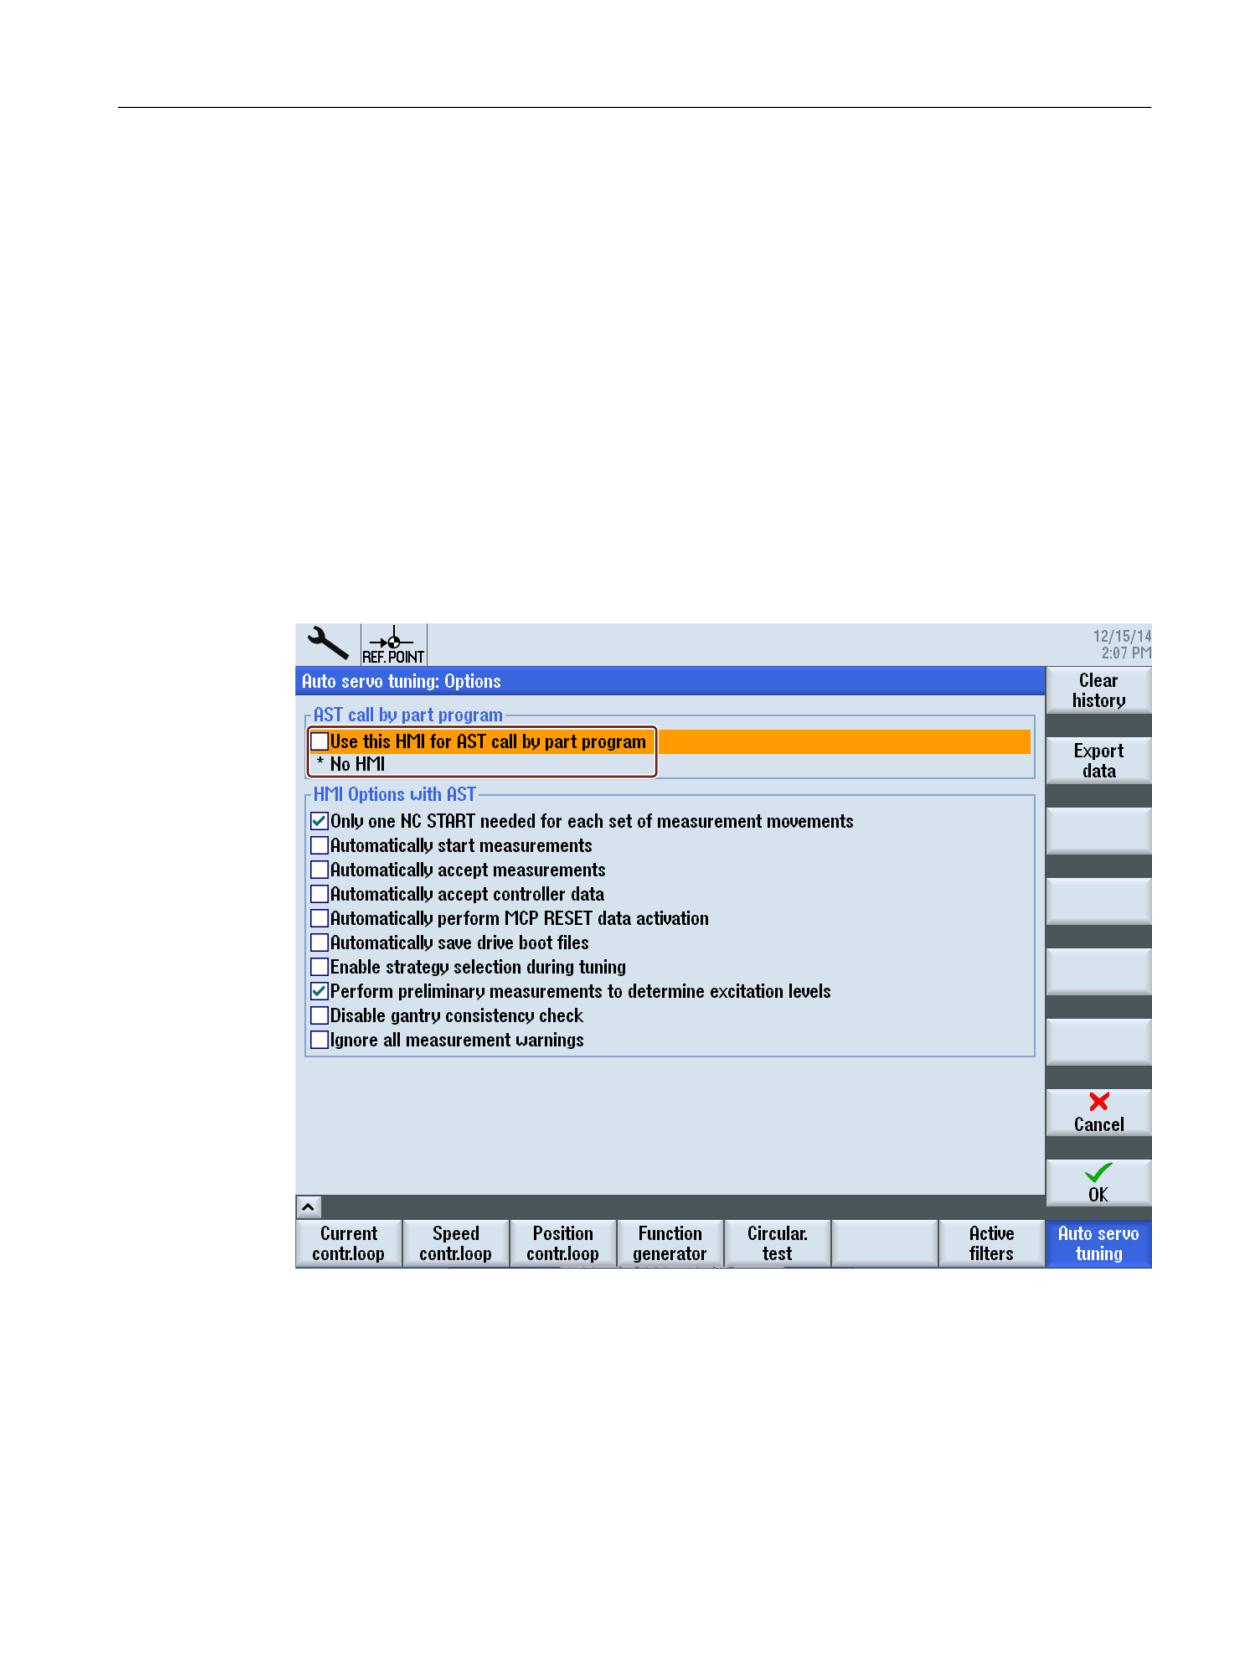
The "Automatic post optimization with AST" function can always be assigned to an HMI.
In order to change the actual assignment, in the HMI intended for the function, window
≫Automat. servo optimization: options≪ must be called, and option ≫Assign this HMI for
"Call AST from the part program" ≪ selected.
Special functions
Function Manual, 12/2018, A5E40874099B AB
625

T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
14.3
Programming
14.3.1
Overview
Predefined cycles for automatic post optimization with AST
SIEMENS provides machinery builders (OEMs) the following cycles so that they can program
their own optimization cycles:
● CYCLE751 - Open/execute/close optimization session (Page 627)
● CYCLE752 - Add axis to an optimization session (Page 628)
● CYCLE753 - Select optimization mode (Page 631)
● CYCLE754 - Add/remove data set (Page 632)
● CYCLE755 - Backup/restore data (Page 633)
● CYCLE756 - Activate optimization results (Page 634)
● CYCLE757 - Save optimization data (Page 635)
● CYCLE758 - Change a parameter value (Page 639)
● CYCLE759 - Read parameter value (Page 641)
Internally, each of these cycles calls CYCLE750, which contains the MMC command with the
actual function call.
Data handling
Archived in standard directories
Automatic servo optimization (AST) uses three standard directories in the file system to save
specific data:
Directory path
To archive the following files
/user/sinumerik/nck/data/optimization
● XML files with axis and/or path-specific optimization data, which
are automatically generated for the user interface-based
automatic servo optimization.
● XML files with axis and/or path-specific optimization data, which
are automatically generated for automatic post optimization with
AST using CYCLE757.
/user/sinumerik/nck/data/optimization/restore
● Backup files that are generated by the automatic post
optimization with AST using CYCLE755.
/user/sinumerik/nck/data/optimization/data
● CSV files that are generated by the automatic post optimization
with AST using CYCLE757.
Addressing using relative path data
The starting point for addressing an optimization file with relative path data is the data-specific
standard directory in the file system. When addressing an XML file with axis-specific
Special functions
626
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
optimization data, the relative path would be specified, e.g. starting at standard directory /card/
user/sinumerik/nck/data/optimization.
The relative path is specified, starting without a forward slash ("/").
Subdirectories can be specified.
Example:
data/my_ast_ax1.xml
(corresponds to absolute path /user/sinumerik/nck/data/optimization/data/my_ast_ax1.xml)
Addressing using absolute path data
Using absolute path data, optimization files outside the standard directories can be addressed.
When addressing an optimization file by specifying an absolute path, the complete file address
is specified.
For Linux, the complete address comprises the following elements:
● Directory path
● File name
Example:
● /user/sinumerik/hmi/log/optimization/data/my_ast_ax1.xml
Addressing files in external memories
When addressing optimization files in an external memory, the drive name must be specified
at the beginning of the path.
All symbolic device names configured in card/user/sinumerik/hmi/cfg/logdrive.ini are
permissible.
Examples:
● LOCAL_DRIVE:/… (local drive)
●
//DEV_5:/… (user-defined drive)
14.3.2
CYCLE751 - Open/execute/close optimization session
Syntax
CYCLE751(<S_I_SESSIONCOMMAND>)
Special functions
Function Manual, 12/2018, A5E40874099B AB
627
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
Parameter
No.
Parameters
1
<S_I_SESSIONCOMMAND>
Data type:
INT
Value:
0
Not defined
1
Open new optimization session
Note:
Multiple sessions cannot be open concurrently. Opening a new session closes the current session
automatically.
2
Close current optimization session
3
Execute optimization functions of the current session with immediate transfer of the optimization
results
The scope of the optimization functions (measurement of the speed control loop, measurement of
the position control loop, optimization of the path interpolation) to be executed depends on the axis-
specific optimization strategies set from the user interface.
The optimization results are transferred immediately (update the axis and drive parameters, update
the optimization files).
4
Execute optimization functions of the current session without immediate transfer of the optimization
results
Unlike 3, the optimization results are not transferred immediately. Transfer can be realized later in
the optimization session using CYCLE756.
14.3.3
CYCLE752 - Add axis to an optimization session
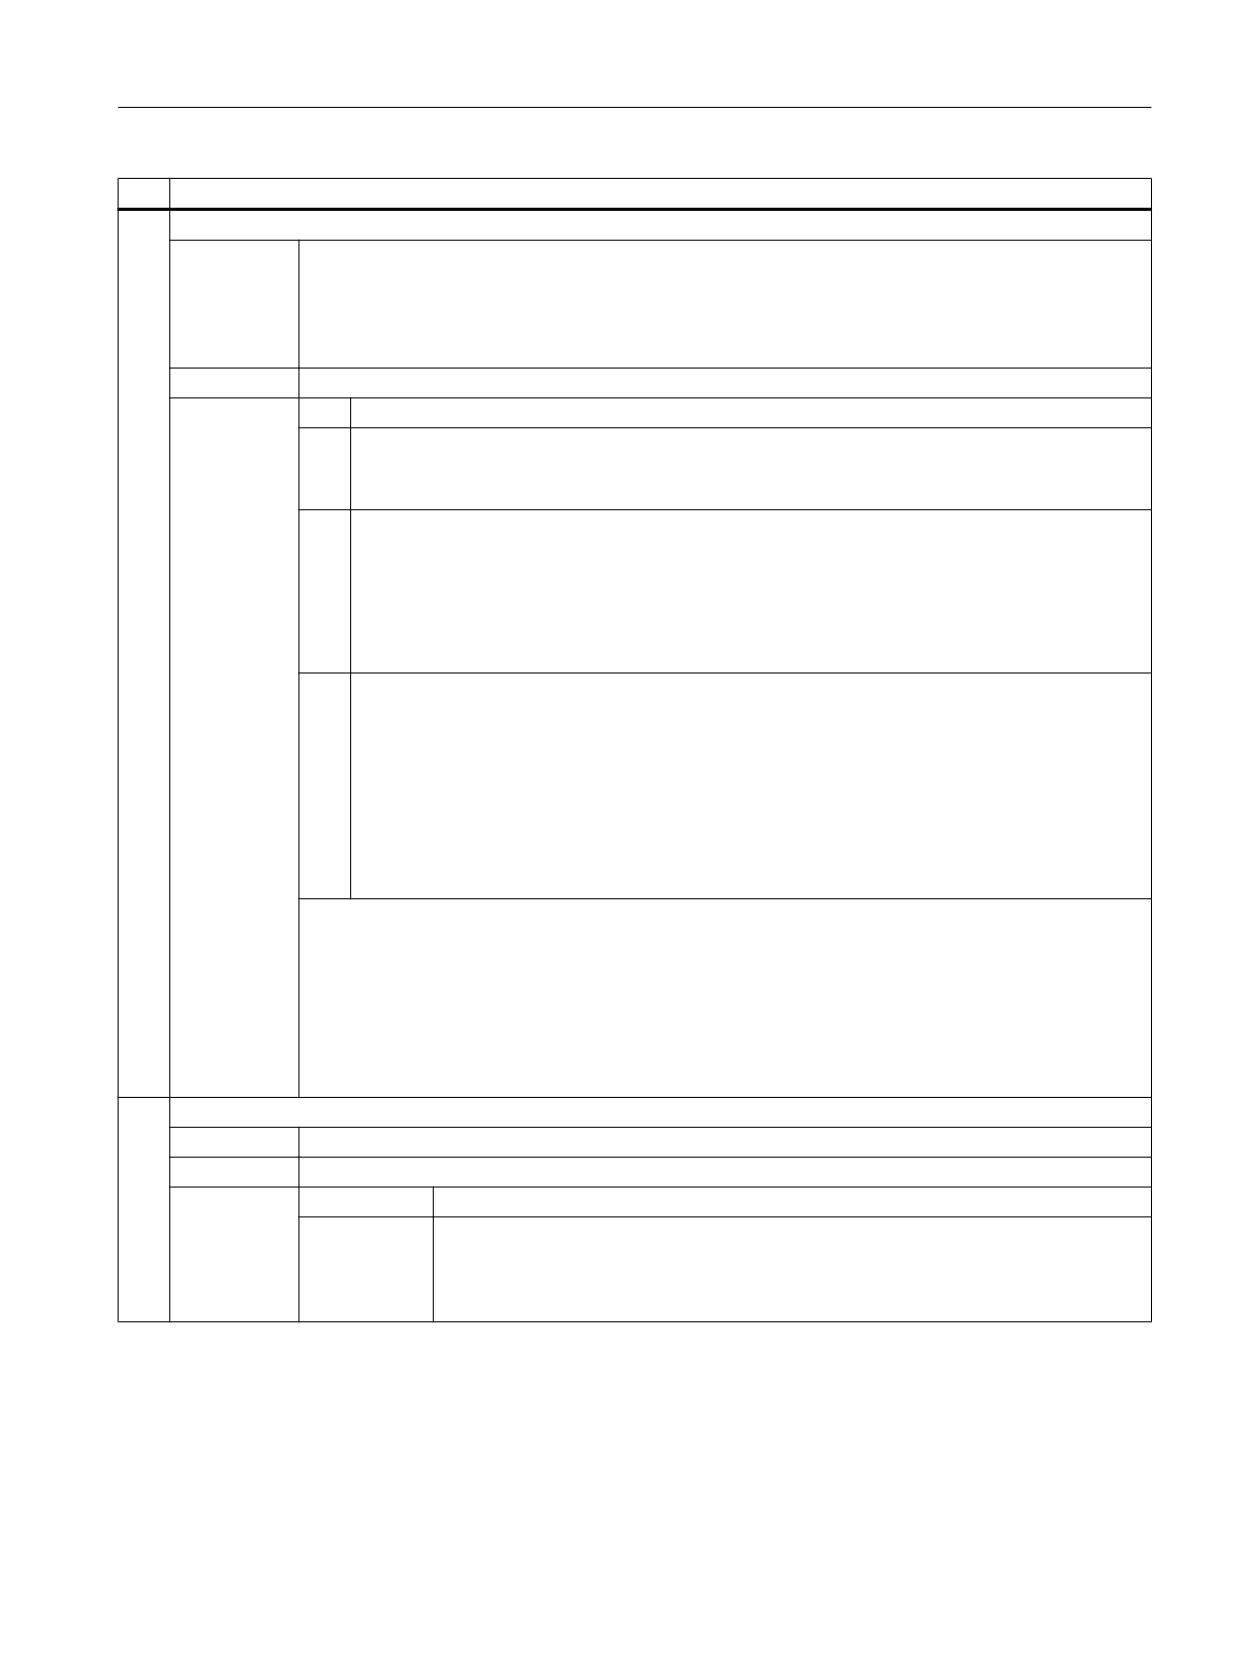
After opening the optimization session, CYCLE752 specifies which axes should be
reoptimized. If a reoptimization of the path interpolation is provided, CYCLE752 also specifies
the axes required for the comparison of the path interpolation.
Syntax
CYCLE752(<S_I_AXIS>, <S_I_ACTIONREQUEST>, <S_B_ISPATHMEMBER>,
<S_SZ_FILENAME>)
Parameters
No.
Parameters
1
<S_I_AXIS>
Meaning:
Machine axis number
Specifies the axis to be added to the optimization session.
Note:
For gantry or master-slave couplings, only the leading or master axis of the coupling group should be
specified.
Data type:
INT
Special functions
628
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
No.
Parameters
2
<S_I_ACTIONREQUEST>
Meaning:
Specifies whether the stored optimization data (optimization strategy and optimization results) should
be used or the axis with AST default settings reoptimized for the axis to be added.
Note:
If the axis has already been optimized and the optimization data has been saved in an optimization
file, this data is normally accessed first. CYCLE753 can then specify the further procedure.
Data type:
INT
Value:
0
Not defined
1
Reoptimization with AST default settings
The axis should be remeasured and reoptimized with the AST default settings. The selected
AST settings are not considered on the user interface.
2
Optimization data from a user-defined optimization file
The stored optimization data from the specified user-defined optimization file (see <S_SZ_FIL-
ENAME> parameter) is used for the axis.
Note:
This setting is only possible if the axis has already been optimized once, and the results have
been saved to a user-defined optimization file.
3
Optimization data from the standard optimization file
The stored optimization data from the axis-specific standard optimization file is used for the axis.
The selected AST settings are not considered on the user interface.
Note:
For the user interface-based automatic servo optimization, the standard optimization files are
automatically generated to backup optimization information and data (optimization strategy,
measuring and optimization results) and saved in the file system under /user/sinumerik/nck/data/
optimization. There is a standard optimization file for every axis - and a standard optimization
file for the path interpolation.
For example, the setting <S_I_ACTIONREQUEST> = 2 or 3 is used in the following cases:
● The axis should be post-optimized using the saved strategy and measurement settings. To do this,
the saved optimization data is loaded with CYCLE752 and the deployed optimization mode defined
with CYCLE753.
● On completion of the reoptimization of the individual axes, the path interpolation must be
reoptimized.
● Saved optimization results (values for NC and drive parameters) should be restored.
3
<S_B_ISPATHMEMBER>
Meaning:
Consideration of the axis for the last optimization step (optimization of the path interpolation)
Data type:
BOOL
Value:
0 (FALSE)
Do not consider the axis for the optimization of the path interpolation
1 (TRUE)
Consider the axis for the optimization of the path interpolation
All axes, which are added using CYCLE752( , , TRUE, ), are taken into account when
optimizing path interpolation. This is realized within the scope of the optimization, e.g.
started using CYCLE751(3).
Special functions
Function Manual, 12/2018, A5E40874099B AB
629

T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
No.
Parameters
4
<S_SZ_FILENAME>
Meaning:
Address of the user-defined, axis-specific optimization file (only relevant for <S_I_ACTIONREQUEST>
= 2!)
If the file was generated via the program-based automatic post-optimization with AST using CY-
CLE757, then as default setting, the file is in directory /user/sinumerik/nck/data/optimization and it is
not necessary to specify a directory path.
However, the more frequent use case is that the file is generated via the user interface-based automatic
servo optimization, and was saved in directory /user/sinumerik/hmi/log/optimization. In addition to the
file name, the address must also include the directory path (unless the file was subsequently copied
to the standard directory /user/sinumerik/nck/data/optimization). See also "Example 6: Measuring an
axis without optimization (Page 663)".
Data type:
STRING [100]
Note
Gantry/master-slave coupling
For gantry or master-slave couplings, with CYCLE752, only the leading or master axis of the
coupling group is specified. The AST software automatically adds the coupled following or
slave axes.
AST then automatically measures all axes of a coupling group - and optimizes them with
identical controller settings. The position controller gains are set the same, the integral time in
the speed controller is selected the same and the effective speed controller gain (relative to
the overall moment of inertia) is selected the same. The current setpoint filters can be optimized
differently.
Coupled axes must be referenced (homed) before the automatic optimization!
Note
Premeasurement
The decision for performing a premeasurement depends on the available axis optimization
data.
● Cases in which the control unit performs a premeasurement for determining the measuring
parameters:
- The optimization strategy envisages a premeasurement; data from an earlier
premeasurement is not available.
- The optimization data does not specify any optimization strategy.
● Cases in which no premeasurement is performed:
- The optimization strategy envisages a premeasurement; data from an earlier
premeasurement is available.
- The optimization strategy does not envisage any premeasurement (the optimization
strategy takes precedence over the "Perform premeasurement for determining the
excitation" option selected from the user interface).
Special functions
630
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
14.3.4
CYCLE753 - Select optimization mode
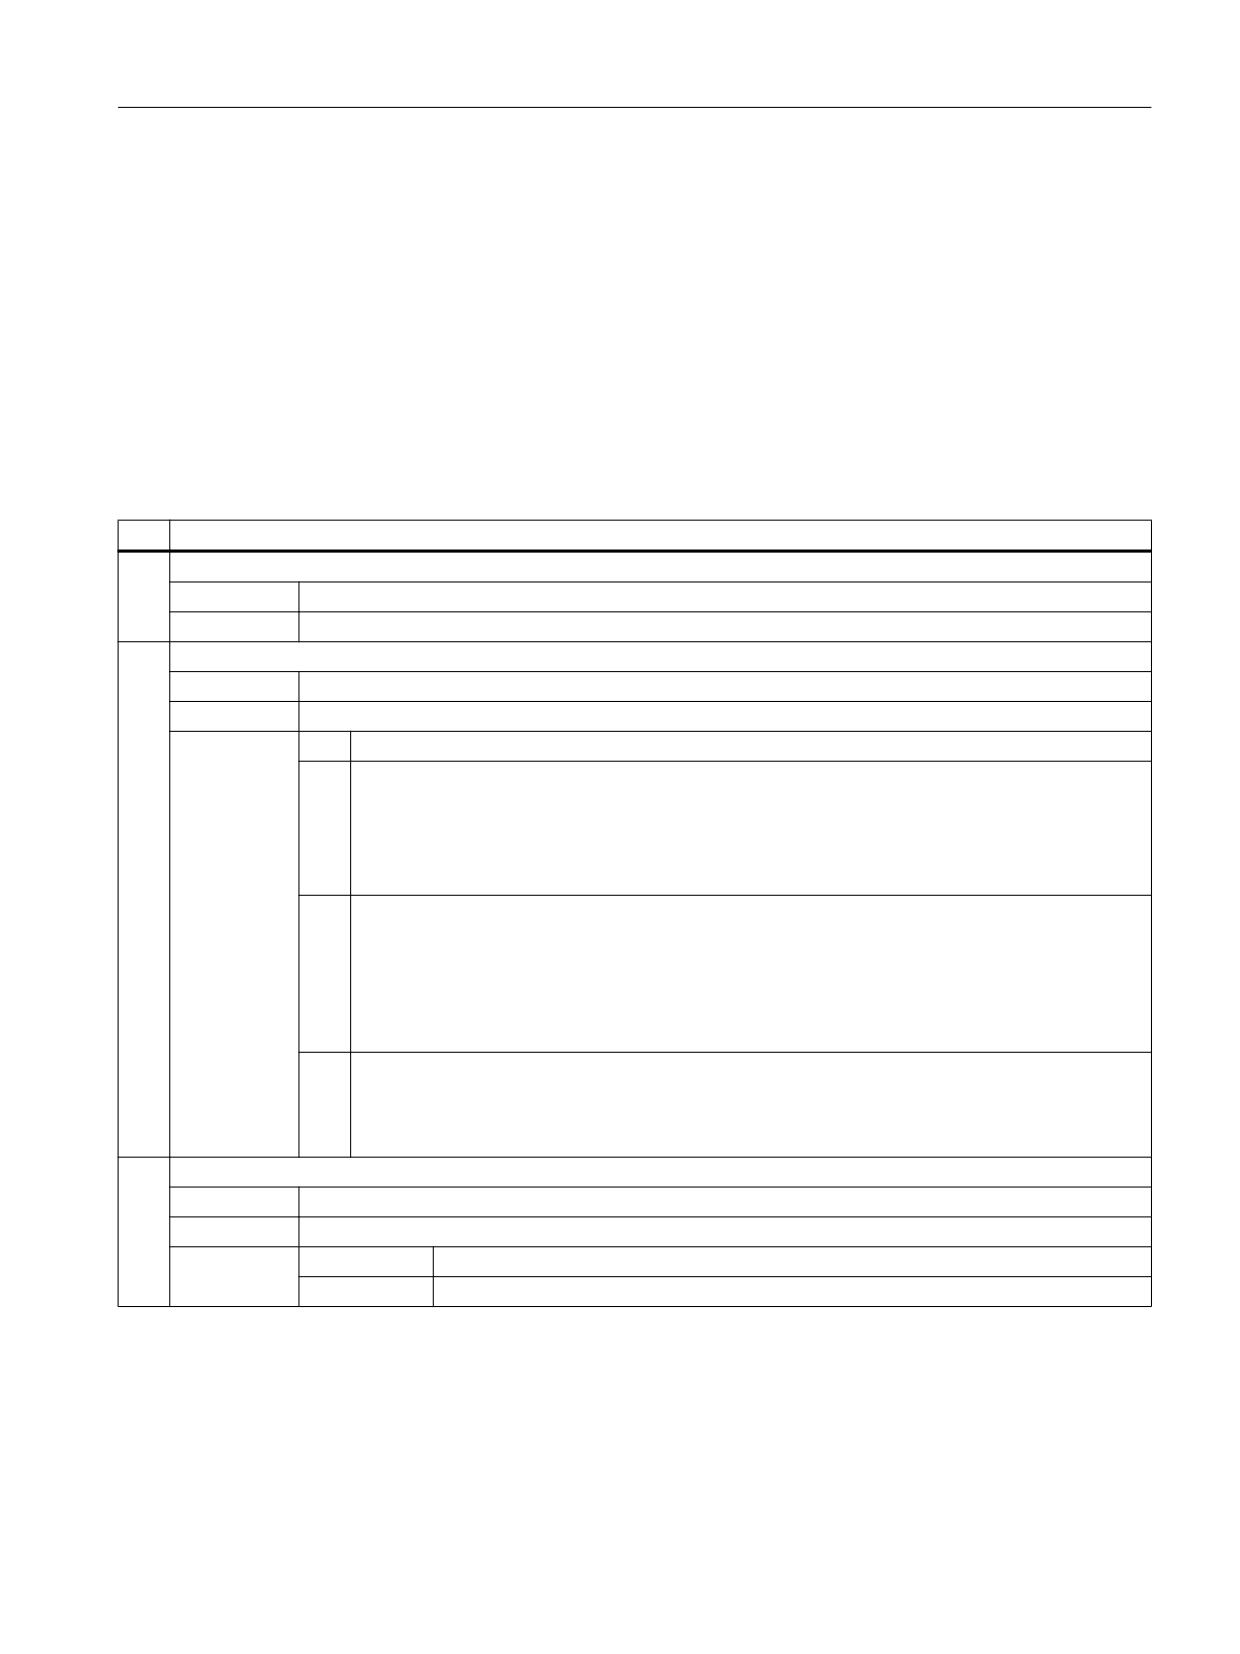
CYCLE753 must be programmed when different strategy settings should act for the axis than
those stored as standard or selected from the user interface. For example, this the case when
an axis with user-defined strategy and measuring settings from a stored optimization file should
be remeasured and reoptimized.
Syntax
CYCLE753(<S_I_AXIS>, <S_I_ACTION>, <S_B_SAVEBOOTFILES>)
Parameters
No.
Parameters
1
<S_I_AXIS>
Meaning:
Machine axis number
Data type:
INT
2
<S_I_ACTION>
Meaning:
Specifies the optimization mode for the specified axis.
Data type:
INT
Value:
0
Not defined
1
Match the path interpolation
The axis (path axis) should not be remeasured and reoptimized, but rather considered and
adapted only for the optimization of the path interpolation.
The stored results from the optimization file are used for the axis. The optimization of the path
interpolation means that the axis-specific machine data and drive parameters can change.
2
Reoptimization with a different optimization strategy based on stored measurements
The axis should be reoptimized based on the results from an earlier measurement and currently
valid optimization strategy changed from the user interface or CYCLE758.
This mode is used, for example, to eliminate known periodic disturbance frequencies (see "Ex-
ample 5: Reoptimize the speed control loop to eliminate known periodic disturbance frequen-
cies. (Page 661)").
3
Measurement and reoptimization (→ Mode for changed mechanics/loading!)
The mechanics/loading has changed. The axis should be remeasured and reoptimized using
the user-defined strategy and measuring settings from an optimization file. The strategy and
measuring settings can be adapted from the user interface or with CYCLE758.
3
<S_B_SAVEBOOTFILES>
Meaning:
Save updated drive parameter values as persistent data
Data type:
BOOL
Value:
0 (FALSE)
No
1 (TRUE)
Yes (default)
Special functions
Function Manual, 12/2018, A5E40874099B AB
631
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
14.3.5
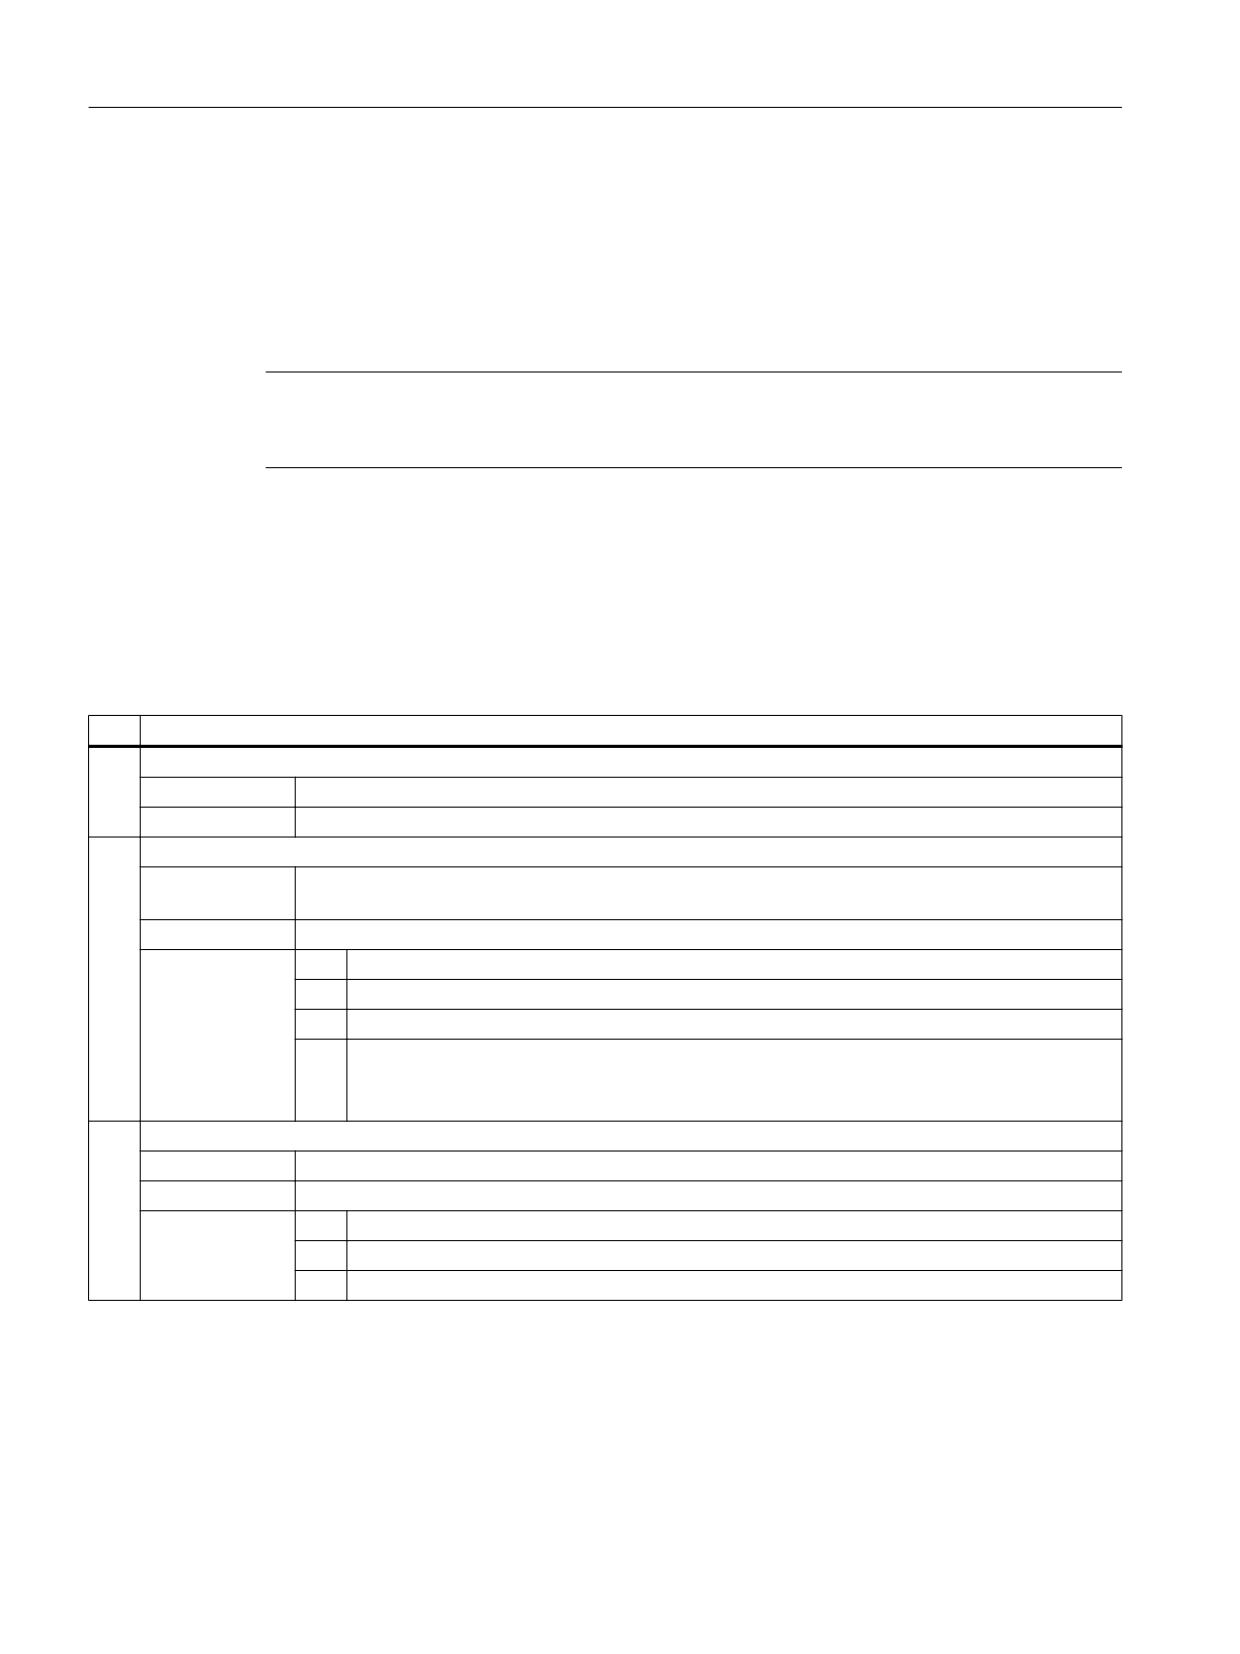
CYCLE754 - Add/remove data set
If the optimization results rather than the current data set should overwrite a specific axis or
drive data set, the data set to be overwritten must be added to the data set list with CYCLE754.
This list involves an invisible internal function list used to define data sets to be optimized. As
default setting, only the currently selected data set is included in it. CYCLE754 must also be
used to remove a data set from the list.
Note
Adding or removing an axis or drive data set using CYCLE754 only refers to the data set list,
i.e an axis or drive data set removed from the list still remains in the control or in the drive.
Syntax
CYCLE754(<S_I_AXIS>, <S_I_ACTIONREQUEST>, <S_I_DATASETTYPE>,
<S_I_INDEX>)
Parameters
No.
Parameters
1
<S_I_AXIS>
Meaning:
Machine axis number
Data type:
INT
2
<S_I_ACTIONREQUEST>
Meaning:
Specifies whether the specified axis or drive data set should be added to or removed from the data
set list.
Data type:
INT
Value:
0
Not defined
1
Add a data set
2
Remove a data set
3
Remove all data sets from the list
Note:
If the list is empty, the optimization results can be written only to the active data set.
3
<S_I_DATASETTYPE>
Meaning:
Data set type
Data type:
INT
Value:
0
Not defined
1
Axis data set (servo parameter set)
2
Drive data set (DDS)
Special functions
632
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
No.
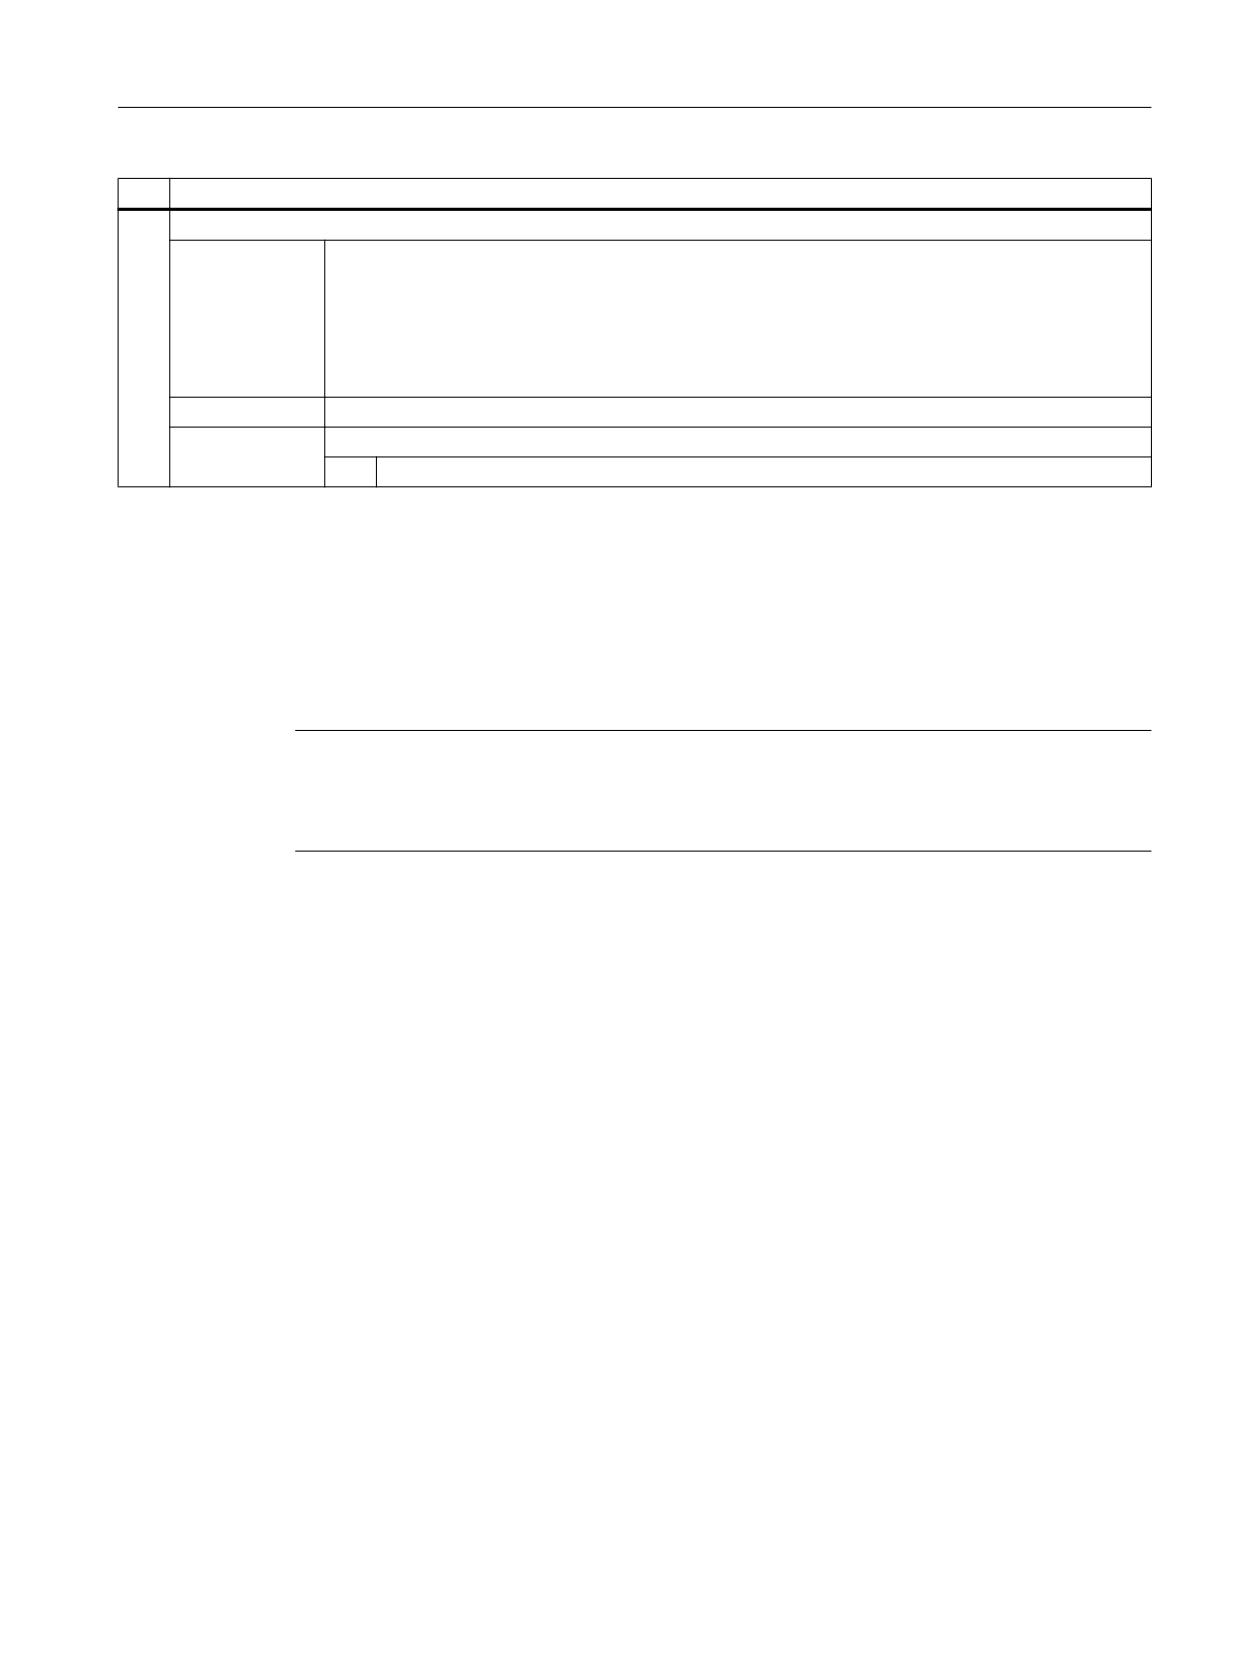
Parameters
4
<S_I_INDEX>
Meaning:
Data set index
Specifies the data set to be added and into which the optimization results should be written or should
be removed from the list.
Note:
The following applies to the axisdata set index: <n> = parameter set number - 1
Example: Index 0 ≙ parameter set 1
Data type:
INT
Range of values:
-1, 0, 1, ... <MAX_INDEX>
-1
active data set
14.3.6
CYCLE755 - Backup/restore data
Using CYCLE755, backup files can be created in the file system that permit the backup of the
actual data, and therefore facilitate specific data restoration at any time during the optimization
session. Data restoration is also called using CYCLE755. Further, CYCLE755 is used to query
the existence of a backup file as well as to delete backup files.
Note
The backup files are no longer required after the optimization session has been successfully
completed. This is the reason that these should be deleted again at the end of the optimization
session with CYCLE755.
Typical examples for using CYCLE755 include:
● Undoing data changes, which are only to be temporarily valid.
● Restoring data after an interrupted optimization session.
A program that queries the existence of a backup file, and for a positive result, restores the
data from this file, can be used to return to a defined initial state after an optimization session
has been interrupted.
Syntax
CYCLE755(<S_I_ACTIONREQUEST>, <S_SZ_NAME>, <S_SZ_GUD_BOOL_NAME>)
Special functions
Function Manual, 12/2018, A5E40874099B AB
633
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
Parameters
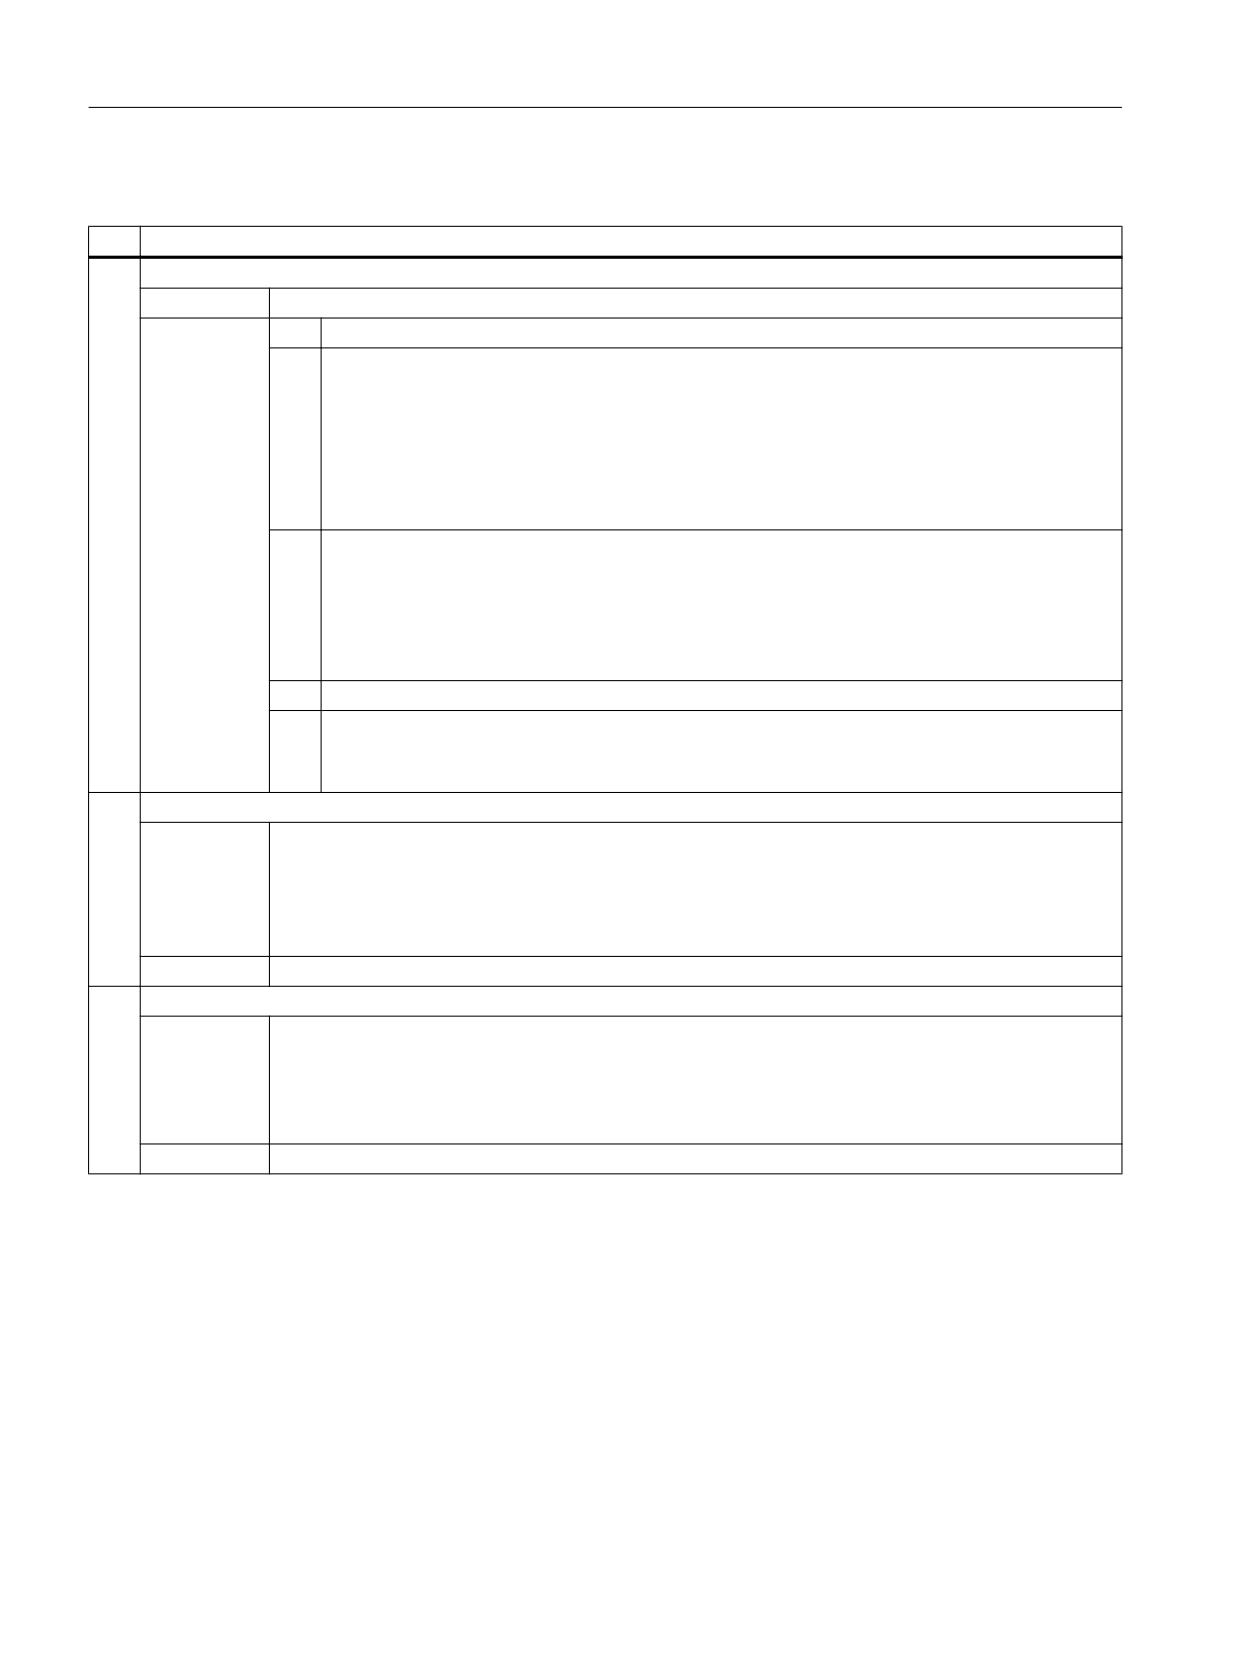
No.
Parameters
1
<S_I_ACTIONREQUEST>
Data type:
INT
Value:
0
Not defined
1
Backup data for a later restore
This setting saves the data values at the time of the cycle call in the specified file.
The following parameters define the content of the data backup:
● the currently valid optimization strategy
● the axes currently added to the optimization session
● the current list of parameter sets to be written
2
Restore data
This setting restores the data from the specified file.
Requirements:
● The optimization session is still active.
● The axis and data set selection at the time of the backup is still available.
3
Delete backup file
4
Querying the existence of a backup file
The result of the query is saved to a channel-global user variable (GUD), type BOOL (see pa-
rameter <S_SZ_GUD_BOOL_NAME>).
2
<S_SZ_NAME>
Meaning:
Name of backup file
The file name can be freely selected with the following restriction: it is not permissible that the sequence
of letters "AST" is located at the beginning of the file name.
Specifying a path (absolute or relative) is only required if the file is not to be saved to the standard
directory /user/sinumerik/nck/data/optimization/restore.
Data type:
STRING [100]
3
<S_SZ_GUD_BOOL_NAME>
Meaning:
Name of the GUD, in which the result of the file query should be saved
(only relevant, if <S_I_ACTIONREQUEST> = 4!)
Note:
The specified GUD must be defined in a definition file as a channel-global variable, type BOOL:
DEF CHAN BOOL
Data type:
STRING [50]
14.3.7
CYCLE756 - Activate optimization results
CYCLE756 can be used to activate the optimization results at a specific time / under specific
conditions. The conditions must be queried in the manufacturer cycle. CYCLE756 can also
specify which control parameters should be active: original data, axis-optimum data or path-
optimum data.
Syntax
CYCLE756(<S_I_AXIS>, <S_I_REGULATOR_ROLE>, <S_B_SAVEBOOTFILES>)
Special functions
634
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
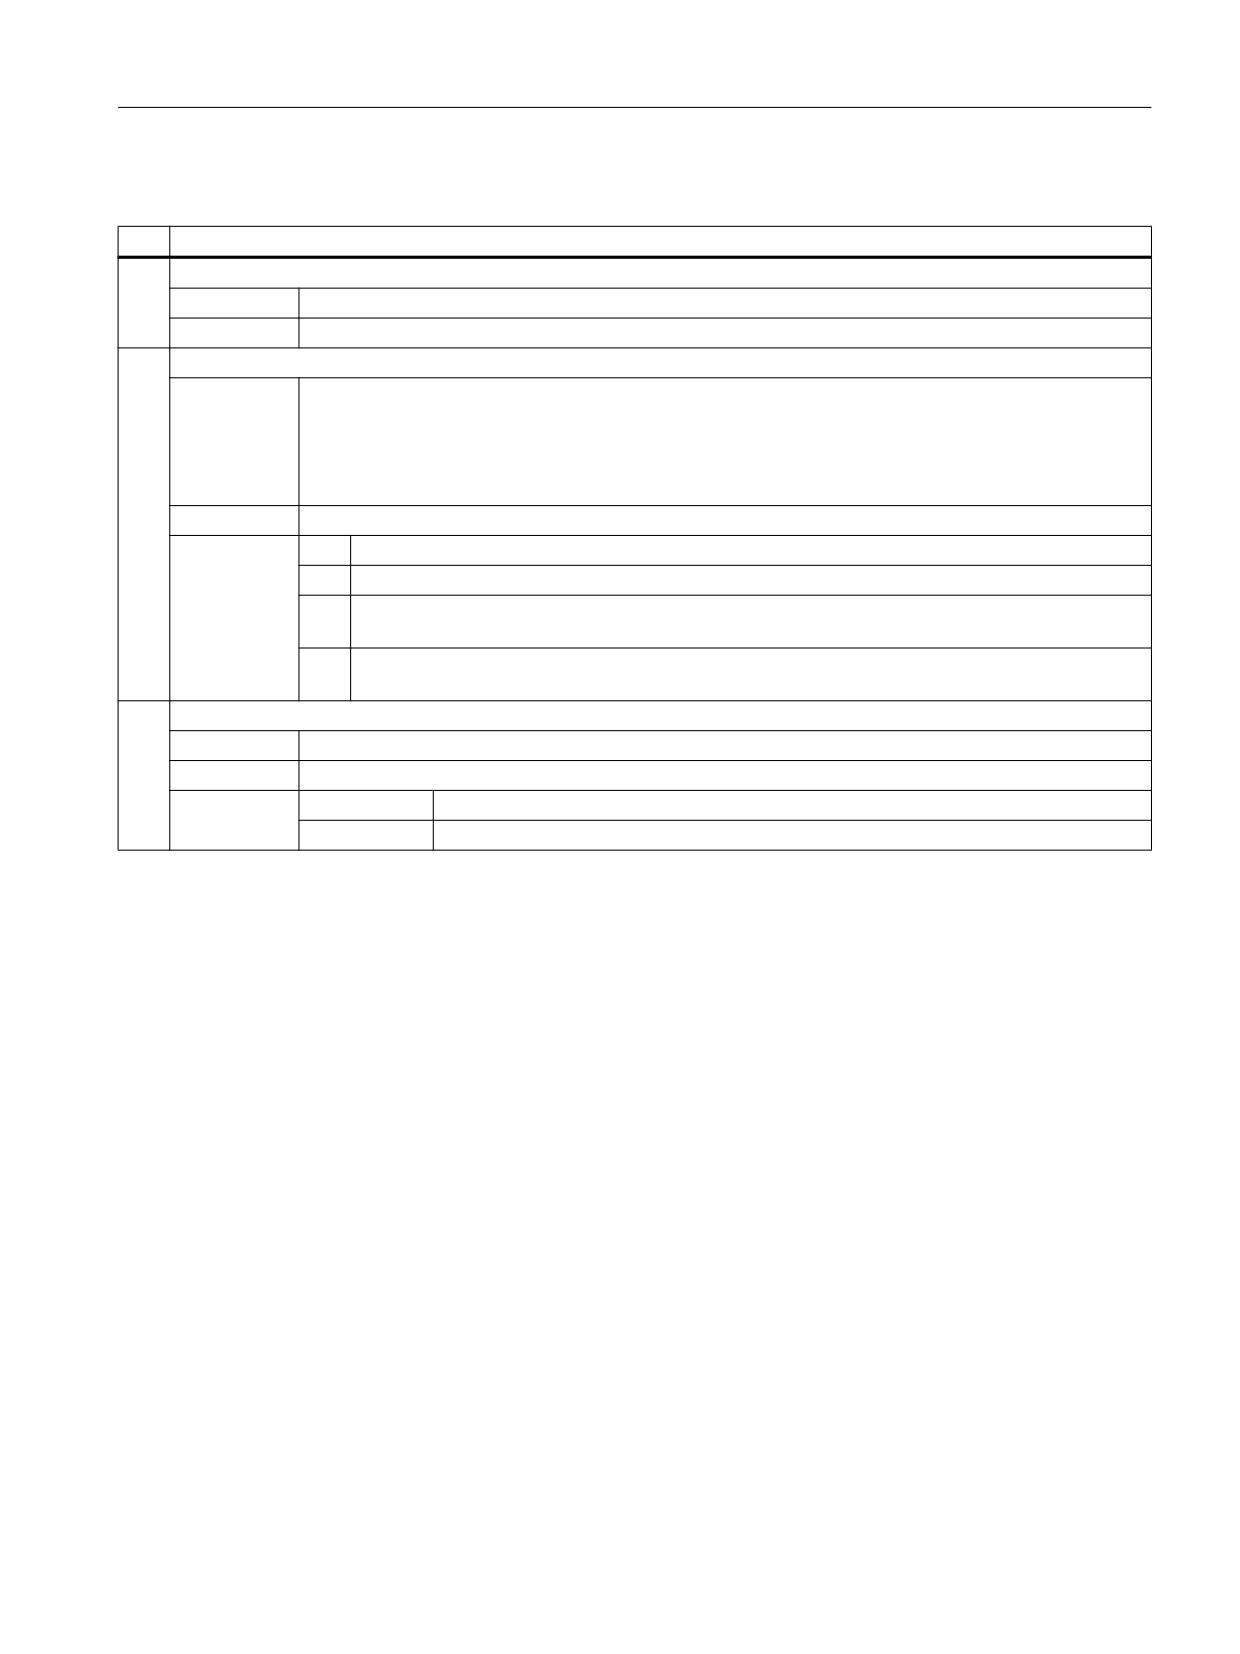
Parameters
No.
Parameters
1
<S_I_AXIS>
Meaning:
Machine axis number
Data type:
INT
2
<S_I_REGULATOR_ROLE>
Meaning:
Specifies which optimization results should act for the specified axis in the control unit and in the drive.
Note:
If the axis is part of a gantry group or a master-slave coupling, then optimization factors are included
in the optimization results, which would be necessary to adapt the dynamic response of all axes of the
coupling group.
Data type:
INT
Value:
0
Not defined
1
The original data should act for the specified axis.
2
The current optimization results without optimization of the path interpolation should become
active for the specified axis (axis-optimum data)
3
The current optimization results with optimization of the path interpolation should become active
for the specified axis (path-optimum data).
3
<S_B_SAVEBOOTFILES>
Meaning:
Save updated drive parameter values as persistent data
Data type:
BOOL
Value:
0 (FALSE)
No
1 (TRUE)
Yes (default)
Application
Some situations for which CYCLE756 is useful:
● CYCLE751(4) executes the optimization functions of the current session without
transferring the optimization results immediately. The optimization results can be activated
later during the optimization session with CYCLE756. Prior to the activation, the data can
be read and tested with CYCLE758/759.
● CYCLE752 loads the saved optimization data from an optimization file. CYCLE756
activates the loaded data.
14.3.8
CYCLE757 - Save optimization data
Contrary to the user interface-based automatic servo optimization, where optimization data
are automatically saved (standard optimization files), saving optimization data for program-
based automatic post optimization with AST must be explicitly called by programming
CYCLE757.
Special functions
Function Manual, 12/2018, A5E40874099B AB
635

T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
The following user-defined optimization files can be created in CYCLE757:
● Optimization files in the XML format:
- for the axis-specific optimization data
- for the data to optimize path interpolation
● Optimization files in the CSV format with frequency, amplitude and phase of the following
frequency responses:
- measured speed-controlled system
- measured mechanical frequency response
- calculated closed speed controller
- calculated closed position controller
- measured closed speed controller
- measured closed position controller
If a path is not specified, the files are saved in the file system in the following standard
directories:
● XML files: /user/sinumerik/nck/data/optimization
● CSV files: /user/sinumerik/nck/data/optimization/data
NOTICE
Data loss
If CYCLE757 is not programmed, measurement data as well as parameters for assessment
and offline optimization are no longer available after the optimization session has been closed.
However, the optimization (depending on the strategy) is written to the axis and drive
parameters.
Remedy: Save optimization data to be backed up before closing the optimization session with
CYCLE757.
Syntax
CYCLE757(<S_I_AXIS>, <S_SZ_FILENAME>, <S_I_CONTENT_TYPE>,
<S_I_FORMATFILTER>, <S_I_SUPPINFO>)
Parameters
No.
Parameters
1
<S_I_AXIS>
Meaning:
Machine axis number
Data type:
INT
Special functions
636
Function Manual, 12/2018, A5E40874099B AB

T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
No.
Parameters
2
<S_SZ_FILENAME>
Meaning:
Name of the optimization file to be created (with file extension ".xml" or ".csv")
The file name can be freely selected with the following restriction: it is not permissible that the sequence
of letters "AST" is located at the beginning of the file name.
Specifying a path (absolute or relative) is only required if the file is not to be saved to the standard
directory.
Examples:
● AXIS.xml
● PATH.xml
● SPEEDCTRL_PLANT.csv
● POSCTRL_MECHRESP.csv
Special case:
● Empty string (""); only valid, if <S_I_CONTENT_TYPE> = 1 or 2
Entering an empty string means that the data of the program-based automatic post optimization
are written to the standard optimization file for the axis (<S_I_CONTENT_TYPE> = 1) or for the
path interpolation (<S_I_CONTENT_TYPE> = 2).
Notice:
The standard optimization files contain the data of the user interface-based automatic servo
optimization. By programming <S_SZ_FILENAME> = "", these are overwritten by the data of the
program-based automatic post optimization.
Data type:
STRING [100]
Special functions
Function Manual, 12/2018, A5E40874099B AB
637
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
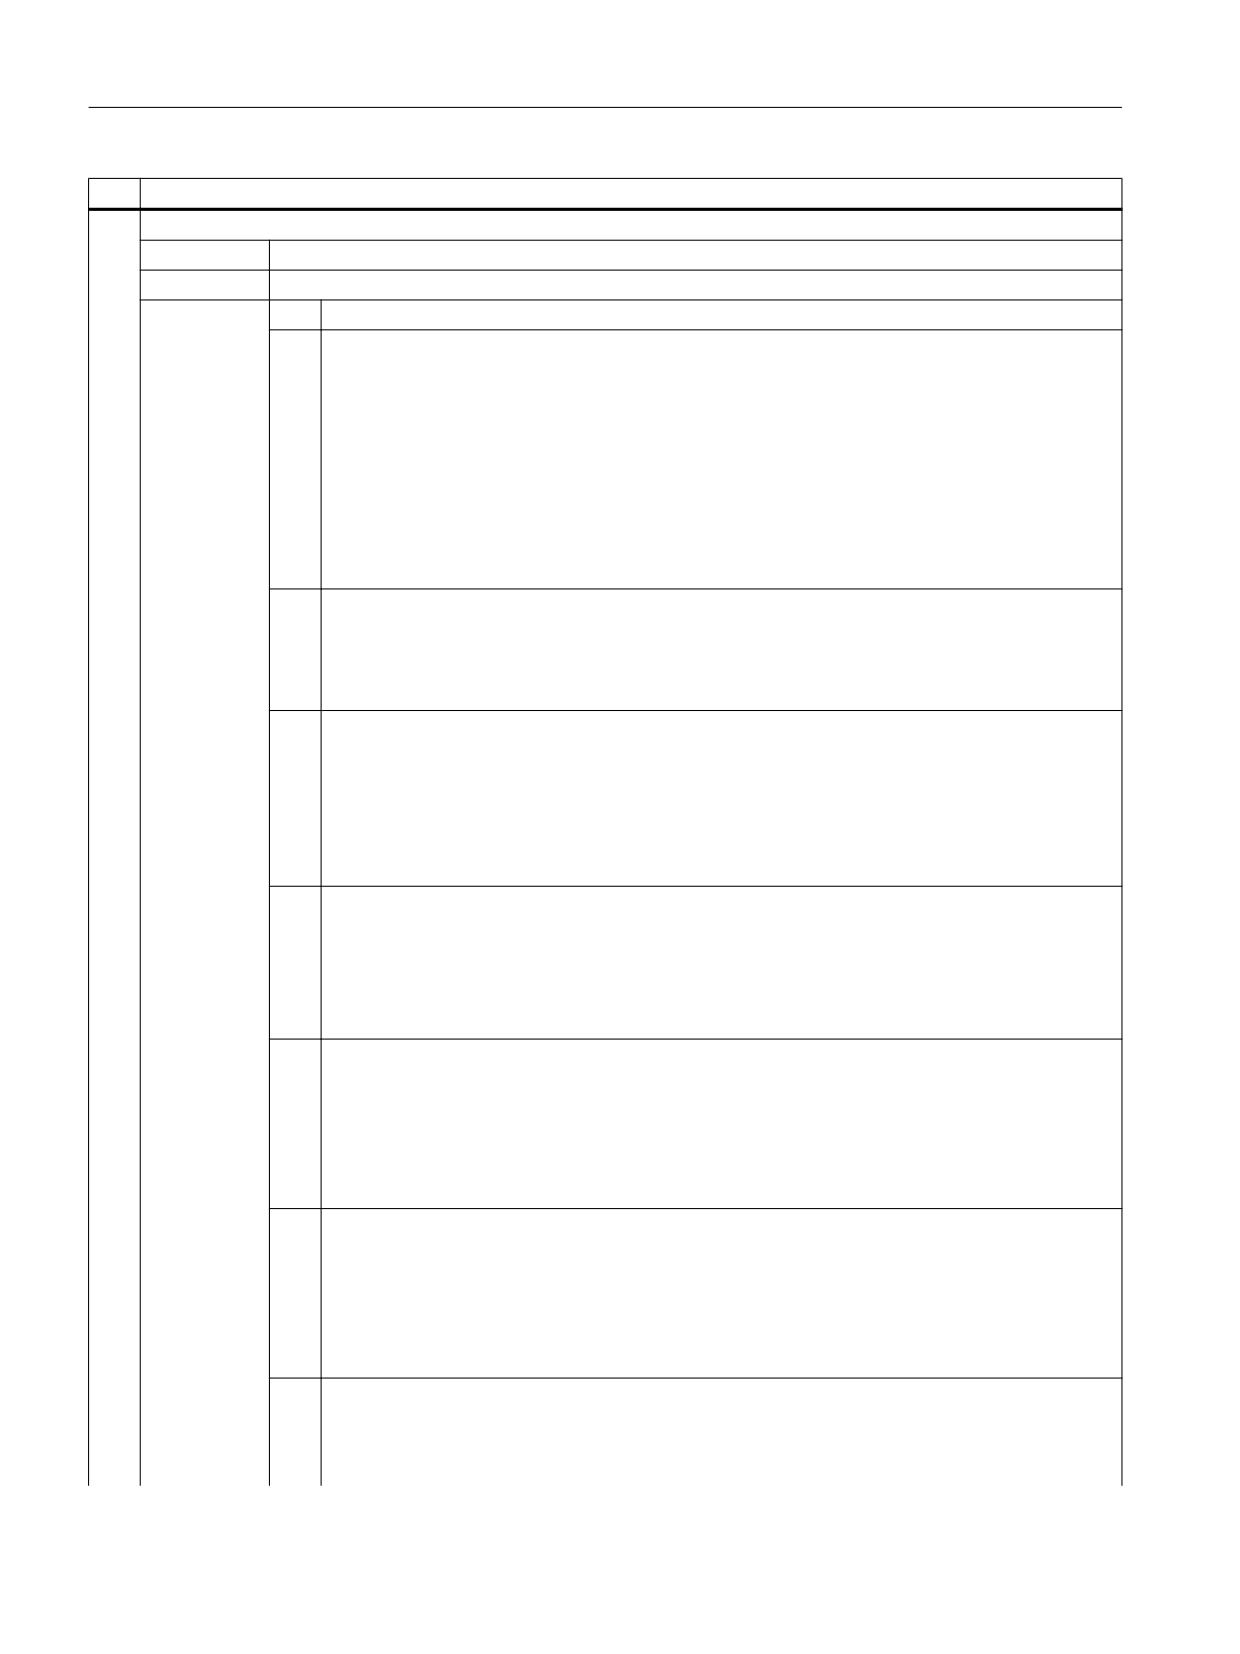
No.
Parameters
3
<S_I_CONTENT_TYPE>
Meaning:
Specifies which optimization data should be saved in the created optimization file.
Data type:
INT
Value:
0
Not defined
1
Creates an XML file in which the axis-specific optimization data for the specified axis is saved.
The following data is included:
● Measuring conditions
● Measurement results
● Optimization strategy
● Optimization results
Note:
If the axis is part of a gantry group or a master-slave coupling, then the optimization information
for the axis, includes the optimization information for all other axes of the coupling group.
2
Creates an XML file in which the data for optimization of the path interpolation is saved.
The following data is included:
● List of all involved axes.
● Strategy for optimization of the path interpolation
3
Creates a CSV file, in which the data for the frequency characteristic of the measured speed
controlled system is to be saved.
The data is stored as a 3-column table:
● Column 1: Frequency [Hz]
● Column 2: Linear amplitude
● Column 3: Phase [rad]
4
Creates a CSV file in which the data for the measured mechanical frequency response is saved.
The data is stored as a 3-column table:
● Column 1: Frequency [Hz]
● Column 2: Linear amplitude
● Column 3: Phase [rad]
5
Creates a CSV file, in which the data for the frequency response of the calculated closed speed
controller is saved.
The data is stored as a 3-column table:
Column 1: Frequency [Hz]
Column 2: Linear amplitude
Column 3: Phase [rad]
6
Creates a CSV file, in which the data for the frequency response of the calculated closed position
controller is saved.
The data is stored as a 3-column table:
Column 1: Frequency [Hz]
Column 2: Linear amplitude
Column 3: Phase [rad]
7
Creates a CSV file, in which the data for the frequency response of the measured closed speed
controller is saved.
The data is stored as a 3-column table:
Column 1: Frequency [Hz]
Special functions
638
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
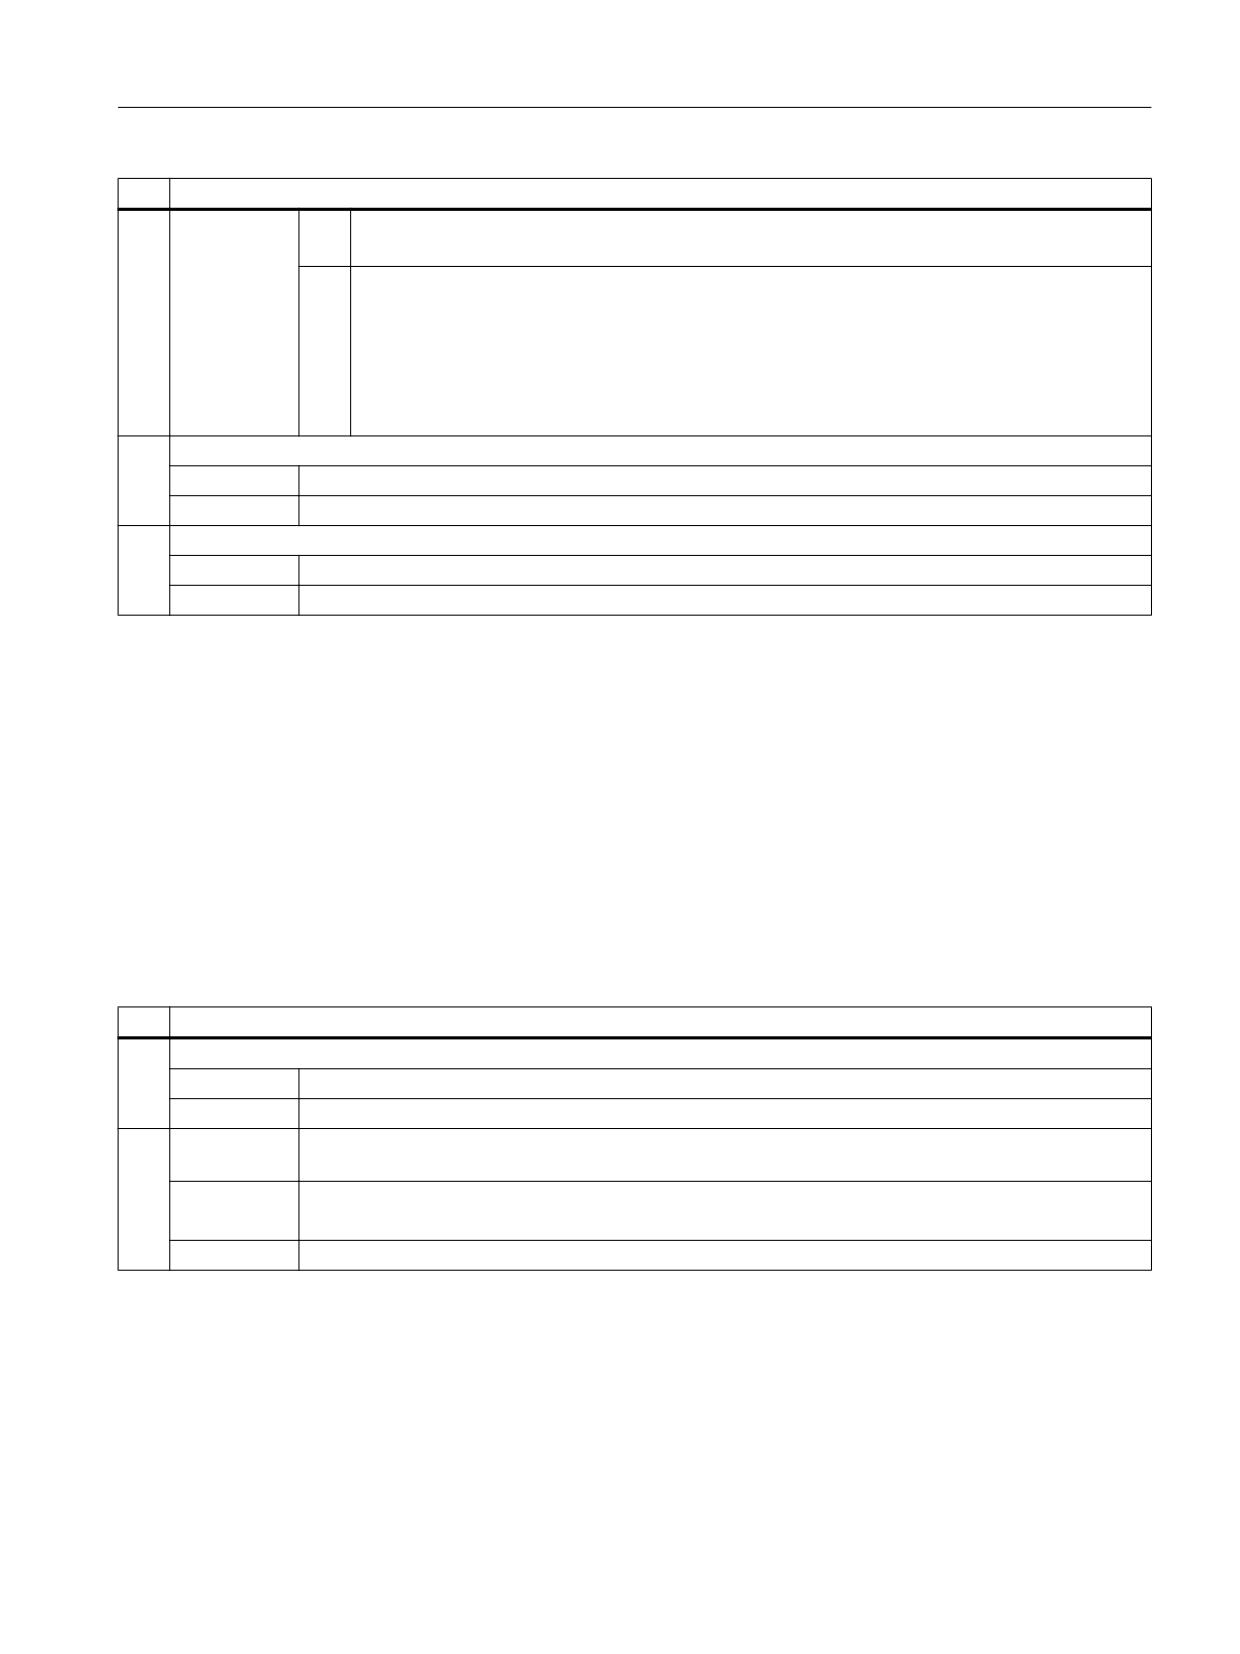
No.
Parameters
Column 2: Linear amplitude
Column 3: Phase [rad]
8
Creates a CSV file, in which the data for the frequency response of the measured closed position
controller is saved.
The data is stored as a 3-column table:
Column 1: Frequency [Hz]
Column 2: Linear amplitude
Column 3: Phase [rad]
4
<S_I_FORMATFILTER>
Meaning:
Reserved
Data type:
INT
5
<S_I_SUPPINFO>
Meaning:
Reserved
Data type:
INT
14.3.9
CYCLE758 - Change a parameter value
CYCLE758 changes individual strategy and measuring settings prior to the optimization or the
optimization results after the optimization.
Syntax
CYCLE758(<S_I_AXIS>, <S_I_PARAMID>, <S_I_MEASTYPE>, <S_I_MEASINDEX>,
<S_SZ_NEWVALUE>)
Parameters
No.
Parameters
1
<S_I_AXIS>
Meaning:
Machine axis number (not relevant for parameters that affect the optimization of the path interpolation!)
Data type:
INT
2
<S_I_PARAM
ID>
Meaning:
ID number of the parameter whose value should be changed
Parameter IDs, see "List of the parameters for the automatic servo optimization (Page 642)".
Data type:
INT
Special functions
Function Manual, 12/2018, A5E40874099B AB
639
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
No.
Parameters
3
<S_I_MEASTYPE>
Meaning:
Measuring type to which the parameter refers (relevant only for measuring parameters!)
Uniquely identifies measuring parameters with the same ID number.
Data type:
INT
Value:
1
Mechanical frequency response
2
Closed position control loop
3
Closed speed control loop
4
Speed-controlled system
5
Speed setpoint step change
4
<S_I_MEASINDEX>
Meaning:
Measurement index to which the parameter refers (relevant only for measuring parameters!)
Uniquely identifies measuring parameters with the same ID number that refer to the same measuring
type. It must be specified only when multiple measurements of a measuring type exist.
Data type:
INT
5
<S_SZ_NEWVALUE>
Meaning:
New parameter value
Data type:
STRING [20]
Value:
The value should be specified as a character string in inverted commas. The character string can
comprise a maximum of 20 characters.
Values are only permissible that correspond to the data type of the parameter to be changed - and
that lie within the valid range.
Examples:
1. The parameter to be changed is of data type BOOL (e.g. <S_I_PARAMID> = 157).
Value range: 0 (= FALSE), 1 (= TRUE)
For <S_SZ_NEWVALUE>, the following permissible character string is obtained: "true", "false",
"TRUE", "FALSE", "0" or "1"
Inadmissible character strings would be, for example: 0, 1, true, false, "2", "my_bool"
2. The parameter to be changed is of data type REAL (e.g. <S_I_PARAMID> = 34).
In this particular case, with <S_SZ_NEWVALUE> theoretically, every real number within the value
range ± (∼ 2.2*10-308 … ∼ 1.8*10+308) can be specified.
Permissible character strings are, for example: "14.1", ".0023"
Inadmissible character strings would be, for example "true", 14.1, "my_real", "R1"
Note
Gantry/master-slave coupling
If the measurement parameters of a specific following or slave axis must be changed, then in
CYCLE758 the corresponding number of this axis must be specified (not the number of the
leading or master axis, as when adding coupled axes with CYCLE752 (Page 628)).
Special functions
640
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
14.3.10
CYCLE759 - Read parameter value
CYCLE759 reads the strategy and measuring parameters and the optimized controller
parameters. This is useful for checking the file loaded with CYCLE752 prior to the optimization
or reading the results after the optimization (e.g. determined total inertia, determined gain).
Syntax
CYCLE759(<S_I_AXIS>, <S_I_PARAMID>, <S_I_MEASTYPE>, <S_I_MEASINDEX>,
<S_SZ_GUDRESULT>)
Parameters
No.
Parameters
1
<S_I_AXIS>
Meaning:
Machine axis number (not relevant for parameters that affect the optimization of the path interpolation!)
Data type:
INT
2
<S_I_PARAM
ID>
Meaning:
ID number of the parameter whose value should be read
Parameter IDs, see "List of the parameters for the automatic servo optimization (Page 642)".
Data type:
INT
3
<S_I_MEASTYPE>
Meaning:
Measuring type to which the parameter refers (relevant only for measuring parameters!)
Uniquely identifies measuring parameters with the same ID number.
Data type:
INT
Value:
1
Mechanical frequency response
2
Closed position control loop
3
Closed speed control loop
4
Speed-controlled system
5
Speed setpoint step change
4
<S_I_MEASINDEX>
Meaning:
Measurement index to which the parameter refers (relevant only for measuring parameters!)
Uniquely identifies measuring parameters with the same ID number that refer to the same measuring
type. It must be specified only when multiple measurements of a measuring type exist.
Data type:
INT
5
<S_SZ_GUDRESULT>
Meaning:
Name of the global user variable (GUD) into which the parameter value should be copied.
Note:
The specified GUD must be defined in a definition file. The data type of the GUD must match the data
type of the parameter.
Data type:
STRING [20]
Special functions
Function Manual, 12/2018, A5E40874099B AB
641
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
14.3.11
List of the parameters for the automatic servo optimization
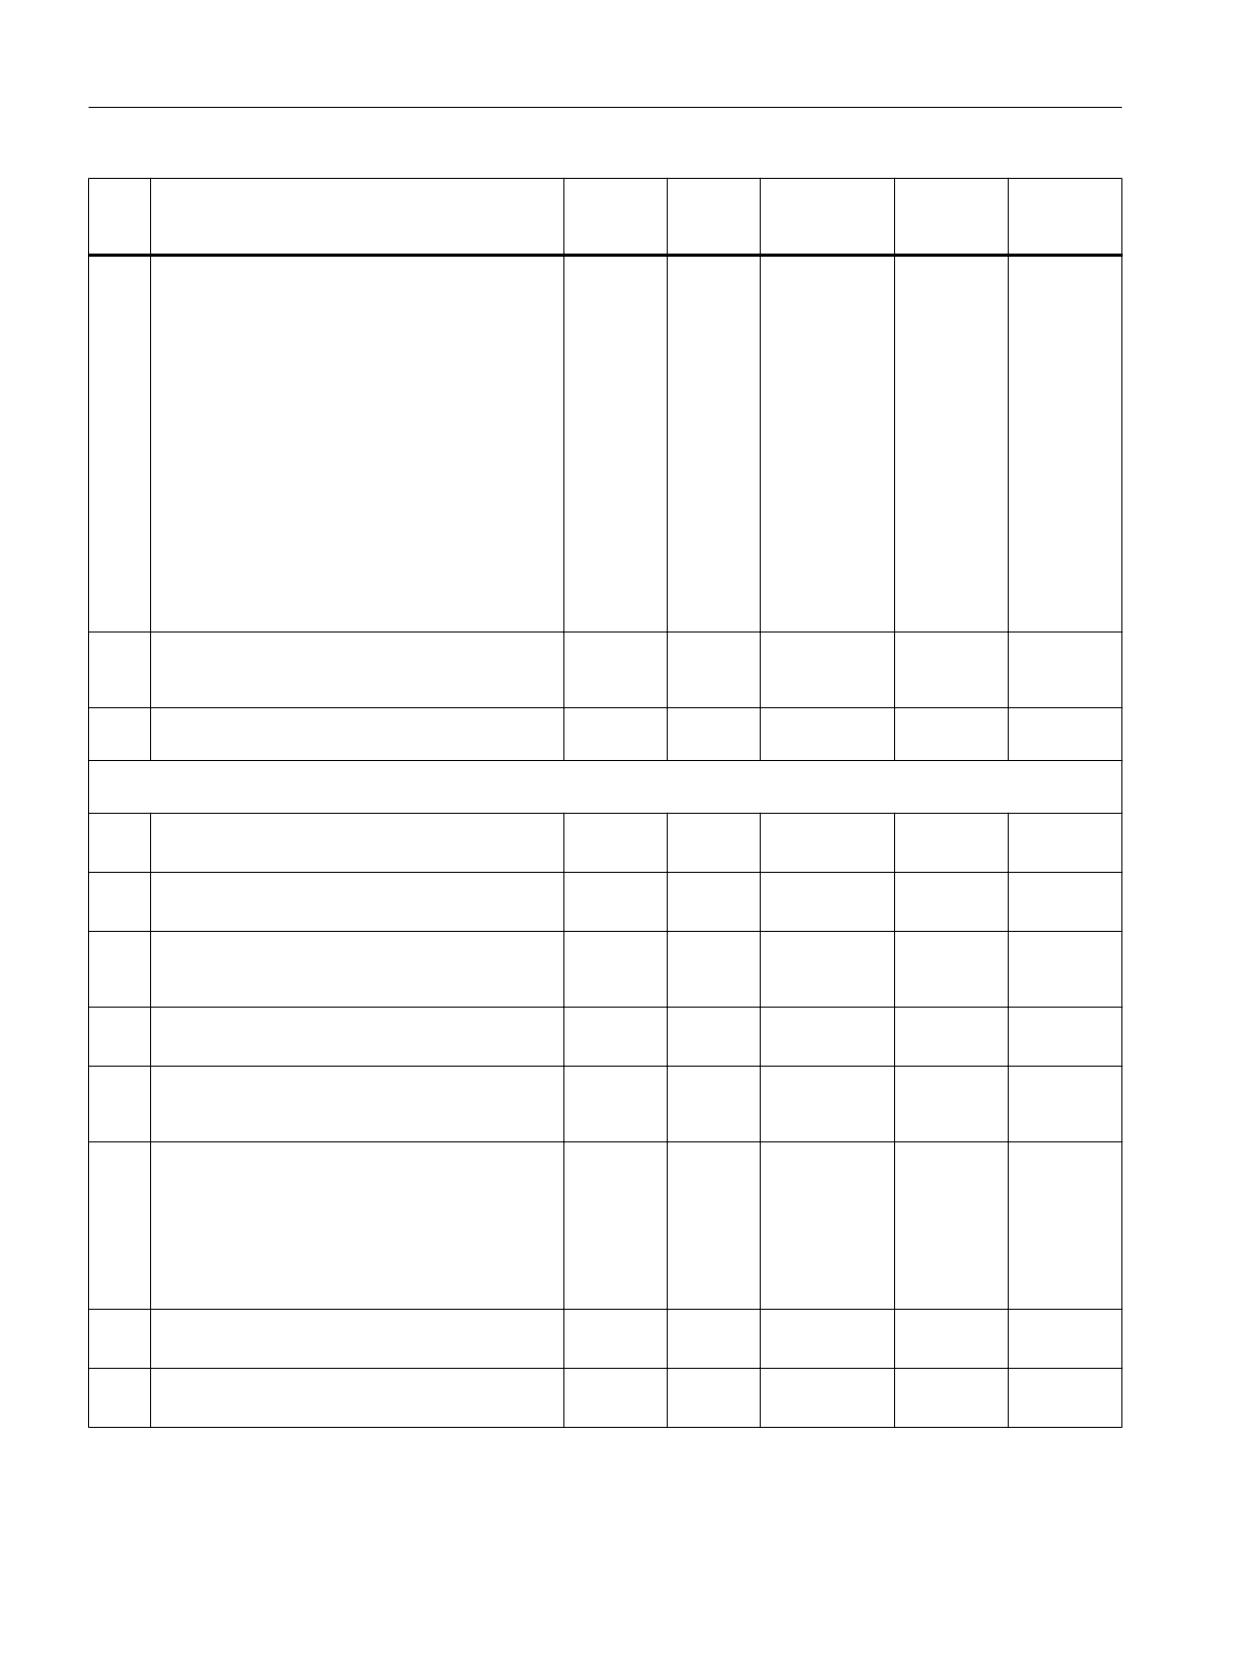
The ID of a parameter for the automatic servo optimization whose value should be changed
with CYCLE758 or read with CYCLE759 can be taken from the following table:
ID
Meaning
Unit
Data
Value range
Write
Read
type
with
with
CYCLE758
CYCLE759
Measuring conditions
001
Start position of the axis during a measurement
mm or de-
REAL
-
+
grees
002
Direction sequence during a measurement
INT
1, 2, 3, 4
+
+
●
1 = plus
●
2 = minus
●
3 = plus, then minus
●
4 = minus, then plus
003
Number of measurement repetitions for deter-
INT
0 to
+
+
mining the frequency range averaging
004
Number of time range windows in each time
INT
1 to
+
+
range averaging
005
Settling time: The wait time after the PRBS exci-
s
REAL
0 to
+
+
tation before the first measuring window is ac-
quired
006
Measurement bandwidth
Hz
REAL
Float: 0 ... fs/2
+
+
This value only determines the measurement
bandwidth (i.e. excitation and sampling frequen-
cy). This allows the frequency resolution to be
influenced.
007
Time for performing an individual measurement
s
REAL
-
+
(without repetition, ramp-up and settling time)
008
Time required to bring the speed offset to the
s
REAL
-
+
setpoint
009
Estimated travelled distance during the maxi-
m or rad
REAL
-
+
mum traversing motion in the repetition se-
quence
010
Estimated total time of the axis motion during the
s
REAL
-
+
measurement
011
Specifies the measurement type:
INT
-
+
●
1 = frequency response of the mechanical
parts
●
2 = closed position control loop
●
3 = closed speed control loop
●
4 = speed-controlled system
●
5 = speed setpoint increment
012
Specifies whether the axis motion lies within the
BOOL
0 (= FALSE)
-
+
traverse range limits
1 (= TRUE)
Special functions
642
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
ID
Meaning
Unit
Data
Value range
Write
Read
type
with
with
CYCLE758
CYCLE759
013
Specifies whether a measurement is performed
BOOL
0 (= FALSE)
-
+
with the maximum bandwidth
1 (= TRUE)
021
Amplitude of the excitation
Nm, N, m/
REAL
Dynamic
+
+
s, rad/s,
m, rad (de-
pendent
on the
measure-
ment
type1) )
022
Velocity offset
m/s or rad/
REAL
Dynamic
+
+
s (depend-
ing on
measure-
ment
type1) )
Speed control (controller)
031
Proportional gain for the speed control loop
Nms/rad
REAL
+
+
or Ns/m
032
Integral time for the speed control loop
s
REAL
+
+
033
Motor moment of inertia
kgm2
REAL
-
+
or kg
034
Total moment of inertia of the axis expressed in
kgm2
REAL
+
+
the units of the motor
or kg
035
Specifies whether the reference model is activa-
BOOL
0 (= FALSE)
+
+
ted for the speed control
1 (= TRUE)
036
Frequency of the PT2 reference model
Hz
REAL
+
+
037
Damping of the PT2 reference model
REAL
+
+
038
Ratio of the Kp proportional gain to the moment
1/s
REAL
-
+
of inertia that represents the 1/s bandwidth of the
idealized PT1-equivalent (proportional-control-
led) systems
Position control (controller)
101
Position control loop gain
1000/min
REAL
+
+
102
Specifies whether DSC (dynamic stiffness con-
BOOL
0 (= FALSE)
+
+
trol) is active
1 (= TRUE)
103
Specifies the precontrol type:
INT
0, 1, 2
+
+
●
0 = none
●
1 = speed precontrol
●
2 = speed and torque precontrol
104
Total moment of inertia of the axis as parameter
kg m2
REAL
+
+
for the torque precontrol
or kg
Special functions
Function Manual, 12/2018, A5E40874099B AB
643

T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
ID
Meaning
Unit
Data
Value range
Write
Read
type
with
with
CYCLE758
CYCLE759
105
Delay of the speed precontrol in the drive (e.g.
s
REAL
+
+
p1429)
106
Equivalent time constant of the speed control
s
REAL
+
+
loop as parameter for the speed precontrol
107
Adapted parameter value 106 for considering
s
REAL
+
+
the following effects:
● Inconsistent delays
● Changes carried out by the NC
108
Equivalent time constant of the current control
s
REAL
+
+
loop as parameter for the torque precontrol
109
Adapted parameter value 108 for considering
s
REAL
+
+
the following effects:
● Inconsistent delays
● Changes carried out by the NC
110
PT1 time constant of the axis to adapt the dy-
s
REAL
+
+
namic response
(MD32910 $MA_DYN_MATCH_TIME)
111
Time constant used for the dynamic response
s
REAL
+
+
adaptation for the axis-specific setpoint phase
filter (MD32895 $MA_DESVAL_DELAY_TIME)
112
Calculated total time constant for the positioning
s
REAL
-
+
response, including precontrol and all prefilters.
This time constant is only intended to provide
users with information. You can use it as a target
time constant for the position controller strategy
for another axis. By forcing the same total time
constant, interpolation fits already after axis op-
timization.
Position control (strategy)
151
Adaptation factor (reduction) for the optimized
REAL
0.1 ... 1.0
+
+
maximum Kv value
152
Not defined
153
Specifies the additional method for maximizing
INT
0 ... 3
+
+
the Kv value:
●
0 = none (standard)
●
1 = PT1 speed filter 2
●
2 = damping of the optimum speed controller
●
3 = PT1 speed filter 1
154
DSC
BOOL
0 (= FALSE)
+
+
1 (= TRUE)
155
Select precontrol type:
INT
0, 1, 2
+
+
●
0 = none
●
1 = speed precontrol
●
2 = speed and torque precontrol
Special functions
644
Function Manual, 12/2018, A5E40874099B AB

T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
ID
Meaning
Unit
Data
Value range
Write
Read
type
with
with
CYCLE758
CYCLE759
156
Maximum permissible Kv value
1000/min
REAL
0.1 ... 99.0
+
+
157
Specifies whether the precontrol should always
BOOL
0 (= FALSE)
+
+
be active for the axis
1 (= TRUE)
158
Setpoint for the equivalent time of the position
s
REAL
+
+
controller overall response (including precontrol
and setpoint filter)
159
Indicates whether an attempt should be made to
BOOL
0 (= FALSE)
+
+
attain the nominal equivalent time
1 (= TRUE)
160
Specifies the jerk filter technology to be selected:
INT
0 ... 2
+
+
●
0 = keep the existing jerk filter settings in the
machine data
●
1 = deactivates the jerk filter
●
2 = use jerk filter, type 2 (= sliding average
value generation)
161
Time constant (MD32410
s
REAL
0 … 0.5
+
+
$MA_AX_JERK_TIME) for type 2 jerk filter (pa-
rameter 160 = 2)
Speed control (strategy)
201
Setpoint for the amplitude reserve for the optimi-
dB
REAL
+
+
zation
202
Setpoint for the phase reserve for the optimiza-
deg
REAL
+
+
tion
203
Indicates whether the reference model should be
BOOL
0 (= FALSE)
+
+
activated
1 (= TRUE)
204
Specifies the permissible minimum value for the
s
REAL
0.001 ... 1.000
+
+
integral time of the speed control loop
205
Specifies whether the design of band-stop filters
BOOL
0 (= FALSE)
+
+
should deploy a constant reduction (for the case
1 (= TRUE)
that significantly more poles are available as fil-
ter)
206
Optimization aggressiveness of the speed con-
REAL
0 ... 1
+
+
troller
A higher value produces a better optimization re-
sult coupled with a reduction of the robustness
Special functions
Function Manual, 12/2018, A5E40874099B AB
645
T4: Automatic post optimization with AST (option) - only 840D sl
14.3 Programming
ID
Meaning
Unit
Data
Value range
Write
Read
type
with
with
CYCLE758
CYCLE759
207
Kp upper limit based on the bandwidth of a PT1-
Hz
REAL
+
+
equivalent proportionally-controlled system
Specifying a maximum speed controller band-
width is an additional rule to limit the Kp. In so
doing, the dynamic response of the speed con-
trol is limited in the form of a "Control bandwidth"
(speed controller response in the frequency do-
main). Just as before, amplitude and phase re-
serves must be maintained. As long as the am-
plitude and phase reserve permit a higher Kp,
Kp is calculated under the following assump-
tions:
● The total moment of inertia is a rigid mass.
● The speed control loop can be approximated
as a first order (PT1) lowpass filter.
208
Indicates whether a gain filter for eliminating fre-
BOOL
0 (= FALSE)
+
+
quency-specific periodic disturbances should be
1 (= TRUE)
designed and deployed
209
Frequency of the optional gain filter for eliminat-
Hz
REAL
+
+
ing frequency-specific periodic disturbances
Optimization of path interpolation (strategy)
251
Indicates whether an attempt should be made to
BOOL
0 (= FALSE)
+
+
achieve an agreement with the effective Kp value
1 (= TRUE)
252
Indicates whether an attempt should be made to
BOOL
0 (= FALSE)
+
+
achieve an agreement with the Tn integral time
1 (= TRUE)
253
The maximum proportion with which the Kp val-
REAL
0.1 ... 1.0
+
+
ue may be reduced to order to achieve an agree-
ment with the effective Kp value
254
Specifies whether non-agreements of the Kv val-
BOOL
0 (= FALSE)
+
+
ue between axes are permitted
1 (= TRUE)
255
Indicates whether the axes without precontrol or
BOOL
0 (= FALSE)
+
+
with speed precontrol must have matched refer-
1 (= TRUE)
ence models
256
Specifies the strategy for the path compensation:
INT
0, 1
+
+
●
0 = adapt the equivalent time of the control
loop with controller parameters and/or
MD32800/MD32810
●
1 = use MD32895 (time constant for the axial
setpoint phase filter) for adaptation
257
Specifies whether the precontrol should always
BOOL
0 (= FALSE)
+
+
be active for all axes in the group
1 (= TRUE)
258
Specifies whether the equivalent times should
BOOL
0 (= FALSE)
+
+
be identical for all axes
1 (= TRUE)
Special functions
646
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.5 Supplementary conditions
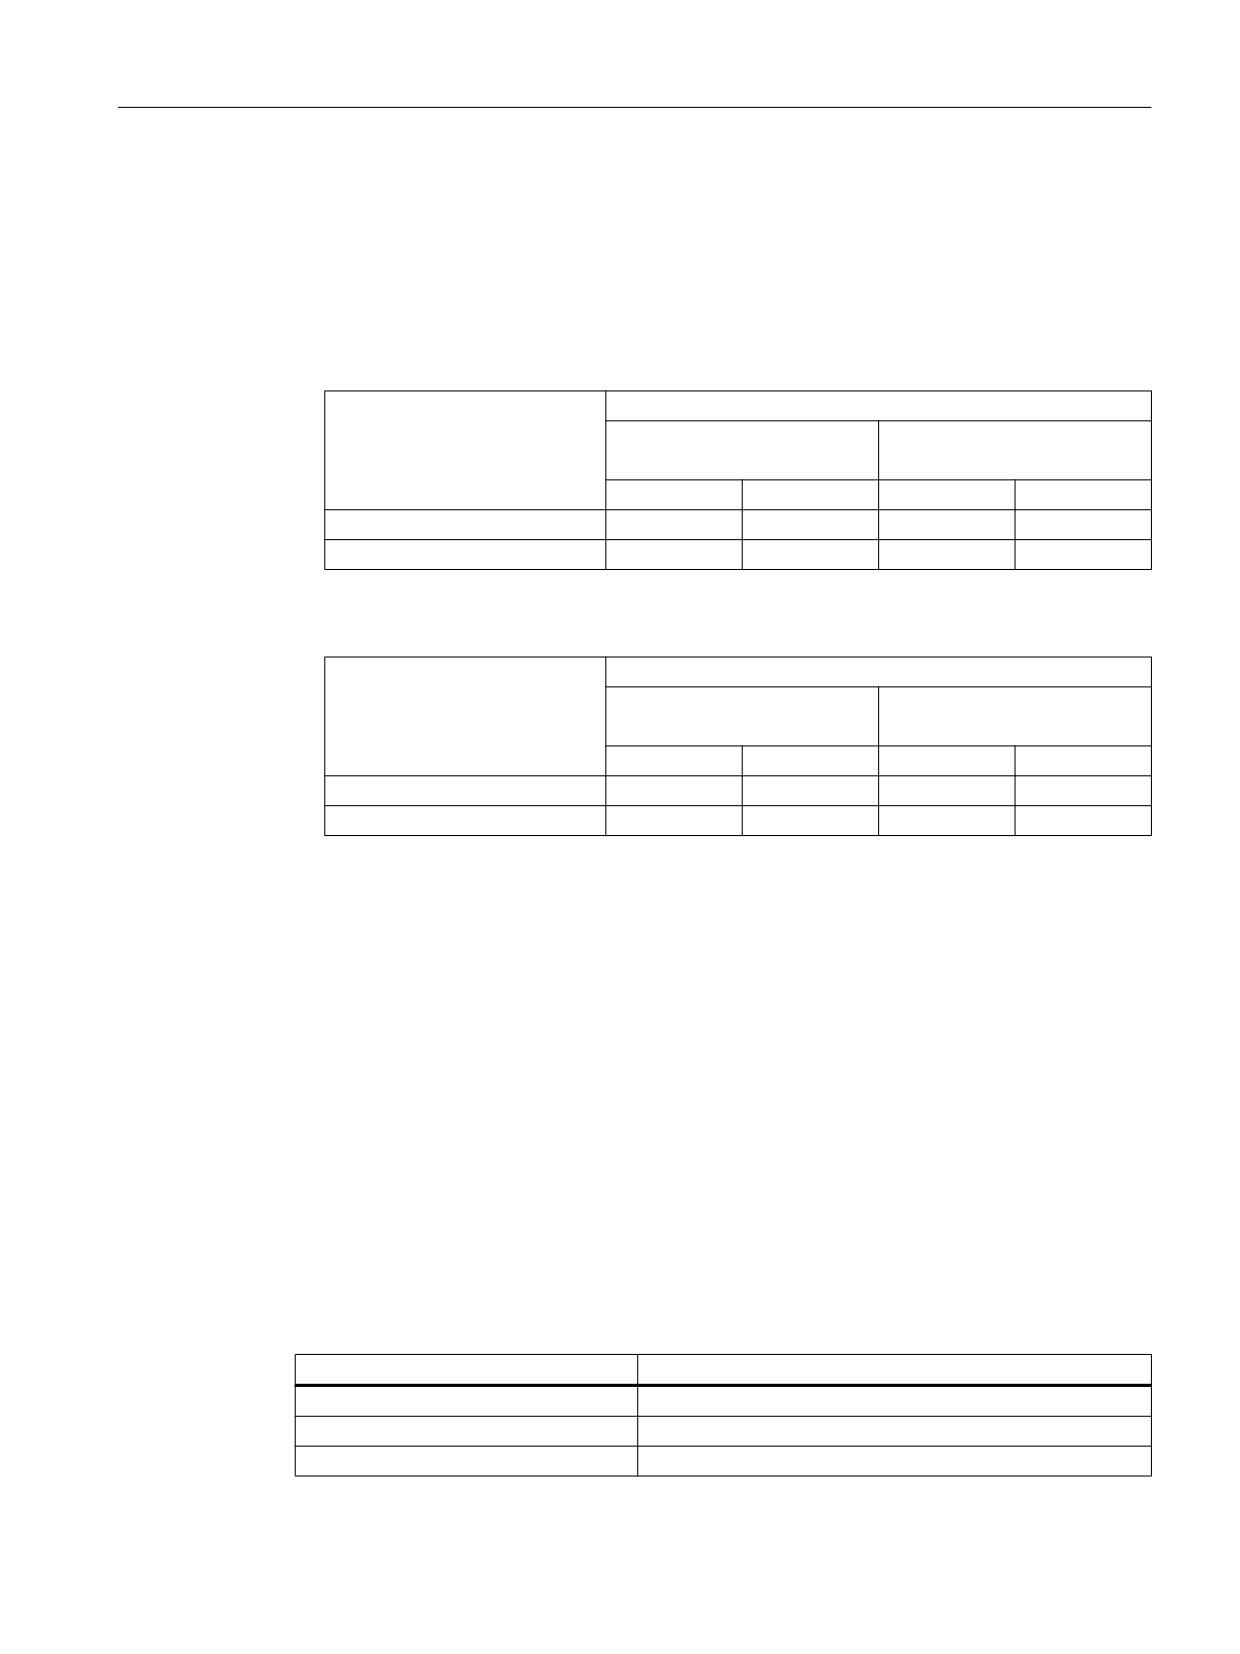
1)
The parameter value unit depends on the measurement type:
● The following measurements were carried out in the drive. This is the reason that the units
refer to the motor side. The resulting axis velocity is obtained, taking into account the
gearbox ratios or spindle pitch. The velocity specified here is only equal to the axis velocity
for linear motors and torque motors (without gearbox). Here, it should be noted that the
axis velocity is specified in the AST screen forms, e.g. mm/min. Here, the numerical values
cannot be taken from the screen forms.
Unit
Parameter 021:
Parameter 022:
Amplitude of the excitation
Velocity offset
Measurement type
Rotary motor
Linear motor
Rotary motor
Linear motor
Speed-controlled system
Nm
N
rad/s
m/s
Closed speed control loop
rad/s
m/s
rad/s
m/s
● The following measurement were carried out via the control. Here, the units refer to the
axis, i.e. to the load side. It may be necessary to convert to SI units.
Unit
Parameter 021:
Parameter 022:
Amplitude of the excitation
Velocity offset
Measurement type
Rotary axis
Linear axis
Rotary axis
Linear axis
Mechanical frequency response
rad/s
m/s
rad/s
m/s
Closed position control loop
rad
m
rad/s
m/s
14.4
Diagnostics
If an error occurs when executing cycles, then an appropriate HMI alarm is output (number
range 150001 to 150004) as well as NC alarm 61840. Based on the block number specified
in alarm 61840, the user can define which NC block with a CYCLE75x call caused the error.
Reference:
For alarm descriptions, refer to the Diagnostics Manual Alarms.
14.5
Supplementary conditions
"Automatic post optimization with AST" for active coupling
The following table lists which coupling function support the "Automatic post optimization with
AST":
Coupling function
"Automatic post optimization with AST" can be used?
Gantry axes
+
Master-slave coupling
+
Coupled motion
-
Special functions
Function Manual, 12/2018, A5E40874099B AB
647

T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
Coupling function
"Automatic post optimization with AST" can be used?
Leading value coupling
-
Electronic gear
-
Synchronous spindle
-
14.6
Examples
14.6.1
Example 1: Measuring an axis with AST default settings
The rotary axis (here: 4th axis) driven with a torque motor depends greatly on the inertia of the
clamped mass. If the load inertia changes, the axis must be measured again. No controller
values for AST should be overwritten; the optimization, however, is determined with new
measurements. The results, such as the complete inertia, can be read with CYCLE759. The
newly calculated values also indicate whether the controlled system has changed. In specific
cases, switching can be made to predefined controller data sets or the acceleration changed.
The AST default setting includes the speed and position controller optimization with "normal"
optimization objective. The determined controller data is, however, not activated in this
example.
Programming
Definition of global user variables (GUD)
To read out the complete moment of inertia, a new type CHAN REAL variable must be defined
in file MGUD.DEF (it is possible that this file must be newly created):
; Definition of GUD to read out the total moment of inertia:
DEF CHAN REAL _AST_R_ESTINERTIA
Optimization cycle
Note
In the following program example, those cycle calls required for the measurement are
highlighted bold.
Any cycle calls not highlighted are optional.
DEF INT myaxiswithnewload=4
; Switch to a safe data set.
; Traverse axis to the safe position / home position.
; Is the optimization strategy set from the user interface?
; Is a destination data set (DDS) available that may be overwritten?
; Open the optimization session.
Special functions
648
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
CYCLE751(1)
; Optimize axis 4: Optimization with a selected strategy based on a new
measurement.
; Optimization with default values (the selection from the AST user
interface is not used).
; No path interpolation, no values are written by AST.
CYCLE752(myaxiswithnewload,1,false)
; Save the original state in a file.
CYCLE755(1,"restorepoint1")
; Start the optimization without activating the results.
CYCLE751(4)
; Save the optimization data in an XML file.
CYCLE757(myaxiswithnewload,"axis_retuned.xml",1,,)
; Export the speed-controlled system.
CYCLE757(myaxiswithnewload,"speedctrlplant.csv",3,,)
; Fetch the inertia.
CYCLE759(myaxiswithnewload,34,,,"_AST_R_ESTINERTIA")
; If required check the optimization results, and then activate.
; Do not activate the results.
; Use predefined parameter sets.
; Close the optimization session.
CYCLE751(2)
; Switch to the newly optimized DDS or select the predefined DDS depending
on the load inertia.
; Limit the acceleration depending on the new inertia.
M17
Special functions
Function Manual, 12/2018, A5E40874099B AB
649
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
14.6.2
Example 2: Reoptimize the speed controller of an axis
The controller setting of the rotary axis (here: 4th axis), which is driven by a torque motor,
depends on the clamping equipment and the load moment of inertia. If the clamping equipment
or the load inertia changes, the axis must be measured again. A new controller parameter set
must be determined (a DDS will be overwritten), otherwise the axis would be unstable because
of the new resonances. New current setpoint filters must probably by set. Only the speed
controller is reoptimized. Because the position control remains identical and the precontrol
should not be changed, a similar bandwidth of the speed controller should be attained again.
For this purpose, a target bandwidth can be selected in the speed controller optimization
strategy. This is set to 100 Hz for the "normal compensation" optimization objective. If the new
load inertia and the clamping make many filters necessary and the ratio from the load inertia /
motor inertia is large, this objective may possibly not be achieved. In this case, a message is
issued. And the axis machine data is still set correctly from the first optimization (initial
commissioning). This means that the precontrol mode (MD32620 $MA_FFW_MODE), DSC
(MD32640 $MA_STIFFNESS_CONTROL_ENABLE), position controller gain (MD32200
$MA_POSCTRL_GAIN) and equivalent time precontrol (MD32800
$MA_EQUIV_CURRCTRL_TIME or MD32810 $MA_EQUIV_SPEEDCTRL_TIME) are set
correctly so that the loop interpolation is correct.
The results of the reoptimization, such as the complete inertia, can be read with CYCLE759.
The newly optimized speed controller is written to another data set. The path interpolation is
not considered here, because it is assumed that the precontrol data does not change
significantly or another axis has a larger time constant in MD32800
$MA_EQUIV_CURRCTRL_TIME. The optimization strategy for axis and speed controllers,
selected from the user interface, is deployed and was stored in the XML file for this axis (/user/
sinumerik/nck/data/optimization/AST_AX4_A1….xml).
Special functions
650
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
Preparation
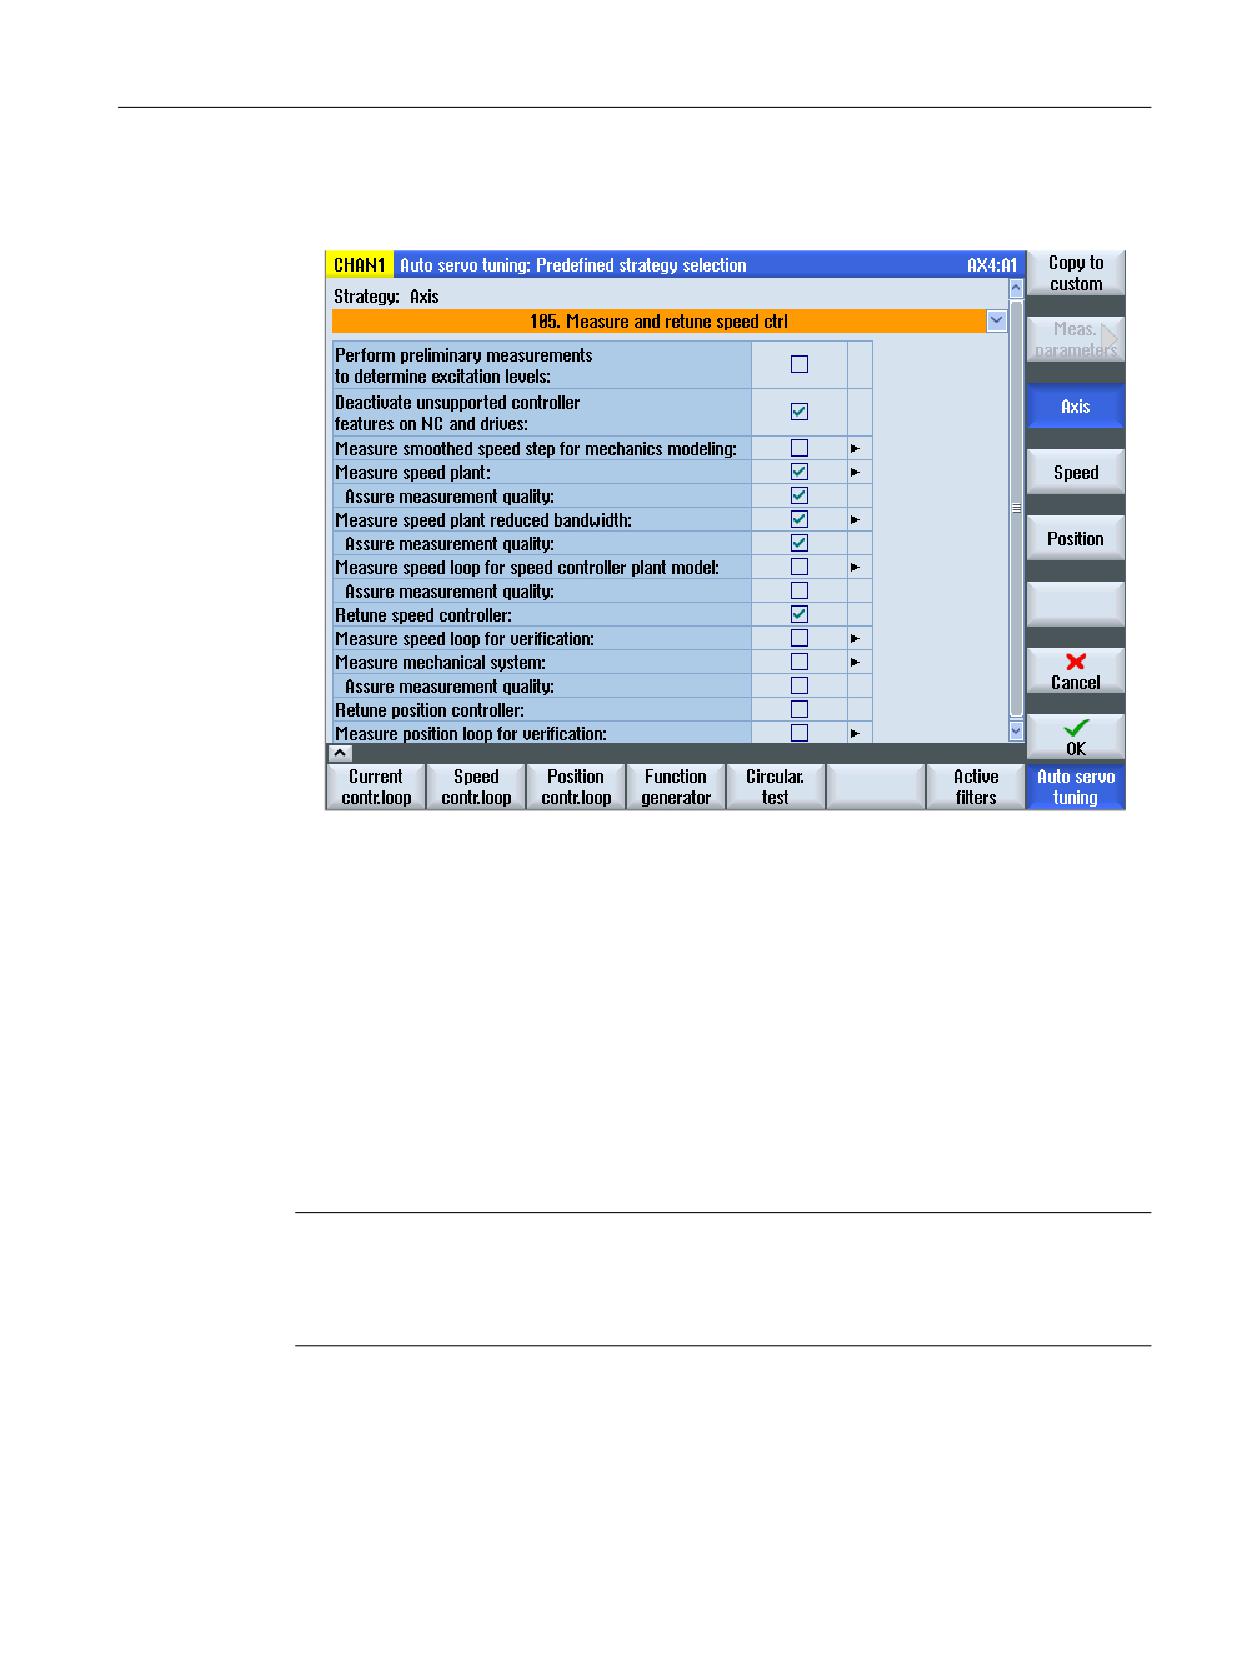
● Select optimization strategy 105 from the user interface:
● If necessary, change the optimization objective (fast, moderate, robust) with the "Speed"
softkey.
Programming
Definition of global user variables (GUD)
To read out the complete moment of inertia, a new type CHAN REAL variable must be defined
in file MGUD.DEF (it is possible that this file must be newly created):
; Definition of GUD to read out the total moment of inertia:
DEF CHAN REAL _AST_R_ESTINERTIA
Optimization cycle
Note
In the following program example, those cycle calls required for the reoptimization are
highlighted bold.
Any cycle calls not highlighted are optional.
DEF INT myaxiswithnewload=4
; Switch to a safe data set.
Special functions
Function Manual, 12/2018, A5E40874099B AB
651
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
; Traverse axis to the safe position / home position.
; Is the optimization strategy set from the user interface?
; Is a destination data set (DDS) available that may be overwritten?
; Open the optimization session.
CYCLE751(1)
; Optimize axis 4: Optimization with a selected strategy based on a new
measurement.
; Add axis 4.
; Accept the optimization strategy from the standard optimization file (XML
file).
; The axis is not considered for an optimization of the path interpolation.
CYCLE752(myaxiswithnewload,3,false)
; Remove the current DDS from the data set list.
CYCLE754(myaxiswithnewload,2,2,-1)
; Add DDS3 to the data set list and overwrite after optimization.
CYCLE754(myaxiswithnewload,1,2,3)
; Save the original state in a file.
CYCLE755(1,"restorepoint1")
; Start the optimization by activating the results.
; CYCLE751(3)
; Start optimization without activation of the results, if necessary, check
the results first.
CYCLE751(4)
; Save the optimization data in an XML file.
CYCLE757(myaxiswithnewload,"axis_retuned.xml",1,,)
; Export the speed-controlled system.
CYCLE757(myaxiswithnewload,"speedctrlplant.csv",3,,)
; The inertia can be used to limit the acceleration:
; Fetch the inertia.
CYCLE759(myaxiswithnewload,34,,,"_AST_R_ESTINERTIA")
; If required check the optimization results, and then activate.
; Activate result:
; Activate axis-optimum results.
Special functions
652
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
; Save boot files.
CYCLE756(myaxiswithnewload,2,1)
; Close the optimization session.
CYCLE751(2)
; Switch to the newly optimized DDS or limit the acceleration depending on
the new inertia.
M17
14.6.3
Example 3: Reoptimize the speed controller and the position controller of an axis
The controller setting of the rotary axis (here: 4th axis), which is driven by a torque motor,
depends on the clamping equipment and the load moment of inertia. If the clamping equipment
or the load inertia changes, the axis must be measured again. New current setpoint filters must
probably by set. The speed controller must be reoptimized. Because it is not known whether
the low-frequency behavior has changed, the position controller must also be reoptimized and
the associated mechanical frequency response measured.
The results, such as the complete inertia, can be read with CYCLE759. The newly optimized
speed controller is written to another data set. The newly optimized position controller can be
written to any desired axis parameter set. The correct path interpolation is guaranteed by a
target value for the (precontrolled) positioning behavior being specified in accordance with the
previously optimized axes. The optimization strategy for axis and speed controllers, selected
from the user interface, is deployed and was stored in the XML file for this axis (/user/sinumerik/
nck/data/optimization/AST_AX4_A1….xml).
Special functions
Function Manual, 12/2018, A5E40874099B AB
653
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
Preparation
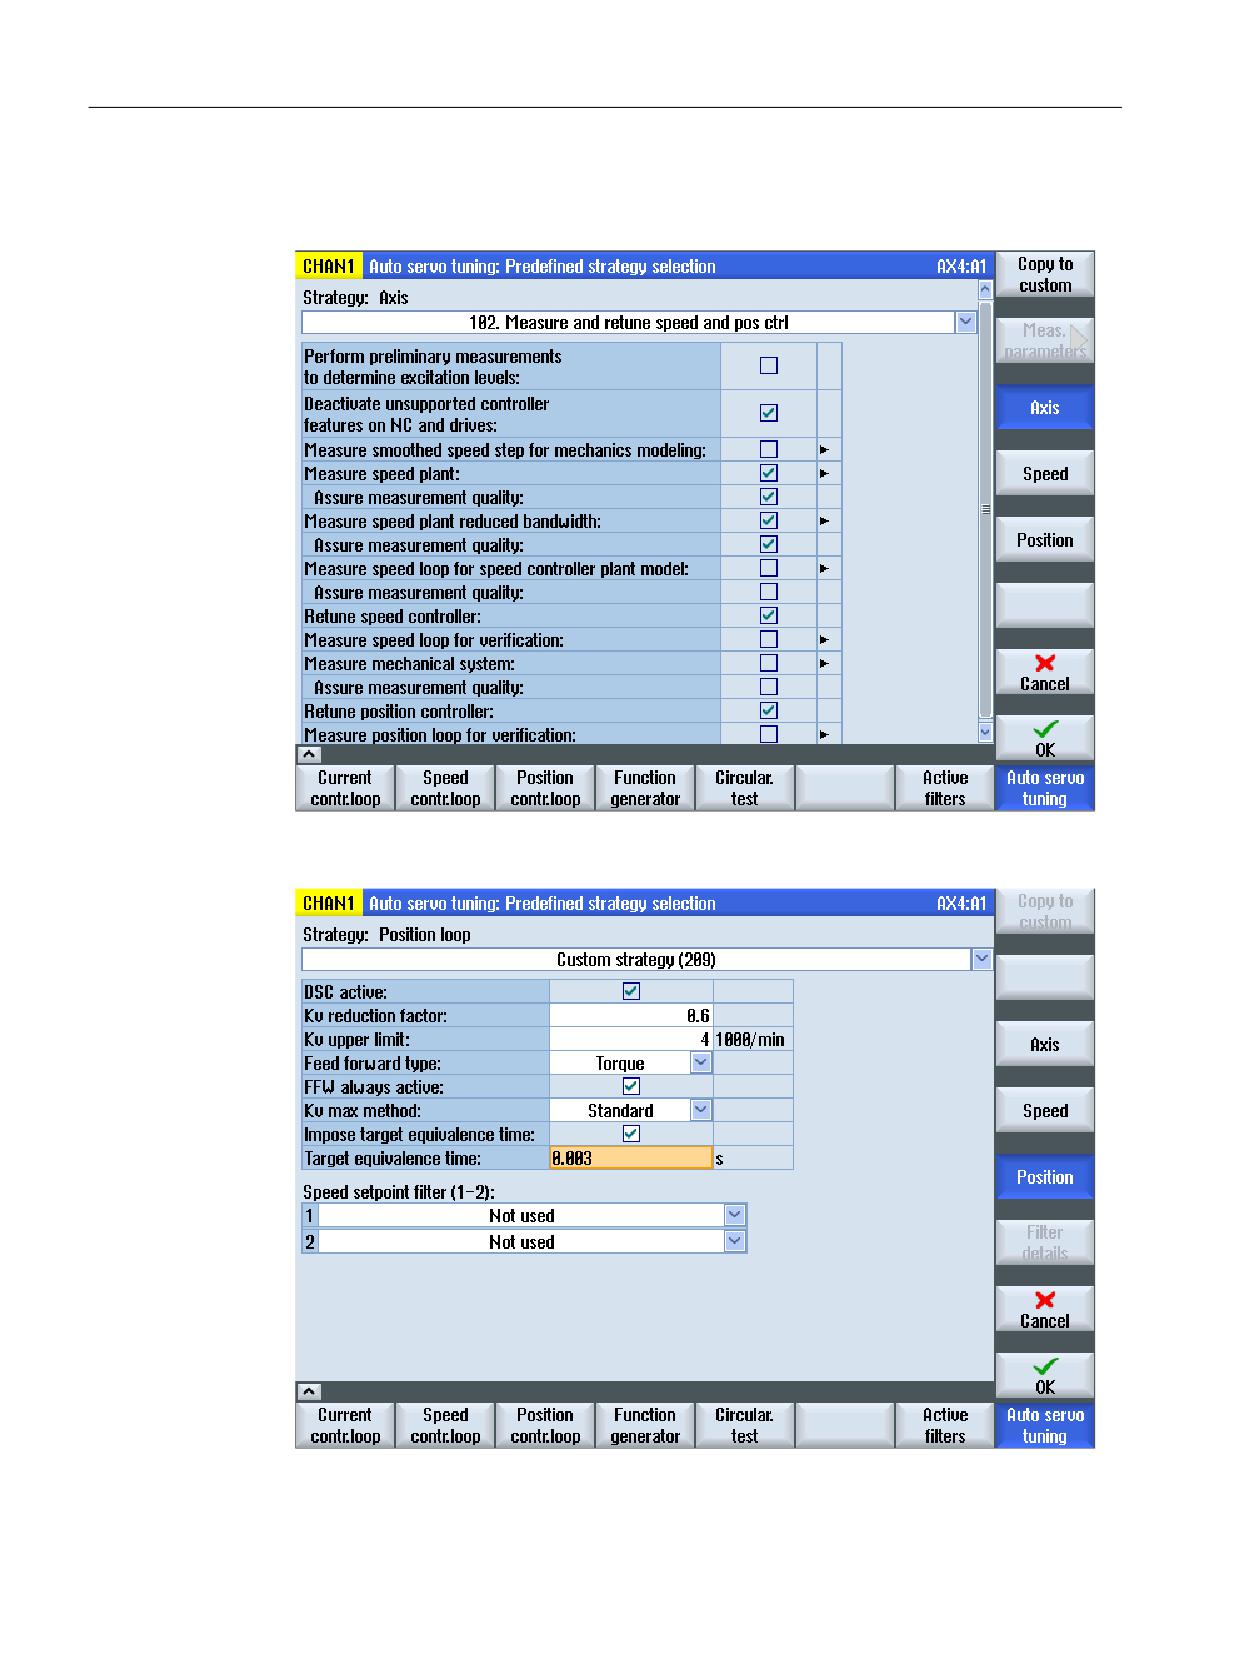
● Select optimization strategy 102 from the user interface:
● Press the "Position" softkey to display the window for adaptation of the position controller
strategy and select "User-defined strategy 209":
Special functions
654
Function Manual, 12/2018, A5E40874099B AB

T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
● Select the "Force equivalent time target value" option.
Note
The "Force equivalent time target value" option is set, when in addition to the speed
controller, the position controller is also reoptimized, and despite an equivalent time of the
precontrol specified, the path interpolation should not be reoptimized.
To ensure the correct path interpolation, an equivalent time can be specified. This should
correspond to the equivalent time of the axes previously optimized on the path.
● Take the equivalent time (MD32800 $MA_EQUIV_CURRCTRL_TIME or MD32810
$MA_EQUIV_SPEEDCTRL_TIME depending on MD32620 $MA_FFW_MODE) from the
other axes (here, 3 ms).
● The following parameters must be set in the servo parameter set:
- Precontrol equivalent time (MD32800 $MA_EQUIV_CURRCTRL_TIME) = 3 ms
- Position controller gain (MD32200 $MA_POSCTRL_GAIN)
Note
For the automatic operation, the servo parameter set with the appropriate path-optimum
values must then be selected in the other axes (here: with equivalent time = 3 ms).
Programming
Definition of global user variables (GUD)
To read out the complete moment of inertia, a new type CHAN REAL variable must be defined
in file MGUD.DEF (it is possible that this file must be newly created):
; Definition of GUD to read out the total moment of inertia:
DEF CHAN REAL _AST_R_ESTINERTIA
Optimization cycle
Note
In the following program example, those cycle calls required for the reoptimization are
highlighted bold.
Any cycle calls not highlighted are optional.
DEF INT myaxiswithnewload=4
; Switch to a safe data set.
; Traverse axis to the safe position / home position.
; Strategy settings were made from the user interface: target value for the
equivalent time!
; Is a destination data set (DDS) available that may be overwritten?
Special functions
Function Manual, 12/2018, A5E40874099B AB
655
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
; Open the optimization session.
CYCLE751(1)
; Optimize axis 4: Optimization with a selected strategy based on a new
measurement.
; Add axis 4.
; Accept the optimization strategy from the standard optimization file (XML
file).
; The axis is not considered for an optimization of the path interpolation.
CYCLE752(myaxiswithnewload,3,false)
; Remove the current DDS from the data set list.
CYCLE754(myaxiswithnewload,2,2,-1)
; Add DDS3 to the data set list and overwrite after optimization.
CYCLE754(myaxiswithnewload,1,2,3)
; Axis: Add parameter set 4 to the data set list and overwrite after
optimization.
CYCLE754(myaxiswithnewload,1,1,3)
; Save the original state in a file.
CYCLE755(1,"restorepoint1")
; Start the optimization by activating the results.
; CYCLE751(3)
; Start optimization without activation of the results, if necessary, check
the results first.
CYCLE751(4)
; Save the optimization data in an XML file.
CYCLE757(myaxiswithnewload,"axis_retuned.xml",1,,)
; Export the speed-controlled system.
CYCLE757(myaxiswithnewload,"speedctrlplant.csv",3,,)
; The inertia can be used to limit the acceleration:
; Fetch the inertia.
CYCLE759(myaxiswithnewload,34,,,"_AST_R_ESTINERTIA")
; If required check the optimization results, and then activate.
; Activate result:
; Activate axis-optimum results.
Special functions
656
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
; Save boot files.
CYCLE756(myaxiswithnewload,2,1)
; Close the optimization session.
CYCLE751(2)
; Switch to the newly optimized DDS.
; Has Kv been optimized in the current parameter set?
; The equivalent time of the precontrol was forced by the strategy.
; For path interpolation, all axes must select the correct servo parameter
set.
; Limit the acceleration depending on the new inertia.
M17
14.6.4
Example 4: Reoptimization of the path interpolation
For a 5-axis machine, the rotary axis with torque motor (here: 4th axis) must position very
accurate and participate in the path interpolation. The changes of the clamping situation and
the inertia are completely unknown or so large that even large changes of the equivalent time
(also power controller) are expected. The unknown equivalent time means that the path
interpolation must be tested and compensated again after the axis optimization.
Only the rotary axis (workpiece-dependent) should be reoptimized. The other axes need to be
adapted in the precontrol only when the dynamic response of the rotary axis has changed
significantly. The rotary axis has several DDS. A safe data set that has a stable setting for
clamping the workpieces is selected. It must be considered that the mass inertia to be clamped
is not known. Consequently, the maximum inertia must be used for the calculation.
New current setpoint filters must probably be set for the rotary axis. The speed controller must
be reoptimized. Because it is not known whether the low-frequency behavior has changed,
the position controller must also be reoptimized and the associated mechanical frequency
response measured.
The results, such as the complete inertia, can be read with CYCLE759. The newly optimized
speed controller is written to another data set. The newly optimized position controller can be
written to any desired axis parameter set. The correct path interpolation is guaranteed by all
axes involved by being optimized by AST and now, after the reoptimization of the axis, the
path interpolation optimization is performed again by AST. The optimization strategy for axis
and speed controller, selected from the user interface, is deployed and was stored in the XML
file for this axis (/user/sinumerik/nck/data/optimization/AST_AX4_A1….xml). The path
optimization strategy set from the user interface is deployed and stored in the XML file for the
optimization of the path interpolation.
Special functions
Function Manual, 12/2018, A5E40874099B AB
657
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
Preparation
● No equivalent time is forced, namely, the predefined strategies for the position controller
optimization are deployed:
● For the path interpolation, the strategy (all equivalent times identical or use MD32895
$MA_DESVAL_DELAY_TIME) was already chosen for the first optimization.
Special functions
658
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
The following selection sets the balancing times (in MD32800
$MA_EQUIV_CURRCTRL_TIME or MD32810 $MA_EQUIV_SPEEDCTRL_TIME) of all
involved axes to the largest time constant:
● The following questions must be answered:
- Which axis parameter set may be reparameterized (for the path interpolation)?
- May the first axis parameter set be overwritten?
- Does the spindle need to be part of the path interpolation?
- If the thread cutting should also run with this axis configuration, parameter set 2 for the
axes and the gear stages in the spindle (parameter set 2 ... 6) may need to be optimized.
● Save the original path data!
Programming
Definition of global user variables (GUD)
To read out the complete moment of inertia, a new type CHAN REAL variable must be defined
in file MGUD.DEF (it is possible that this file must be newly created):
; Definition of GUD to read out the total moment of inertia:
DEF CHAN REAL _AST_R_ESTINERTIA
Optimization cycle
Note
In the following program example, those cycle calls required for the reoptimization are
highlighted bold.
Any cycle calls not highlighted are optional.
DEF INT myaxiswithnewload=4
; Switch to a safe data set.
; Traverse axis to the safe position / home position.
; Strategy settings were made from the user interface: target value for the
equivalent time!
; Is a destination data set (DDS) available that may be overwritten?
Special functions
Function Manual, 12/2018, A5E40874099B AB
659
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
; Each axis was already optimized once with AST (using the screen forms).
; As a consequence, the standard file for CYCLE752 exists for each axis.
; Open the optimization session.
CYCLE751(1)
; Optimize axis 4, with path interpolation.
; Select strategy:
; Add axis 4.
; Accept the optimization strategy from the standard optimization file (XML
file).
; The axis is considered for an optimization of the path interpolation.
CYCLE752(myaxiswithnewload,3,true)
; Measure axis 4 again and reoptimize, save the boot files.
CYCLE753(myaxiswithnewload,3,1)
; Add axis 1 because of the path interpolation.
CYCLE752(1,3,true)
; Axis 1, only post-optimize path interpolation.
CYCLE753(1,1,true)
; Add axis 2 because of the path interpolation.
CYCLE752(2.3,true)
; Axis 2, only post-optimize path interpolation.
CYCLE753(2,1,true)
; Add axis 3 because of the path interpolation.
CYCLE752(3.3,true)
; Axis 3, only post-optimize path interpolation.
CYCLE753(3,1,true)
; Add axis 6 because of the path interpolation.
CYCLE752(6,3,true)
; Axis 6, only post-optimize path interpolation.
CYCLE753(6,1,true)
; Remove the current DDS from the data set list.
CYCLE754(myaxiswithnewload,2,2,-1)
; Add DDS3 to the data set list and overwrite after optimization.
CYCLE754(myaxiswithnewload,1,2,3)
; Axis: Add parameter set 4 to the data set list and overwrite after
optimization.
CYCLE754(myaxiswithnewload,1,1,3)
Special functions
660
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
; Save the original state in a file.
CYCLE755(1,"restorepoint1")
; Start the optimization by activating the results.
CYCLE751(3)
; Save the optimization data in an XML file.
CYCLE757(myaxiswithnewload,"axis_retuned.xml",1,,)
; Save the measurement data of the speed controlled system to file.
CYCLE757(myaxiswithnewload,"speedctrlplant.csv",3,,)
; Save the result of the path optimization to file.
CYCLE757(1,"path_retuned.xml",2,0,0)
; Fetch the inertia.
CYCLE759(myaxiswithnewload,34,,,"_AST_R_ESTINERTIA")
; Close the optimization session.
CYCLE751(2)
; Switch to the newly optimized DDS.
; Kv has been optimized; switch to the appropriate parameter set.
; The path interpolation has been reoptimized.
; Limit the acceleration in axis 4 depending on the new inertia.
M17
14.6.5
Example 5: Reoptimize the speed control loop to eliminate known periodic
disturbance frequencies.
This example shows how the speed controller from the part program is reoptimized without
new measurement. The objective of the reoptimization is to minimize vulnerability to known
process-related periodic disturbance frequencies. The path interpolation is not reoptimized in
this example because the optimization strategy for the position controller provides a dynamic
customization by setting an equivalent time.
Special functions
Function Manual, 12/2018, A5E40874099B AB
661
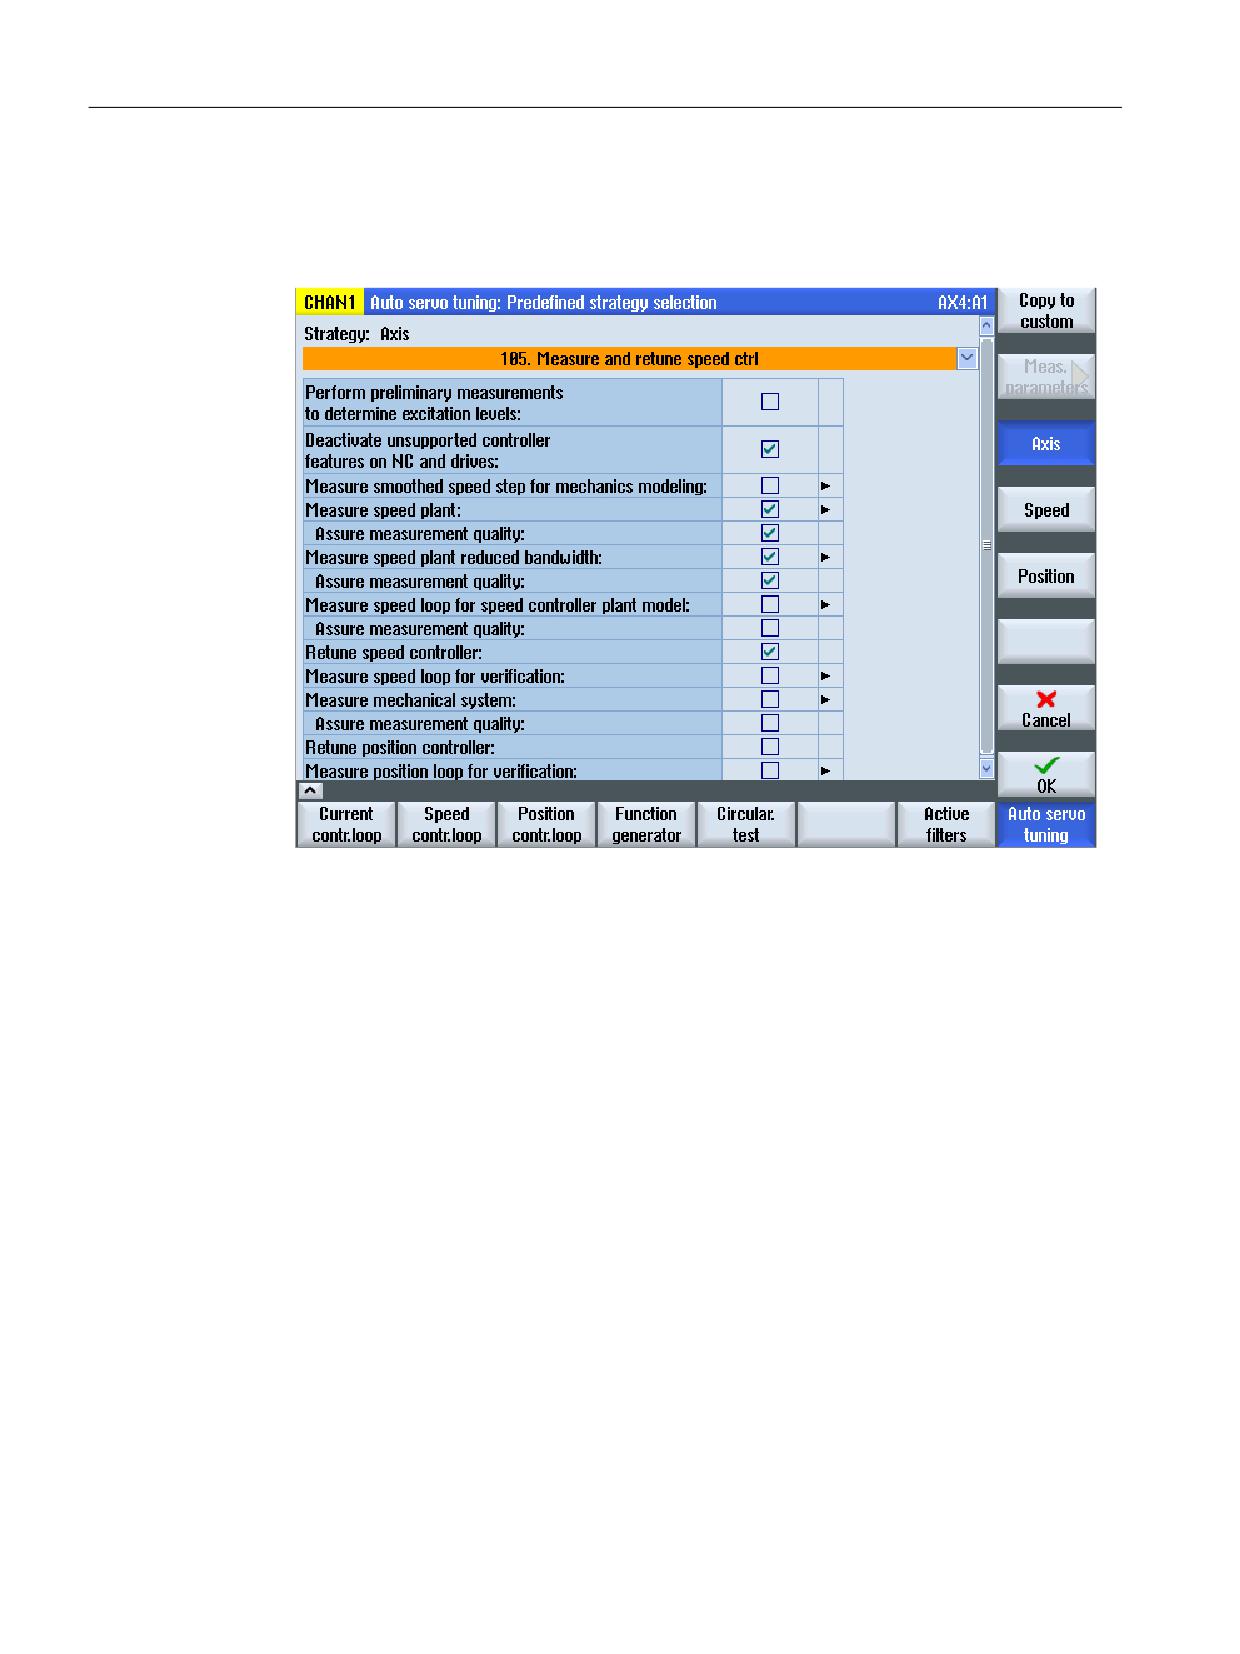
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
Preparation
In the simplest case, only a speed controller optimization is necessary:
● Select optimization strategy 105 from the user interface:
Programming
DEF INT myAxis=4
; Open the optimization session.
CYCLE751(1)
; Add axis.
; The optimization data is loaded from the standard optimization file.
; The axis is not considered for an optimization of the path interpolation.
CYCLE752(myAxis,3,false,)
; The axis dynamic response is not measured again.
; The axis is reoptimized on the basis of the loaded measurement results
and the currently valid optimization strategy.
CYCLE753(myAxis,2,)
; Activate the use of the gain filter.
CYCLE758(myAxis,208,,,"true" )
; Gain filter: set the optimum frequency to 40 Hz.
Special functions
662
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
CYCLE758(myAxis,209,,,"40.0" )
; Perform the optimization.
CYCLE751(3)
; Save the axis-specific optimization data for the offline analysis.
CYCLE757(myAxis,"AX1_TEMP_40HZ.XML",1,,)
; For known periodic disturbance frequencies (40 Hz):
; Deactivate the use of the gain filter.
CYCLE758(myAxis,208,,,"false" )
; Perform the optimization.
CYCLE751(3)
; Close the optimization session.
CYCLE751(2)
; For normal broadband disturbances:
M17
14.6.6
Example 6: Measuring an axis without optimization
By selecting a strategy, which does not carry out any optimization, then the axis can be
automatically measured. This can be used to diagnose mechanical changes. These can
involve:
● Load weight
● Component stiffness
Using the automatic measurement, it can also be checked as to whether the control loop has
the same response as when the system was originally delivered, for example. This AST
strategy then supplies the actual measurement of the closed loop in the CSV format.
The following data can be automatically measured and exported:
● Speed controlled system
● Closed speed control loop (calculated and/or check measurement)
● Mechanical frequency response (if there are 2 encoders)
● Closed position control loop (calculated and/or check measurement of the position control
loop)
Special functions
Function Manual, 12/2018, A5E40874099B AB
663
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
Preparation
1. Select optimization strategy 109 from the user interface:
2. Measure and check controller settings.
3. Accept measurement results.
4. Save data under a new name (e.g. RESULT_STRATEGY109_AX1.xml) as user-defined
file (so that the standard optimization file is not overwritten).
The user-defined file is saved as standard to directory /user/sinumerik/hmi/log/
optimization.
Programming
Example of a cycle to measure an axis without optimization:
; Release brake
DEF INT AxNr=1
; Open the optimization session.
CYCLE751(1)
; For axis 1, the saved data are used from the user-defined file
RESULT_STRATEGY109_AX1.xml.
CYCLE752(AxNr,2,0,"/user/sinumerik/hmi/log/optimization/
RESULT_STRATEGY109_AX1.xml")
Special functions
664
Function Manual, 12/2018, A5E40874099B AB
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
; Start automatic measurement.
CYCLE751(4)
; Export the speed-controlled system in the CSV format.
CYCLE757(AxNr,"speedctrlplant.csv",3)
; Export the mechanical frequency response in the CSV format.
CYCLE757(AxNr,"mechresponse.csv",4)
; Export the speed control loop (calculated) in the CSV format.
CYCLE757(AxNr,"speedloopcalc.csv",5)
; Export the position control loop (calculated) in the CSV format.
CYCLE757(AxNr,"posloopcalc.csv",6)
; Export the speed control loop (measured) in the CSV format.
CYCLE757(AxNr,"speedloopmeas.csv",7)
; Export the position control loop (measured) in the CSV format.
CYCLE757(AxNr,"posloopmeas.csv",8)
; Close the optimization session.
CYCLE751(2)
M17
Special functions
Function Manual, 12/2018, A5E40874099B AB
665
T4: Automatic post optimization with AST (option) - only 840D sl
14.6 Examples
Special functions
666
Function Manual, 12/2018, A5E40874099B AB
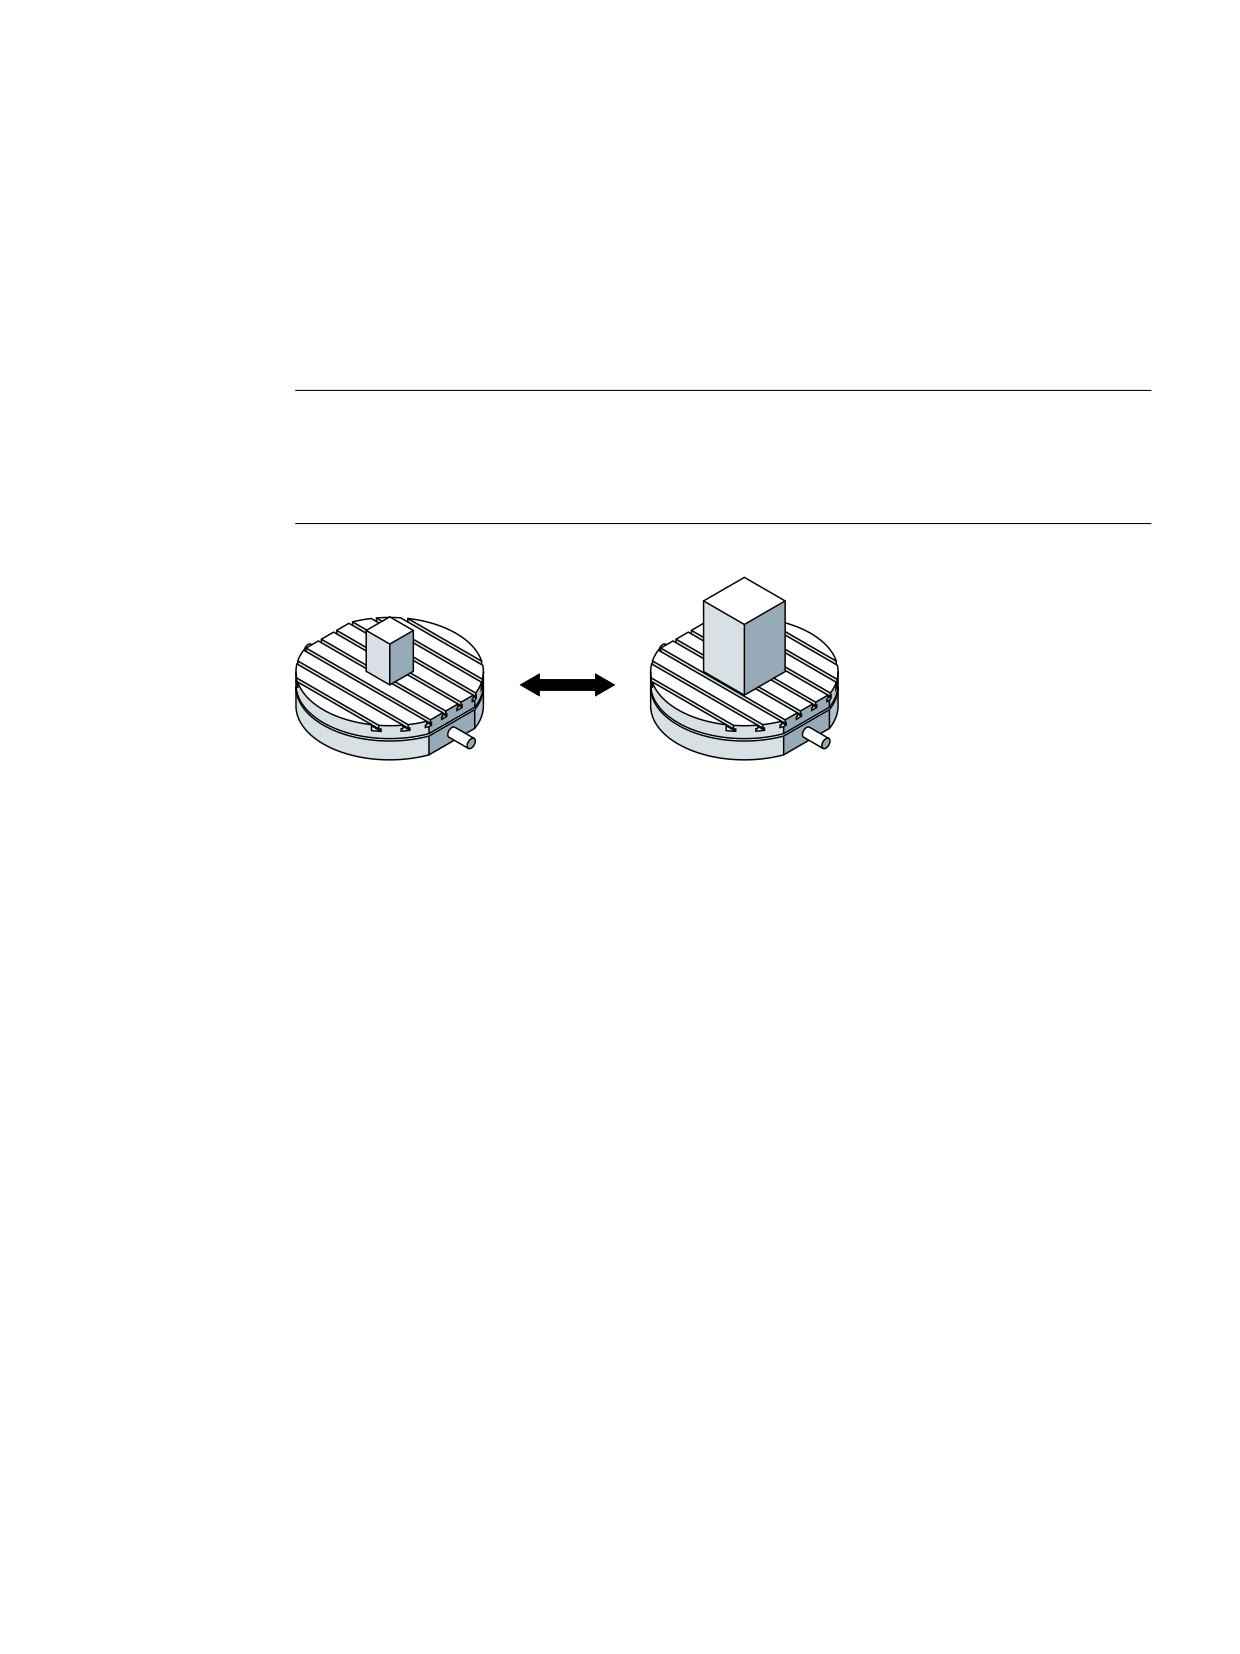
T5: Intelligent Load Control (optional) - 840D sl only
15
15.1
Function
Note
The function "Intelligent Load Control" is an option for SINUMERIK 840D sl that requires a
license.
Article no.: 6FC5800-0AS11-0YB0
,/&
You can use the function Intelligent Load Control (ILC) to adapt dynamic and control
parameters to the actual load of a rotary axis (rotary table, tool spindle, ...) using predefined
adaptation characteristic curves.
This results in the following advantages:
● Shorter machining times
● Increased dynamic response
● Greater accuracy
● Enhanced precision
Input variable and input value
The moment of inertia of the axis that depends on the load is used as the input variable for the
adaptation. The actual value to be determined for the input variable is used as the input value
for calculating the adaptation.
Output variable and adaptation factor.
The control calculates a scaling factor (adaptation factor) for the output variable of the
adaptation (dynamic or closed loop control parameter) based on the input value and the
predefined adaptation characteristic.
Commissioning
When setting up the function, the machine OEM defines the adaptations available on the
machine tool. Dialog boxes on the user interface support the machine OEM in this task:
Operating area "Commissioning" → "NC" → Menu forward key → softkey: "Adaptations"
Special functions
Function Manual, 12/2018, A5E40874099B AB
667

T5: Intelligent Load Control (optional) - 840D sl only
15.2 Parameterization
References:
For more detailed information see "CNC Commissioning Manual: NC, PLC, Drive".
The settings made in the user interface are entered in the relevant machine data (Page 668).
Activation/deactivation
When the control first runs up, the adaptation settings are inactive. The adaptation is activated/
deactivated by calling CYCLE782. The input value is also calculated or specified with this cycle.
References:
For information on how to operate and program cycle CYCLE782, see:
● Operating Manual Universal/Turning/Milling/Grinding,
Chapter "Programming a technological function (cycles)" >
"Load-dependent controller settings (CYCLE782)"
● Programming Manual Job planning, Chapter "Programming cycles externally" >
"Technological cycles" >"CYCLE782 - Adapting to load (option)"
15.2
Parameterization
Activation mode of an adaptation
The activation mode of an adaptation is set with machine data:
MD16501 $MN_CADAPT_MODE[<n>]
where <n> = number of the adaptation (0 ... 99)
Value
Meaning
0
Adaptation is not active (default setting)
1
Adaptation is permanently active
If activated with CYCLE782, permanently active adaptations remain active beyond program
end and channel reset. A previously programmed input value also remains active.
2
Adaptation can be activated temporarily
Temporarily activated adaptations are activated/deactivated by calling CYCLE782. On pro-
gram end or channel reset, all adaptations not deactivated with CYCLE782 are deactivated
implicitly.
Input variable of an adaptation
The input variable of an adaptation is specified in machine data:
MD16502 $MN_CADAPT_INPUT[<n>]
where <n> = number of the adaptation (0 ... 99)
Value
Meaning
1
The input variable for the adaptation is the moment of inertia of the axis.
Special functions
668
Function Manual, 12/2018, A5E40874099B AB
T5: Intelligent Load Control (optional) - 840D sl only
15.2 Parameterization
Output variable of an adaptation
The output variable is selected with machine data:
MD16503 $MN_CADAPT_OUTPUT[<n>]
where <n> = number of the adaptation (0 ... 99)
Value
Meaning
0
No output variable, no adaptation active (default setting)
1
Axis acceleration with dynamic mode DYNNORM
2
Axis acceleration with dynamic mode DYNPOS
3
Axis acceleration with dynamic mode DYNROUGH
4
Axis acceleration with dynamic mode DYNSEMIFIN
5
Axis acceleration with dynamic mode DYNFINISH
11
Position controller gain (servo gain factor)
12
Moment of inertia for torque feedforward control
21
Drive adaptation factor 1
22
Drive adaptation factor 2
23
Drive adaptation factor 3
24
Drive adaptation factor 4
Drive adaptation factor 1 ... 4
A maximum of 4 drive variables from parameter p2782[0...3] "Mode adaptation" can be
adapted.
● Kp speed controller P gain adaptation speed
● Tn speed controller integral time adaptation speed
● Current setpoint filter 1 denominator and numerator
● Current setpoint filter 2 denominator and numerator
● Speed setpoint filter 1 denominator and numerator
● Speed controller reference model natural frequency and damping
● APC / APC ECO Tv (p3769)
● APC / APC ECO filter (p3766)
Note
The adaptation of drive variables requires use of telegram 146, 148, or 149.
References:
● For information about adapting drive variables, see "SINAMICS S120 Drive Functions
Function Manual".
● For information about telegram 146/148/149, see "SINAMICS S120 Function Manual,
Communication".
Special functions
Function Manual, 12/2018, A5E40874099B AB
669

T5: Intelligent Load Control (optional) - 840D sl only
15.2 Parameterization
Machine axis number of the input variable
The input variable of an adaptation is assigned to a machine axis using machine data:
MD16504 $MN_CADAPT_INPUT_AX[<n>]
where <n> = number of the adaptation (0 ... 99)
Value
Meaning
0
No machine axis assigned, adaptation is not active (default setting)
1 ... 31
Number of the assigned machine axis
Machine axis number of the output variable
The output variable of an adaptation is assigned to a machine axis using machine data:
MD16505 $MN_CADAPT_OUTPUT_AX[<n>]
where <n> = number of the adaptation (0 ... 99)
Value
Meaning
0
No machine axis assigned, adaptation is not active (default setting)
1 ... 31
Number of the assigned machine axis
Adaptation characteristic
The characteristic curve of a load adaptation is defined by interpolation points that are derived
from fixed moment of inertia values and the associated scaling factors (0% ... 3000%) for the
output variable. The values between the interpolation points are interpolated linearly.
Two interpolation points are sufficient for a simple adaptation:
● MD16506 $MN_CADAPT_INPUT_VALUE_1[<n>] (input value 1 of the adaptation)
● MD16507 $MN_CADAPT_INPUT_VALUE_2[<n>] (input value 2 of adaptation)
● MD16508 $MN_CADAPT_OUTPUT_VALUE_1[<n>] (output value 1 of the adaptation)
● MD16509 $MN_CADAPT_OUTPUT_VALUE_2[<n>] (output value 2 of adaptation)
Special functions
670
Function Manual, 12/2018, A5E40874099B AB
T5: Intelligent Load Control (optional) - 840D sl only
15.3 Example
15.3
Example
For a rotary table with highly variable loading, the effective acceleration should be adapted to
the current moment of inertia. The function "Intelligent Load control" is used to increase
acceleration at minimal loading to 150 %.
$FFHOHUDWLRQ >
@
ZLWK DGDSWDWLRQ
ZLWKRXW DGDSWDWLRQ
-PLQ
-PD[
0RPHQW RI LQHUWLD >NJP @
Jmin
⇒ MD16506[0] $MN_CADAPT_INPUT_VALUE_1
Jmax
⇒ MD16507[0] $MN_CADAPT_INPUT_VALUE_2
150%
⇒ MD16508[0] $MN_CADAPT_OUTPUT_VALUE_1
100 %
⇒ MD16509[0] $MN_CADAPT_OUTPUT_VALUE_2
Special functions
Function Manual, 12/2018, A5E40874099B AB
671
T5: Intelligent Load Control (optional) - 840D sl only
15.3 Example
Special functions
672
Function Manual, 12/2018, A5E40874099B AB
TE01: Installation and activation of loadable compile
cycles
16
Contents
The following sections describe how technology and special functions in the form of individual
loadable compile cycle files (*.ELF) are installed and activated in the control.
Technology functions available from Siemens in the form of compile cycles
● 1D/3D clearance control in position control cycle
Compile cycle: CCCLC.ELF
References: Function Manual Special Functions; Clearance Control (TE1)
● Handling transformation package
Compile cycle: CCRCTRA.ELF
References: Function Manual Special Functions; Handling Transformation Package (TE4)
● Setpoint exchange
Compile cycle: CCSETP.ELF
References: Function Manual Special Functions; Setpoint Exchange (S9)
● Axial coupling in the machine coordinate system (MCS coupling)
Compile cycle: CCMCSC.ELF
References: Function Manual Special Functions; MCS Coupling (TE6)
● Continue machining at the contour (retrace support)
Compile cycle: CCRESU
References: Function Manual Special Functions; Retrace Support (TE7)
● Fast laser switching signal
Compile cycle: CCHSLC.ELF
References: Function Manual Special Functions; Cycle-Independent Path-Synchronous
Signal Output (TE8)
● Axis pair collision protection
Compile cycle: CCPROT.ELF
References: Function Manual Special Functions; Axis Pair Collision Protection (TE9)
Compile cycle files (*.ELF) and CNC software versions
Compile cycle files (*.ELF) that have been generated for CNC software versions up to SW 4.4
cannot run on systems with CNC software versions as of SW 4.5.
Technology and special functions provided by Siemens in the form of compile cycles
New compile cycle files (*.ELF) for Siemens technology and special functions for CNC software
versions as of SW 4.5 can be obtained from your regional Siemens sales office.
Special functions
Function Manual, 12/2018, A5E40874099B AB
673
TE01: Installation and activation of loadable compile cycles
16.1 Loading compile cycles
Technology and special functions provided by third parties in the form of compile cycles
Compile cycle files (*.ELF) that have been generated for CNC software versions up to SW 4.4
must be adapted and recompiled with the generation environment for CNC software versions
as of SW 4.5. Details on the adaptation of the user-specific technology and special functions
can be found in the the Open Architecture (OA) documentation.
Compile cycles
Compile cycles are functional expansions of the NC system software that can be created by
the machine manufacturer and/or by Siemens and then imported in the control later.
As part of the open NC system architecture, compile cycles have comprehensive access to
data and functions of the NC system level via defined software interfaces. In this way, compile
cycles significantly extend the functionality of the NC.
Including a compile cycle in the NC system software is performed by loading the compile cycle
into the file system of the NC. The compile cycle can be loaded at any time.
Siemens compile cycles
Siemens compile cycles are the technological functions supplied by Siemens.
When you order one of these technological functions, you get only the corresponding software
license number. To obtain the compile cycle in the form of a loadable file (".ELF" extension for
"executable and linking format") please contact your regional Siemens sales partner.
Note
Compile cycles created by Siemens are options that require explicit activation and licensing.
References:
Ordering information in Catalog NC 60/61
16.1
Loading compile cycles
16.1.1
Loading a compile cycle with SINUMERIK Operate
Requirement
● The compile cycle to be transferred to the control must be saved on a storage medium
which can be directly connected to the control, such as a USB-FlashDrive.
● Access authorization of protection level 1 "Machine manufacturer" (default password
"SUNRISE") must be available.
● If there are no cursor keys on the operator panel, a mouse or keyboard must be connected
in order to perform the operator actions.
Special functions
674
Function Manual, 12/2018, A5E40874099B AB
TE01: Installation and activation of loadable compile cycles
16.1 Loading compile cycles
Execution
Perform the following steps to load a compile cycle from a USB-FlashDrive, for example:
1. Insert the USB-FlashDrive in the USB interface on the front of the operator panel.
2. At the user interface, change into the "System data" area:
Horizontal softkey bar: "Operating area switchover" > "Commissioning" > "System data"
3. Open the USB-FlashDrive: Directory "USB" (keyboard: "Enter" key).
4. Select the compile cycle and copy it:
Vertical softkey bar: "Copy"
5. Within the "System data" area, switch into the directory "NC data" > "Compile cycles" and
insert the compile cycle there:
Vertical softkey bar: "Insert"
6. Initiate an NC reset to activate the compile cycle:
Horizontal softkey bar: "Operating area switchover" > "Commissioning" > "Machine data"
Vertical softkey bar: "Reset (po)"
16.1.2
Loading a compile cycle with HMI Advanced
Precondition
To transfer a compile cycle to the control, the following requirements must be met:
A storage medium (e.g. USB FlashDrive), which stores the compile cycle, is connected to the
PCU.
Execution
Perform the following operation to load a compile cycle from a USB FlashDrive to the NC:
1. Insert the USB FlashDrive into the PCU 50/70.
2. Open the USB FlashDrive as the local drive:
Operating area switchover > Services > Data admin > Local USB
If the "Local USB" is displayed as disabled, it implies the USB FlashDrive was not detected.
Wait until HMI Advanced has detected the USB FlashDrive.
3. Select the compile cycle and copy it:
vertical "Copy" softkey
4. Go to the OEM directory of the NC card:
ETC key (">") > "NC card" > Directory: "cc" or "Loadable Compile Cycles"
5. Add the compile cycle to the NC card's OEM directory:
Vertical "Add" softkey
6. Initiate an NCK reset.
Special functions
Function Manual, 12/2018, A5E40874099B AB
675
TE01: Installation and activation of loadable compile cycles
16.2 Interface version compatibility
16.1.3
Loading a compile cycle from an external computer with WinSCP3
Precondition
To transfer a compile cycle to the control, the following requirements must be met:
● The external computer (programming device / PC) which the compile cycle is loaded onto
is linked to the PCU via a network (TCP / IP).
● The program "WinSCP3" is installed on the external computer.
● The host name or the IP address of the PCU is known.
● The user name and the password to log onto the PCU are known.
Execution
Perform the following operations to load a compile cycle from an external computer into the
NC:
1. Start the "WinSCP3" program on the external computer (programming device / PC)
2. Establish a connection to the PCU by selecting an appropriate profile or by entering the
host name or IP address, the user name and the password.
3. Copy the compile cycle from the external computer into the following directory on the PCU:
/oem/sinumerik/data/cc
The file name of the compile cycle should have any capital letters in the directory of the
PCU.
4. Initiate an NC reset.
16.2
Interface version compatibility
A SINUMERIK-specific interface is used for communication between the compile cycle and
NC system software. The interface version used by the loaded compile cycle must be
compatible with the interface version of the NC system software.
Special functions
676
Function Manual, 12/2018, A5E40874099B AB
TE01: Installation and activation of loadable compile cycles
16.2 Interface version compatibility
Interface versions
The relevant interface versions are displayed under:
●
Interface version of the NC system software
HMI Advanced:
Diagnosis > Service Display > Version > NCU Version
Display (excerpt)
-------------------------------------------
CC Interface Version:
@NCKOPI
@Interfaces=<1. Position>.<2. Position>
Loaded Compile Cycles:
-------------------------------------------
●
Interface version of a compile cycle that has not yet been loaded
HMI Advanced (excerpt):
Services > <Medium> > Softkey: "Properties"
Display:
-------------------------------------------
Contents: Loadable compile cycle
Interface:
@Interfaces=<1. Position>.<2. Position>
-------------------------------------------
●
Interface version of a loaded compile cycle
HMI Advanced:
Diagnosis > Service Display > Version > NCU Version
Display (excerpt)
-------------------------------------------
CC Interface Version:
@NCKOPI
Loaded Compile Cycles:
<Identifier> <Version> <Generation Data>
CC start address
_N_<Identifier><Version>IF<1st Position><2nd Position>_ELF . . .
-------------------------------------------
Example:
_N_CLC407IF003001_ELF corresponds to interface version: 3.1
Dependencies
The following dependencies exist between the interface versions of a compile cycle and the
NC system software:
●
1. Position of the interface version number
The 1st position of the interface version number of a compile cycle and the NC system
software must be the same.
●
2. Position of the interface version number
The 2nd position of the interface version number of a compile cycle must be less than or
equal to the 2nd position of the NC system software.
Note
If alarm 7200 is displayed after powering-up, this means no compile cycle has been loaded!
Special functions
Function Manual, 12/2018, A5E40874099B AB
677
TE01: Installation and activation of loadable compile cycles
16.4 Activating the technological functions in the NC
16.3
Software version of a compile cycle
The SW version of a compile cycle is displayed under:
HMI Advanced:
Diagnosis > Service Display > Version > NCU Version
Display (excerpt)
-------------------------------------------
CC Interface Version:
@NCKOPI
Loaded Compile Cycles:
<Identifier> <Version> <Generation Data>
CC start address
_N_<Identifier><Version>IF<1st digit><2nd digit>_ELF . . .
Code=<Address> Data=<Address> . . .
-------------------------------------------
Example:
_N_CLC407IF003001_ELF corresponds to software version 4.7
Note
The display of code and data range start addresses of a compile cycle are provided for
diagnostics purposes only and have no significance in normal operation.
16.4
Activating the technological functions in the NC
Requirement
The corresponding option must be enabled before activating a technology function as
described below.
If the option data has not been set, the following alarm appears every time the NC powers up
- and the technology function will not be activated:
Alarm 7202 "XXX_ELF_option_bit_missing: <bit number>"
Function-specific machine data
Each technology function loaded by compile cycle creates a function-specific global NC
machine data within the range of numbers from 60900 to 60999 in accordance with the
following pattern:
$MN_CC_ACTIVE_IN_CHAN_<identifier>[n], with n = 0, 1
Example:
Special functions
678
Function Manual, 12/2018, A5E40874099B AB
TE01: Installation and activation of loadable compile cycles
16.6 Creating alarm texts
$MN_CC_ACTIVE_IN_CHAN_MCSC[0]
$MN_CC_ACTIVE_IN_CHAN_MCSC[1]
Activation for the 1st NC channel
The technology functions are activated in the first NC channel via:
$MN_CC_ACTIVE_IN_CHAN_<identifier>[0], bit0 = 1
The meaning of machine data bits Bit1 - Bit31 are described in the relevant function description
(TE1 - REn).
After the NC powers up the next time, the activated technology functions are integrated into
the system software.
CAUTION
SINUMERIK 840D sl
The following alarm is displayed when a bit is set for the first time in the function-specific NC
machine data:
$MN_CC_ACTIVE_IN_CHAN_XXXX[0]
:
Alarm 4400 "MD modification causes reorganization of the buffered memory (data loss)"
And you are warned that all user data (part programs, tool data, etc.) will be deleted on the
next run-up. If necessary, an archive should be created after setting the date and before
initiating an NC RESET.
16.5
Function-specific startup
Further function-specific installation routines are described in the corresponding function
description (TE1 - TEn).
16.6
Creating alarm texts
The alarm texts of the technology functions are stored in the system. If a new alarm is required,
then the alarm texts can be supplemented accordingly. The general process depends on the
existing interface.
16.6.1
Creating alarm texts with SINUMERIK Operate
The following alarms should be added to the alarm texts of the technology functions:
075999 0 0 "Channel %1 Block %2 Call parameter is invalid"
Special functions
Function Manual, 12/2018, A5E40874099B AB
679
TE01: Installation and activation of loadable compile cycles
16.6 Creating alarm texts
Proceed as follows
1.
Please copy the "oem_alarms_deu.ts" file from the "/siemens/sinumerik/hmi/template/lng"
directory to the "/oem/sinumerik/hmi/lng" directory.
2.
Rename the file ("xxx_deu.ts").
3.
Open the file in the editor and add the new alarm number and the new alarm text in German:
<message>
<source>075999/NCK</source>
<translation>
Channel %1 block %2 call parameter is invalid
</translation>
</message>
Note
Each alarm starts with the <message> tag and ends with the </message> tag. The
<source> tag contains the alarm number and the source URL. The <translation> tag
contains the alarm text.
4.
To create an alarm text file in a foreign language, copy the just changed file and modify the
language code in the filename (e.g., "xxx_eng.ts for English").
5.
Open the foreign language alarm text file in the editor and record the translated alarm text
in the <translation> tag.
6.
Copy the example configuration file "oem_slaesvcadapconf.xml" from directory "/siemens/
sinumerik/hmi/template/cfg" into directory "/oem/sinumerik/hmi/cfg".
7.
Rename the file to "slaesvcadapconf.xml".
8.
Open the "slaesvcadapconf.xml" file in the editor and enter the new base name (filename
of the newly created alarm text file without language code and postfix), e.g.:
<BaseNames>
<BaseName_02 type="QString" value="xxx"/>
</BaseNames>
9.
Restart SINUMERIK Operate.
More information about creating alarm texts with SINUMERIK Operate can be found in:
References:
SINUMERIK 840D sl Base Software and Operating Software Commissioning Manual;
SINUMERIK Operate (IM9) Commissioning Manual, Section: Configuring machine data/alarms
16.6.2
Creating alarm texts with HMI Advanced
The following alarms should be added to the alarm texts of the technology functions:
075999 0 0 "Channel %1 Sentence %2 Call parameter is invalid"
Special functions
680
Function Manual, 12/2018, A5E40874099B AB
TE01: Installation and activation of loadable compile cycles
16.7 Upgrading a compile cycle
Proceed as follows
1. Copy the "mbdde.ini" file from the "F:\mmc2" directory to the "F:\oem" directory.
2. Add the following two lines in the "mbdde.ini" file:
[TextFiles]
UserCZYK=F:\oem\alc_
3. Create the language-dependent "alc_XX.com" text files in the "F:\oem" directory, e.g.:
"alc_GR.com" for German
"alc_UK.com" for English
4. Insert the new alarm text in the language-dependent text files, e.g.:
075999 0 0 "Channel %1 Sentence %2 Call parameter is invalid"
in the text file in German.
5. Restart HMI Advanced.
For more information about creating alarm texts with HMI Advanced, please refer to:
References:
SINUMERIK 840Di sl/840D sl/840D Base Software and HMI Advanced Commissioning
Manual; HMI-Advanced (IM4) Commissioning Manual, Section: Configuring user alarms
Note
HMI reinstallation
Retain the added alarm texts in the text files of the F:\oem even after a reinstallation of HMI.
16.7
Upgrading a compile cycle
To upgrade a compile cycle installed in the control, under no circumstances is it sufficient to
just exchange the corresponding ELF file. If only the ELF file is exchanged, then this can result
in undefined behavior of the NC software due to inconsistent data of the memory and data
management.
Execution
Perform the following actions to upgrade a compile cycle:
1. Create an NC archive without compile cycles:
Operating area: "Commissioning" > "ETC" key > "Commissioning archive" > "Creating a
commissioning archive" > "OK" >
- Selection: "NC data" selected
- Selection: not selected "with compile cycles"!
2. Delete the old compile cycle:
Operating area: "Commissioning" > "System data" in the directory: NC data> "Compile
cycles" > File: <Identifier>.ELF
3. Download the new compile cycle (see Section "Loading compile cycles (Page 674)")
Special functions
Function Manual, 12/2018, A5E40874099B AB
681
TE01: Installation and activation of loadable compile cycles
16.8 Deleting a compile cycle
4. Initiate a power on reset with an NC general reset (NC commissioning switch: position "1").
See:
References:
Commissioning Manual IBN CNC: NC, PLC, Drive; Section: General tips > Separate NC
and PLC general reset > NC general reset
5. Download the NC archive created under Point 1 into the NCU again.
Operating area: "Commissioning" > "ETC" key > "Commissioning archive" > "Read-in
commissioning archive" > "OK"
Note
Version check
To check the version of the newly loaded compile cycle (see Section "Software version of a
compile cycle (Page 678)").
Several loaded compile cycles
If several compile cycles are loaded in the control, when upgrading a compile cycle according
to the process described above, the other compile cycles remain unchanged.
Newly created data
If the new compile cycle creates new data, which were still not available in the previous version,
then after subsequently booting the control, these are preassigned default values.
16.8
Deleting a compile cycle
If a loaded compile cycle is to be completely deleted in the control, it is not enough to only
delete the corresponding ELF file. With this procedure, the following data is kept in the retentive
memory of the control:
● Activation data: $MN_CC_ACTIVE_IN_CHAN_<identifier>[n]
● Function-specific machine data
Execution
Perform the following actions to delete a compile cycle:
1. Create an NC archive without compile cycles:
Operating area: "Commissioning" > "ETC" key > "Commissioning archive" > "Creating a
commissioning archive" > "OK" >
- Selection: "NC data" selected
- Selection: not selected "with compile cycles"!
2. Delete the compile cycle:
:Operating area: "Commissioning" > "System data" in the directory: NC data> "Compile
cycles" > File: select "<Identifier>.ELF" > "Delete"
Special functions
682
Function Manual, 12/2018, A5E40874099B AB

TE01: Installation and activation of loadable compile cycles
16.9 Data lists
3. Initiate a power on reset with an NC general reset (NC commissioning switch: position "1").
See:
References:
Commissioning Manual IBN CNC: NC, PLC, Drive; Section: General tips > Separate NC
and PLC general reset > NC general reset
4. Download the NC archive created under Point 1 into the NCU again.
Operating area: "Commissioning" > "ETC" key > "Commissioning archive" > "Read-in
commissioning archive" > "OK"
Note
Several loaded compile cycles
If several compile cycles are loaded in the control, when deleting a compile cycle according
to the process described above, the other compile cycles remain unchanged.
Efficient memory usage
To use the memory resources in the NC as efficiently as possible, you should only load the
compile cycles (ELF files) that are actually required into the machine.
16.9
Data lists
16.9.1
Machine data
16.9.1.1
NC-specific machine data
Number
Identifier: $MN_
Description
60900 + i
CC_ACTIV_IN_CHAN_XXXX[n]
n = 0:
Activating the technology function in NC channels
with:
with:
i = 0, 1, 2,
XXXX = function code
n = 1:
3, ...
n = 0 or 1
Additional functions within the technology function
Special functions
Function Manual, 12/2018, A5E40874099B AB
683
TE01: Installation and activation of loadable compile cycles
16.9 Data lists
Special functions
684
Function Manual, 12/2018, A5E40874099B AB
TE02: Simulation of Compile Cycles (only HMI
Advanced)
17
17.1
Brief description
17.1.1
Function
If, at the SINUMERIK user interface "HMI Advanced" part programs are simulated that use
compile cycles, depending on the compile cycle being used, general specific conditions must
be established. These are described in the subsequent chapters.
17.2
OEM transformations
When using OEM transformations, the simulation runtime environment has to be set.
Proceed as follows
1. On the computer, on which HMI Advanced is installed, in addition to the directory available
as standard "<HMI Advanced installation path>/MMC2", create a new directory "<HMI
Advanced installation path>/OEM".
2. In the "OEM" directory, create the file "DPSIM.TEA" with the following content:
$MN_NC_USER_CODE_CONF_NAME_TAB[196]="TRAORI"
$MN_NC_USER_CODE_CONF_NAME_TAB[197]="_TRAORI"
$MN_NC_USER_CODE_CONF_NAME_TAB[198]="TRACON"
$MN_NC_USER_CODE_CONF_NAME_TAB[199]="_TRACON"
CHANDATA(1)
$MC_AXCONF_GEOAX_ASSIGN_TAB[0]=1
$MC_AXCONF_GEOAX_ASSIGN_TAB[1]=2
$MC_AXCONF_GEOAX_ASSIGN_TAB[2]=3
$MC_TRAFO_RESET_VALUE=0
; Make sure that transformation types 4096 - 4101 are deleted
$MC_TRAFO_TYPE_1=0
$MC_TRAFO_TYPE_2=0
$MC_TRAFO_TYPE_3=0
; Delete transformation chains with OEM transformations
$MC_TRACON_CHAIN_1[0]=0
$MC_TRACON_CHAIN_1[1]=0
; NOTICE! No spaces after M30
M30
3. In the "OEM" directory, create the file "DPSIM.INI" with the following content:
[PRELOAD]
CYCLES=1
CYCLEINTERFACE=0
Special functions
Function Manual, 12/2018, A5E40874099B AB
685
TE02: Simulation of Compile Cycles (only HMI Advanced)
17.2 OEM transformations
4. Close the HMI application.
5. Launch the HMI application.
6. In the directory for the manufacturer cycles, create the file "TRAORI.SPF" with the following
content:
PROC TRAORI(INT II)
RET
7. In the directory for the manufacturer cycles, create the file "TRACON.SPF" with the
following content:
PROC TRACON(INT II)
RET
Note
The "TRAORI.SPF" and "TRACON.SPF" manufacturer cycles created under 6. and 7. must
not be loaded onto the NC.
8. Start the simulation.
9. Run a data comparison for the cycles after the simulation has started up:
HMI Advanced: Data comparison > Compare cycles
Note
At least the password for protection level 3 "End user: Service" is needed for the data
comparison.
Special functions
686
Function Manual, 12/2018, A5E40874099B AB